مساحة للاحتفاء بالعقول الجامعية العراقية ومشاريعها المبتكرة. اكتشف تفاصيل الفرق الفائزة وأفكارها العلمية، وشاهد العروض والملفات الأصلية للمشاريع.
32مشروعاً فائزاً
16جامعة مشاركة في الفوز
6مسارات علمية
الفرق والمشاريع الفائزة
تصفّح المشاريع بحسب المسار أو الجامعة، واضغط على أي مشروع لعرض ملفه الكامل.
عدد المشاريع: 32
المركز الأولالمسار الزراعي
NURAI2026-0653
Sanabel A Smart System for Plant-Health Monitoring with Artificial Intelligence
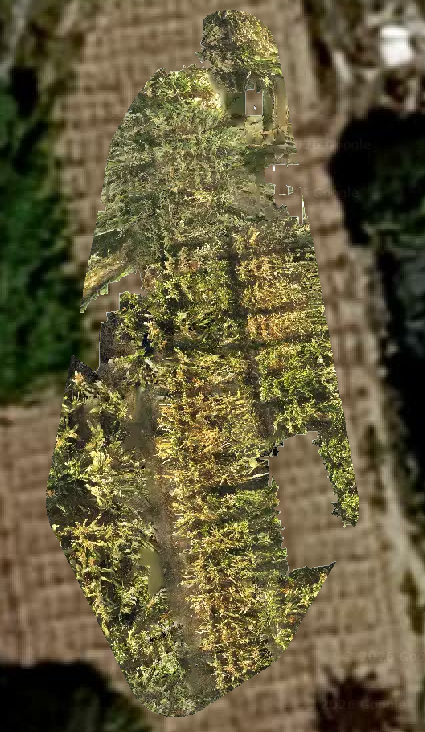
Sanabel is an integrated smart AgriTech platform for monitoring corn crop health in Iraqi agricultural fields, combining UAV technology, artificial in…
الجامعة: جامعة النهرين
الفريق: فريق صناع الأثر
المشرف: د.مصطفى سعد ايوب
NURAI2026-0653 · المسار الزراعي
Sanabel A Smart System for Plant-Health Monitoring with Artificial Intelligence
فريق صناع الأثر — جامعة النهرين
المركز الأول
نبذة عن المشروع
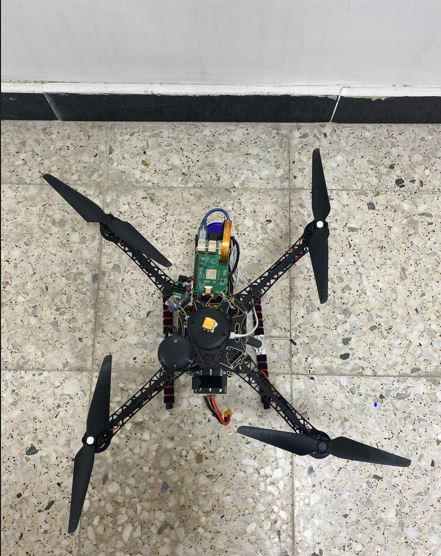
Sanabel is an integrated smart AgriTech platform for monitoring corn crop health in Iraqi agricultural fields, combining UAV technology, artificial intelligence, and IoT-based sensing into a unified system.
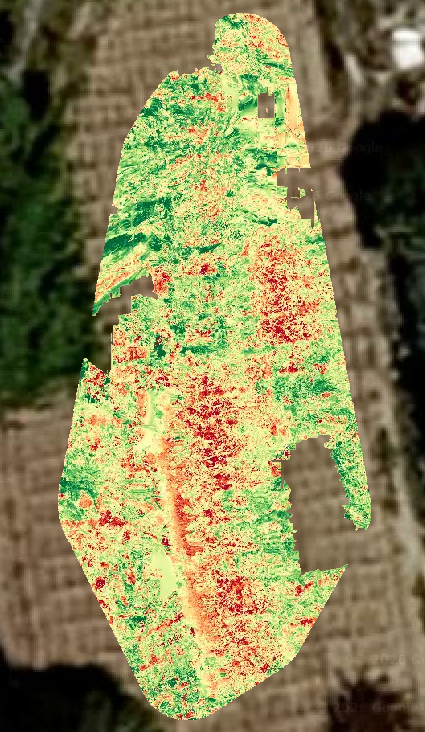
The platform uses a Parrot ANAFI 4K drone to capture high-resolution aerial imagery of the field, which is analyzed through a YOLOv8-based AI model for early detection of corn diseases such as Northern Leaf Blight, Maize Streak Virus, and Gray Leaf Spot. The system integrates solar-powered ground stations equipped with RS485 soil sensors that measure humidity, temperature, and nutrient levels (NPK), communicating wirelessly via LoRa to a central Raspberry Pi 5 processing unit. Aerial imagery is further processed using WebODM to generate orthophoto maps and NDVI-based vegetation health analysis.
Tested on a real corn field at the University of Baghdad, Sanabel achieved an 89.4% photogrammetric reconstruction success rate and identified Northern Leaf Blight as the dominant disease with 88.0% average detection confidence across the monitored field. The project aims to empower farmers with early disease detection, optimize water usage, and increase crop productivity, offering a practical and sustainable solution suited to Iraq's challenging environmental conditions.
بيانات المشروع والفريق
الجامعةجامعة النهرين
المسار العلميالمسار الزراعي
الفريقفريق صناع الأثر
الترتيب النهائيالمركز الأول
التقييم النهائي92.80 / 100
المحافظةبغداد
الإشراف الأكاديمي
د
د.مصطفى سعد ايوب
المشرف الأكاديمي
أعضاء الفريق (5)
ح
حسين عدنان ناجي
قائد الفريق · Bachelor
ض
ضوى حيدر عزيز
AI/Control · Bachelor
ف
فاطمة الزهراء محمد عبد الامير
Programmer · Bachelor
م
ملاك عبد الكريم جابر شنجار
Electronics · Bachelor
ي
ياسر عدنان سعود
Electronics · Bachelor
المركز الأولالمسار الصناعي
NURAI2026-0614
AI-Enhanced Automated 4-Axis Hot Wire Foam Cutting Machine
This project demonstrates the architectural design, and manufacturing processes, and implemented AI tools involved in the proposed automated four-axis…
الجامعة: الجامعة التكنولوجية
الفريق: Orbit Team
المشرف: د. مازن غازي عبد الرزاق
NURAI2026-0614 · المسار الصناعي
AI-Enhanced Automated 4-Axis Hot Wire Foam Cutting Machine
Orbit Team — الجامعة التكنولوجية
المركز الأول
نبذة عن المشروع
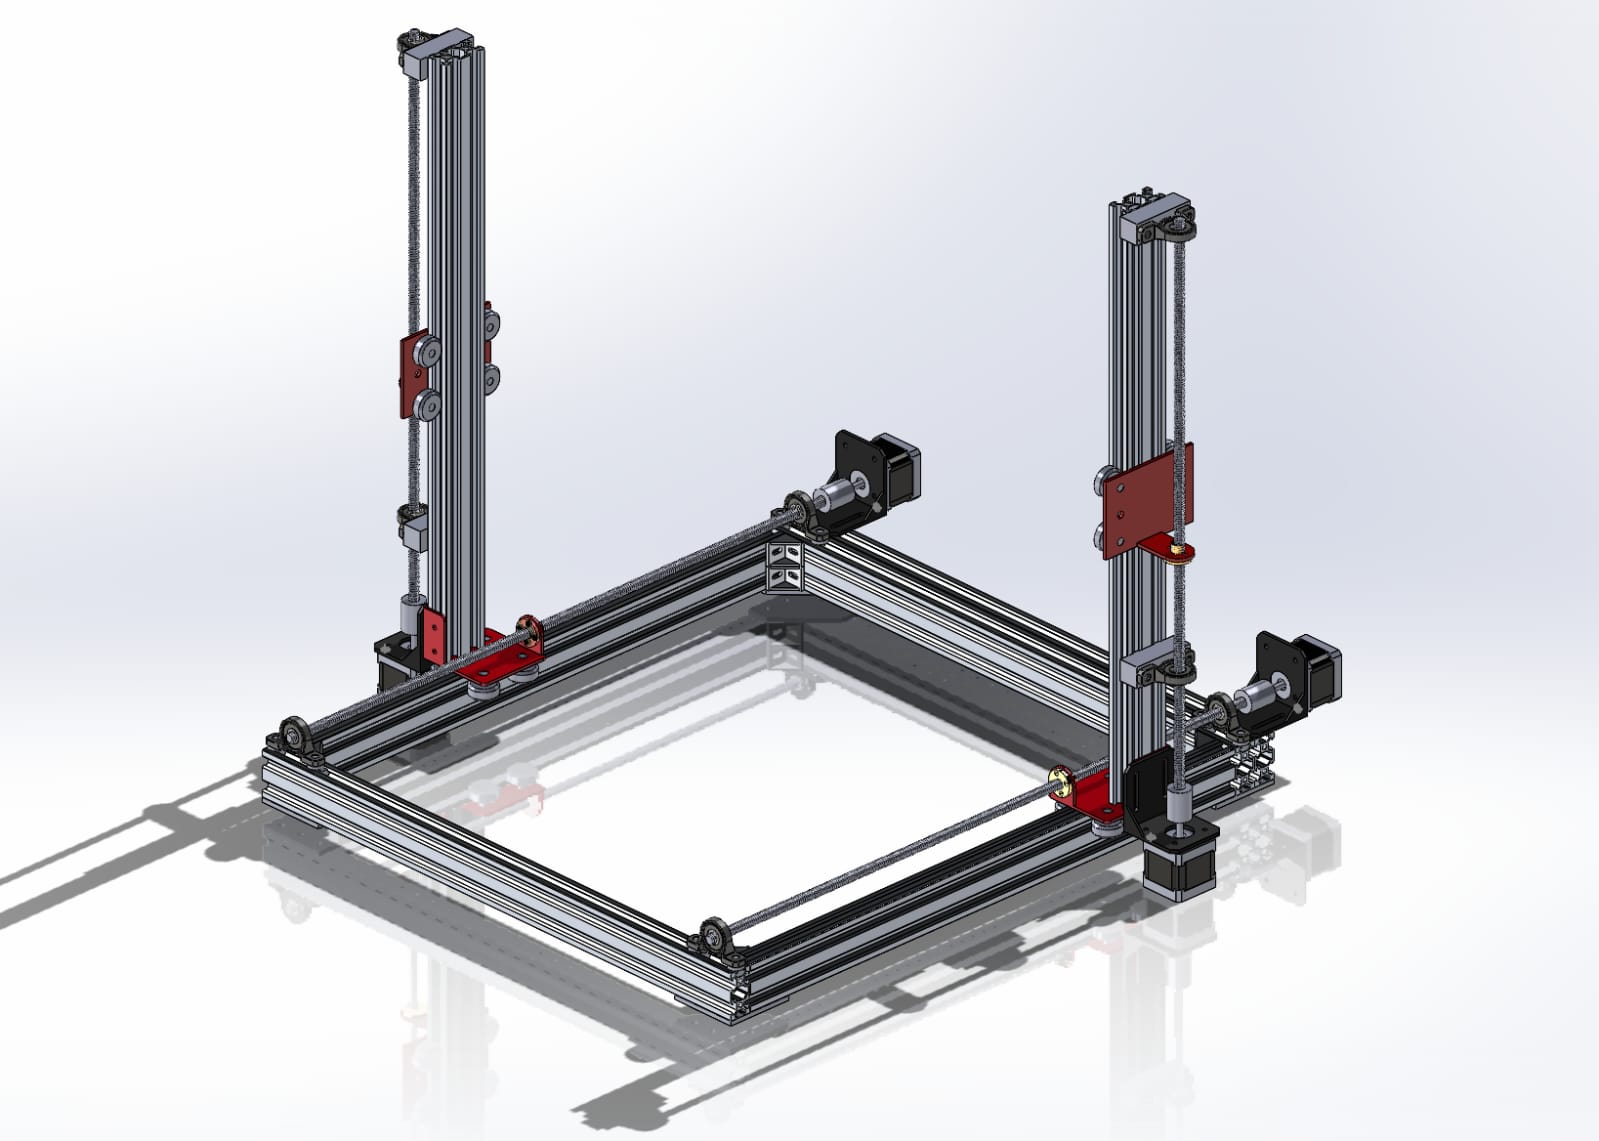
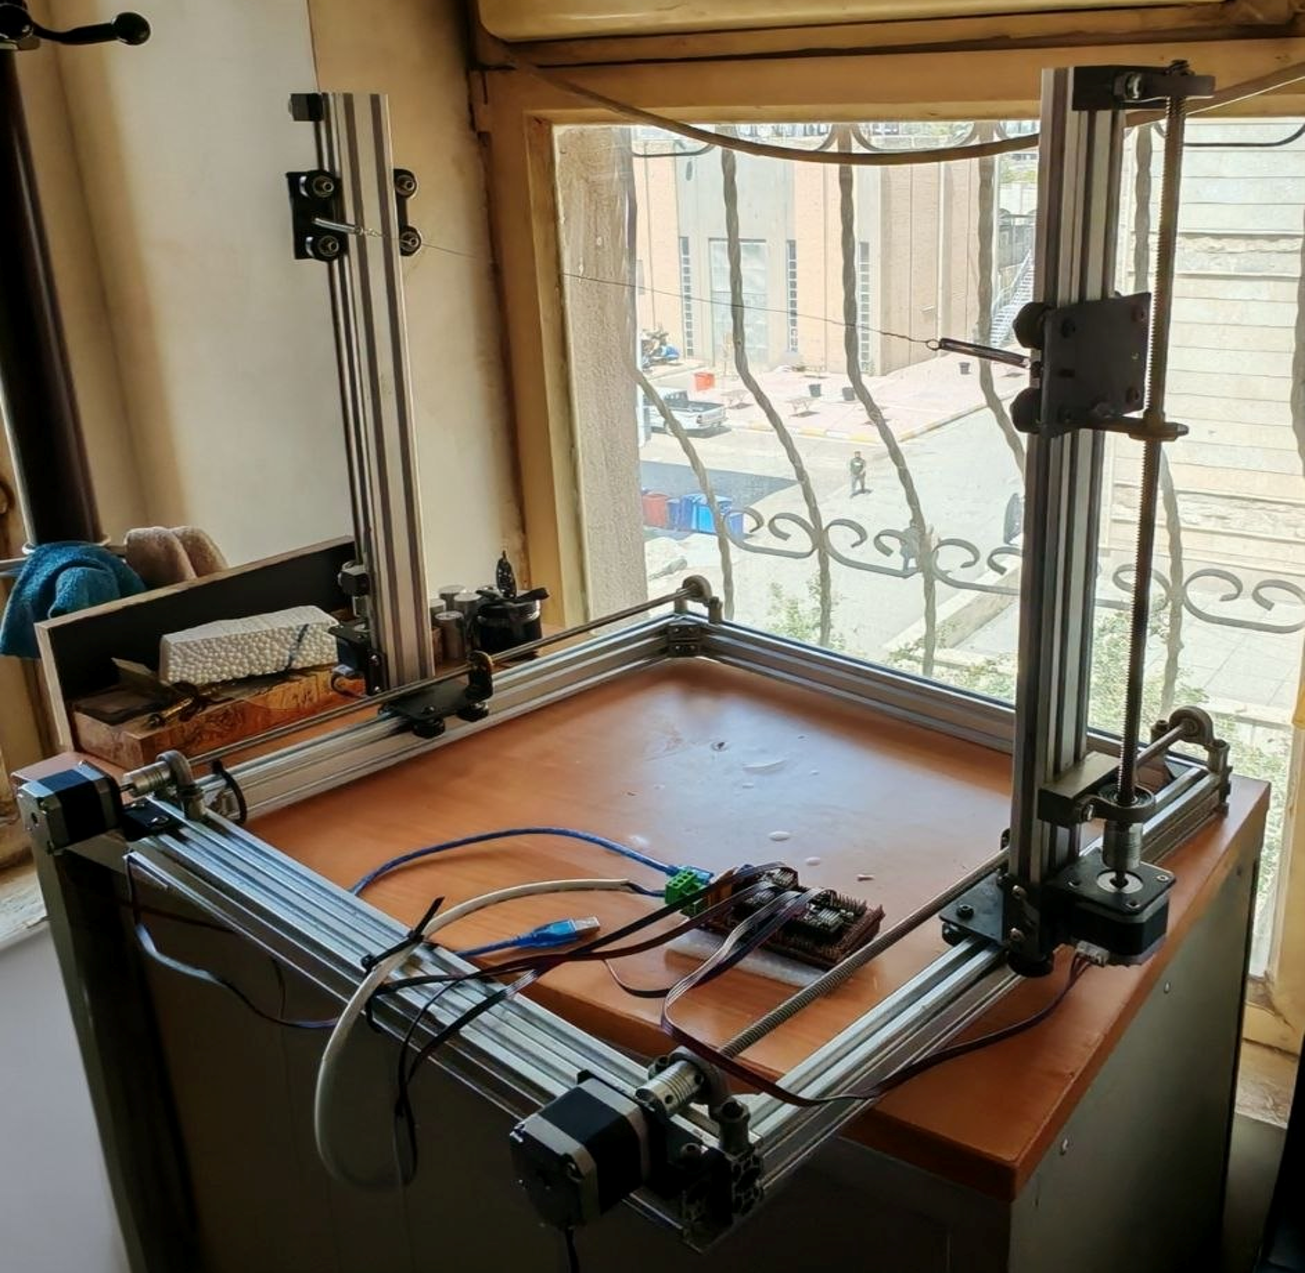
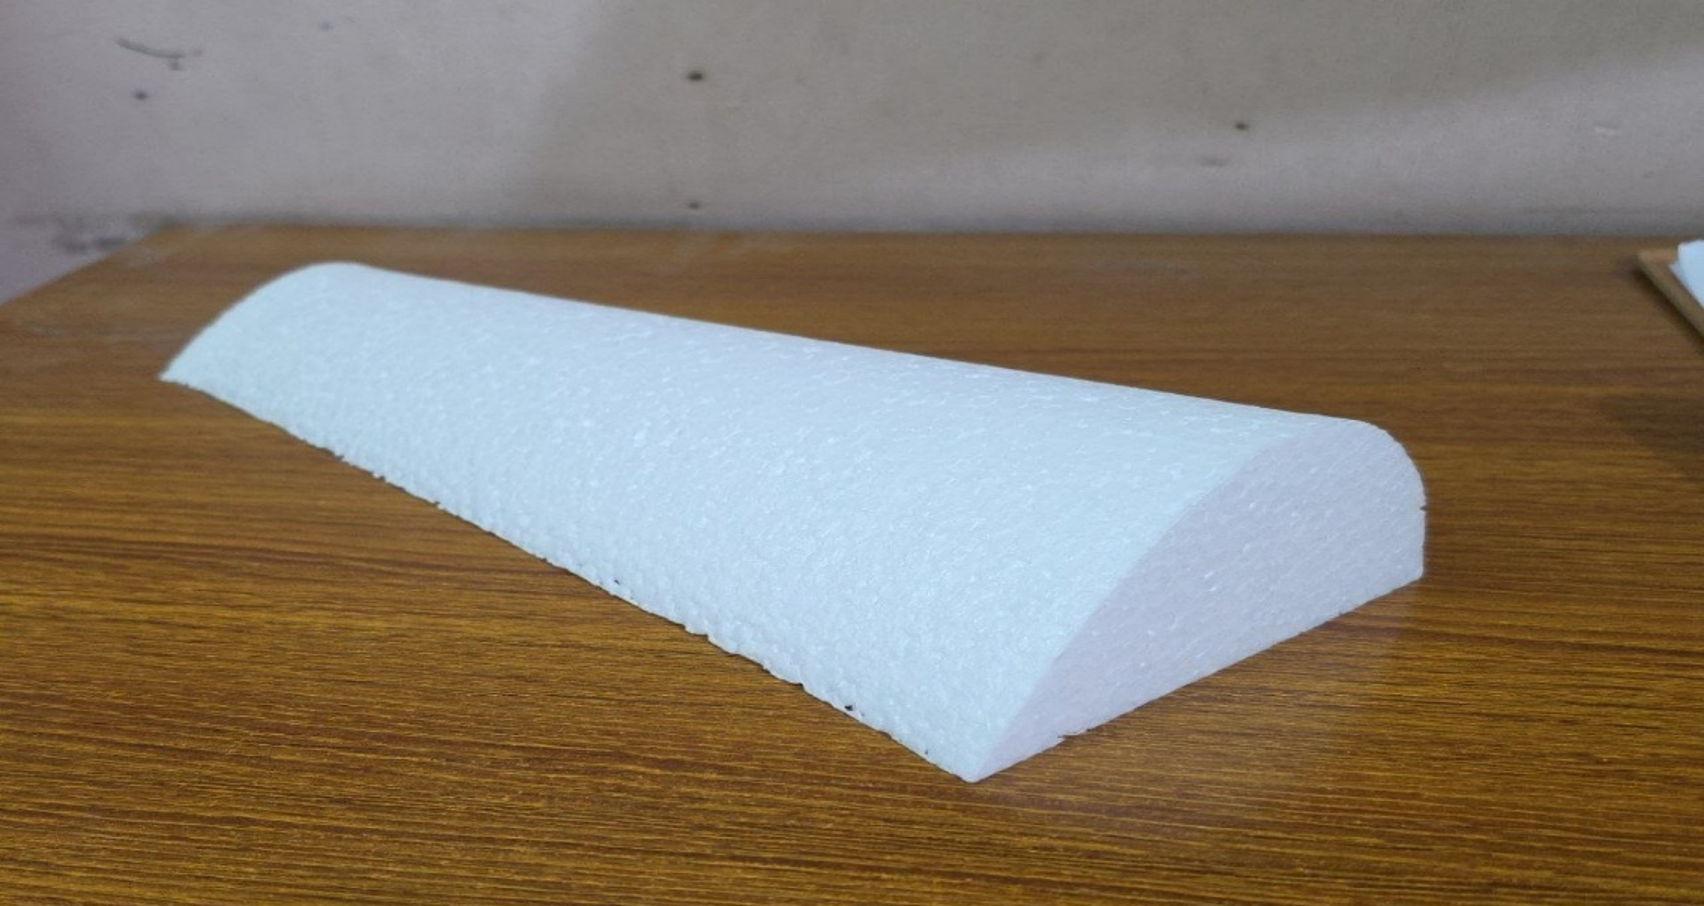
This project demonstrates the architectural design, and manufacturing processes, and implemented AI tools involved in the proposed automated four-axis computer numerical control (CNC) hotwire foam cutting machine. The aim is to cut extruded polystyrene (EPS/XPS) foam three-dimensions (3D) profiles in an optimal time while keeping consistent precise cuts. The machine was designed using SOLIDWORKS software and fabricated via different techniques including wire-cutting, sheet metal bending, and welding. The Grbl Hot Wire software is used to control the proposed machine; however, it is not open source and therefore cannot be modified. To overcome this limitation, the Cursor IDE AI tool is employed to enhance the original software by adding an extension window, integrated with the Gemini chatbot, alongside the Grbl interface. This enhancement enables the conversion of images, CAD models, and other supported file formats into editable and customizable G-code. The generated G-code is then transmitted to the 4-axis machine through an Arduino Mega controller, which can be readily upgraded to accommodate future enhancements and additional functionalities. A Molybdenum hotwire was chosen for the cutting based on the criteria of being the cheapest and available yet most suitable option for this application. Furthermore, other calculations were implemented to make sure that all the energy consumption, wire elongation and ideal cutting temperature match the desired goal. The final outcome of this project is a machine moves within four-dimensional coordinate framework (X-Y-Z-A) which can easily be upgraded into 5-axis or more, that allows it to execute asymmetrical, highly tapered and transitionary geometries like aerodynamic and airfoils. While the machine presents an outstanding dimensional accuracy, it is also considered a full platform cost-effective, upgradable, highly scalable and an adequate rapid prototyping choice.
بيانات المشروع والفريق
الجامعةالجامعة التكنولوجية
المسار العلميالمسار الصناعي
الفريقOrbit Team
الترتيب النهائيالمركز الأول
التقييم النهائي89.20 / 100
المحافظةبغداد
الإشراف الأكاديمي
د
د. مازن غازي عبد الرزاق
المشرف الأكاديمي
أعضاء الفريق (3)
ح
حسين عامر موسى
Other · Bachelor
م
محمد الجواد ياسر هادي
Electronics · Bachelor
م
محمد صفاء عطوان
Other · Bachelor
المركز الأولالمسار الطبي
NURAI2026-0882
Al-Based Liver Disease Diagnosis & Patient Monitoring System
Abstract Liver disease is a "silent killer" whose complex early diagnosis often leads to physician burnout. To address this, we developed a comprehens…
الجامعة: الجامعة التقنية الشمالية
الفريق: دقة
المشرف: د.اسراء تحسين علي
NURAI2026-0882 · المسار الطبي
Al-Based Liver Disease Diagnosis & Patient Monitoring System
دقة — الجامعة التقنية الشمالية
المركز الأول
نبذة عن المشروع
Abstract
Liver disease is a "silent killer" whose complex early diagnosis often leads to physician burnout. To address this, we developed a comprehensive, AI-Based Liver Disease Diagnosis System that is both highly accurate and user-friendly for clinical settings. Methodologically, we engineered a "multi-model ecosystem." After initially testing the Random Forest algorithm, we selected XGBoost as our primary engine for its superior speed and accuracy, pairing it with strict deterministic logic. Guided by a "Data Quality over Quantity" philosophy, we rigorously cleaned our datasets and removed statistical noise. This approach proved that AI learns far better from small, verified clinical facts than from massive, messy data. As an outcome, this rigorous approach yielded exceptional performance across all stages of the diagnostic pipeline. The system’s "Gate Model" used for initial patient triage achieved an accuracy of 97.41%. For specific disease pathways, the deterministic Fatty Liver (NAFLD) model achieved 100.00% accuracy. The specialized XGBoost engines successfully achieved 95.24% accuracy in predicting Hepatitis C (HCV) complications, 71.43% in assessing HCV mortality status using strictly verified data, 62.50% in classifying complex HCV fibrosis stages, and 94.00% in evaluating Hepatocellular Carcinoma (Liver Cancer) risk. Ultimately, by integrating these models into a seamless full-stack web application, this research provides a highly reliable, practical tool that helps shift liver healthcare from reactive treatment to proactive, life-saving prevention.
بيانات المشروع والفريق
الجامعةالجامعة التقنية الشمالية
المسار العلميالمسار الطبي
الفريقدقة
الترتيب النهائيالمركز الأول
التقييم النهائي90.20 / 100
المحافظةنينوى
الإشراف الأكاديمي
د
د.اسراء تحسين علي
المشرف الأكاديمي
أعضاء الفريق (3)
ع
عبدالله اياد ثابت
قائد الفريق · Bachelor
ع
علي أحمد محمد
Programmer · Bachelor
ي
يحيى زهير فتاح
AI/Control · Bachelor
المركز الأولمسار التربية والتعليم
NURAI2026-0020
CyberGuard AI
Problem Statement: Students in the Cybersecurity Department often struggle to get immediate answers to course-related questions outside office hours. …
الجامعة: الجامعة التقنية الوسطى
الفريق: فريق الأمن السيبراني
المشرف: حسن هادي خيون
NURAI2026-0020 · مسار التربية والتعليم
CyberGuard AI
فريق الأمن السيبراني — الجامعة التقنية الوسطى
المركز الأول
نبذة عن المشروع
Problem Statement:
Students in the Cybersecurity Department often struggle to get immediate answers to course-related questions outside office hours. There is no dedicated support system available at the department entrance, leading to delays in learning and reduced student engagement.
Proposed Solution/Innovation:
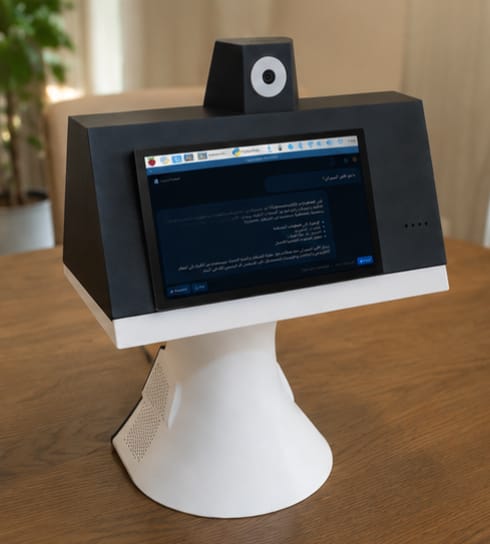
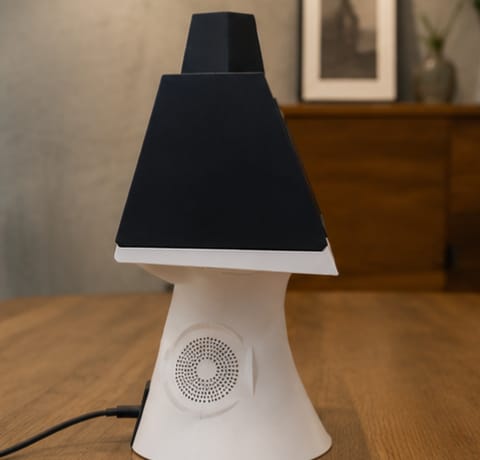
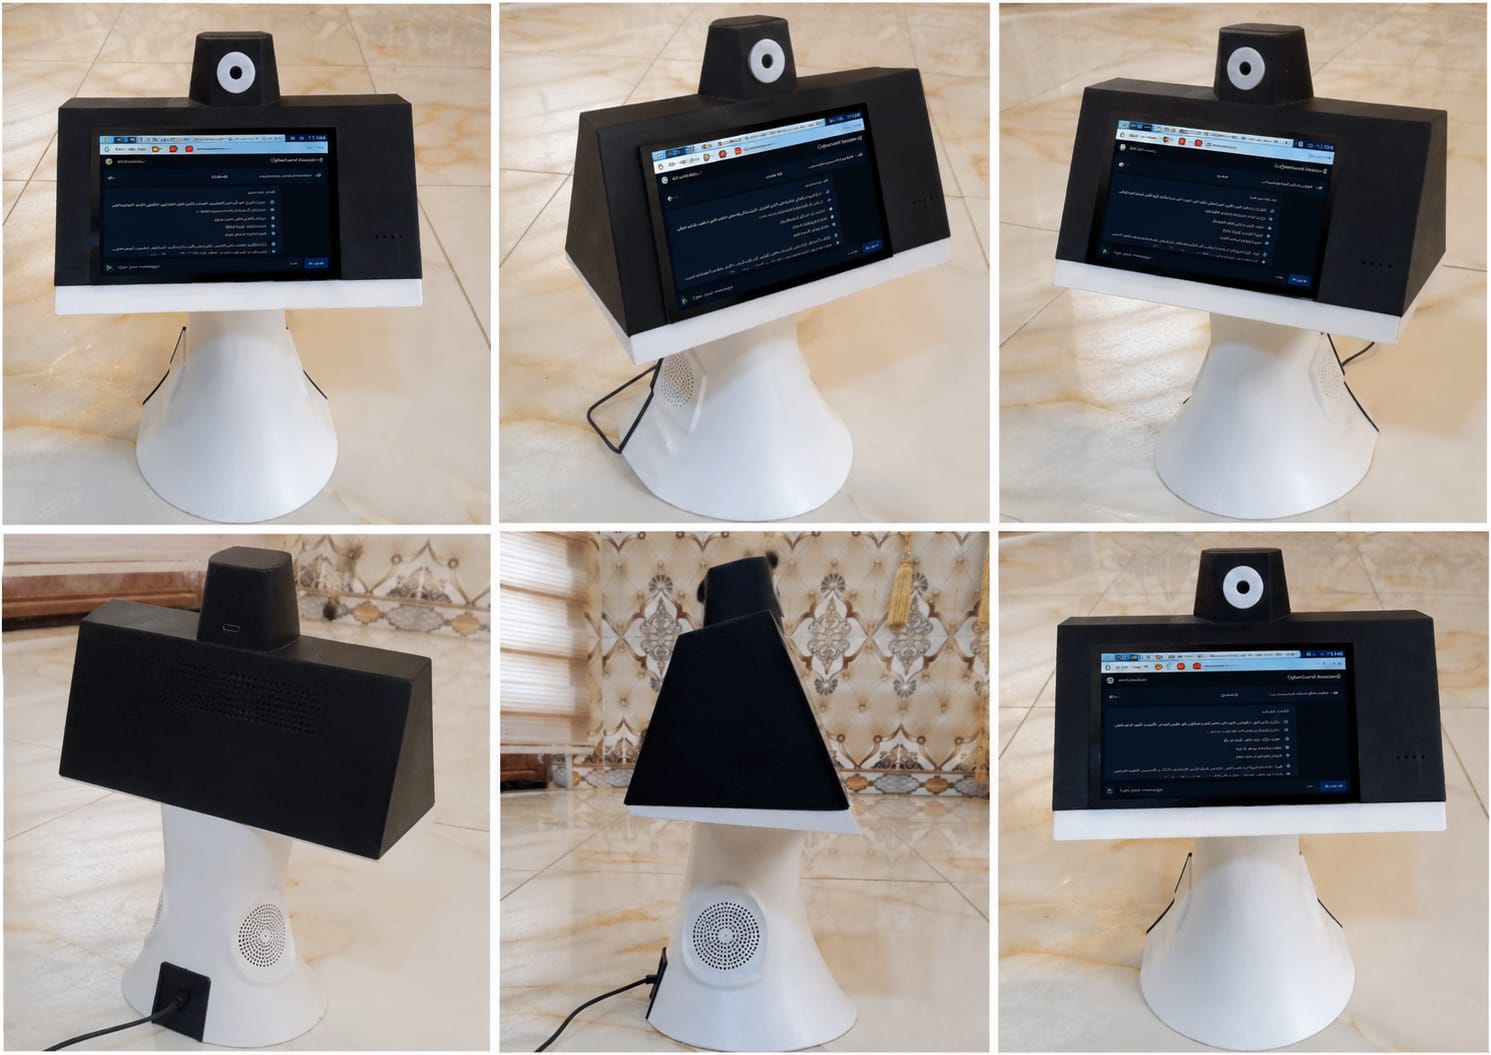
CyberGuard AI is an AI-powered kiosk robot placed at the department entrance. It provides instant, accurate answers to students' academic questions in both Arabic and English — by voice or text — 24/7, without requiring human intervention.
Method/Implementation:
The system uses Retrieval-Augmented Generation (RAG): course materials are ingested into a local ChromaDB vector database. When a student asks a question, the most relevant content is retrieved and passed to an LLM (Groq Cloud API with local fallback) to generate a grounded answer. The entire pipeline runs on a Raspberry Pi 5.
Key Components (HW/SW/AI):
Hardware: Raspberry Pi 5 (8GB), touchscreen, USB microphone, speaker, and Pi camera. Software: PySide6 UI, LangChain + ChromaDB (RAG), Groq API (Llama 3.3 70B online), LlamaCpp (Llama 1B offline), Face-ID authentication, and a full security layer against injection attacks.
Results/Impact:
The robot successfully answers cybersecurity course questions in real time, recognizes registered students via Face-ID, operates in kiosk mode preventing unauthorized system access, and continues functioning during internet outages using the local AI model.
Demo Summary:
The 60-second demo shows a student approaching the kiosk, logging in via Face-ID, asking a cybersecurity question in Arabic by voice, and receiving a spoken answer — then switching to English text input to demonstrate bilingual capability.
بيانات المشروع والفريق
الجامعةالجامعة التقنية الوسطى
المسار العلميمسار التربية والتعليم
الفريقفريق الأمن السيبراني
الترتيب النهائيالمركز الأول
التقييم النهائي86.87 / 100
المحافظةبغداد
الإشراف الأكاديمي
ح
حسن هادي خيون
المشرف الأكاديمي
أعضاء الفريق (3)
ع
علي نائل عبود
قائد الفريق · Master
ع
عبدالله شهيد
Other · Master
م
مصطفى تحسين علي
Programmer · Master
المركز الأولمسار خدمة المجتمع
NURAI2026-0901
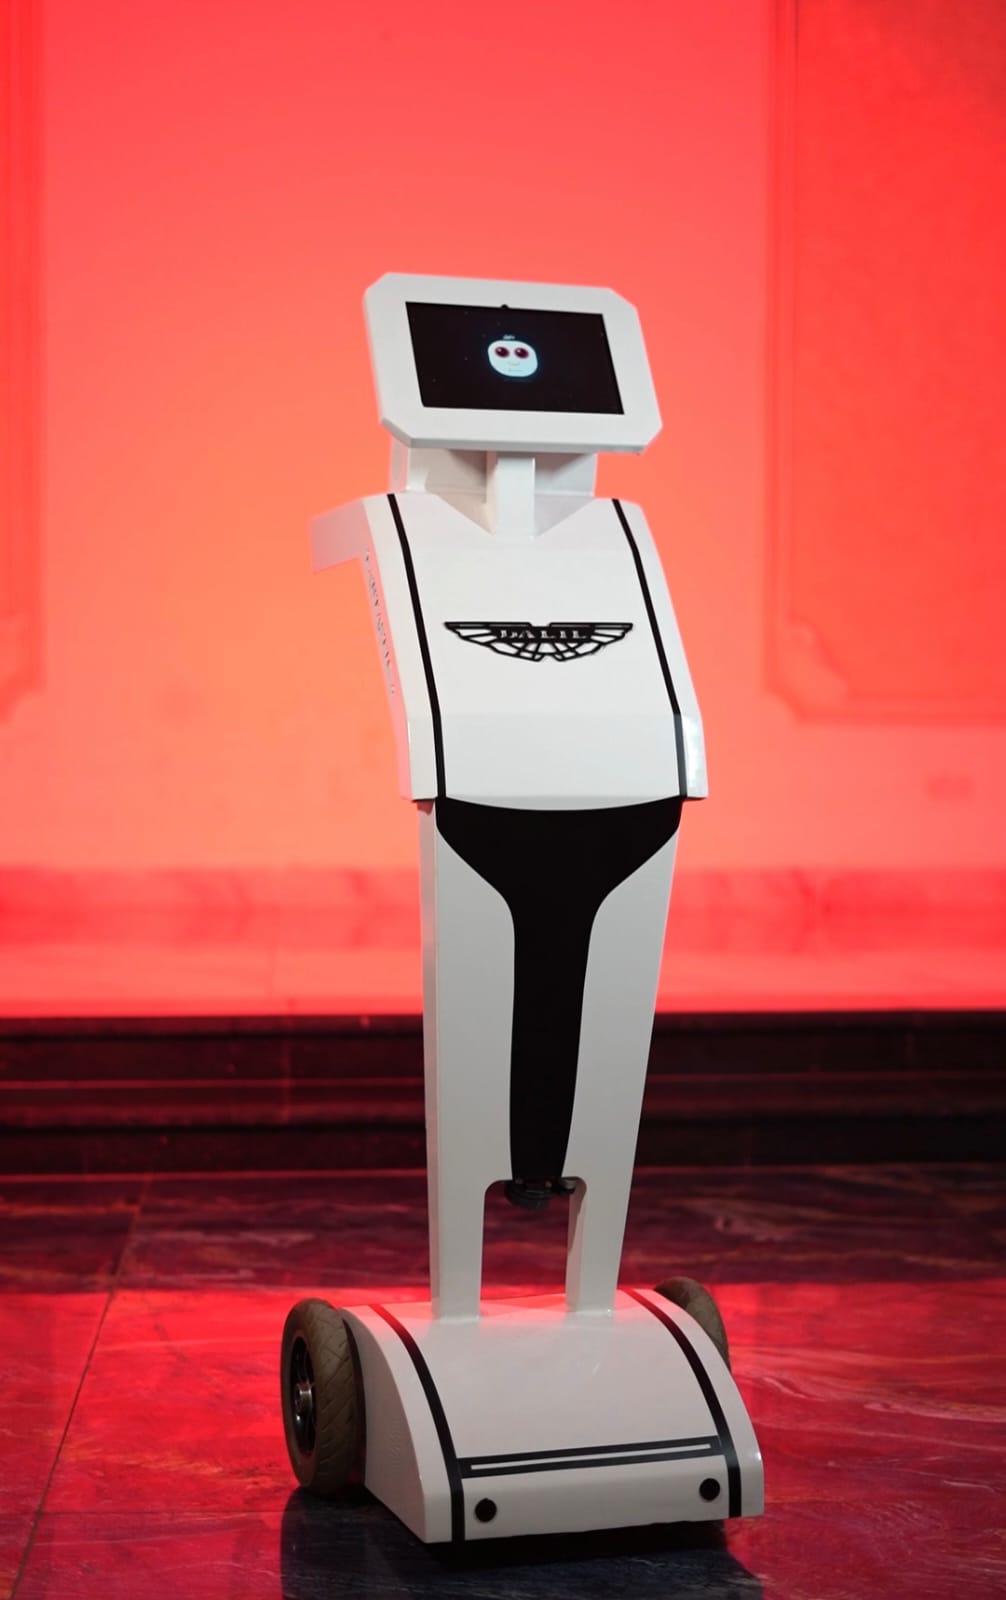
Digital Academic Link And Intelligent Logistics (DALIL)
ٌThis project addresses a significant problem in human-robot interaction and campus academic orientation. The proposed solution is based on "Dalil," a…
الجامعة: الجامعة التقنية الشمالية
الفريق: FANTASTIC 4
المشرف: سنابل محسن محمدعلي
NURAI2026-0901 · مسار خدمة المجتمع
Digital Academic Link And Intelligent Logistics (DALIL)
FANTASTIC 4 — الجامعة التقنية الشمالية
المركز الأول
نبذة عن المشروع
ٌThis project addresses a significant problem in human-robot interaction and campus academic orientation. The
proposed solution is based on "Dalil," an autonomous, open-source robotic assistant utilizing a hybrid
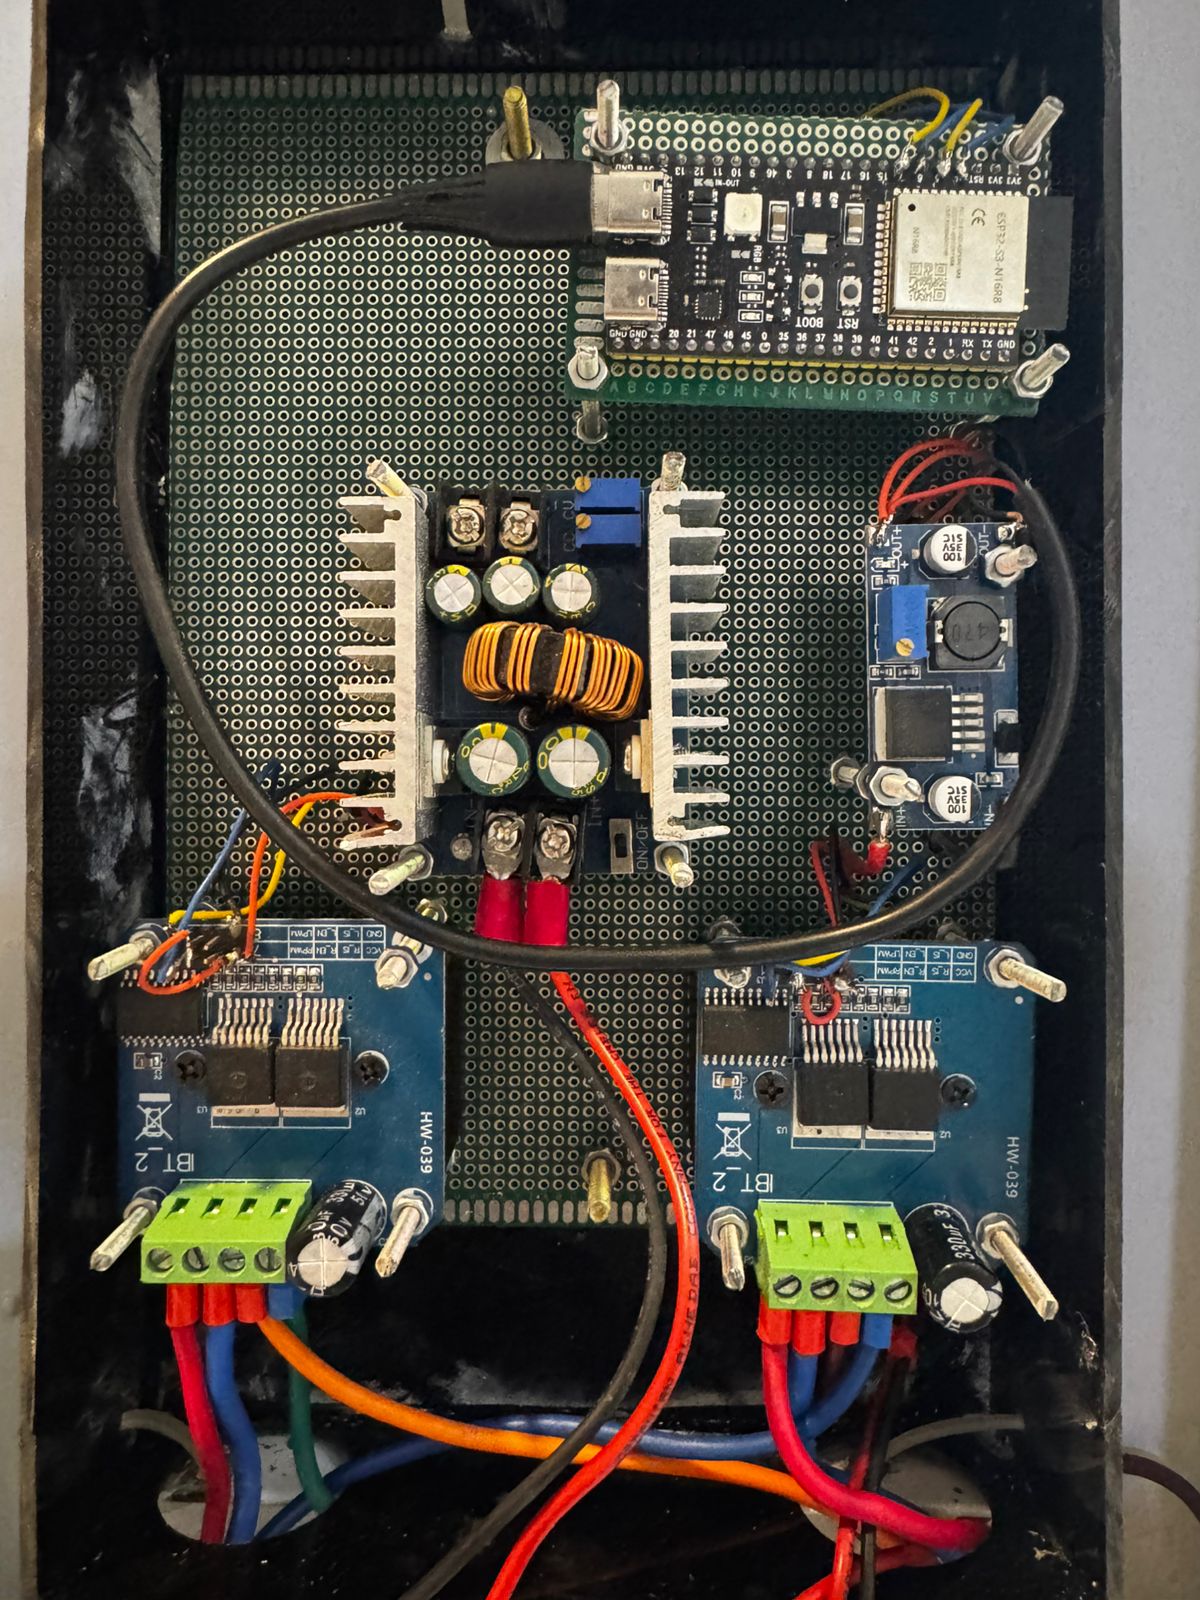
processing architecture that pairs a Raspberry Pi 5 with an ESP32 microcontroller, with the aim of deploying
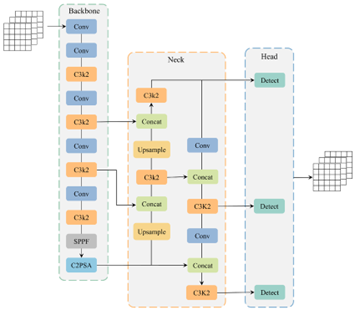
YOLOv8 facial recognition and natural language processing to guide university visitors and independently
resolve repetitive academic inquiries. The expected outcomes include achieving highly optimized response
latencies under 3 seconds, attaining a speech processing accuracy exceeding 90% in the localized Iraqi dialect
via secure API connections, and delivering a substantial reduction in the routine administrative burden imposed
on university personnel.
بيانات المشروع والفريق
الجامعةالجامعة التقنية الشمالية
المسار العلميمسار خدمة المجتمع
الفريقFANTASTIC 4
الترتيب النهائيالمركز الأول
التقييم النهائي91.33 / 100
المحافظةنينوى
الإشراف الأكاديمي
س
سنابل محسن محمدعلي
المشرف الأكاديمي
أعضاء الفريق (4)
س
سيف الدين مهند عبدالرزاق
قائد الفريق · Bachelor
ا
اقباس انور محمد
Other · Bachelor
ع
عبدالله ياسر سامي
Programmer · Bachelor
م
محمدسعيد فرات محمدسعيد
AI/Control · Bachelor
المركز الثاني مكررالمسار البيئي
NURAI2026-0737
FPGA-Based Intelligent Mobile Robotic Rover with Edge AI for Remote Monitoring and Early Fire Detection
The increasing demand for intelligent robotic systems capable of operating in hazardous, remote, and inaccessible environments has accelerated the int…
الجامعة: جامعة بابل
الفريق: Early Detection and Rescue Team
المشرف: الاستاذ الدكتور احمد عبد الكاظم حمد
NURAI2026-0737 · المسار البيئي
FPGA-Based Intelligent Mobile Robotic Rover with Edge AI for Remote Monitoring and Early Fire Detection
Early Detection and Rescue Team — جامعة بابل
المركز الثاني مكرر
نبذة عن المشروع
The increasing demand for intelligent robotic systems capable of operating in hazardous, remote, and inaccessible environments has accelerated the integration of robotics, embedded computing, and artificial intelligence technologies. This project presents the design and implementation of a remotely operated mobile robotic rover that enhances operator safety while providing continuous situational awareness. The proposed platform combines a Zynq FPGA-based processing system with a Raspberry Pi 5 for edge AI processing and advanced sensor integration. The rover incorporates wireless telemetry, GPS positioning, real-time video transmission, and a tracked crawler chassis to ensure reliable mobility over uneven terrain. System control and sensor interfacing are implemented using MicroPython, enabling efficient development and integration of embedded functionalities.
To enhance autonomous monitoring capabilities, a Convolutional Neural Network (CNN) model is developed and optimized using TinyML techniques for deployment on the Raspberry Pi 5. The integrated platform, which also includes a live video stream and a six-degree-of-freedom (6DOF) robotic arm, an MQ-2 gas sensor, and a firefighting hose, provides an effective solution for remote surveillance, environmental monitoring, industrial inspection, emergency response, and AI-driven research applications.
بيانات المشروع والفريق
الجامعةجامعة بابل
المسار العلميالمسار البيئي
الفريقEarly Detection and Rescue Team
الترتيب النهائيالمركز الثاني مكرر
التقييم النهائي86.80 / 100
المحافظةبابل
الإشراف الأكاديمي
ا
الاستاذ الدكتور احمد عبد الكاظم حمد
المشرف الأكاديمي
أ
أ.د. هلال عبد الحسين عبود
المشرف المشارك
أعضاء الفريق (4)
ح
حوراء موفق رحيم
قائد الفريق · Bachelor
ب
باقر صدام عبد الكريم
Programmer · Bachelor
م
مبين عصام كاظم
Electronics · Bachelor
م
مجتبى ابراهيم مالك
Other · Bachelor
المركز الثانيالمسار البيئي
NURAI2026-0572
Implementation of a Sustainable Smart Robotic System for Outdoor Plastic Waste Collection
Global plastic production exceeds 400 million tons annually with under 9% recycled, making manual waste collection inefficient and hazardous. NatureCl…
الجامعة: جامعة الموصل
الفريق: MSM
المشرف: د. زهراء طارق محمد
NURAI2026-0572 · المسار البيئي
Implementation of a Sustainable Smart Robotic System for Outdoor Plastic Waste Collection
MSM — جامعة الموصل
المركز الثاني
نبذة عن المشروع
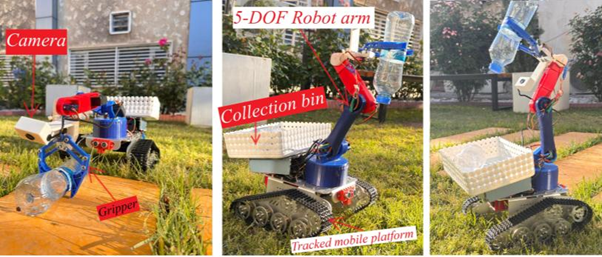
Global plastic production exceeds 400 million tons annually with under 9% recycled, making manual waste collection inefficient and hazardous. NatureCleanerBot is an autonomous mobile robot designed to detect and collect plastic bottles in semi-structured outdoor environments. Its mechatronic architecture integrates a tracked platform with a custom five-degree-of-freedom robotic arm and 3D-printed gripper. A Raspberry Pi 5 central controller fuses YOLO11n-OBB object detection with a dual ultrasonic sensor system facilitating both obstacle avoidance and precise depth measurement for “Scan-and-Verify” navigation and inverse-kinematics retrieval. Evaluations showed 85.1% precision, 89.5% recall, 91.3% mAP50, and 9.0 ms inference speed. Field testing validated stable operation, though detecting vertically oriented bottles remains a limitation. Results prove the feasibility of combining edge AI and robotics for sustainable waste management.
بيانات المشروع والفريق
الجامعةجامعة الموصل
المسار العلميالمسار البيئي
الفريقMSM
الترتيب النهائيالمركز الثاني
التقييم النهائي86.80 / 100
المحافظةنينوى
الإشراف الأكاديمي
د
د. زهراء طارق محمد
المشرف الأكاديمي
أعضاء الفريق (3)
م
مكرم ليث رشيد
قائد الفريق · Bachelor
س
سالم سنان سالم
Electronics · Bachelor
م
مؤمن وليد خالد فخري
AI/Control · Bachelor
المركز الثانيالمسار الزراعي
NURAI2026-0199
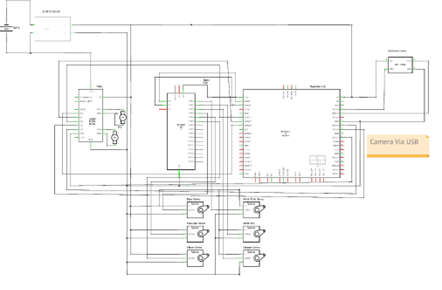
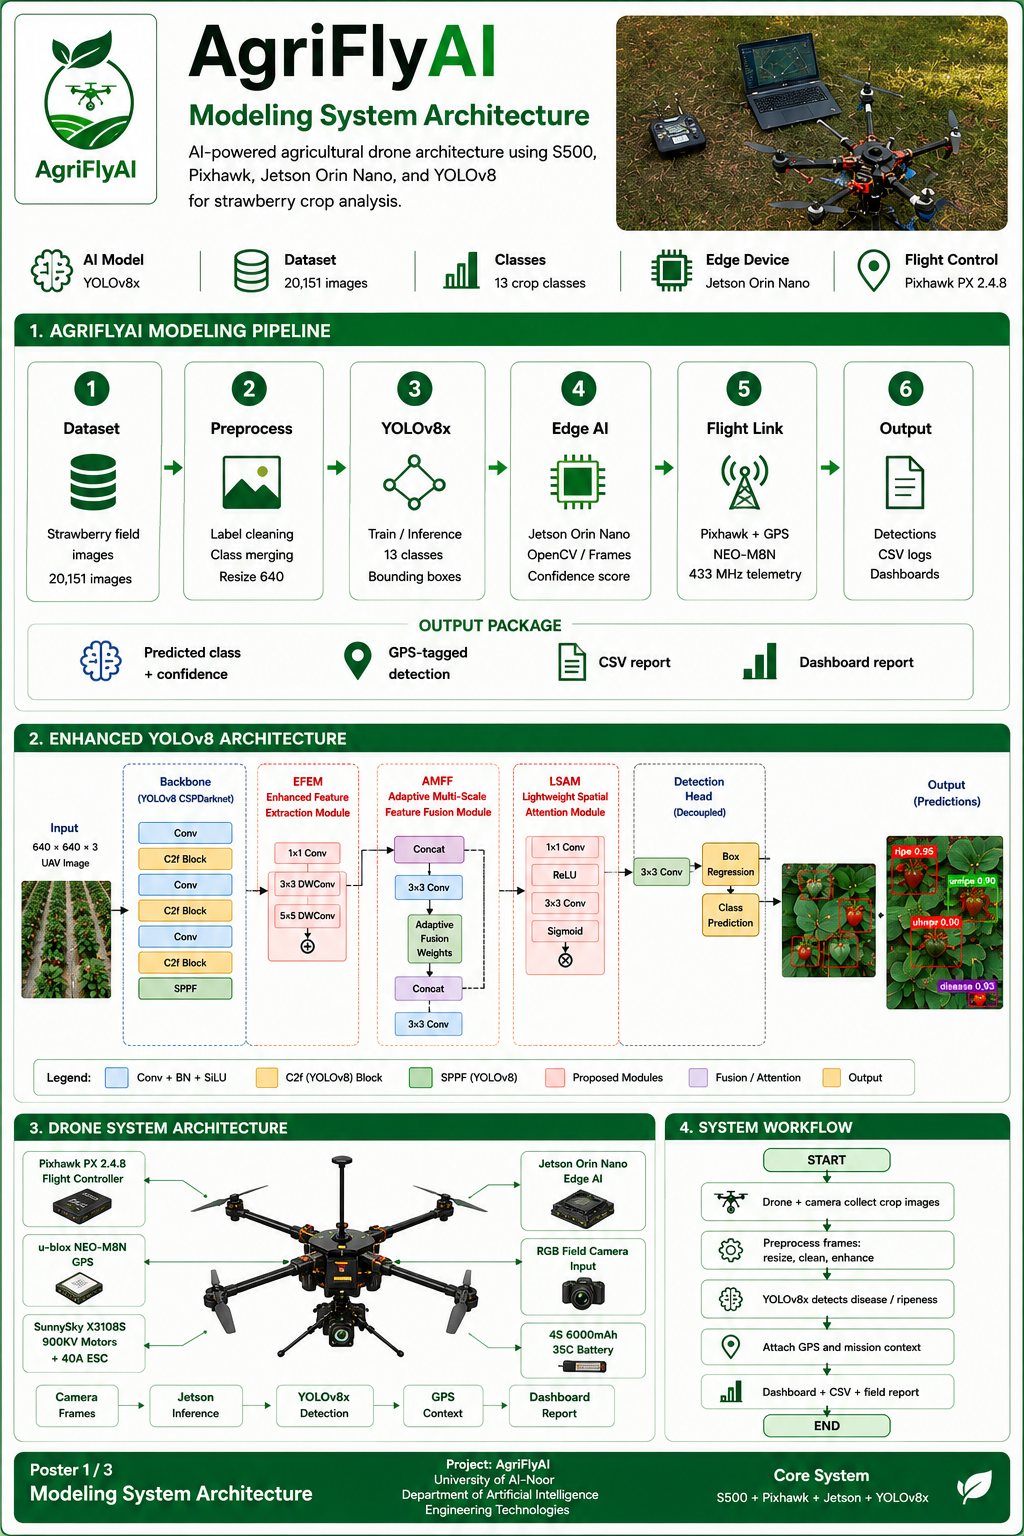
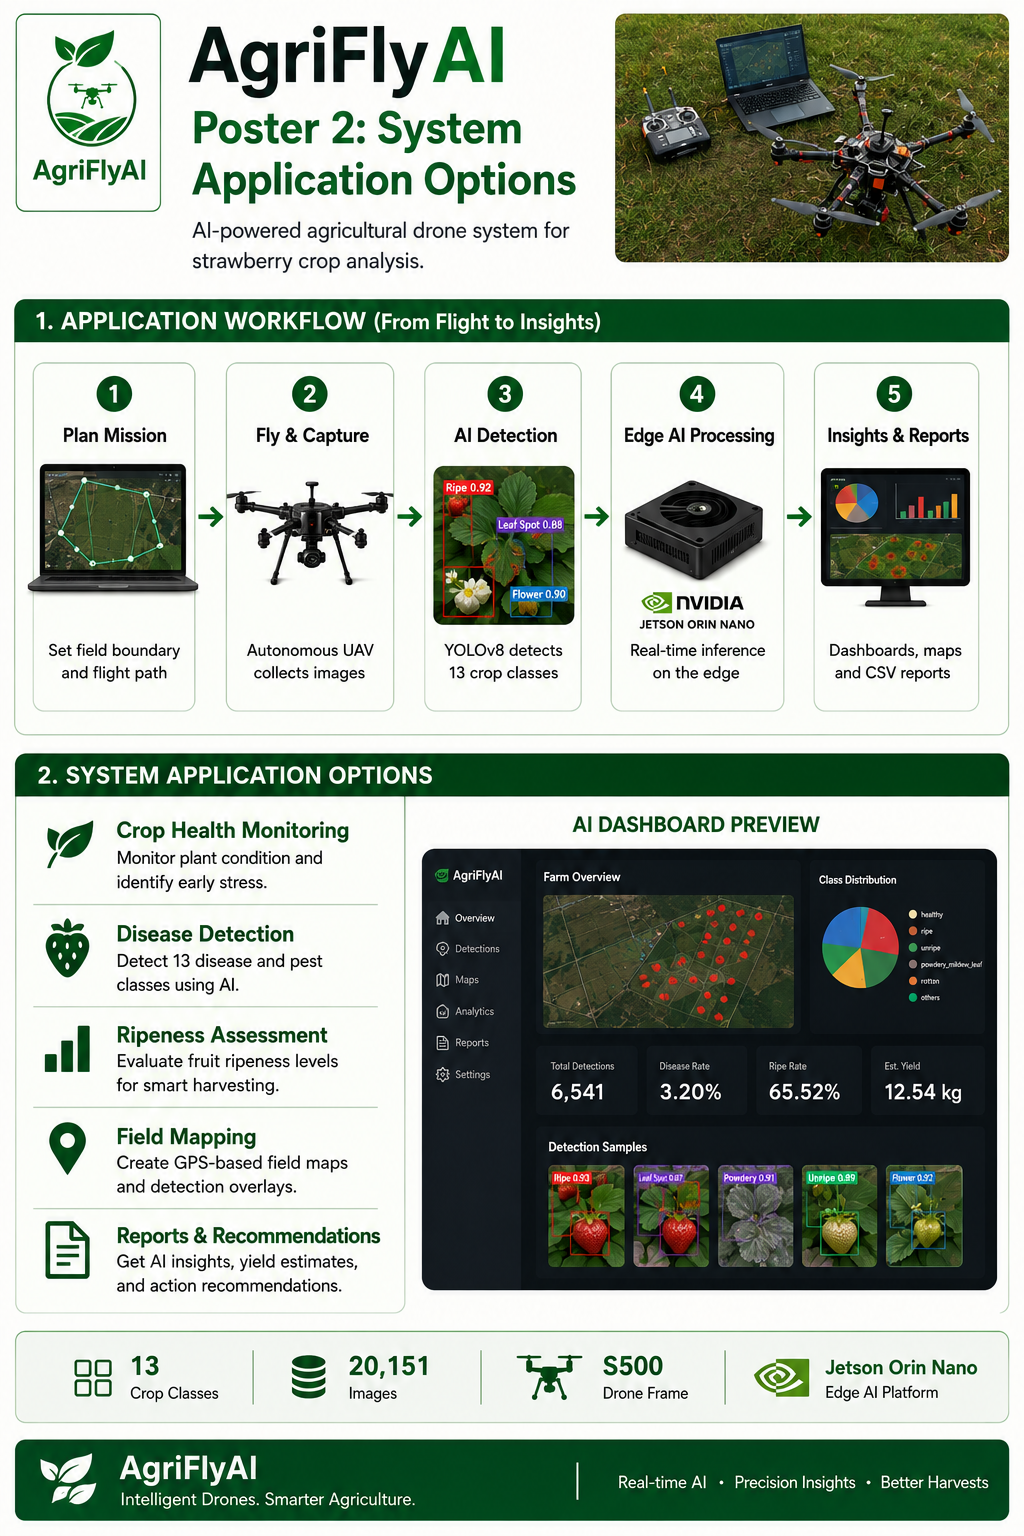
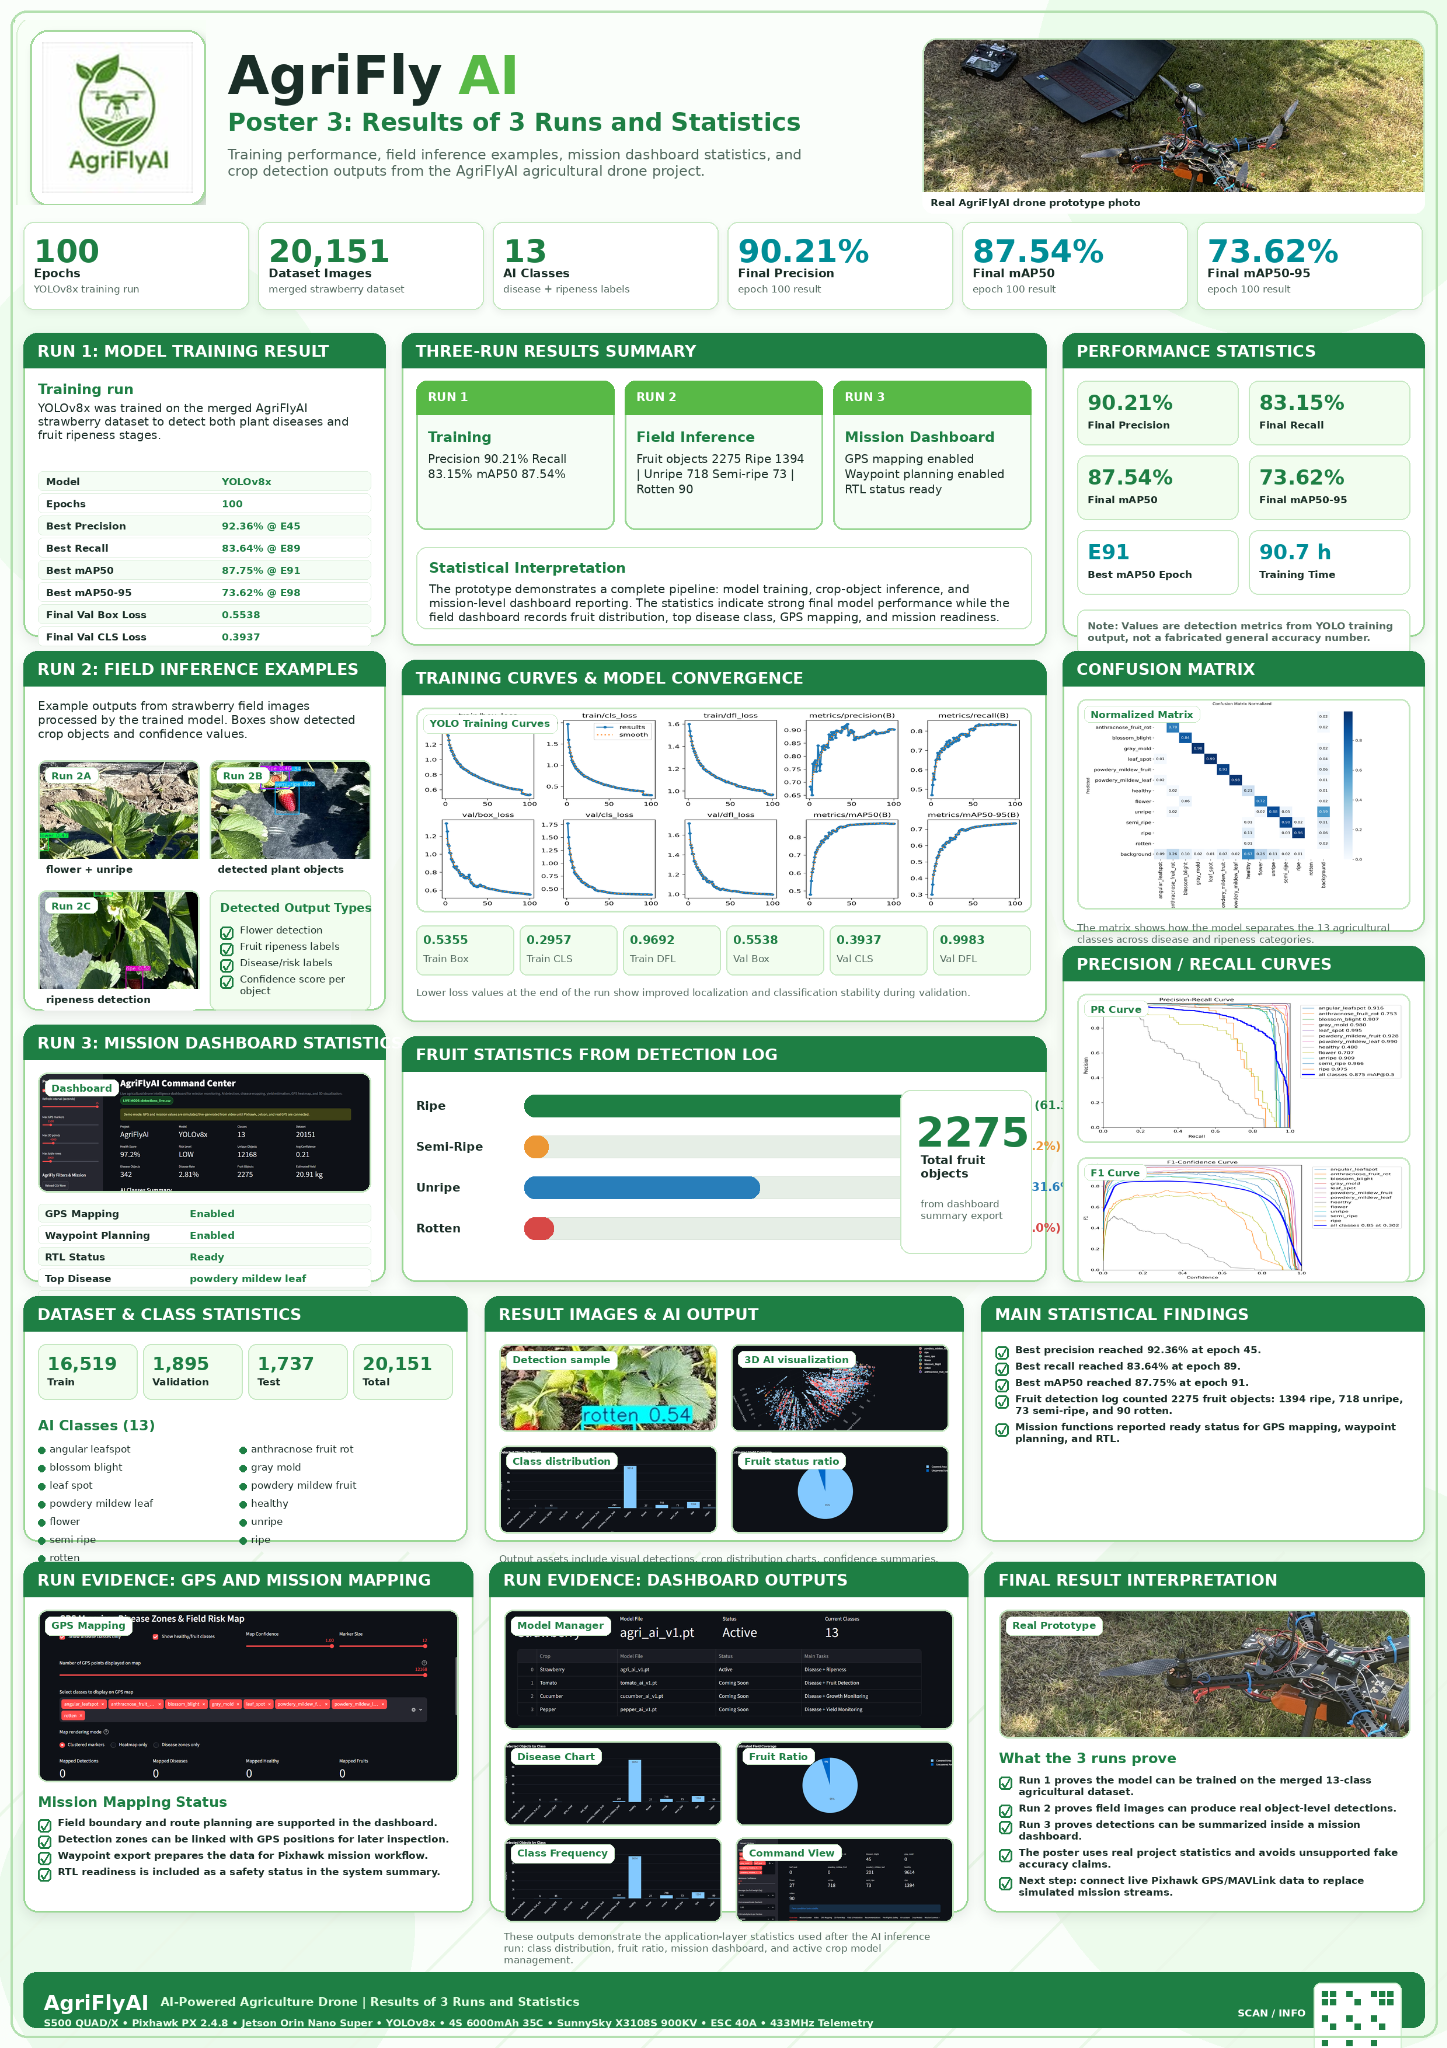
AgriFlyAI: An Autonomous UAV System Powered by an Enhanced YOLOv8-Based Edge AI Model for Real-Time Strawberry Detection and Crop Monitoring
Application of autonomous Unmanned Aerial Vehicle (UAV) systems and the use of artificial intelligence in precision agriculture are increasing and are…
الجامعة: جامعة النور
الفريق: فريق الذكاء الطائر
المشرف: د. سلامة ادريس مصطفى نجم
NURAI2026-0199 · المسار الزراعي
AgriFlyAI: An Autonomous UAV System Powered by an Enhanced YOLOv8-Based Edge AI Model for Real-Time Strawberry Detection and Crop Monitoring
فريق الذكاء الطائر — جامعة النور
المركز الثاني
نبذة عن المشروع
Application of autonomous Unmanned Aerial Vehicle (UAV) systems and the use of artificial intelligence in precision agriculture are increasing and are important tools for better crop monitoring, reduction of human labor, and enhancement of agricultural productivity. Although the above-mentioned challenges exist, real-time strawberry detection is still difficult under different illumination or unseen fruits and complicated backgrounds. This paper presents an edge artificial intelligence (AI) model improved by using the YOLOv8 model to detect strawberries and monitor them in real time, and introduces an autonomous unmanned aerial vehicle (UAV) system for strawberry monitoring. The model to be used is optimized for the YOLOv8 model, with the addition of edge computing on an NVIDIA Jetson Orin Nano, autonomous flight control using a Pixhawk controller, and an intelligent dashboard for flight mission planning and crop analysis. To meet the requirement of detecting strawberry ripeness stages, plant health conditions, and common diseases under complex field environments, it is proposed that feature extraction methods be strengthened to generate better feature representations, multi-scale feature fusion methods be adopted to fuse the information from different scales, and lightweight attention mechanisms be introduced to achieve effective detection. The model was trained on more than 20,000 annotated images from 12 classes and tested based on the Precision, Recall, and mean Average Precision (mAP) metrics. Results from this experiment showed 90% Precision, 83% Recall, 88% mAP@50, and 74% mAP@50-95, with real-time inference at around 9 fps on Jetson Orin Nano, with no dependency on the cloud. The full AgriFlyAI suite also produces crop health analysis, disease hotspot maps, and crop yield predictions to aid data-informed farming decisions. The outcomes prove that the suggested model is an efficient, scalable, and practice-oriented solution to the problem of intelligent UAV-based precision agriculture.
بيانات المشروع والفريق
الجامعةجامعة النور
المسار العلميالمسار الزراعي
الفريقفريق الذكاء الطائر
الترتيب النهائيالمركز الثاني
التقييم النهائي87.20 / 100
المحافظةنينوى
الإشراف الأكاديمي
د
د. سلامة ادريس مصطفى نجم
المشرف الأكاديمي
أعضاء الفريق (4)
ب
بلال محمد عبدالقادر سليمان
Programmer · Bachelor
ج
جنة زيد محمد-نجيب
Electronics · Bachelor
ذ
ذنون رائد يونس
Other · Bachelor
ر
راستي عبدالمناف عبدالباقي علي
AI/Control · Bachelor
المركز الثانيالمسار الصناعي
NURAI2026-0768
الكشف الآلي عن الأعطال وتصنيفها وتحديد موقعها في الحقول الشمسية باستخدام التعلم العميق والذكاء الاصطناعي
تُعدّ الطاقة الشمسية الكهروضوئية من أسرع تقنيات الطاقة المتجددة نموًا على مستوى العالم، إلا أن كفاءة وموثوقية هذه الأنظمة تتأثر بشكل كبير بالأعطال الم…
الجامعة: جامعة كربلاء
الفريق: القدرة والتحكم
المشرف: أ. د. علي عبد الرزاق عباس الطاهر
NURAI2026-0768 · المسار الصناعي
الكشف الآلي عن الأعطال وتصنيفها وتحديد موقعها في الحقول الشمسية باستخدام التعلم العميق والذكاء الاصطناعي
القدرة والتحكم — جامعة كربلاء
المركز الثاني
نبذة عن المشروع
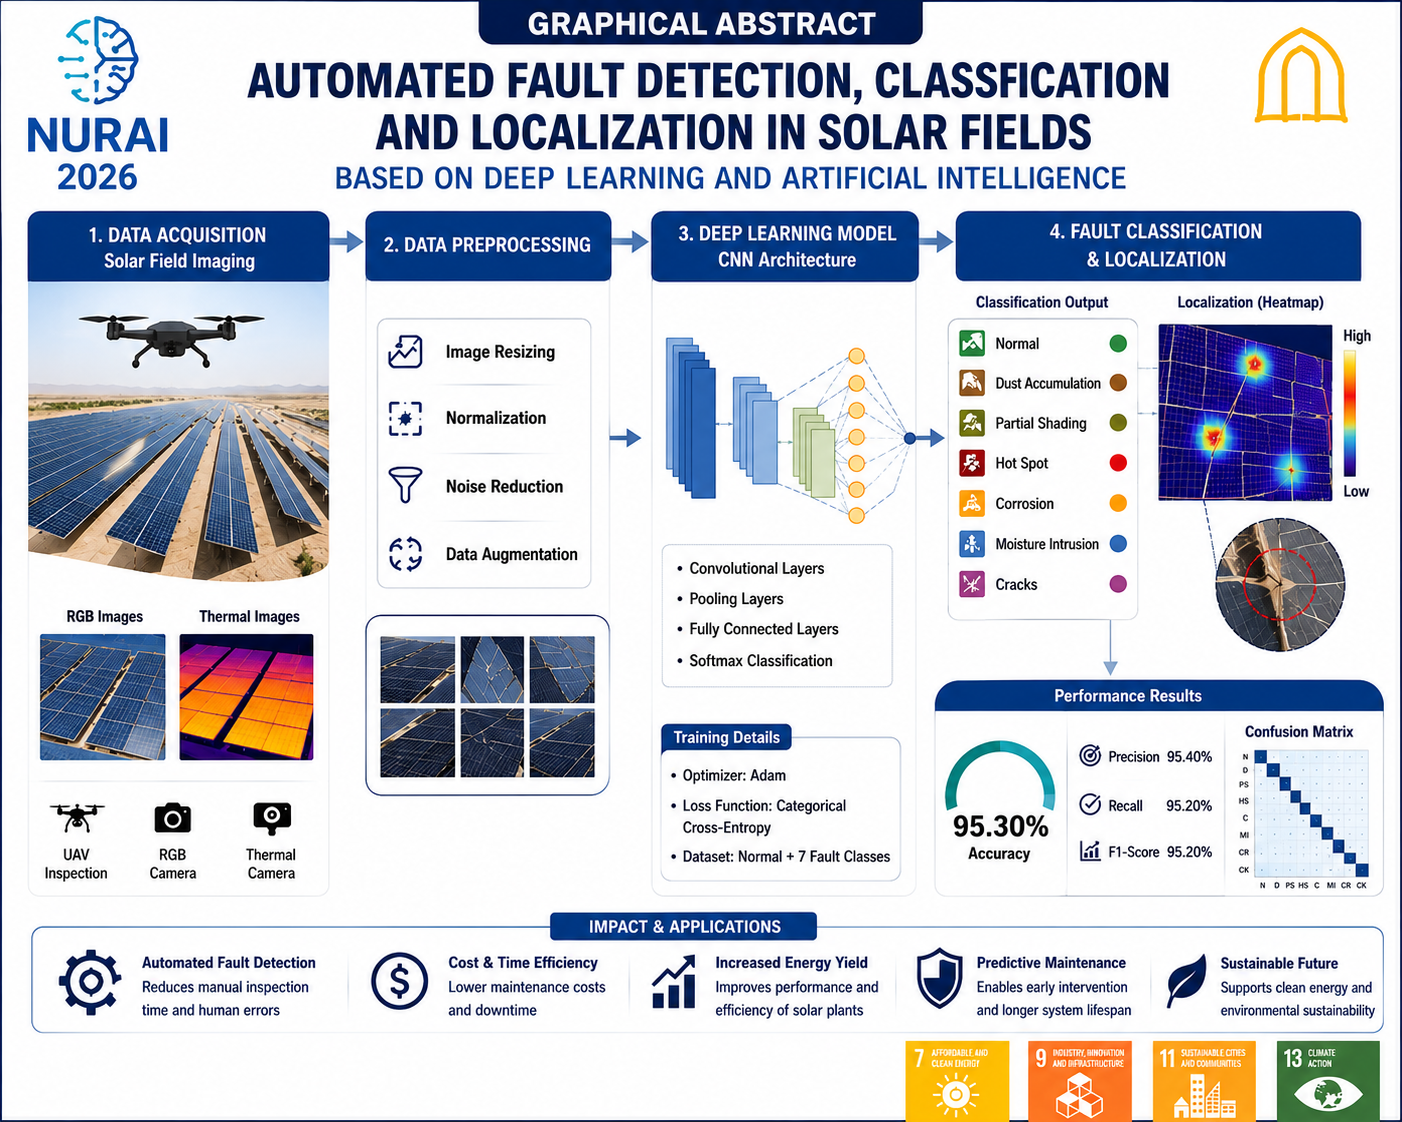
تُعدّ الطاقة الشمسية الكهروضوئية من أسرع تقنيات الطاقة المتجددة نموًا على مستوى العالم، إلا أن كفاءة وموثوقية هذه الأنظمة تتأثر بشكل كبير بالأعطال المختلفة، مثل تراكم الغبار، والتظليل الجزئي، والبقع الساخنة، والتشققات، والتآكل، وتسرب الرطوبة، وأعطال الثنائيات، والتي تؤدي إلى انخفاض إنتاج الطاقة وارتفاع تكاليف الصيانة. يعالج هذا المشروع تحدي الكشف الآلي عن الأعطال وتصنيفها وتحديد مواقعها في حقول الطاقة الشمسية الكهروضوئية من خلال تطوير نظام مراقبة ذكي يعتمد على الذكاء الاصطناعي والتعلم. يعتمد الحل المقترح على استخدام الشبكات العصبية الالتفافية) لتحليل الصور المرئية والحرارية الملتقطة للألواح الشمسية، مما يتيح التعرف التلقائي على أنواع متعددة من الأعطال وتصنيفها وتحديد مواقعها بدقة عالية. ويهدف المشروع إلى تحسين موثوقية وكفاءة تشغيل محطات الطاقة الشمسية، وتطوير عمليات الصيانة من خلال تقليل الاعتماد على الفحص اليدوي، وخفض زمن اكتشاف الأعطال، وتقليل التكاليف التشغيلية. وقد أظهرت النتائج التجريبية أن النموذج المقترح حقق دقة تصنيف بلغت 95.3%، مما يؤكد كفاءته في التشخيص الذكي للأعطال. كما يوفر النظام إطارًا عمليًا وقابلًا للتوسع لدعم المراقبة الآنية، والصيانة التنبؤية، مع إمكانية التكامل مستقبلًا مع الطائرات المسيّرة وتقنيات إنترنت الأشياء. ومن خلال تعزيز قدرات تشخيص الأعطال وتحسين استراتيجيات الصيانة، يسهم المشروع في تطوير أنظمة إدارة ذكية للطاقة المتجددة ودعم التشغيل المستدام لمحطات الطاقة الشمسية الكهروضوئية واسعة النطاق
بيانات المشروع والفريق
الجامعةجامعة كربلاء
المسار العلميالمسار الصناعي
الفريقالقدرة والتحكم
الترتيب النهائيالمركز الثاني
التقييم النهائي88.00 / 100
المحافظةكربلاء
الإشراف الأكاديمي
أ
أ. د. علي عبد الرزاق عباس الطاهر
المشرف الأكاديمي
م
م.د أروى حميد محمد تقي
المشرف المشارك
أعضاء الفريق (3)
م
منتظر حازم محمد
قائد الفريق · Bachelor
ع
علي معز حسن
Electronics · Bachelor
م
مصطفى عامر علي
Programmer · Bachelor
المركز الثانيالمسار الطبي
NURAI2026-0029
Amal: An AI-Based Assistive Communication System Using Eye Blink Detection and Sign Language Recognition
Patients with severe speech and motor impairments often face difficulty expressing basic needs, especially when they cannot use speech, hands, or conv…
الجامعة: جامعة بابل
الفريق: IT Babylon Team
المشرف: د.امير الحق الشمري
NURAI2026-0029 · المسار الطبي
Amal: An AI-Based Assistive Communication System Using Eye Blink Detection and Sign Language Recognition
IT Babylon Team — جامعة بابل
المركز الثاني
نبذة عن المشروع
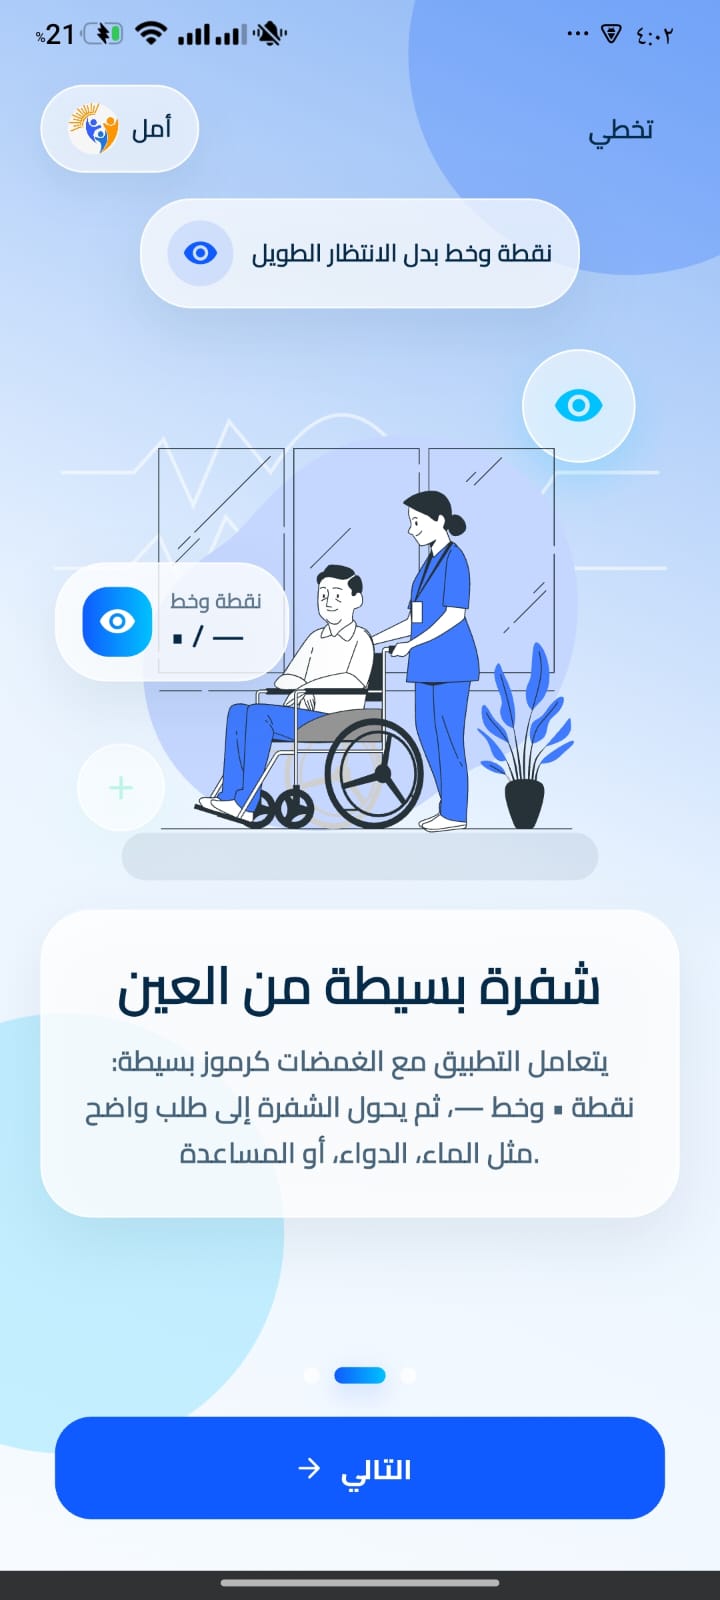
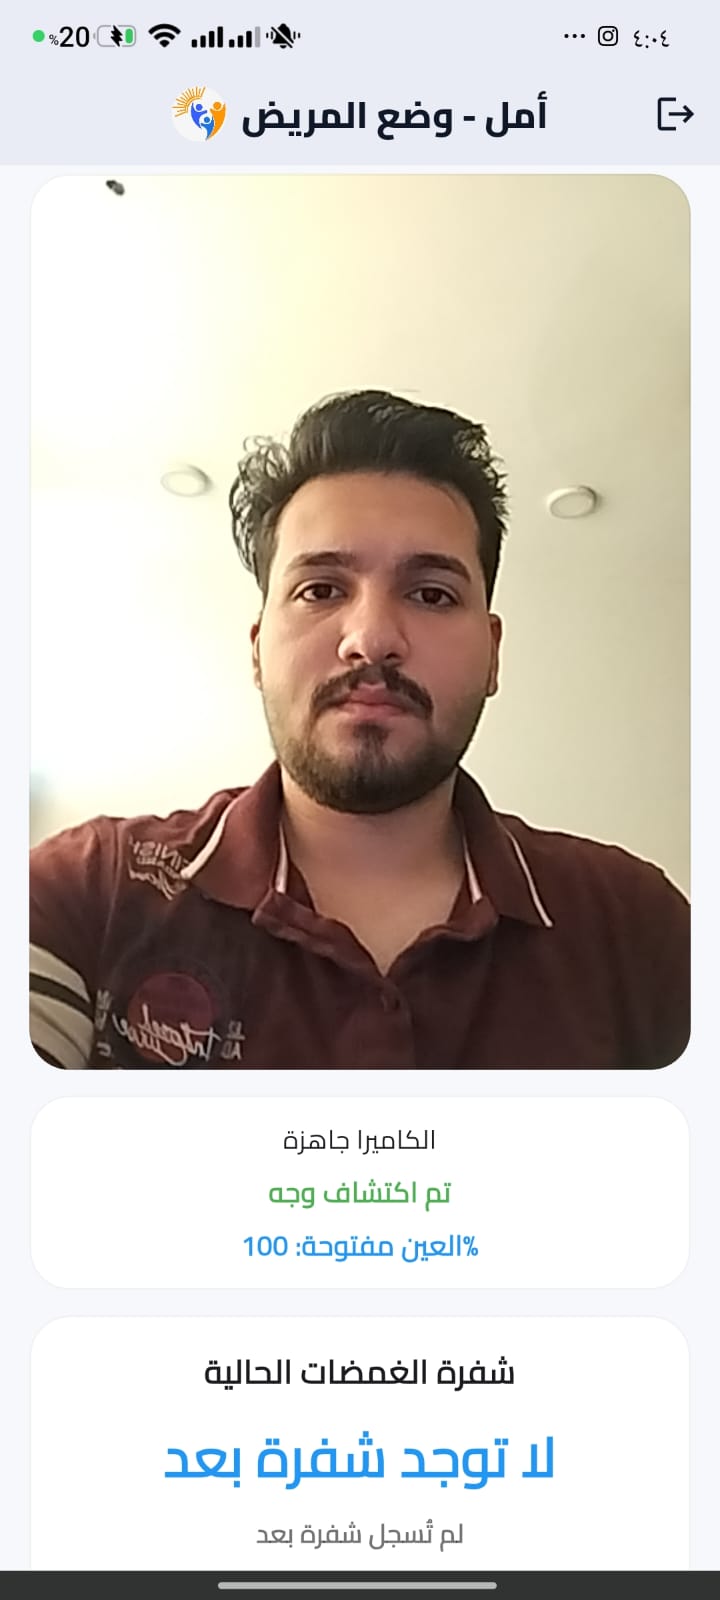
Patients with severe speech and motor impairments often face difficulty expressing basic needs, especially when they cannot use speech, hands, or conventional input devices. This project presents Amal, an AI-based assistive communication system that enables patients to communicate with caregivers using eye blink detection and sign language recognition. The system uses the mobile camera to detect short and long eye blinks and convert them into dot/dash patterns. These patterns are mapped to caregiver-defined commands, allowing an unlimited set of personalized requests according to the patient’s daily needs.
بيانات المشروع والفريق
الجامعةجامعة بابل
المسار العلميالمسار الطبي
الفريقIT Babylon Team
الترتيب النهائيالمركز الثاني
التقييم النهائي89.60 / 100
المحافظةبابل
الإشراف الأكاديمي
د
د.امير الحق الشمري
المشرف الأكاديمي
أعضاء الفريق (5)
ع
عباس فاضل عبدالحسين جميل
قائد الفريق · Bachelor
م
محمد قاسم محمد
Programmer · Bachelor
ح
حسين احمد كاظم
AI/Control · Bachelor
ط
طيبه طالب جاسم
Electronics · Bachelor
م
محمود علي ساهي
Mechanical · Bachelor
المركز الثانيمسار التربية والتعليم
NURAI2026-0177
Ulfana: A Multi-Tier Arabic Educational Platform with an Offline Retrieval-Augmented Speaking Library and Iraqi-Dialect Support
Across Iraq, learners from primary school to university face fragmented study tools, intermittent connectivity, weak support for colloquial Iraqi Arab…
الجامعة: جامعة الصفوة
الفريق: فريق المستقبل الذكي
المشرف: م. فارس كريم حليوت
NURAI2026-0177 · مسار التربية والتعليم
Ulfana: A Multi-Tier Arabic Educational Platform with an Offline Retrieval-Augmented Speaking Library and Iraqi-Dialect Support
فريق المستقبل الذكي — جامعة الصفوة
المركز الثاني
نبذة عن المشروع
Across Iraq, learners from primary school to university face fragmented study tools,
intermittent connectivity, weak support for colloquial Iraqi Arabic, and weak privacy
safeguards for a mostly-minor user base. This paper presents Ulfana, a privacy-first
educational platform that serves all tiers (school, institute, university, vocational)
from a single Arabic right-to-left application, unifying capabilities usually scattered
across separate tools. It contributes a multi-tier adaptive architecture; a study-feed
ranker governed by an education-specific 'golden rule' with per-post transparency;
action-linked gamification with an anonymised leaderboard; a cross-tier Academic
Passport and a Smart Transition Bridge that schedules prerequisite review to peak
on the enrolment date; and the Speaking Library, an offline Arabic Retrieval
Augmented Generation (RAG) assistant that answers each student from their own
books by fusing BM25 and FAISS HNSW retrieval with cross-encoder re-ranking and
a per-user BM25 sub-index, local Qwen2.5 generation, Iraqi-dialect post-processing,
and offline neural speech. The Speaking Library runs fully offline on commodity
CPUs; the implementation was verified through 60+ application and 161 backend
tests.
بيانات المشروع والفريق
الجامعةجامعة الصفوة
المسار العلميمسار التربية والتعليم
الفريقفريق المستقبل الذكي
الترتيب النهائيالمركز الثاني
التقييم النهائي82.87 / 100
المحافظةكربلاء
الإشراف الأكاديمي
م
م. فارس كريم حليوت
المشرف الأكاديمي
أعضاء الفريق (4)
ا
ايمن كاظم يوسف
قائد الفريق · Bachelor
ح
حسن وضاح سالم
Programmer · Bachelor
ح
حيدر فيصل حسن موسى
Other · Bachelor
ي
يوسف سيف عبد الجبار
Programmer · Bachelor
المركز الثانيمسار خدمة المجتمع
NURAI2026-0843
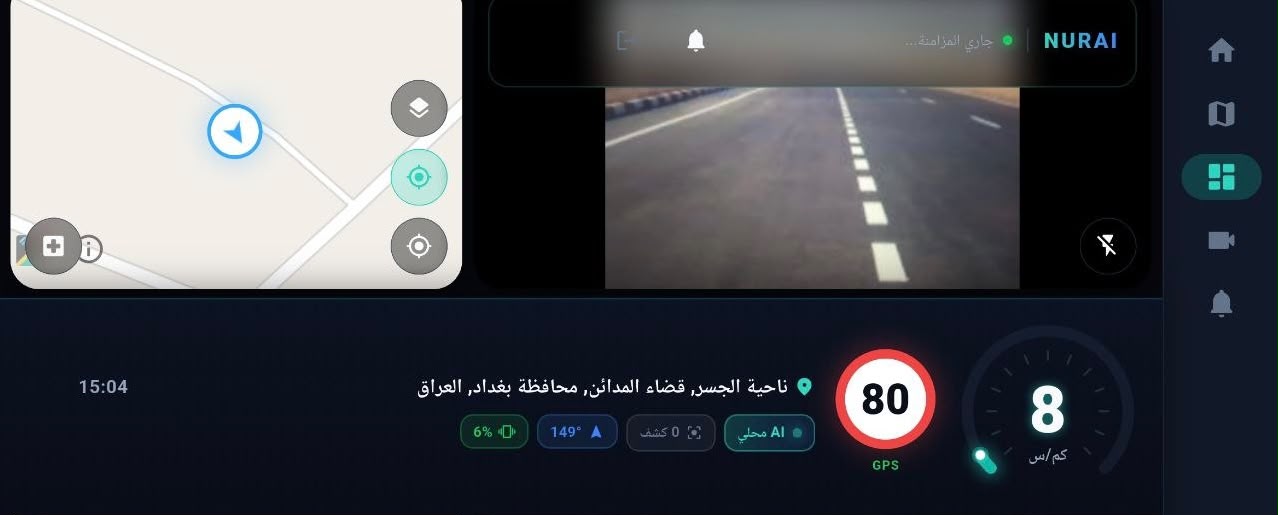
RASID: An Integrated MLOps and GIS Platform for Real-Time Road Hazard Detection and Fleet Intelligence
More than 3,000 preventable deaths occur on Iraqi roads each year, partly due to the lack of integration between road hazard detection, geospatial map…
الجامعة: جامعة تكنولوجيا المعلومات والاتصالات
الفريق: Teana team
المشرف: د.مهند عبد الاله عباس
NURAI2026-0843 · مسار خدمة المجتمع
RASID: An Integrated MLOps and GIS Platform for Real-Time Road Hazard Detection and Fleet Intelligence
Teana team — جامعة تكنولوجيا المعلومات والاتصالات
المركز الثاني
نبذة عن المشروع
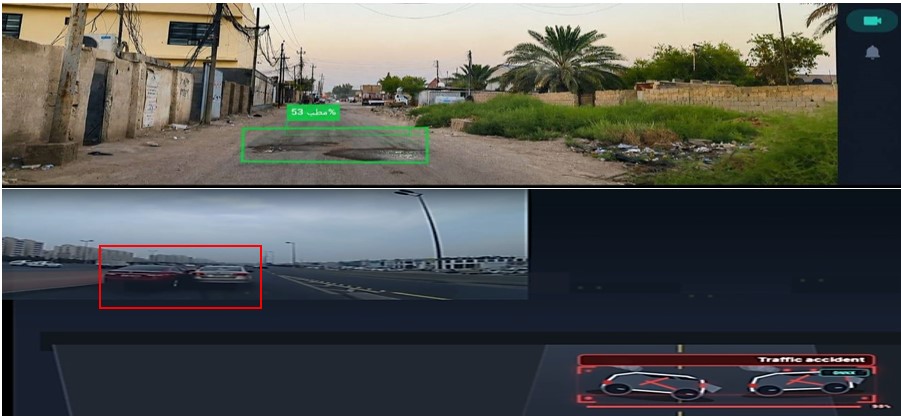
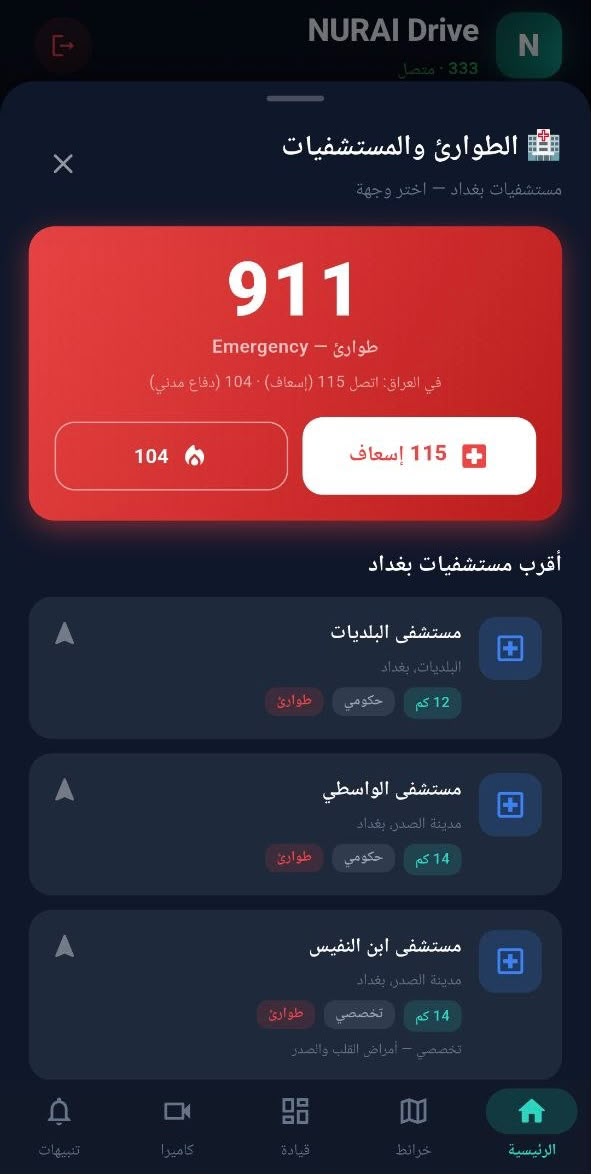
More than 3,000 preventable deaths occur on Iraqi roads each year, partly due to the lack of integration between road hazard detection, geospatial mapping, and emergency response systems. Existing CCTV networks, citizen-reporting applications, and standalone machine-learning solutions operate independently, limiting their effectiveness in supporting timely decision-making. This paper presents RASID (Road AI Surveillance Intelligence Detection), an integrated MLOps and GIS platform for real-time road hazard monitoring and fleet intelligence. The proposed system streams image frames and GPS coordinates from fleet vehicles to a centralized server, where a YOLO11s detection model performs hazard detection and stores validated events in a PostGIS database as geotagged records. Detected events are distributed through a WebSocket-based GIS platform, enabling real-time notifications for drivers, maintenance teams, and emergency responders. In addition, an active-learning pipeline supports continuous model improvement through automated retraining and deployment. A pilot deployment involving ten vehicles achieved 78.0% [email protected], 74.7% precision, and 81.1% recall, while sustaining up to 120 frames per second of server throughput and maintaining sub-second event dissemination latency. The results demonstrate the feasibility of combining computer vision, geospatial intelligence, and MLOps into a unified platform for intelligent road safety management.
بيانات المشروع والفريق
الجامعةجامعة تكنولوجيا المعلومات والاتصالات
المسار العلميمسار خدمة المجتمع
الفريقTeana team
الترتيب النهائيالمركز الثاني
التقييم النهائي91.00 / 100
المحافظةبغداد
الإشراف الأكاديمي
د
د.مهند عبد الاله عباس
المشرف الأكاديمي
م
م.م. طيف طارق عبد الصاحب
المشرف المشارك
أعضاء الفريق (3)
م
مهدي احمد جبوري جعفر
قائد الفريق · Bachelor
ب
بشير محمد عطيوي
Programmer · Bachelor
س
سلمان داود سلمان
Electronics · Bachelor
المركز الثالثالمسار البيئي
NURAI2026-0602
Autonomous Outdoor Misting Climate Control System for Enhancing Urban Thermal Comfort Using Fuzzy IoT-Based Technologies
The traditional outdoor misting systems are known to have high ongoing energy use and significant water loss due to inefficient spraying. Moreover, tr…
الجامعة: الجامعة التكنولوجية
الفريق: soul tech
المشرف: عماد محمد عبود
NURAI2026-0602 · المسار البيئي
Autonomous Outdoor Misting Climate Control System for Enhancing Urban Thermal Comfort Using Fuzzy IoT-Based Technologies
soul tech — الجامعة التكنولوجية
المركز الثالث
نبذة عن المشروع
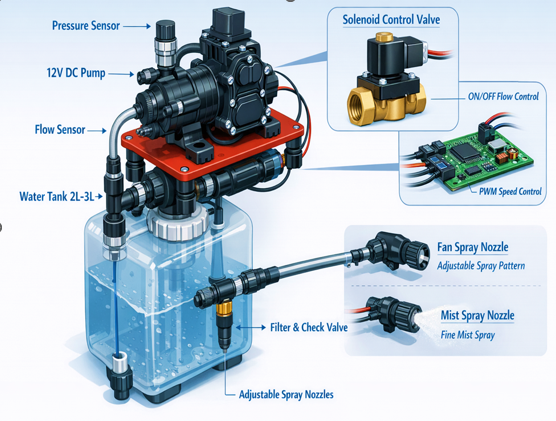
The traditional outdoor misting systems are known to have high ongoing energy use and significant water loss due to inefficient spraying. Moreover, traditional methods often create nuisance to pedestrians by unwanted wetting. In an attempt to overcome these inefficiencies, this paper presents SMART ECO-MISTER Breeze, a solar based urban cooling system with the support of Edge AI. The architecture proposed consists of a Raspberry Pi 4, AMG8833 Thermal Camera and BME280 sensor to enable ambient monitoring and human heat detection in real-time. The system uses AI algorithm to determine the amount of mist needed for each person and uses a 50W monocrystalline solar panel, along with a 12V LiFePO4 battery and MPPT controller to operate off the grid. The 60cm 3D printed physical prototype includes a 12V high pressure diaphragm pump, 0.1mm brass nozzles, solenoid valves and closed loop water re-cycling system. Further, the system includes a LoRa MESH wireless network, which allows to coordinate multiple cooling poles in a decentralised way across the city. Experimental validation shows that the system can provide targeted and personalized cooling without wetting pedestrians, if they do not want to be wet. In so doing, this smart architecture requires much less energy and water than traditional methods, providing a highly sustainable paradigm for urban climate adaptation.
بيانات المشروع والفريق
الجامعةالجامعة التكنولوجية
المسار العلميالمسار البيئي
الفريقsoul tech
الترتيب النهائيالمركز الثالث
التقييم النهائي85.40 / 100
المحافظةبغداد
الإشراف الأكاديمي
ع
عماد محمد عبود
المشرف الأكاديمي
أعضاء الفريق (4)
ع
علي حيدر علاء الدين
قائد الفريق · Bachelor
ح
حنين حسين عامر
AI/Control · Bachelor
غ
غيث ياسر طالب
Other · Bachelor
ف
فهد محمد عبدالعزيز
Programmer · Bachelor
المركز الثالثالمسار الزراعي
NURAI2026-0916
بستاني +
تناول هذا المشروع مشكلةً جوهريةً في مجال الزراعة وإدارة الموارد المائية، حيث يواجه المزارعون صعوبة في تشخيص أمراض النباتات واكتشافها مبكراً نتيجة غياب…
الجامعة: الجامعة التقنية الجنوبية
الفريق: فريق الاشاوس
المشرف: أ.د. عيسى احمد عبد
NURAI2026-0916 · المسار الزراعي
بستاني +
فريق الاشاوس — الجامعة التقنية الجنوبية
المركز الثالث
نبذة عن المشروع
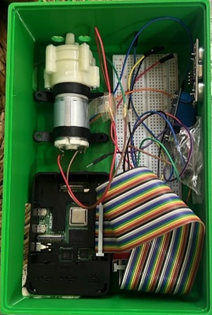
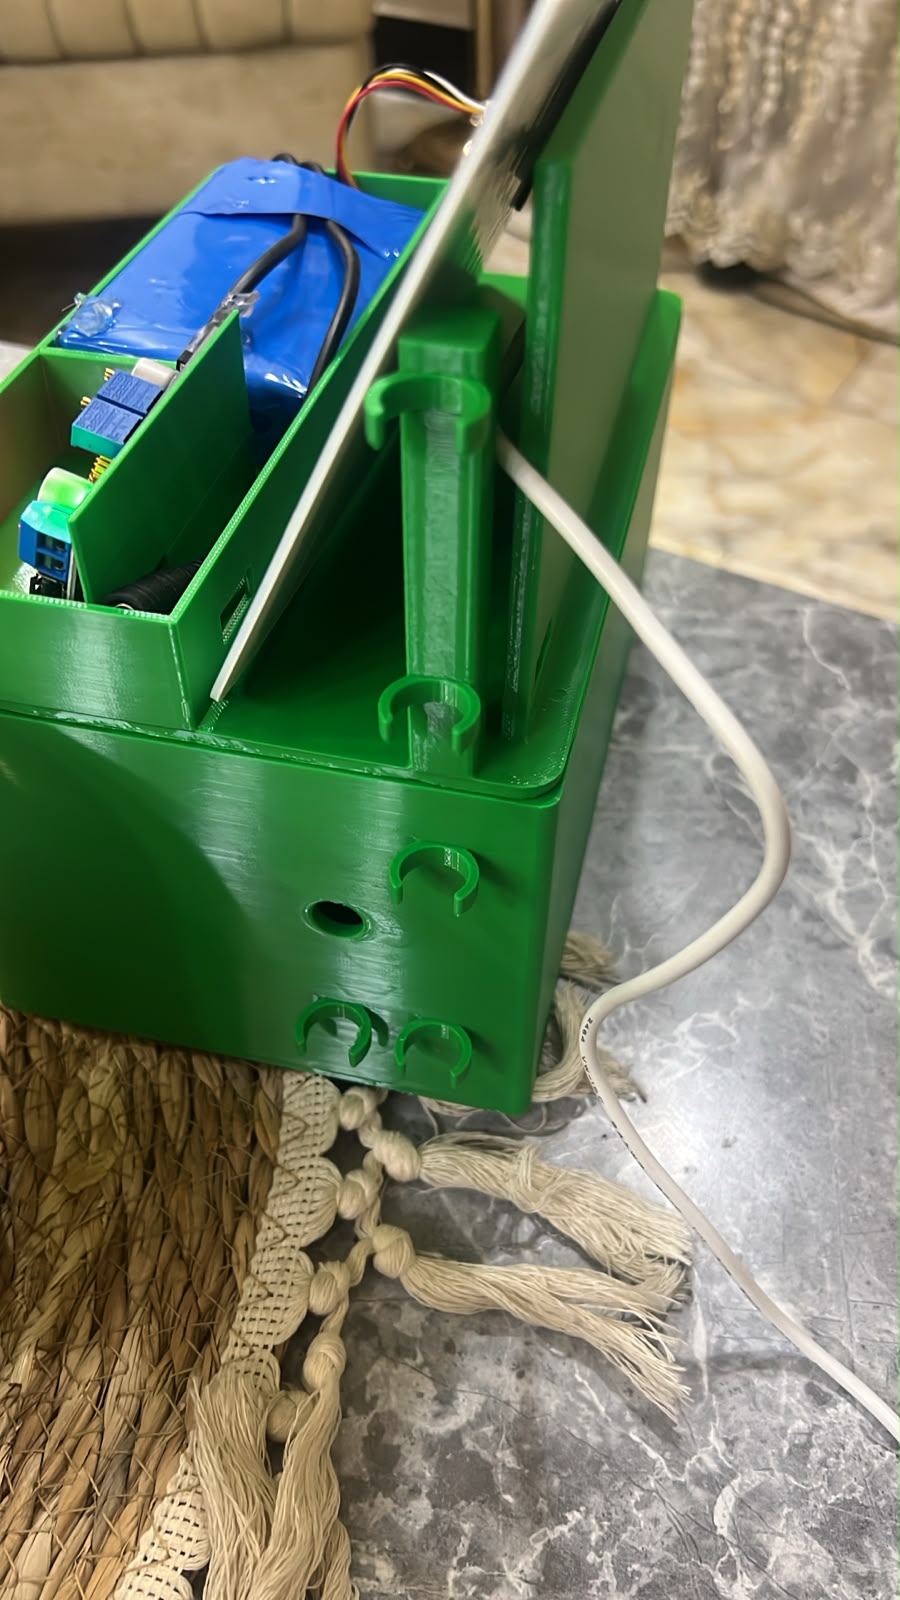
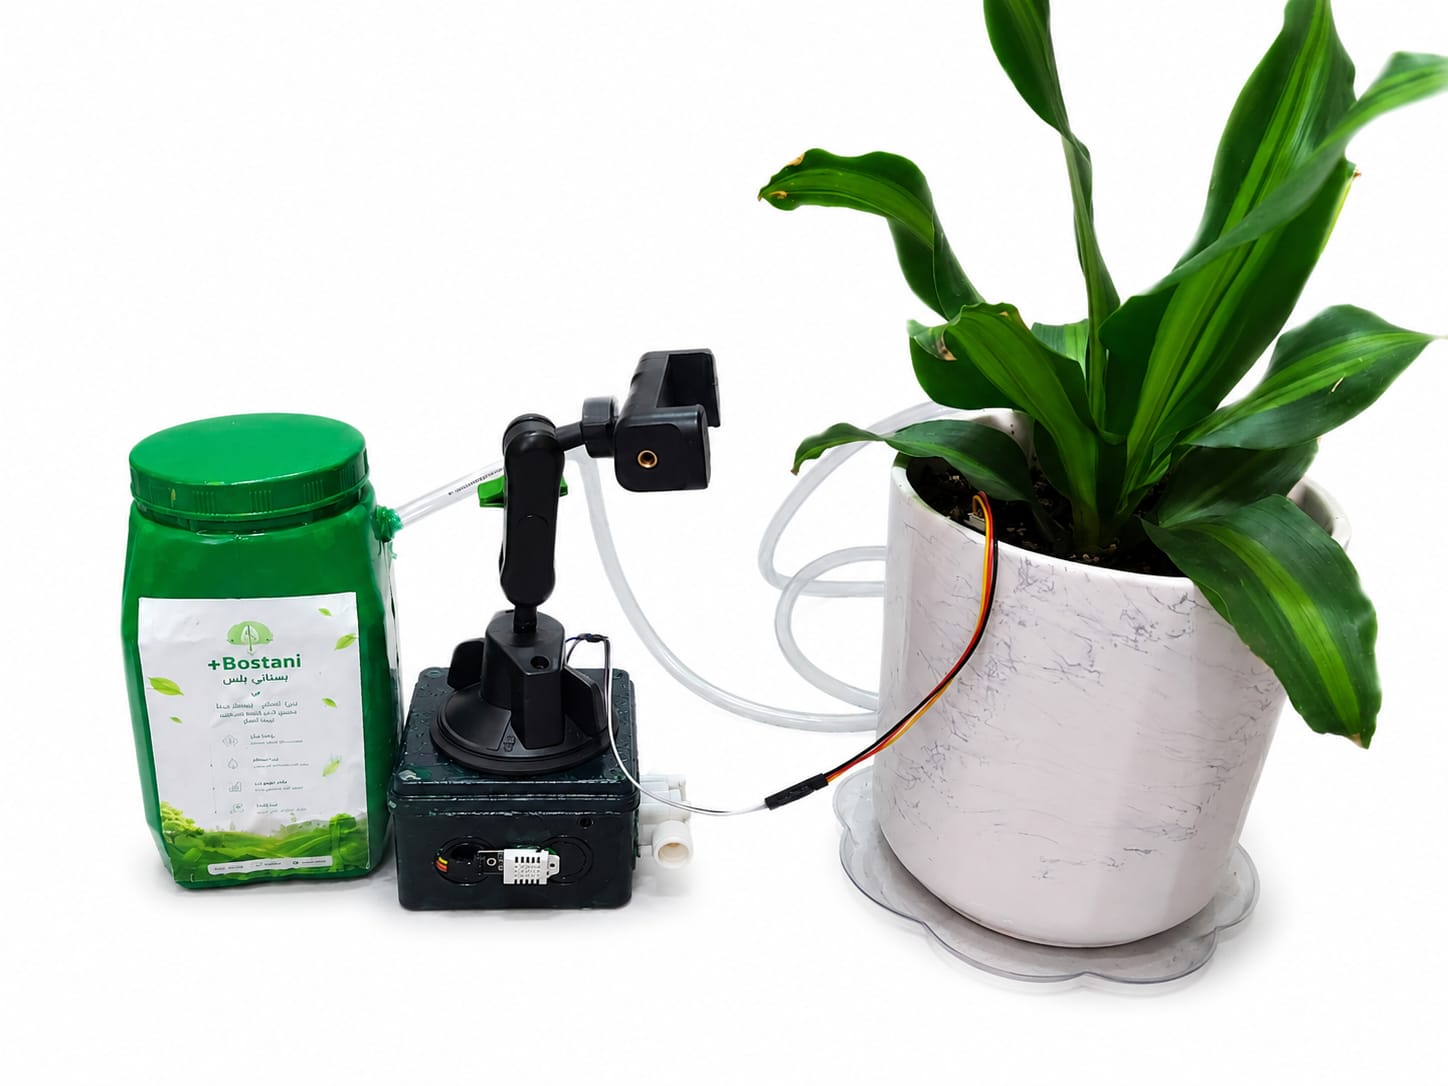
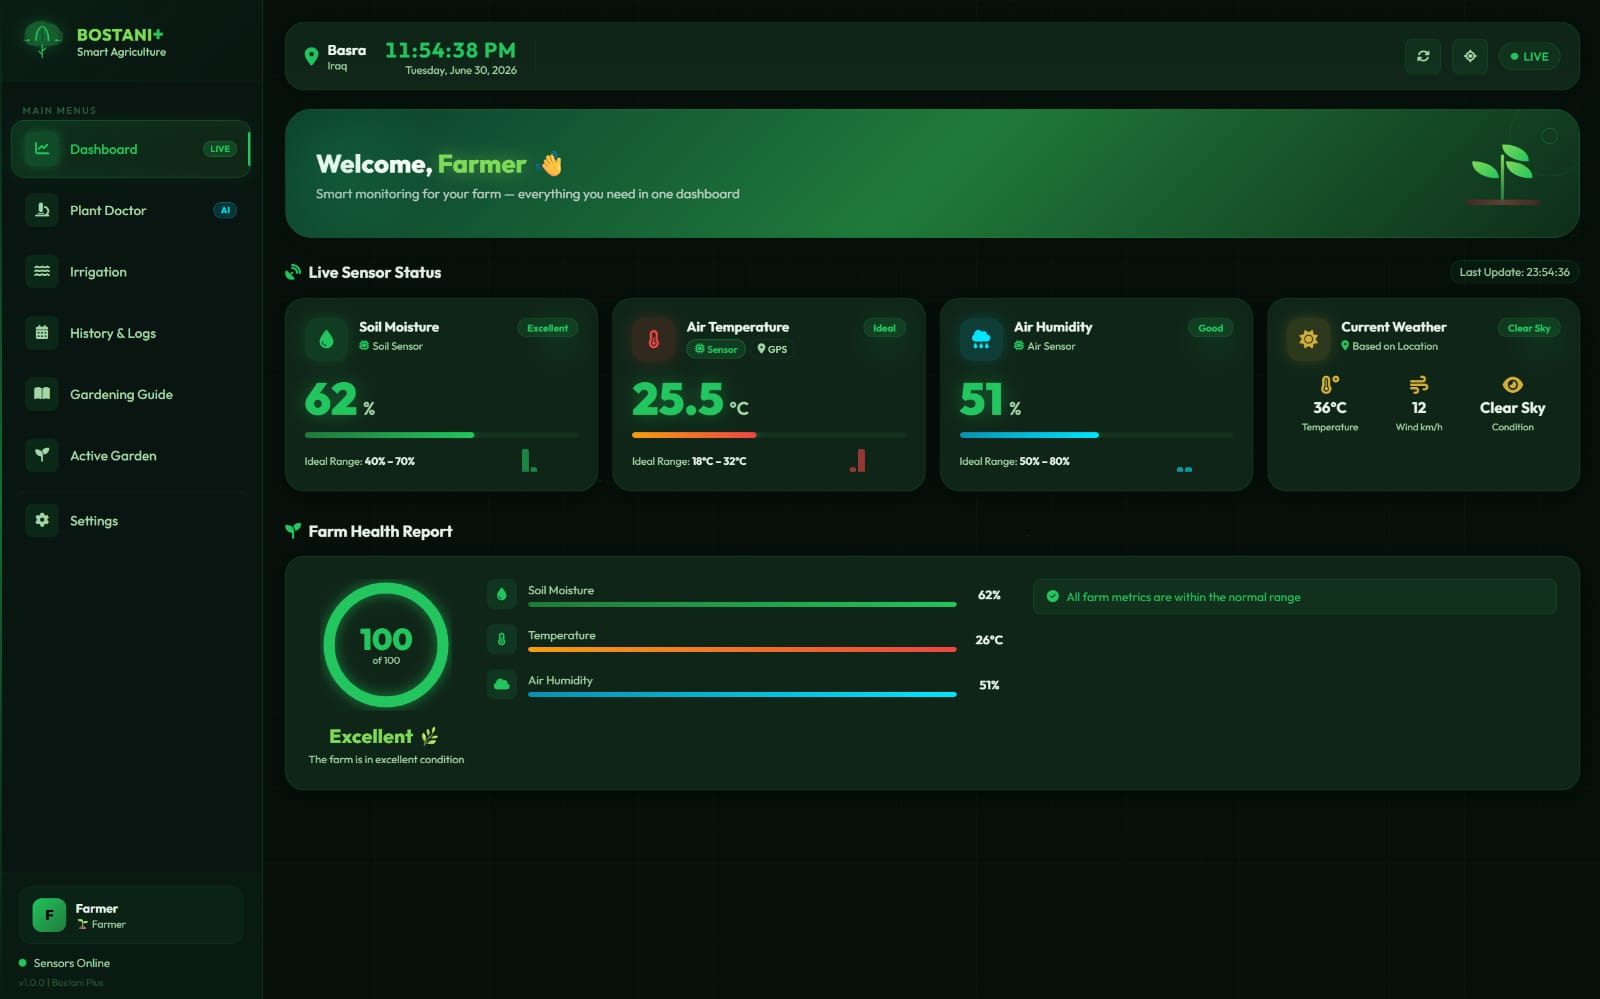
تناول هذا المشروع مشكلةً جوهريةً في مجال الزراعة وإدارة الموارد المائية، حيث يواجه المزارعون صعوبة في تشخيص أمراض النباتات واكتشافها مبكراً نتيجة غياب المراقبة اللحظية للبيانات الحيوية، بالإضافة إلى أضرار الري العشوائي الذي يسقي جميع المحاصيل بكميات متساوية متجاهلاً عتبة الرطوبة الخاصة بكل نبتة، مما يؤدي إلى هدر المياه واختناق الجذور. ويستند الحل المقترح (منصة بستاني+) إلى تقنيات إنترنت الأشياء (IoT) والذكاء الاصطناعي، من خلال دمج متحكم دقيق (ESP32) وحساسات بيئية مع نظام ري آلي متصل سحابياً، ووحدة رؤية حاسوبية، بهدف توفير بيانات مراقبة شاملة ولحظية لجميع النباتات، وتقديم إرشاد زراعي رقمي متكامل يُمكّن المزارعين -حتى المبتدئين منهم- من العناية بمحاصيلهم باحترافية. وتشمل النتائج المتوقعة أتمتة عملية الري بالكامل وترشيد استهلاك المياه بناءً على الاحتياج الفعلي للنبات، والتشخيص الآلي للأمراض لاقتراح خطط العلاج المناسبة، بالإضافة إلى حماية معدات الضخ من التلف، مما يؤسس لبيئة زراعية ذكية ومستدامة.
بيانات المشروع والفريق
الجامعةالجامعة التقنية الجنوبية
المسار العلميالمسار الزراعي
الفريقفريق الاشاوس
الترتيب النهائيالمركز الثالث
التقييم النهائي86.20 / 100
المحافظةالبصرة
الإشراف الأكاديمي
أ
أ.د. عيسى احمد عبد
المشرف الأكاديمي
م
مرتضى محمد حسن
المشرف المشارك
أعضاء الفريق (3)
ح
حسين قاسم رحمه الحيدري
Other · Bachelor
ع
علي سامي عباس
Electronics · Bachelor
م
مصطفى أيمن رياض
Programmer · Bachelor
المركز الثالثالمسار الصناعي
NURAI2026-0630
AI-Powered Autonomous Delivery Drone
Road congestion and a rapidly growing delivery economy make last-mile logistics in Iraqi cities slow, costly, and unreliable. This paper presents our …
الجامعة: الجامعة التكنولوجية
الفريق: Metalhead
المشرف: رنا محمد حسن زكي
NURAI2026-0630 · المسار الصناعي
AI-Powered Autonomous Delivery Drone
Metalhead — الجامعة التكنولوجية
المركز الثالث
نبذة عن المشروع
Road congestion and a rapidly growing delivery economy make last-mile logistics in Iraqi cities slow, costly, and
unreliable. This paper presents our project: a low-cost autonomous delivery drone built on the Holybro S500 V2
quadcopter with a Pixhawk 6C Mini flight controller running ArduPilot, supervised by a Raspberry Pi 5 companion
computer with a 13-TOPS Hailo-8L AI accelerator. The system performs the complete delivery mission
autonomously—takeoff, obstacle-aware cruise, arrival notification, operator-confirmed package release, and
automatic return to launch—while a custom web ground-control dashboard provides the live map, camera and
LiDAR feeds, telemetry, and a complete audit log. Onboard edge AI runs object detection in real time, and the
navigation layer uses smart algorithms including advanced robot path planning, Dijkstra-based route selection,
and 360° 2-D LiDAR obstacle avoidance with hard-stop and side-step policies. The full mission pipeline was
validated end-to-end over the University of Technology campus in Baghdad, demonstrating a practical, affordable
path toward delivery drone services in Iraq
بيانات المشروع والفريق
الجامعةالجامعة التكنولوجية
المسار العلميالمسار الصناعي
الفريقMetalhead
الترتيب النهائيالمركز الثالث
التقييم النهائي87.60 / 100
المحافظةبغداد
الإشراف الأكاديمي
ر
رنا محمد حسن زكي
المشرف الأكاديمي
أعضاء الفريق (3)
م
مصطفى كريم عبدالرحمن
قائد الفريق · Bachelor
م
محمد حيدر احمد
AI/Control · Bachelor
م
محمود ياسين عبدالله
Electronics · Bachelor
المركز الثالثالمسار الطبي
NURAI2026-0543
A Non-Invasive Breath-Based Early Detection System for Lung Cancer Using MOS Sensor Array and Machine Learning
يهدف هذا المشروع إلى تطوير نظام أولي منخفض التكلفة للكشف المبكر عن سرطان الرئة بطريقة غير جراحية، من خلال تحليل هواء الزفير باستخدام مصفوفة من حساسات …
الجامعة: جامعة الموصل
الفريق: اوميكاترون
المشرف: د. سيف عبد الحميد مجيد
NURAI2026-0543 · المسار الطبي
A Non-Invasive Breath-Based Early Detection System for Lung Cancer Using MOS Sensor Array and Machine Learning
اوميكاترون — جامعة الموصل
المركز الثالث
نبذة عن المشروع
يهدف هذا المشروع إلى تطوير نظام أولي منخفض التكلفة للكشف المبكر عن سرطان الرئة بطريقة غير جراحية، من خلال تحليل هواء الزفير باستخدام مصفوفة من حساسات الغازات من نوع MOS (Metal Oxide Semiconductor) وتقنيات الذكاء الاصطناعي. تعتمد فكرة المشروع على أن الخلايا السرطانية تُنتج مركبات عضوية متطايرة (VOCs) تختلف عن تلك الموجودة في الأشخاص الأصحاء، ويمكن الاستفادة منها كمؤشرات حيوية للكشف المبكر عن المرض.
تعمل آلية النظام على التقاط استجابة الحساسات عند تعرضها لهذه المركبات، ثم إرسال البيانات إلى متحكم Arduino لمعالجتها مبدئيًا، قبل تحليلها باستخدام خوارزميات التعلم الآلي في بيئة Python، والتي تتضمن معالجة الإشارة، وتحليل المكونات الرئيسية (PCA)، وتصنيف الأنماط باستخدام خوارزمية SVM. ويتيح ذلك التمييز بين الأنماط المختلفة للمركبات العضوية المتطايرة وإظهار نتائج الفحص بصورة سريعة وغير جراحية.
أثبت النموذج الأولي إمكانية استخدام الحساسات منخفضة الكلفة مع تقنيات التعلم الآلي في تحليل أنماط المركبات العضوية المتطايرة، مما يمثل خطوة واعدة نحو تطوير أنظمة ذكية وسريعة للكشف المبكر عن سرطان الرئة. وتتمثل المرحلة المستقبلية للمشروع في التحقق من أداء النظام باستخدام عينات زفير حقيقية من المرضى لتقييم دقته في التطبيقات السريرية.
بيانات المشروع والفريق
الجامعةجامعة الموصل
المسار العلميالمسار الطبي
الفريقاوميكاترون
الترتيب النهائيالمركز الثالث
التقييم النهائي86.60 / 100
المحافظةنينوى
الإشراف الأكاديمي
د
د. سيف عبد الحميد مجيد
المشرف الأكاديمي
أ
أحمد عبد الكريم محمد حسين
المشرف المشارك
أعضاء الفريق (3)
ط
طه جاسم محمد يونس
قائد الفريق · Bachelor
ر
رانيا عمار محمد
Other · Bachelor
ي
يحيى محمد خالد
Programmer · Bachelor
المركز الثالثمسار التربية والتعليم
NURAI2026-0675
Autism Care System: An Interactive Robot for Supporting Daily Task Independence in Children with Autism
Design and implementation of an interactive assistive system to help children with Autism Spectrum Disorder (ASD) to perform the activities of daily l…
الجامعة: جامعة تكريت
الفريق: تأهيل اطفال التوحد
المشرف: أ.م.نايف محمد حماش
NURAI2026-0675 · مسار التربية والتعليم
Autism Care System: An Interactive Robot for Supporting Daily Task Independence in Children with Autism
تأهيل اطفال التوحد — جامعة تكريت
المركز الثالث
نبذة عن المشروع
Design and implementation of an interactive assistive system to help children with Autism Spectrum Disorder (ASD) to perform the activities of daily living independently is presented in this project, which is named Autism Care System. This system utilizes an ESP32 microcontroller and also involves a TFT display, audio stimulation using a DFPlayer Mini module, touch and sound sensors, and physical interaction buttons, integrating a multisensory learning environment. The robot guides and teaches step by step using visual and auditory cues for everyday tasks like handwashing and dressing, and offers instant positive feedback with sounds and animation to keep the children engaged and motivated in learning. The proposed system aims to assist children with ASD within the home and educational context to become more independent, improve adherence to tasks, and enhance interactive learning, while being low-cost, portable, and child-friendly.
بيانات المشروع والفريق
الجامعةجامعة تكريت
المسار العلميمسار التربية والتعليم
الفريقتأهيل اطفال التوحد
الترتيب النهائيالمركز الثالث
التقييم النهائي82.73 / 100
المحافظةصلاح الدين
الإشراف الأكاديمي
أ
أ.م.نايف محمد حماش
المشرف الأكاديمي
أعضاء الفريق (4)
س
ساهجة عكرمة
قائد الفريق · Bachelor
خ
خديجة فارس
Electronics · Bachelor
ر
رفيف غزوان
Programmer · Bachelor
ف
فاطمة محمود
AI/Control · Bachelor
المركز الثالثمسار خدمة المجتمع
NURAI2026-0613
تصميم وتطوير نظام رادار بصري للكشف عن الطائرات المسيّرة ومواجهتها
يعتمد المشروع على تصميم رادار بصري ذكي باستخدام تقنيات الرؤية الحاسوبية والذكاء الاصطناعي، حيث تم تدريب النموذج على أكثر من 15 ألف صورة للطائرات المسي…
الجامعة: الجامعة التكنولوجية
الفريق: Sky zone
المشرف: ميادة تقي وازي
NURAI2026-0613 · مسار خدمة المجتمع
تصميم وتطوير نظام رادار بصري للكشف عن الطائرات المسيّرة ومواجهتها
Sky zone — الجامعة التكنولوجية
المركز الثالث
نبذة عن المشروع
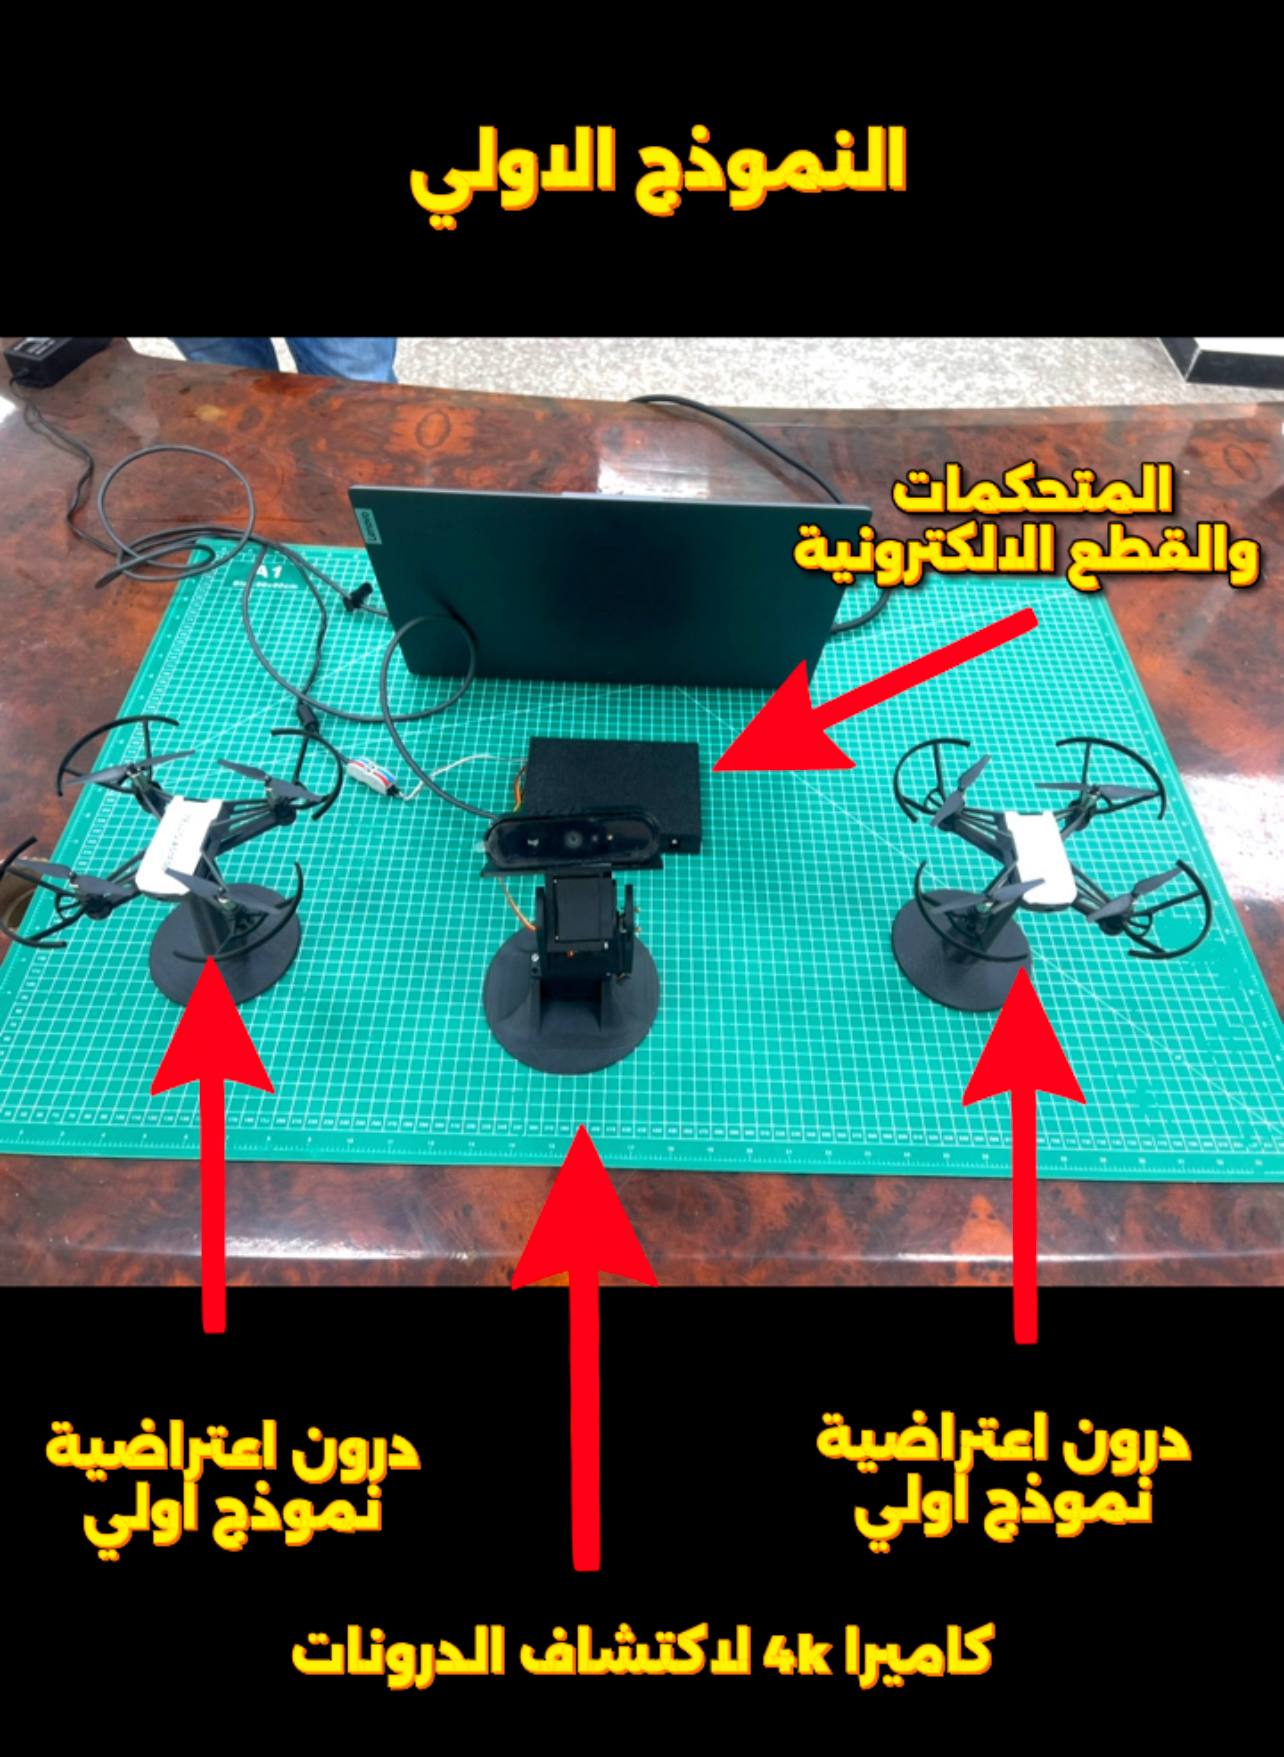
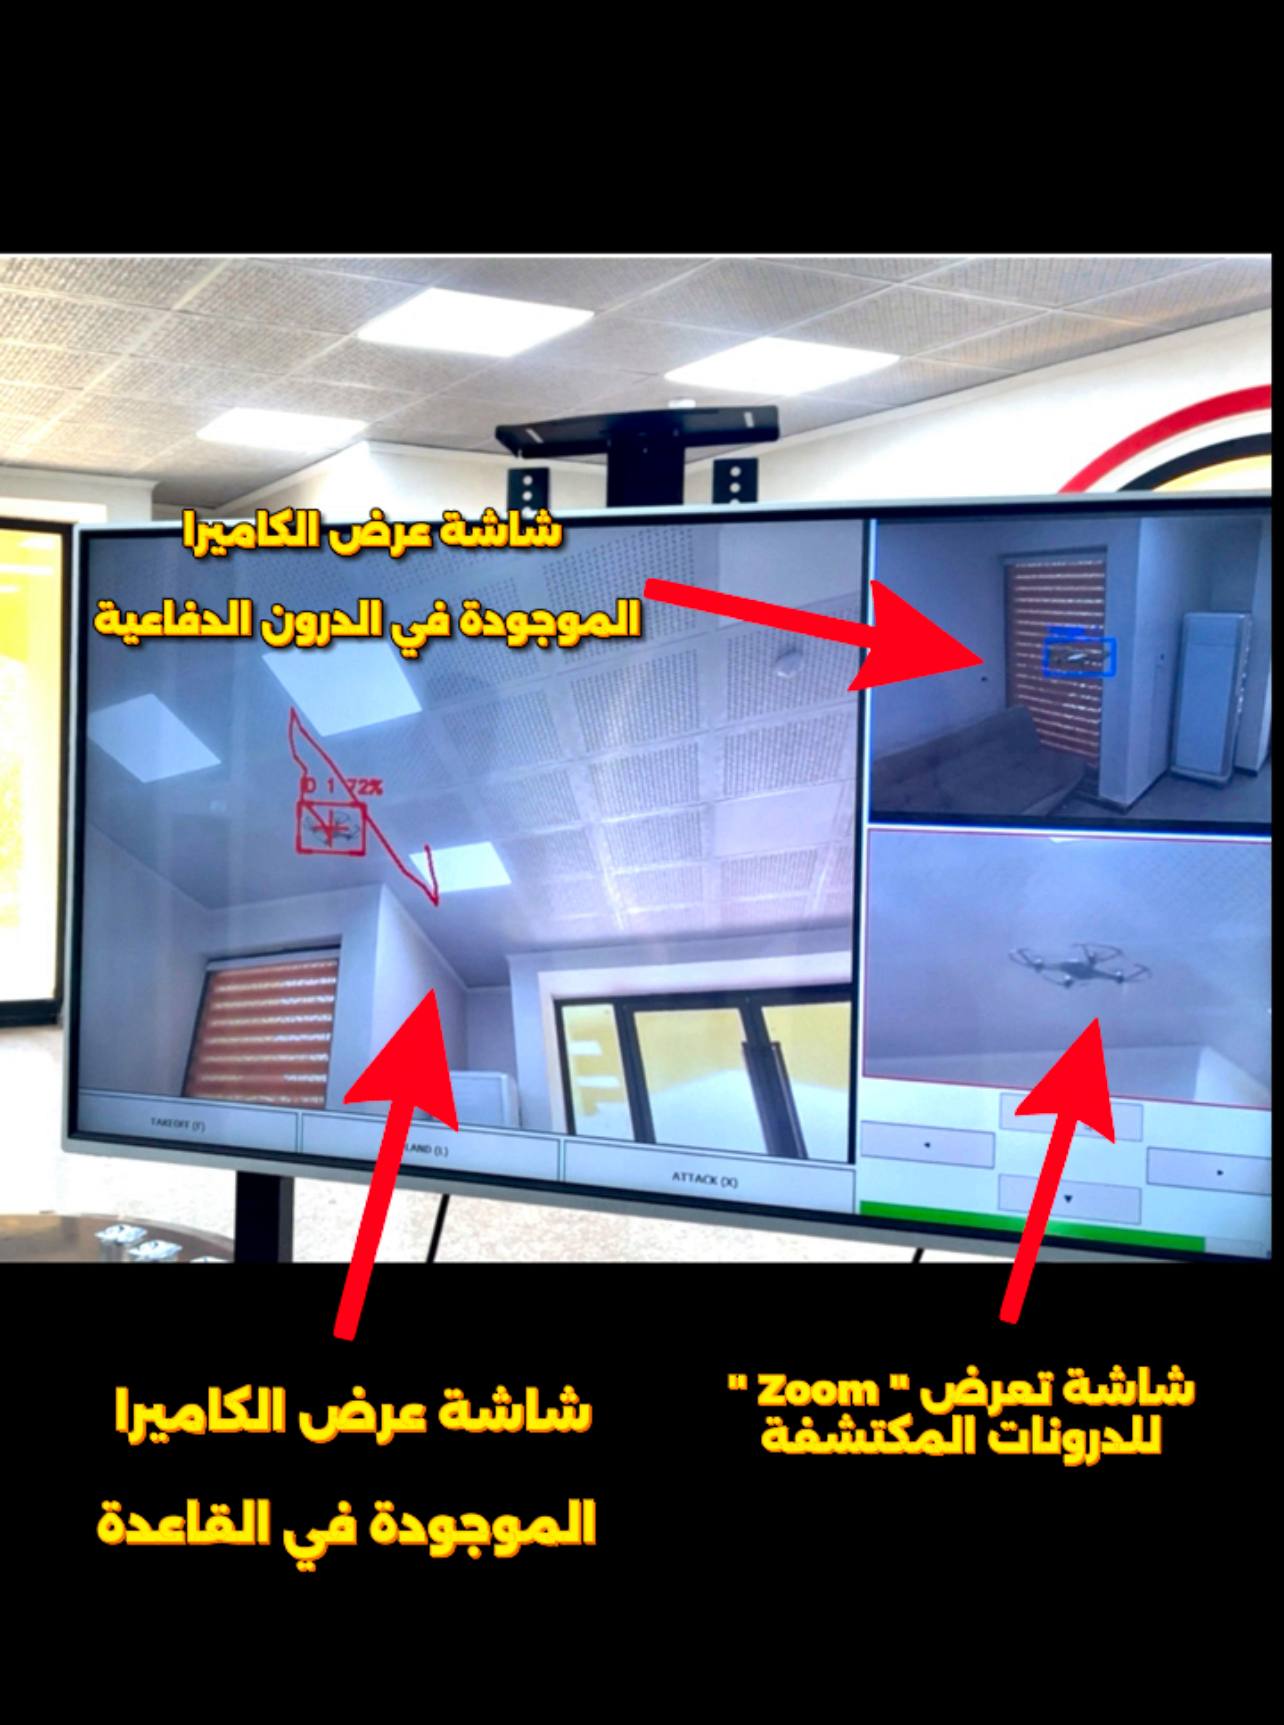
يعتمد المشروع على تصميم رادار بصري ذكي باستخدام تقنيات الرؤية الحاسوبية والذكاء الاصطناعي، حيث تم تدريب النموذج على أكثر من 15 ألف صورة للطائرات المسيّرة ليتمكن النظام من اكتشاف الدرونات وتتبعها وتحليل حركتها والتنبؤ بمسارها المستقبلي.
بعد اكتشاف الهدف يقوم النظام بتكبيره وعرض بياناته، ثم يرسل المعلومات إلى درون اعتراضية ذكية مدعومة بالذكاء الاصطناعي لملاحقة الهدف.
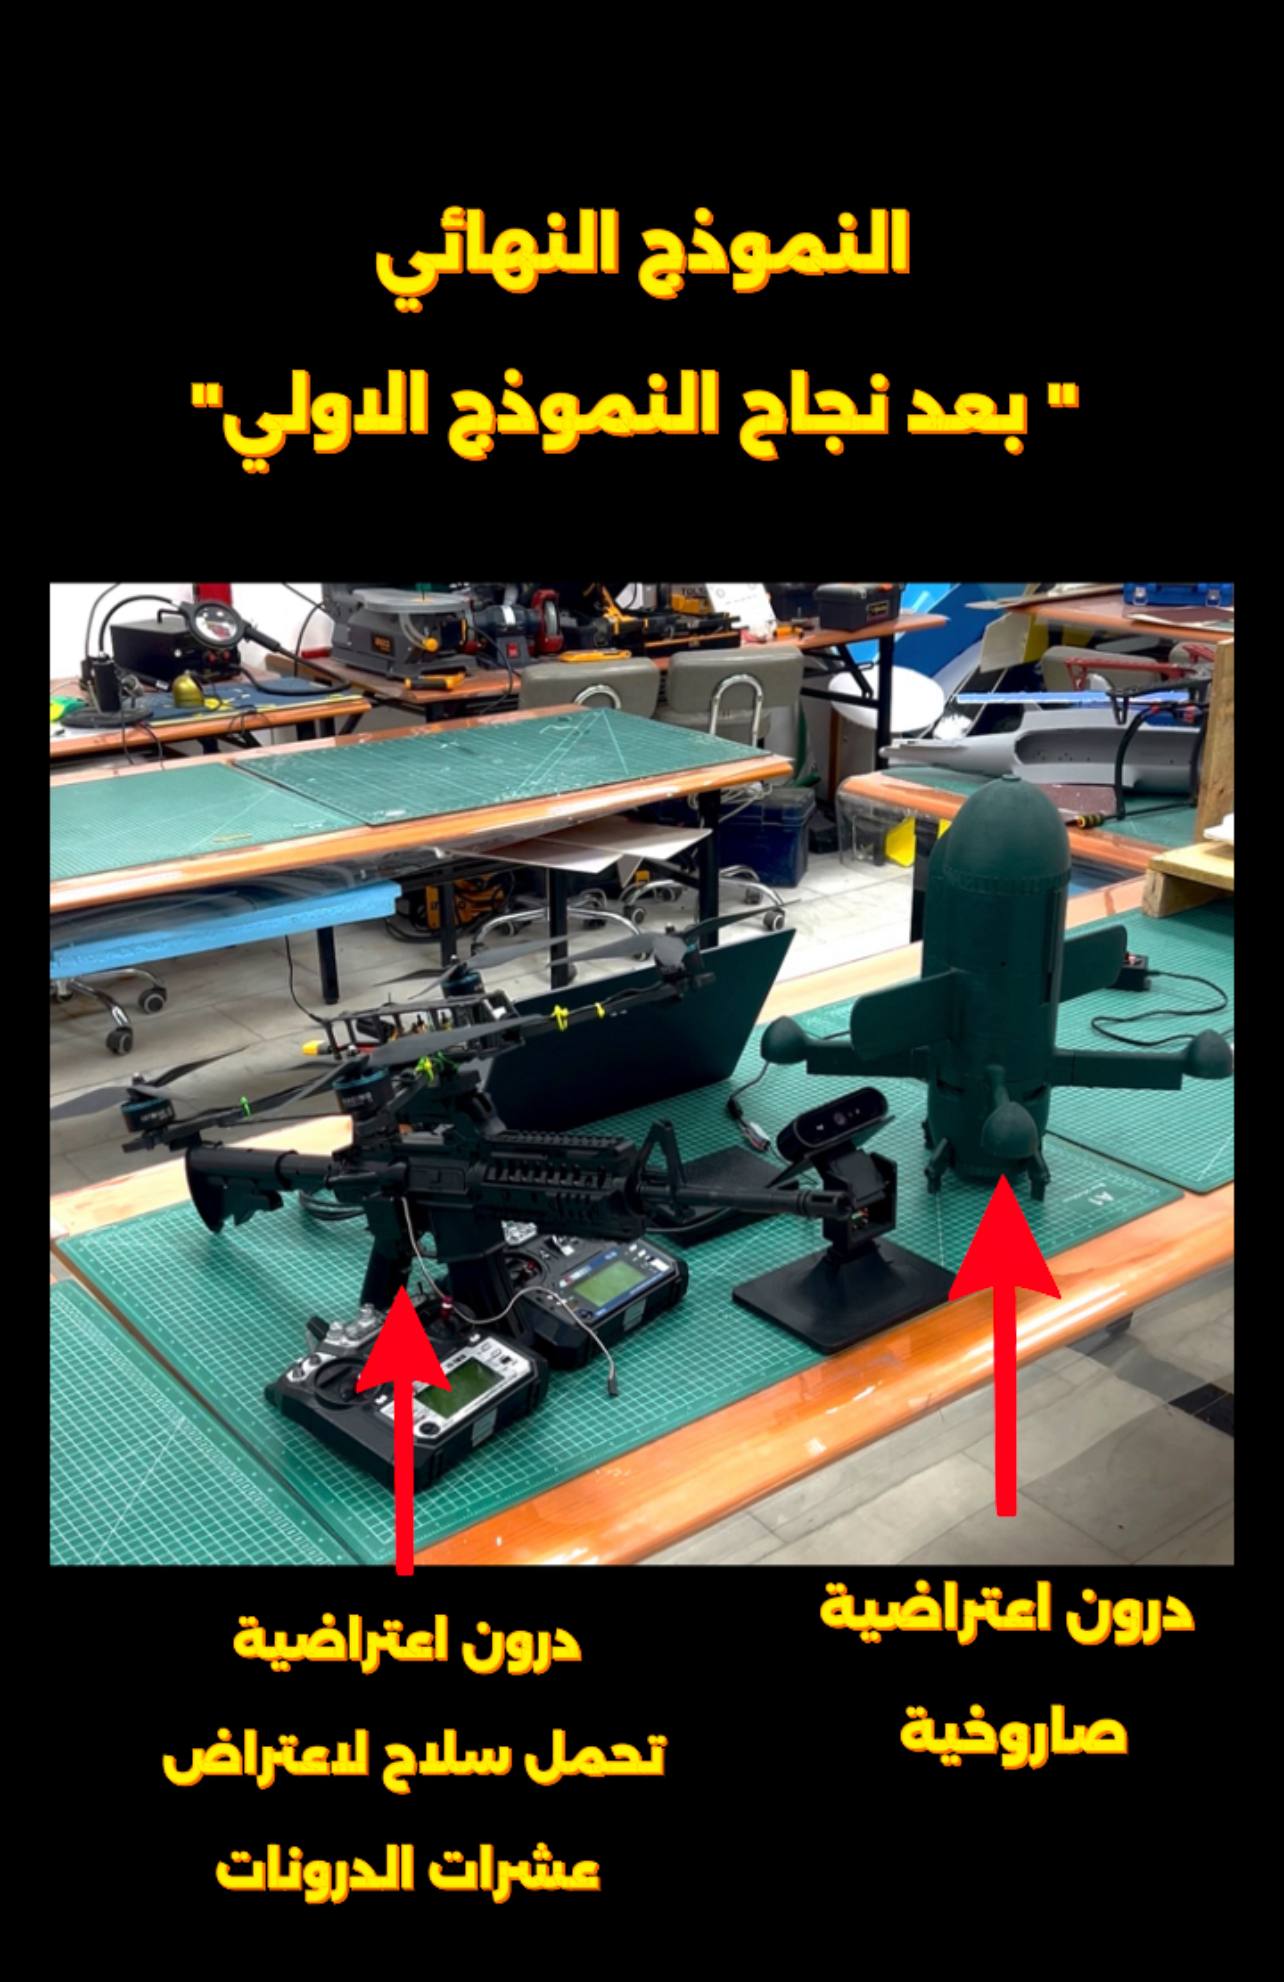
تم اختبار السوفتوير على درون DJI Tello مفتوحة المصدر، وبعد نجاح الاختبارات تم تطوير الهاردوير لبناء نموذج عملي، يتضمن درون اعتراضية عالية السرعة مستوحاة من نماذج درونات مستخدمة فعلياً في ساحات القتال، بالإضافة إلى تطوير درون يحمل سلاح مدعوم بالذكاء الاصطناعي لتنفيذ مهام الاعتراض والتعامل مع عدة أهداف دون خسارة المنصة.
المشروع حالياً مكتمل من ناحية التصميم والبرمجيات وجاهز للاختبار العملي، ويحتاج فقط إلى بعض القطع الإلكترونية لإكمال الدرون الاعتراضية، بالإضافة إلى استخدام كاميرا ذات مواصفات أعلى من المستخدمة حالياً لزيادة مدى الكشف ورفع دقة التتبع.
النتائج المتوقعة:
• إنشاء منظومة متكاملة لكشف وتتبع ومواجهة الطائرات المسيّرة بالذكاء الاصطناعي.
• القدرة على اكتشاف الدرونات والتنبؤ بمسارها والتعامل معها بسرعة عالية.
• تطوير حلول دفاعية قابلة للتوسع لحماية المنشآت والمناطق الحساسة.
• الاعتماد على تقنيات حديثة أصبحت من أهم توجهات الجيوش حول العالم، بعد إثبات فعالية أنظمة مكافحة الدرونات المدعومة بالذكاء الاصطناعي في الاستخدامات الحديثة
بيانات المشروع والفريق
الجامعةالجامعة التكنولوجية
المسار العلميمسار خدمة المجتمع
الفريقSky zone
الترتيب النهائيالمركز الثالث
التقييم النهائي90.60 / 100
المحافظةبغداد
الإشراف الأكاديمي
م
ميادة تقي وازي
المشرف الأكاديمي
أعضاء الفريق (4)
ش
شاكر محمد محمود
قائد الفريق · Bachelor
ا
احمد اياد خلف
Electronics · Bachelor
ز
زينب طلال ضياء
Other · Bachelor
ف
فاضل هاشم فاضل
Electronics · Bachelor
المركز الرابعالمسار البيئي
NURAI2026-0195
Tigris Eye: Design and Development of a Low-Cost Autonomous Surface Robot Fleet for AI-Powered River Water Quality Monitoring with Hydrokinetic Energy Harvesting and Bio-Inspired Fin Steering
River water pollution is a grave threat to the health of the public, the integrity of ecosystems and sustainable development, especially for countries…
الجامعة: جامعة النور
الفريق: Byte Force
المشرف: م.م. محمد بسمان غانم
NURAI2026-0195 · المسار البيئي
Tigris Eye: Design and Development of a Low-Cost Autonomous Surface Robot Fleet for AI-Powered River Water Quality Monitoring with Hydrokinetic Energy Harvesting and Bio-Inspired Fin Steering
Byte Force — جامعة النور
المركز الرابع
نبذة عن المشروع
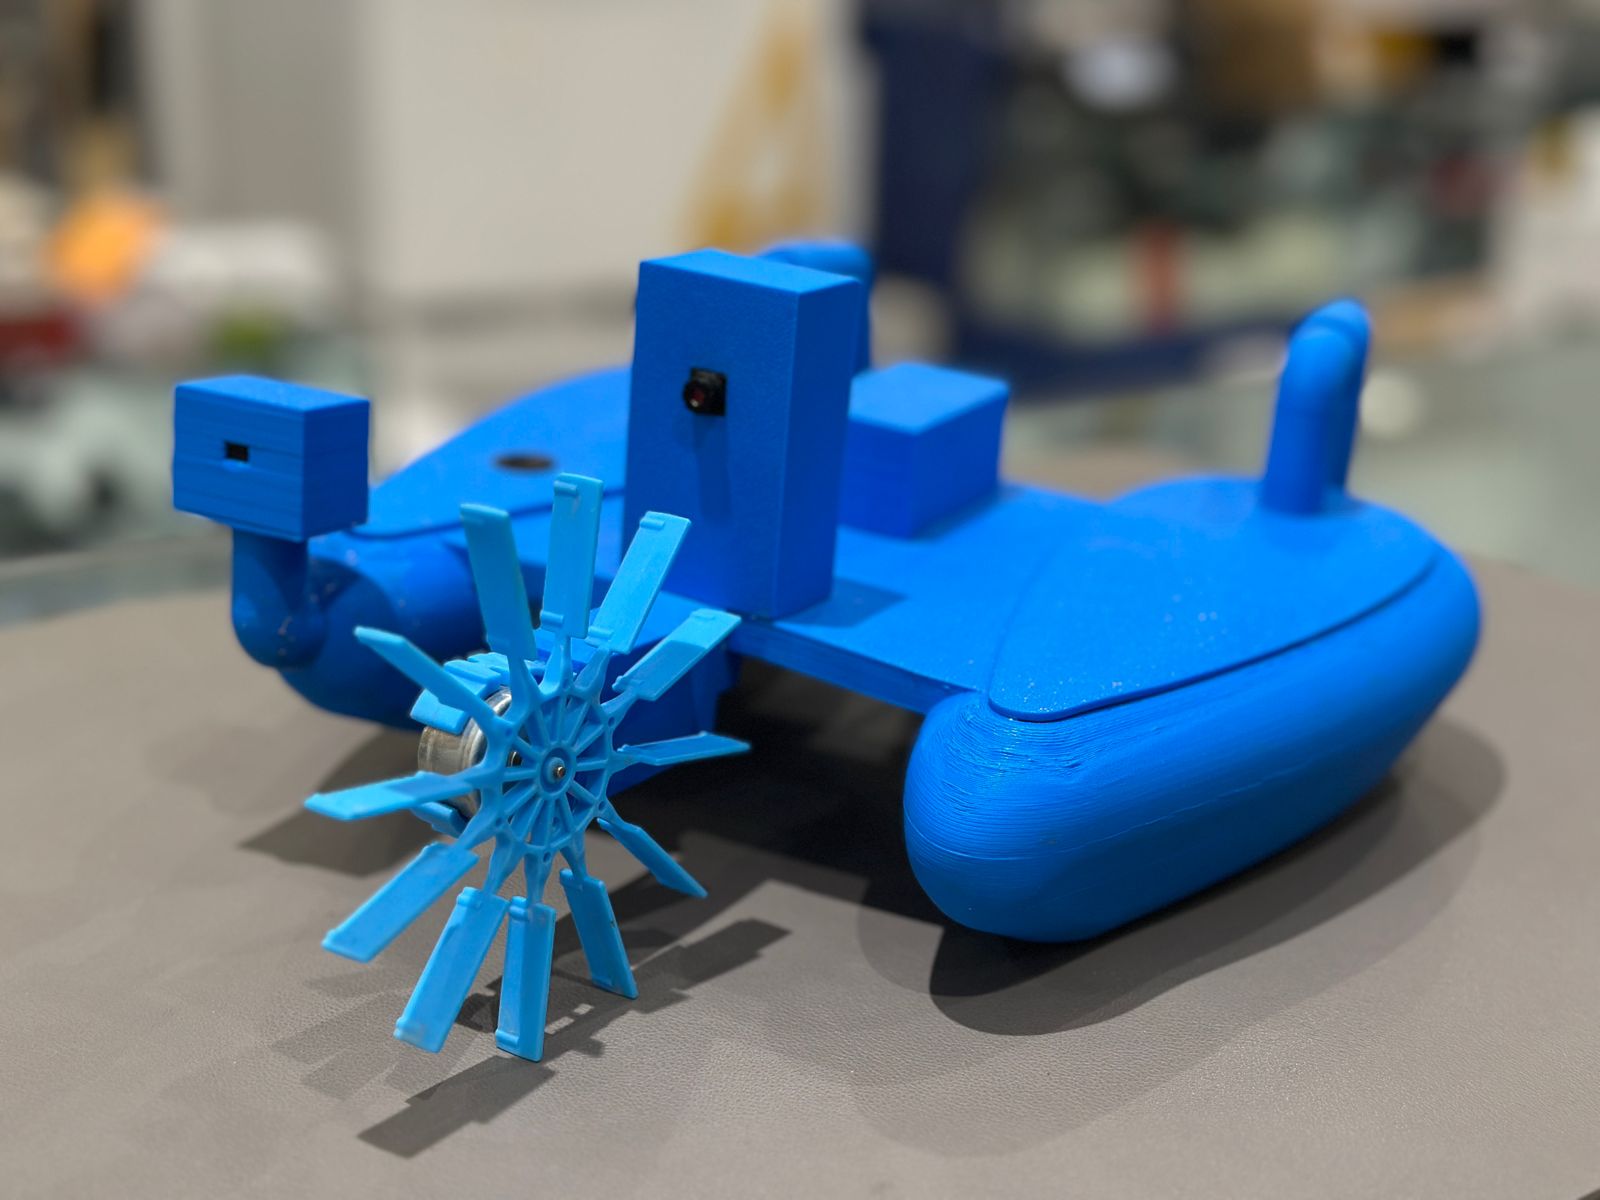
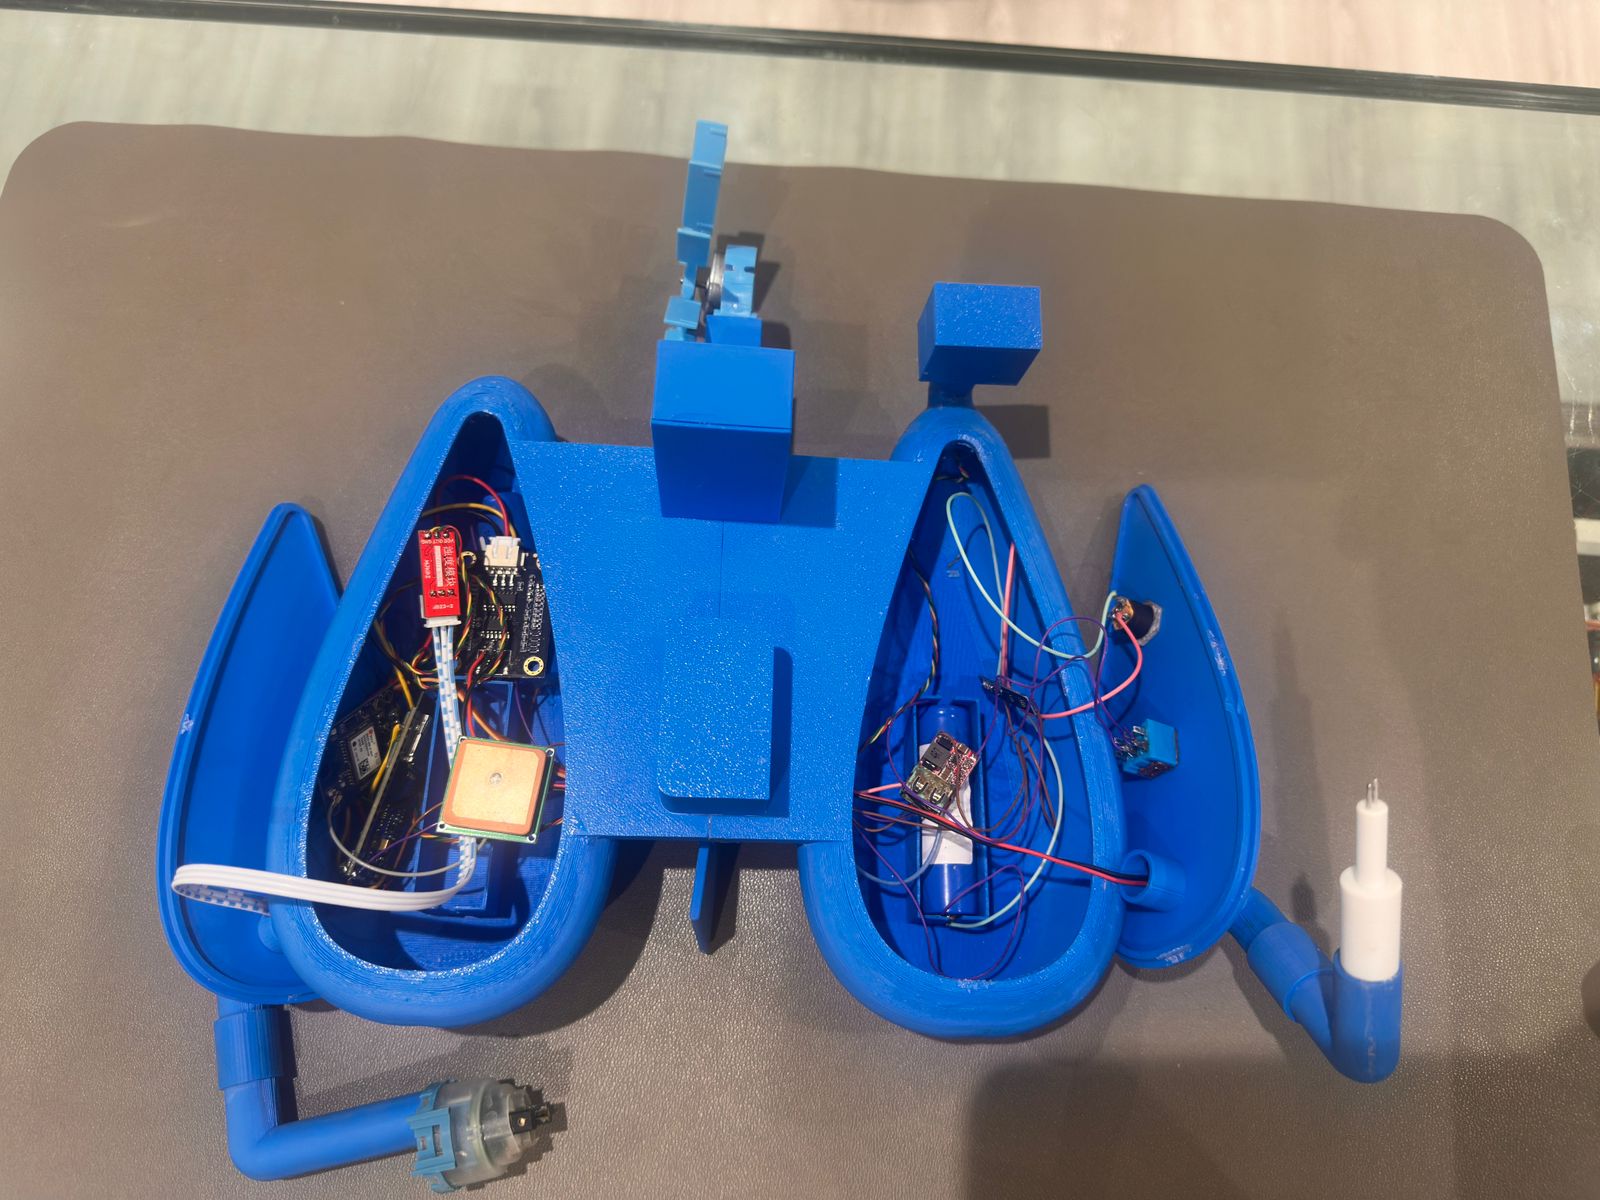
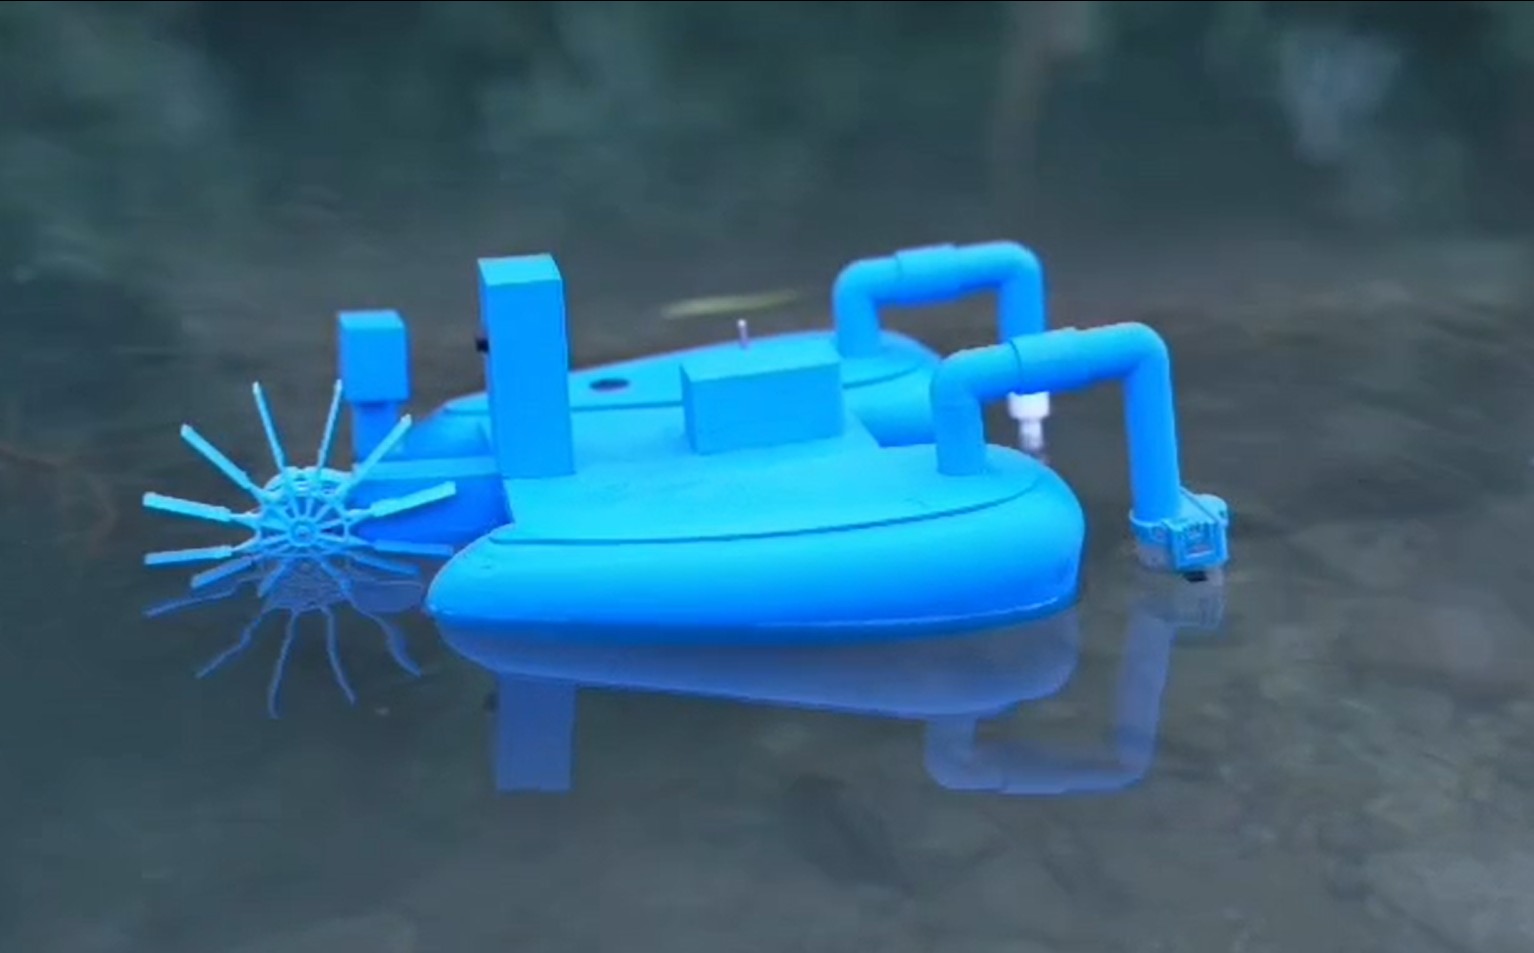
River water pollution is a grave threat to the health of the public, the integrity of ecosystems and sustainable development, especially for countries like Iraq where the Tigris River is one of the main sources of water for millions of residents. Traditional monitoring methods based on manual sampling are labor-intensive, spatially limited and lack the ability to acquire spatiotemporal data in real time. In this paper, we present Tigris Eye, a novel low-cost autonomous surface robot (ASR) system for continuous GPS-tagged AI-powered river water quality monitoring. The system adopts a passive drift navigation strategy, where a fleet of robots passively drifts through the river current without any propulsion, but with directional control only via a bio-inspired fin rudder Each robot is equipped with an ESP32-S3 microcontroller for sensor data acquisition (TDS, turbidity, laser distance), an ESP32-CAM module for periodic visual capture, a GPS module for geotagging every reading, and a hydrokinetic waterwheel mounted at the bow to harvest supplementary electrical energy from river current. All data are sent in real-time over a secure WebSocket (WSS/TLS) to a cloud-based Node.js server hosted on Railway, where YOLOv8-based visual detection identifies floating waste, algal blooms, oil spills, and colour anomalies, and GPT-4o Vision generates structured nine-field pollution assessment reports. An interactive web-based dashboard displays live sensor readings, AI analysis results, GPS-tagged pollution maps and rudder control. The fleet deployment model, multiple low-cost units operating in parallel, guarantees a complete coverage of the river and enables source-localisation of pollutants. Field validation on the Tigris River demonstrates the system's effectiveness in detecting pollution events with sub-10-second latency.
بيانات المشروع والفريق
الجامعةجامعة النور
المسار العلميالمسار البيئي
الفريقByte Force
الترتيب النهائيالمركز الرابع
التقييم النهائي84.80 / 100
المحافظةنينوى
الإشراف الأكاديمي
م
م.م. محمد بسمان غانم
المشرف الأكاديمي
م
م.م. حسام نوفل فاضل
المشرف المشارك
أعضاء الفريق (5)
ق
قاسم محمد الياس
قائد الفريق · Bachelor
س
سرمد حمزة اسماعيل
AI/Control · Bachelor
ع
علي حسين عبدالغني
AI/Control · Bachelor
ع
عمر حاتم يعقوب
Programmer · Bachelor
ف
فواز خضر الياس
Other · Bachelor
المركز الرابعالمسار الزراعي
NURAI2026-0246
Enhanced Morphological Grasping for Fruit Harvesting: Integrating Directional Nano-Adhesion with Logarithmic Spiral Soft Robots
This project addresses a significant problem in the field of soft robotics and automated manipulation for Fruit Harvesting, which is the unstable gras…
الجامعة: جامعة العين العراقية
الفريق: انامل
المشرف: م.م. عمر جاسب كاظم
NURAI2026-0246 · المسار الزراعي
Enhanced Morphological Grasping for Fruit Harvesting: Integrating Directional Nano-Adhesion with Logarithmic Spiral Soft Robots
انامل — جامعة العين العراقية
المركز الرابع
نبذة عن المشروع
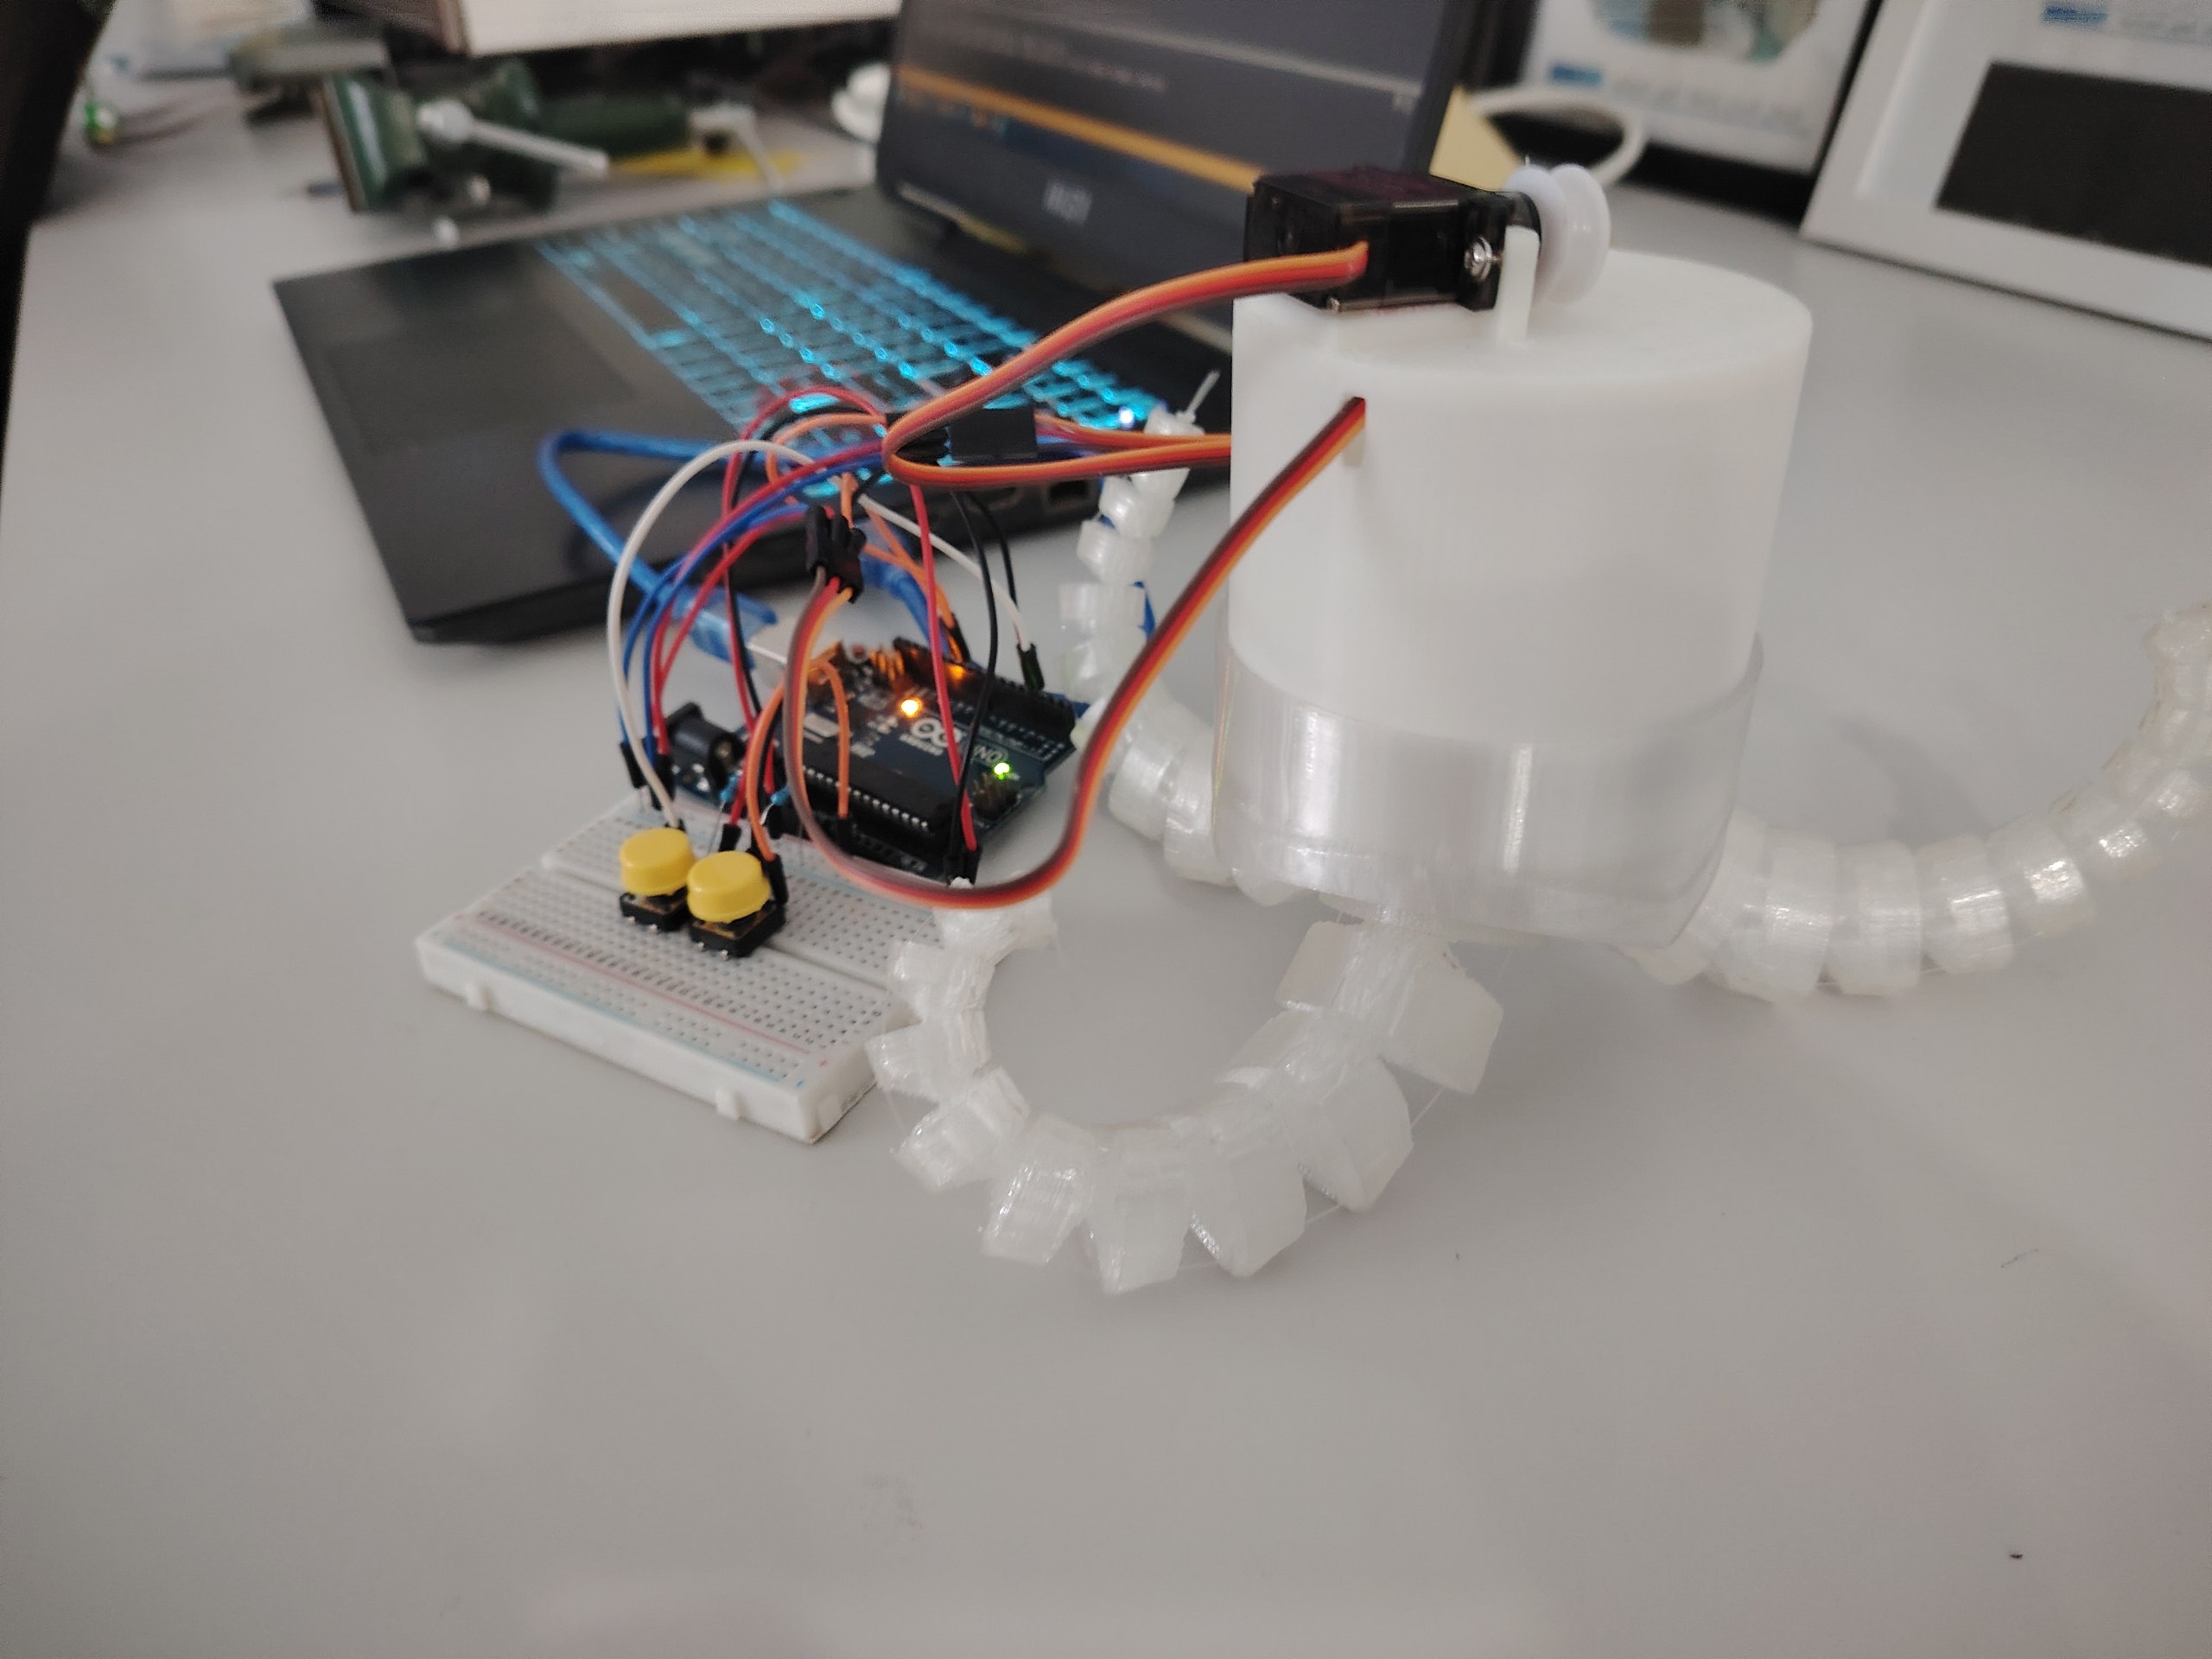
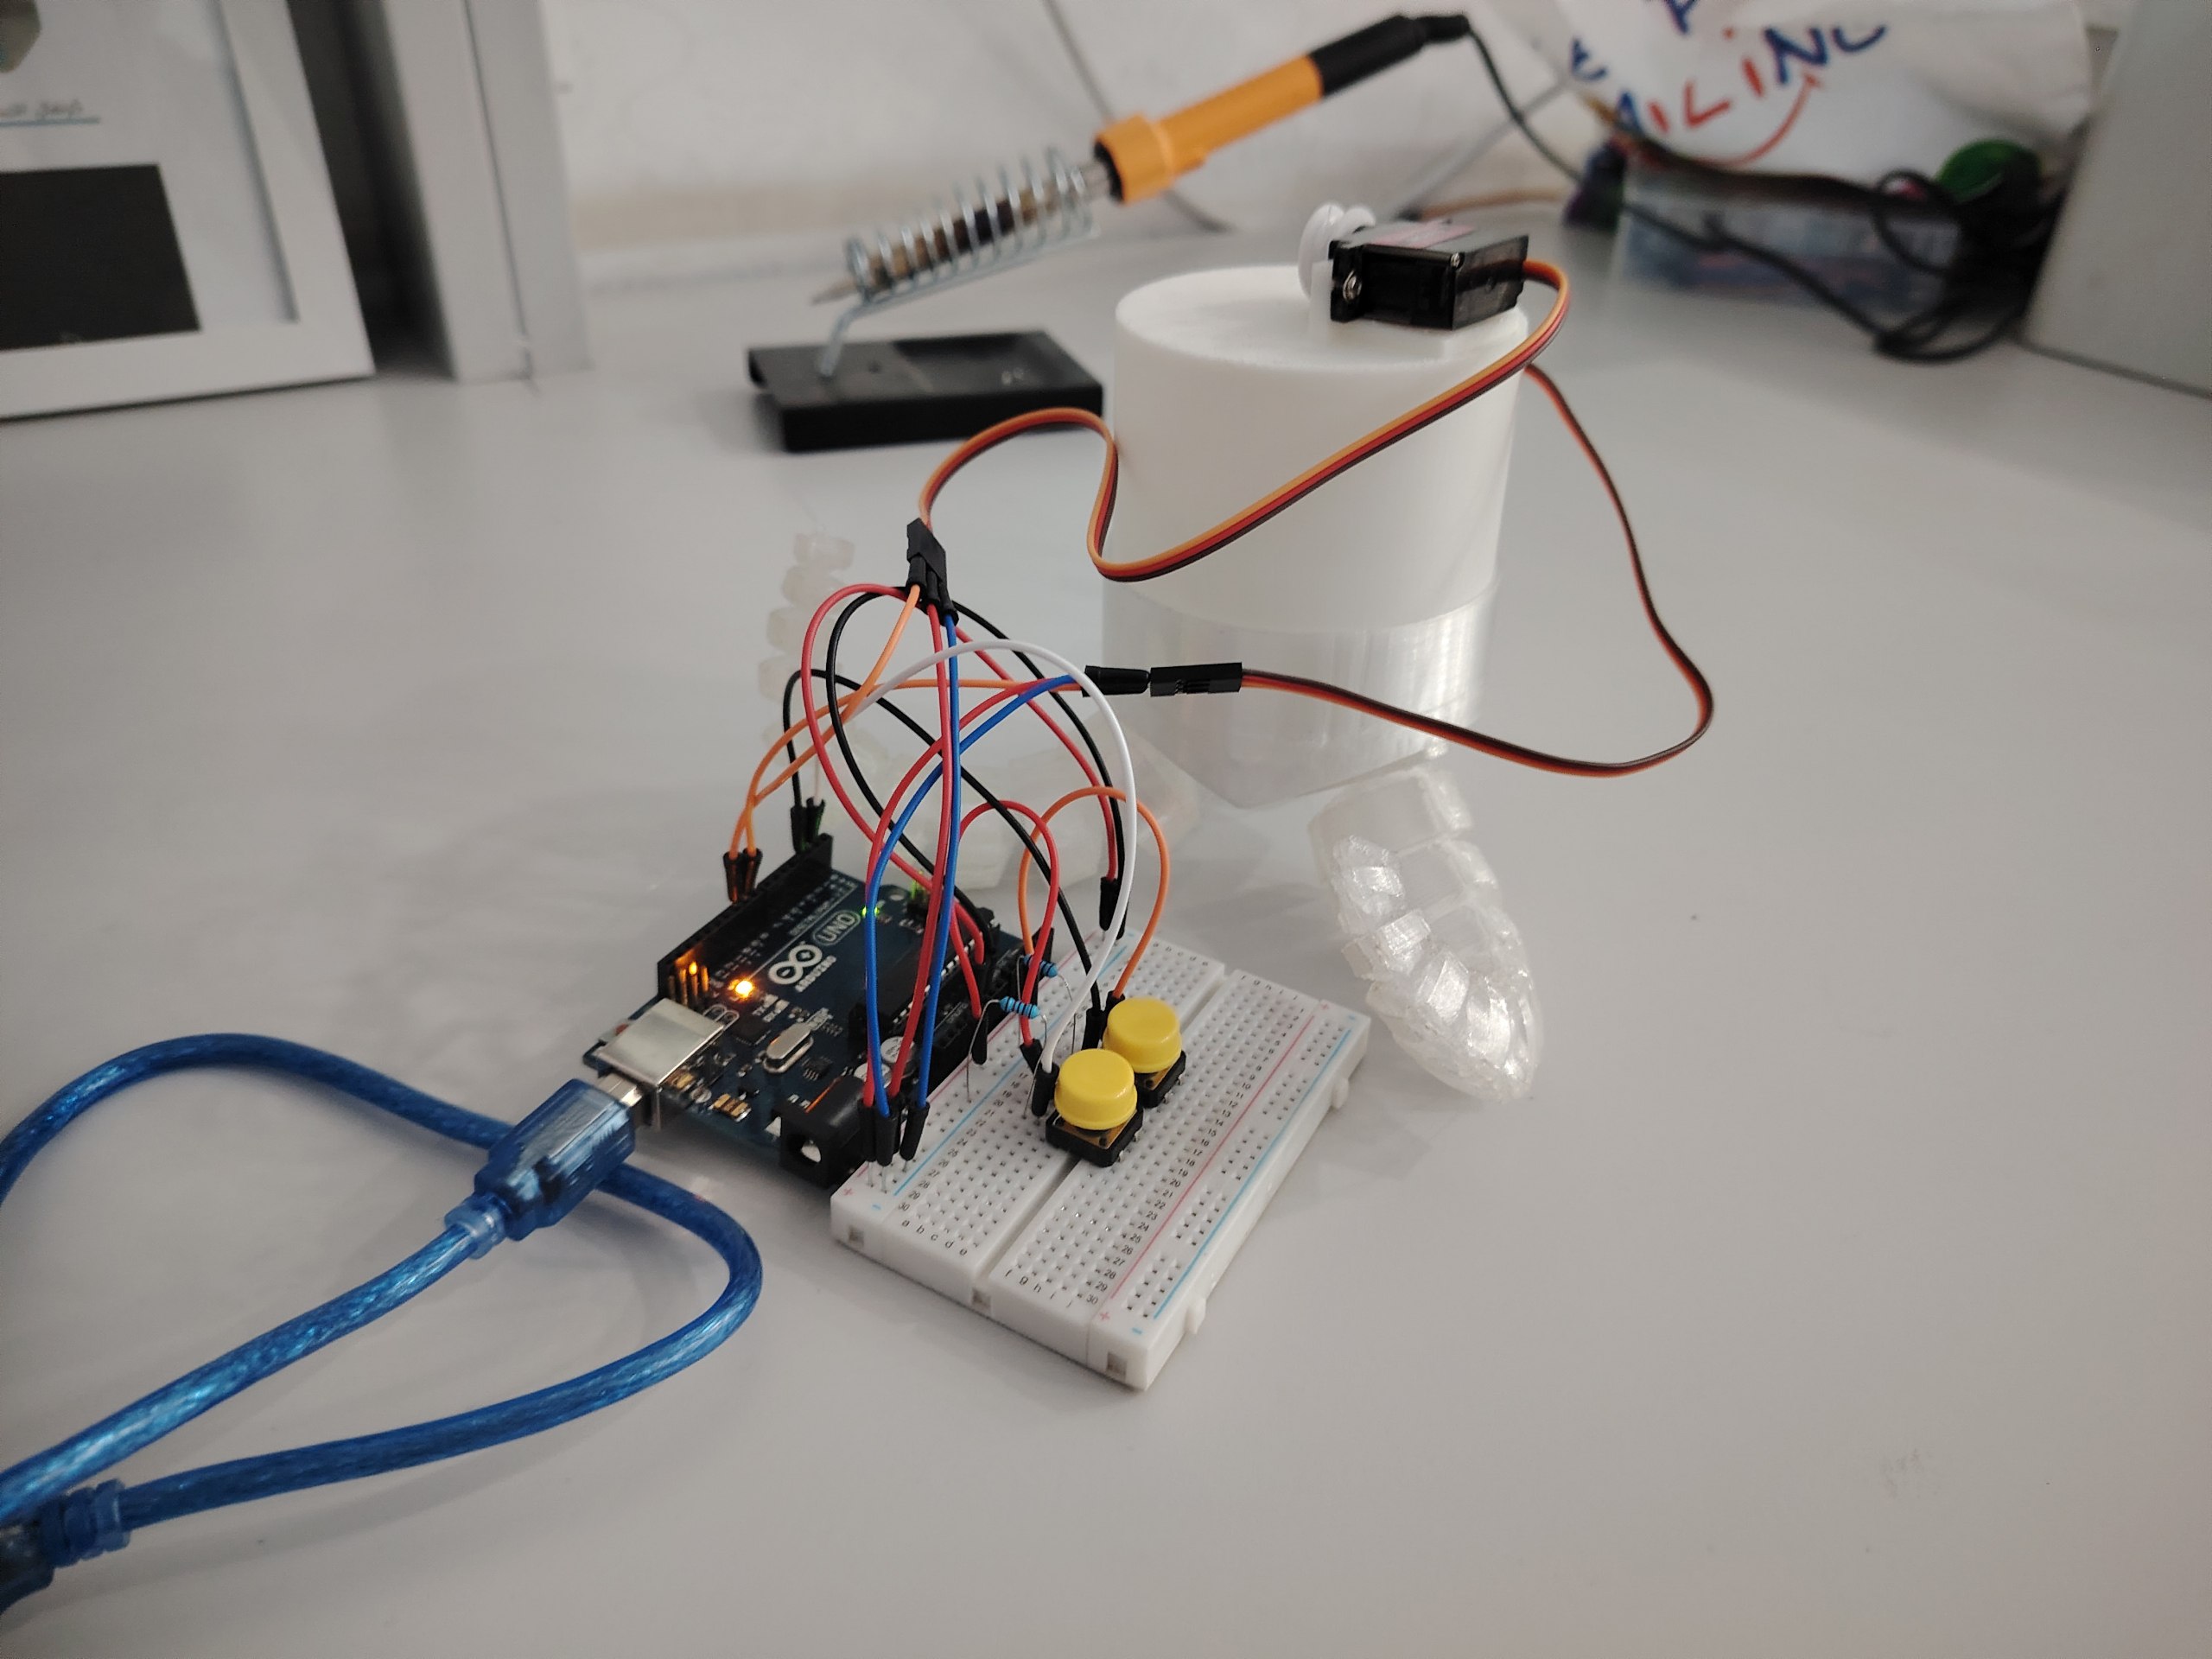
This project addresses a significant problem in the field of soft robotics and automated manipulation for Fruit Harvesting, which is the unstable grasping of smooth or low-friction objects. The proposed solution is based on a cable-driven logarithmic spiral soft robot (SpiRob) integrated with 3D-printed flexible contact membranes and reusable directional nano-adhesion tape, with the aim of maximizing payload stability without requiring excessive mechanical clamping force. The expected outcomes include a substantial increase in grasping reliability for 3-arm robotic arrays, allowing the system to securely hold smooth geometries by combining morphological wrapping with physical van der Waals adhesion.
بيانات المشروع والفريق
الجامعةجامعة العين العراقية
المسار العلميالمسار الزراعي
الفريقانامل
الترتيب النهائيالمركز الرابع
التقييم النهائي86.13 / 100
المحافظةذي قار
الإشراف الأكاديمي
م
م.م. عمر جاسب كاظم
المشرف الأكاديمي
أعضاء الفريق (4)
ح
حسن حيدر زامل
قائد الفريق · Bachelor
س
سامر محمد عبدالرضا
Programmer · Bachelor
س
سجاد ناصر محمد
Other · Bachelor
ض
ضيف الحسن نوار عامر
Electronics · Bachelor
المركز الرابعالمسار الصناعي
NURAI2026-0506
Protecting a Factory from Cyberattacks Using Artificial Intelligence
Industrial factories face increasing cyber threats targeting programmable logic controllers (PLCs), sensors, cameras, and human-machine interfaces (HM…
الجامعة: جامعة الموصل
الفريق: Beta5G
المشرف: د. محمد زكي حسن
NURAI2026-0506 · المسار الصناعي
Protecting a Factory from Cyberattacks Using Artificial Intelligence
Beta5G — جامعة الموصل
المركز الرابع
نبذة عن المشروع
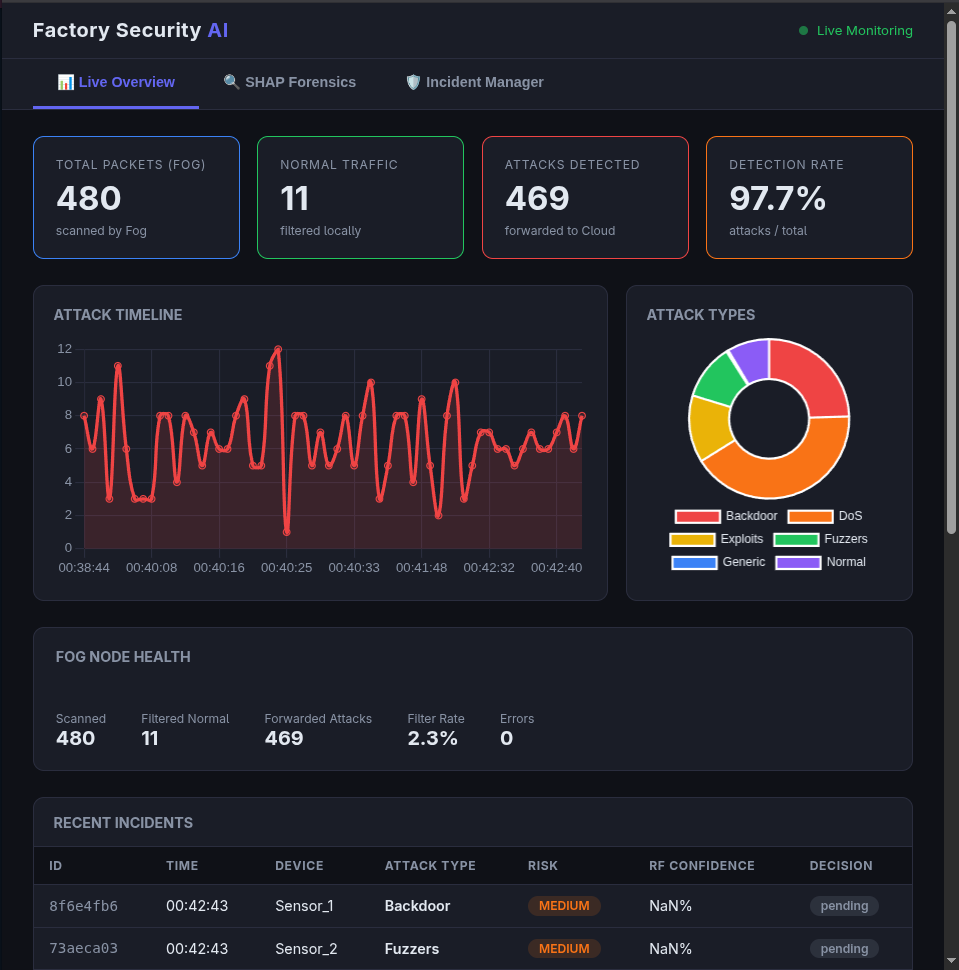
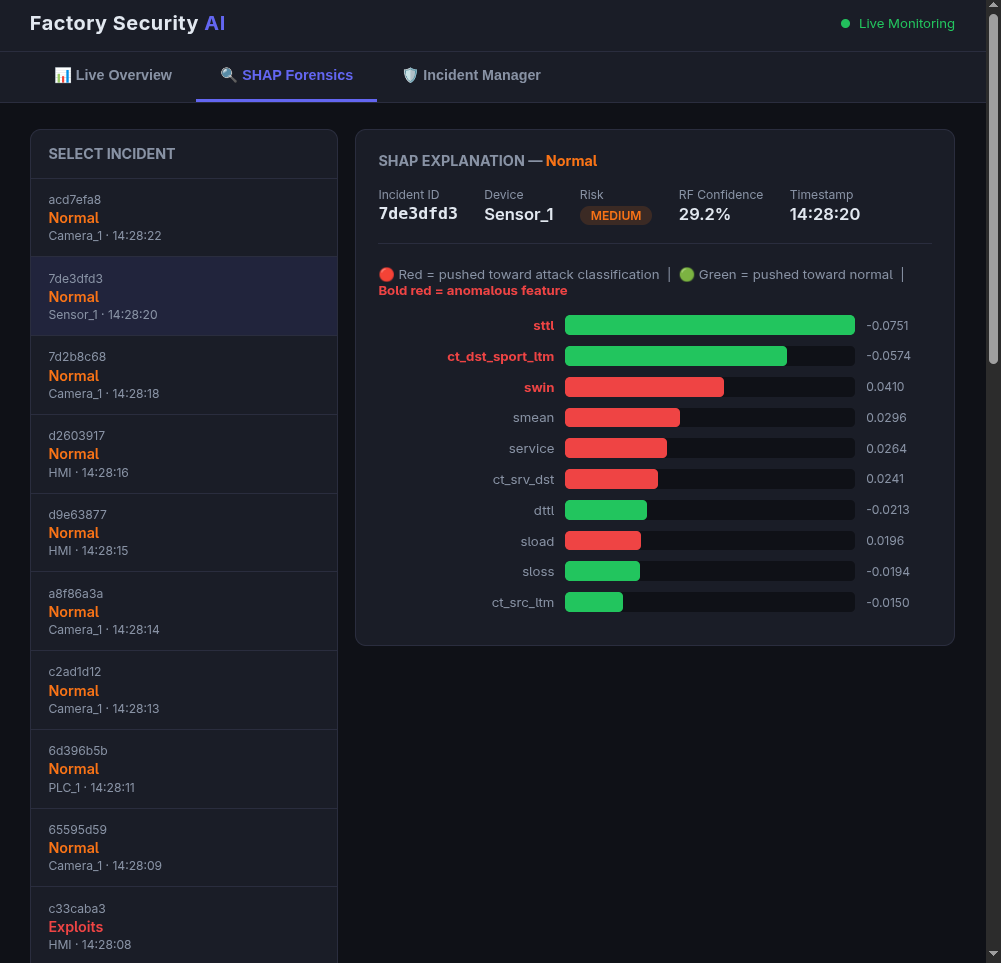
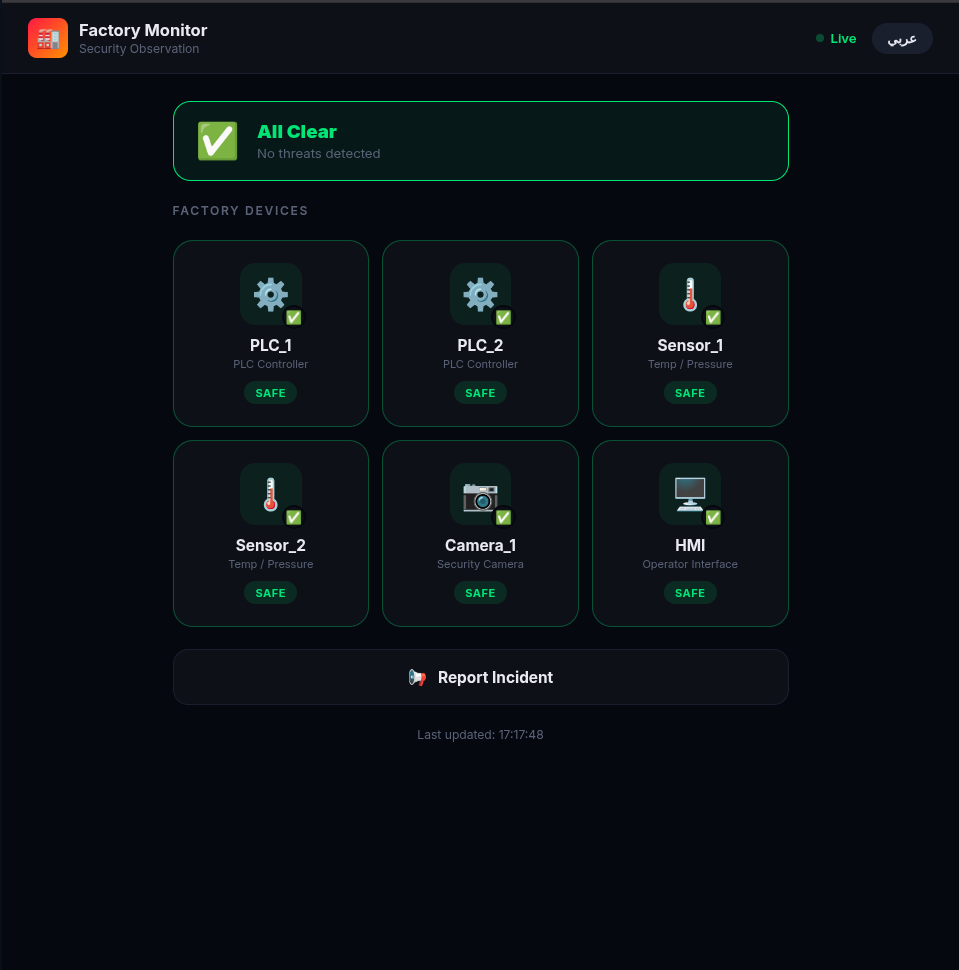
Industrial factories face increasing cyber threats targeting programmable logic controllers (PLCs), sensors, cameras, and human-machine interfaces (HMIs). This paper presents a distributed, real-time intrusion detection system (IDS) for smart factories, built on a three-tier Fog–Cloud–Dashboard architecture deployed via Docker. The Fog layer applies a tuned Decision Tree (DT v3, Recall = 99.89%) combined with an Isolation Forest anomaly detector to filter network traffic locally, forwarding only suspicious packets to the Cloud. The Cloud layer uses an XGBoost classifier (Accuracy = 76.15%) trained on the UNSW-NB15 dataset with SMOTE oversampling and adversarial augmentation to classify nine attack types, while SHAP values provide human-interpretable explanations for each decision. Two web dashboards serve distinct roles: a technical dashboard for security managers and a simplified bilingual (Arabic/English) observer interface. Live tests demonstrate a detection rate exceeding 97% under stress conditions, with sub-second response latency.
بيانات المشروع والفريق
الجامعةجامعة الموصل
المسار العلميالمسار الصناعي
الفريقBeta5G
الترتيب النهائيالمركز الرابع
التقييم النهائي84.00 / 100
المحافظةنينوى
الإشراف الأكاديمي
د
د. محمد زكي حسن
المشرف الأكاديمي
أعضاء الفريق (5)
ح
حسن حسين ناصر
قائد الفريق · Bachelor
إ
إسراء ريان حامد
Other · Bachelor
ح
حكم زكريا طه
Other · Bachelor
ع
عامر منيب محمد
Programmer · Bachelor
م
محمد طه عبد الله
AI/Control · Bachelor
المركز الرابع مكررالمسار الصناعي
NURAI2026-0971
Machine Learning for Threat Detection in Mobile Applications
This project presents a machine-learning system that detects malicious Android applications through static analysis alone, without executing the appli…
الجامعة: الجامعة المستنصرية
الفريق: Machine learning for detection threats on mobile applications
المشرف: ا.م.د. نور ثامر
NURAI2026-0971 · المسار الصناعي
Machine Learning for Threat Detection in Mobile Applications
Machine learning for detection threats on mobile applications — الجامعة المستنصرية
المركز الرابع مكرر
نبذة عن المشروع
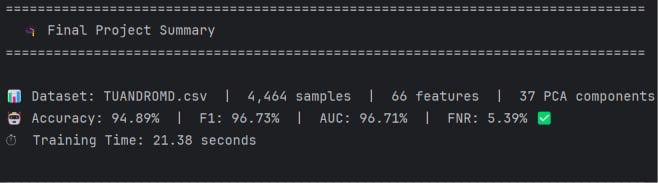
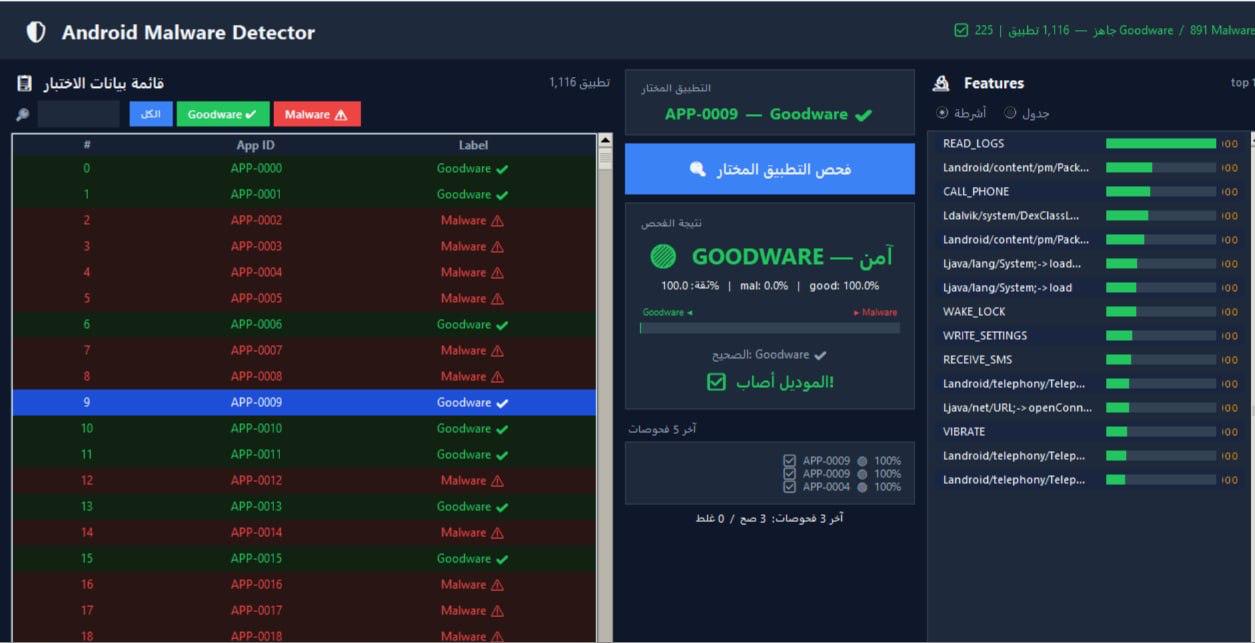
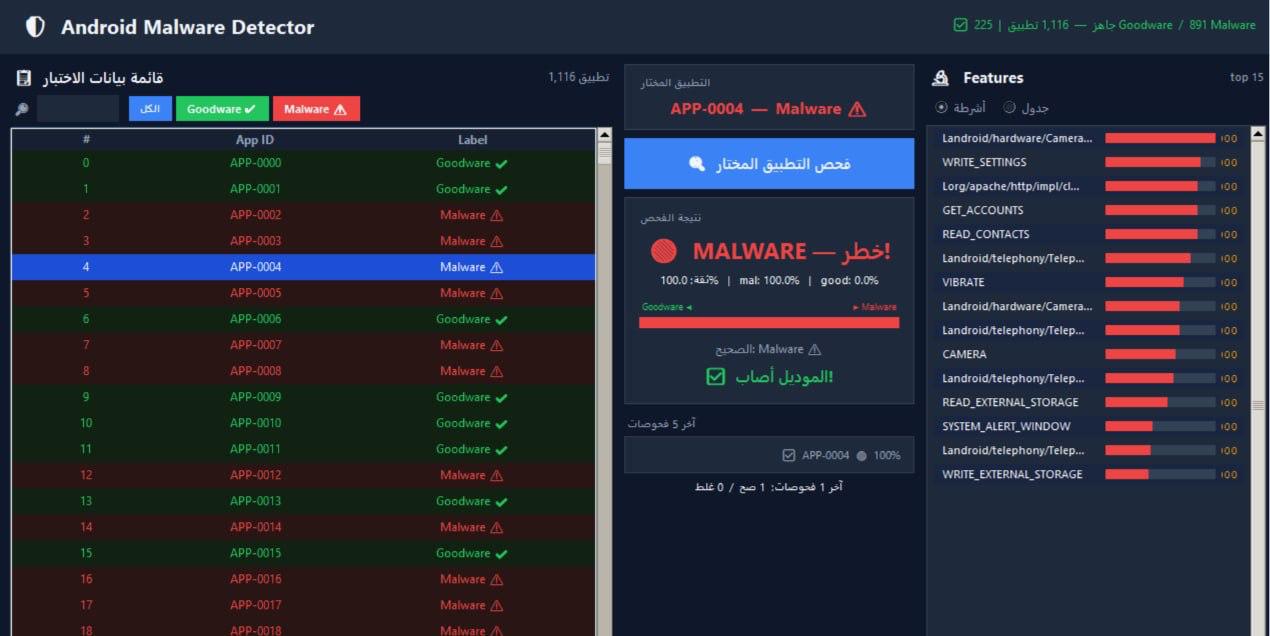
This project presents a machine-learning system that detects malicious Android applications through static analysis alone, without executing the application. Using the TUANDROMD dataset of 4,465 real Android applications described by 241 static features, the pipeline applies a custom Random Forest model for feature selection and Principal Component Analysis for dimensionality reduction, then classifies each application as malware or goodware using a Double Q-Learning reinforcement-learning model with an asymmetric reward structure that penalizes missed malware more heavily than false alarms. The trained model achieves 94.89% accuracy and a low false-negative rate of 5.39%, and is deployed through a simple interactive desktop application.
بيانات المشروع والفريق
الجامعةالجامعة المستنصرية
المسار العلميالمسار الصناعي
الفريقMachine learning for detection threats on mobile applications
الترتيب النهائيالمركز الرابع مكرر
التقييم النهائي84.00 / 100
المحافظةبغداد
الإشراف الأكاديمي
ا
ا.م.د. نور ثامر
المشرف الأكاديمي
أعضاء الفريق (3)
ك
كوثر عبد المجيد
قائد الفريق · Bachelor
ف
فرح طه ياسين
Programmer · Bachelor
ي
يحيى عمر حياوي
Other · Bachelor
المركز الرابعالمسار الطبي
NURAI2026-0272
AI Framework for Lung Sound Analysis of Respiratory Diseases Asthma, Bronchial, COPD and Pneumonia (ABCP)
Abstract This project addresses the growing problem of poor air quality and its impact on respiratory health, especially among children, older adults,…
الجامعة: جامعة الناجي
الفريق: PH Coders
المشرف: ا.م.د. مصطفى رعد عبدالباقي
NURAI2026-0272 · المسار الطبي
AI Framework for Lung Sound Analysis of Respiratory Diseases Asthma, Bronchial, COPD and Pneumonia (ABCP)
PH Coders — جامعة الناجي
المركز الرابع
نبذة عن المشروع
Abstract
This project addresses the growing problem of poor air quality and its impact on respiratory health, especially among children, older adults, and people with respiratory diseases. The proposed solution is based on combining air quality monitoring with lung sound analysis using gas sensors, signal processing, and artificial intelligence. The main objective is to provide an intelligent system that can monitor environmental air conditions and detect possible respiratory diseases at an early stage. The expected outcomes include air quality assessment, early detection of lung diseases such as asthma, bronchitis, chronic obstructive pulmonary disease (COPD), and pneumonia, continuous health monitoring, and better support for medical decision-making.
Keywords: Lung sound analysis, Artificial intelligence, Respiratory disease detection, Air quality monitoring.
برنامج ذكاء اصطناعي لتحليل صوت الرئة لأمراض الجهاز التنفسي: الربو، التهاب القصيبات، مرض الانسداد الرئوي المزمن والالتهاب
الرئوي
الخلاصة
يعالج هذا المشروع المشكلة المتزايدة لسوء جودة الهواء وتأثيرها على صحة الجهاز التنفسي، خاصة بين الأطفال وكبار السن والأشخاص المصابين بأمراض الجهاز التنفسي. الحل المقترح يعتمد على دمج مراقبة جودة الهواء مع تحليل صوت الرئة باستخدام حساسات الغاز، ومعالجة الإشارات، والذكاء الاصطناعي. الهدف الرئيسي هو توفير نظام ذكي يمكنه مراقبة حالة الهواء البيئية واكتشاف الأمراض التنفسية المحتملة في مرحلة مبكرة. تشمل النتائج المتوقعة تقييم جودة الهواء، والكشف المبكر عن أمراض الرئة مثل الربو، والتهاب الشعب الهوائية، ومرض الانسداد الرئوي المزمن، والالتهاب الرئوي، والمراقبة الصحية المستمرة، ودعم أفضل لاتخاذ القرار الطبي.
الكلمات المفتاحية: تحليل صوت الرئة، الذكاء الاصطناعي، كشف أمراض الجهاز التنفسي، مراقبة جودة الهواء.
بيانات المشروع والفريق
الجامعةجامعة الناجي
المسار العلميالمسار الطبي
الفريقPH Coders
الترتيب النهائيالمركز الرابع
التقييم النهائي84.00 / 100
المحافظةبغداد
الإشراف الأكاديمي
ا
ا.م.د. مصطفى رعد عبدالباقي
المشرف الأكاديمي
أعضاء الفريق (3)
إ
إيلياس حيدر ناصب
قائد الفريق · Bachelor
ا
احمد محمد عبدالوهاب
AI/Control · Bachelor
م
منتظر صاحب غلام
Other · Bachelor
المركز الرابعمسار التربية والتعليم
NURAI2026-0200
Nibras: An Intelligent Iraqi Educational Robot for Learning, Emotional Wellbeing Monitoring, and Parent-Assisted Student Support Using Computer Vision and Conversational AI
University students in Iraq face significant gaps in culturally specific educational and emotional support. This project introduces Nibras, an open-so…
الجامعة: جامعة النور
الفريق: NGX
المشرف: م. م. سدرة علي الصغير محمد
NURAI2026-0200 · مسار التربية والتعليم
Nibras: An Intelligent Iraqi Educational Robot for Learning, Emotional Wellbeing Monitoring, and Parent-Assisted Student Support Using Computer Vision and Conversational AI
NGX — جامعة النور
المركز الرابع
نبذة عن المشروع
University students in Iraq face significant gaps in culturally specific educational and emotional support. This project introduces Nibras, an open-source, low-cost (US$31) intelligent robot deployed on a Raspberry Pi 4. Unlike generic AI, Nibras integrates a Claude Haiku 4.5 language model with a specialized computer vision pipeline to estimate emotional cues such as stress and fatigue. Using a voice-first interface, it communicates in native Iraqi Arabic, providing tutoring and emotional wellbeing support. A parent dashboard provides daily summarized reports on mood trends and engagement without compromising student privacy through local-only processing. Testing across 150 cases demonstrates high accuracy in dialect preservation (96%) and crisis detection (100%), proving that sophisticated, hardware-integrated AI can be accessible and culturally resonant.
Keywords: Artificial intelligence, AI, computer vision, Iraqi dialect, emotional well-being.
بيانات المشروع والفريق
الجامعةجامعة النور
المسار العلميمسار التربية والتعليم
الفريقNGX
الترتيب النهائيالمركز الرابع
التقييم النهائي82.67 / 100
المحافظةنينوى
الإشراف الأكاديمي
م
م. م. سدرة علي الصغير محمد
المشرف الأكاديمي
أعضاء الفريق (3)
ا
اسحاق اسيل اسحاق
قائد الفريق · Bachelor
ح
حمزه محمد شاکر محمود
Other · Bachelor
ع
عبد العزيز لقمان عبد العزيز اسماعيل
Other · Bachelor
المركز الرابعمسار خدمة المجتمع
NURAI2026-0618
اثر: مسار هجين مساعد لترجمة المخطوطات العربية ومراجعتها علميًا
مشروع أثر هو نظام ذكي مساعد لقراءة المخطوطات العربية التاريخية ومراجعتها يجمع بين عدة طبقات ذكية تبدا من نموذج تعرّف الخط اليدوي HTR( دربناه على مجموع…
الجامعة: الجامعة التكنولوجية
الفريق: فينكس
المشرف: م.م. محمد ثامر عبدالهادي
NURAI2026-0618 · مسار خدمة المجتمع
اثر: مسار هجين مساعد لترجمة المخطوطات العربية ومراجعتها علميًا
فينكس — الجامعة التكنولوجية
المركز الرابع
نبذة عن المشروع
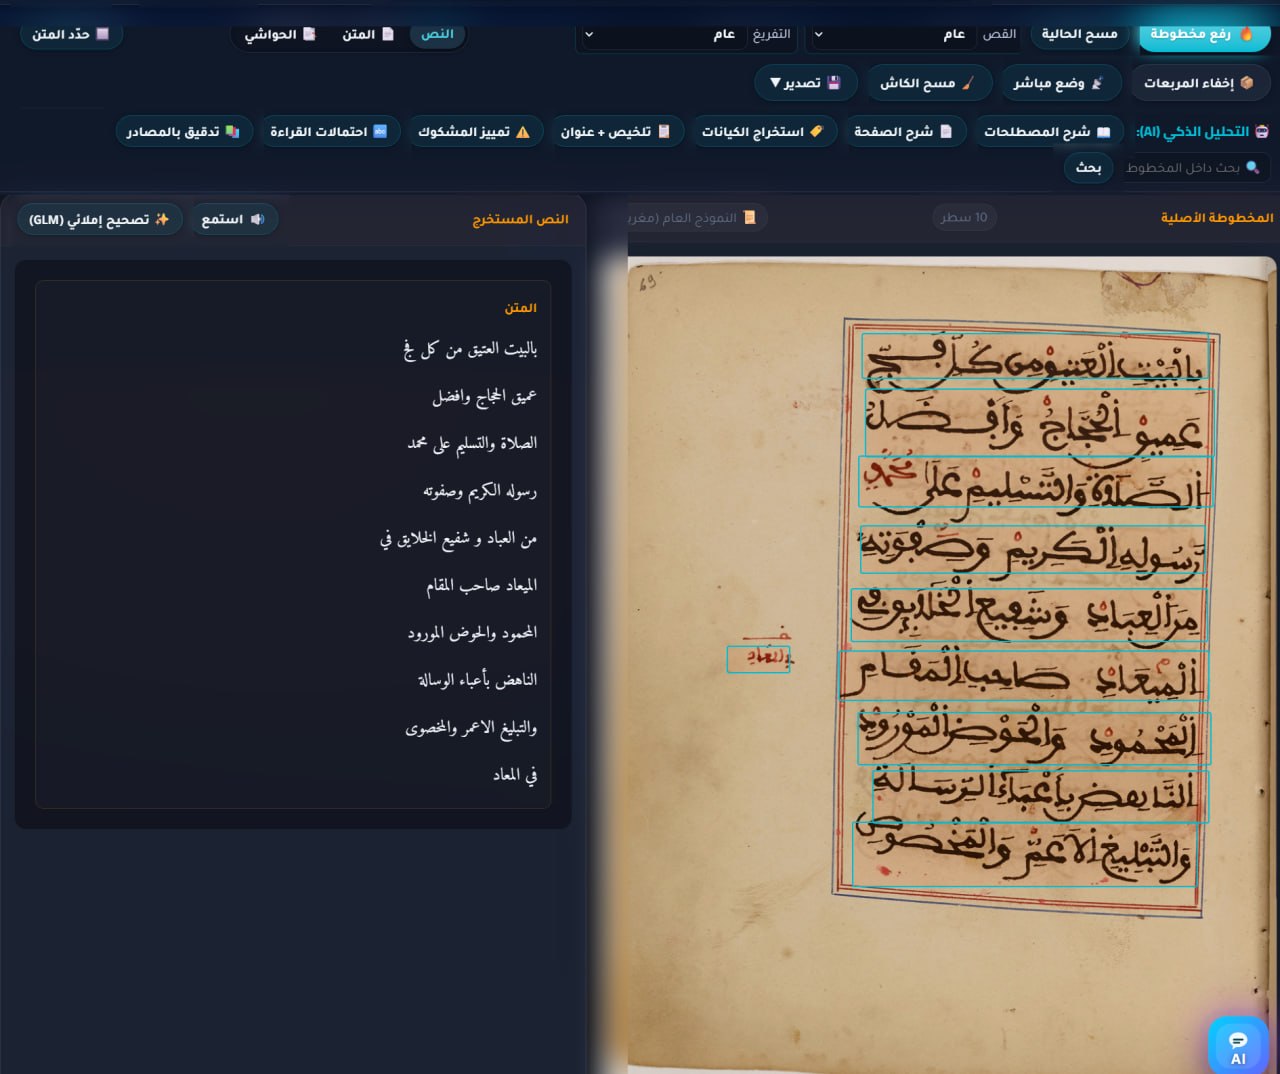
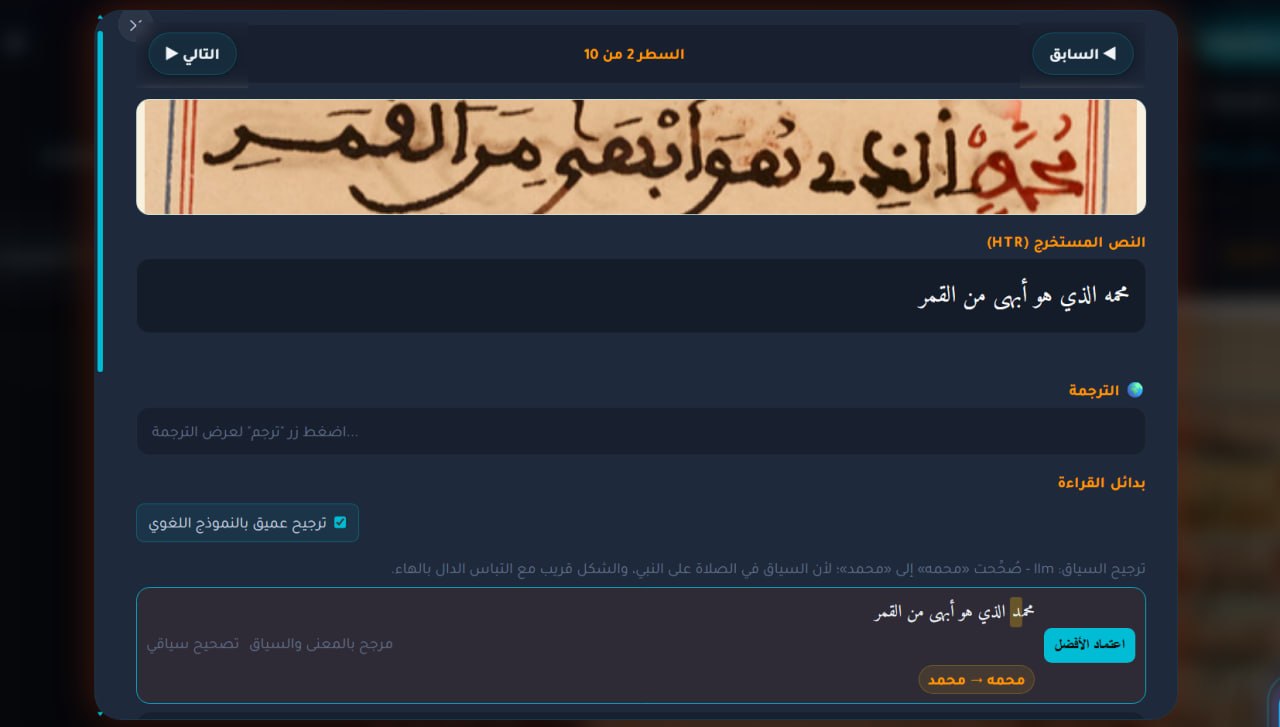
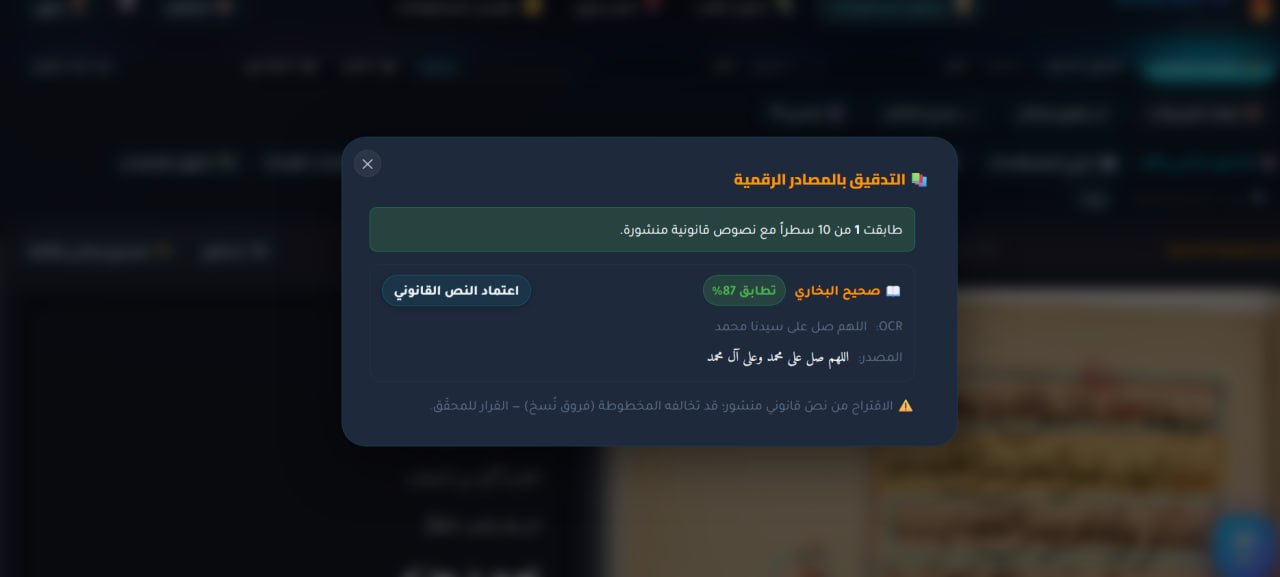
مشروع أثر هو نظام ذكي مساعد لقراءة المخطوطات العربية التاريخية ومراجعتها يجمع بين عدة طبقات ذكية تبدا من نموذج تعرّف الخط اليدوي HTR( دربناه على مجموعة اوسع من مخطوطات) ، ونموذج تجزئة تخطيط الصفحات، ونموذج لغوي مصغر موجّه لدعم التفريغ، مع أدوات مراجعة بشرية تفاعلية. يهدف المشروع إلى تحويل صور المخطوطات إلى نصوص قابلة للبحث والتحليل، مع الحفاظ على النص الأصلي وإظهار مواضع الشك والقراءات البديلة بدلاً من التصحيح الصامت. كما يدعم النظام الذكاء الاصطناعي في قراءة المخطوطات او شرحها، والتدقيق بالمصادر الرقمية مثل المكتبات الخارجية والبحث في فهارس المخطوطات مما يوفر أداة مساعدة للباحثين والمحققين في التعامل مع المخطوطات العربية المعقدة,
بيانات المشروع والفريق
الجامعةالجامعة التكنولوجية
المسار العلميمسار خدمة المجتمع
الفريقفينكس
الترتيب النهائيالمركز الرابع
التقييم النهائي89.53 / 100
المحافظةبغداد
الإشراف الأكاديمي
م
م.م. محمد ثامر عبدالهادي
المشرف الأكاديمي
أعضاء الفريق (3)
ع
علي حيدر صفاء
قائد الفريق · Bachelor
ذ
ذوالفقار مهدي وادي
Other · Bachelor
ع
عبدلله احمد علي
AI/Control · Bachelor
المركز الخامسالمسار البيئي
NURAI2026-0175
Adaptive Traffic Learning and Automation System
يتناول هذا المشروع مشكلةً جوهريةً في مجال إدارة حركة المرور الحضري. ويستند الحل المقترح إلى وكيل Double DQN مشترك مدرَّب على شبكة محاكاة مكونة من 50 ت…
الجامعة: جامعة الصفوة
الفريق: البينه
المشرف: د. احمد صالح غافل
NURAI2026-0175 · المسار البيئي
Adaptive Traffic Learning and Automation System
البينه — جامعة الصفوة
المركز الخامس
نبذة عن المشروع
يتناول هذا المشروع مشكلةً جوهريةً في مجال إدارة حركة المرور الحضري. ويستند الحل المقترح إلى وكيل Double DQN مشترك مدرَّب على شبكة محاكاة مكونة من 50 تقاطعاً، يتعلم زيادة الوقت او انقاص وقت عبور السارات بالتوافق مع الطلب المروري مع دعم تحديد أولويات سيارات الإسعاف عبر GPS، بهدف تقليل وقت انتظار السائقين والحد من الازدحام وخفض الانبعاثات الناتجة عن توقف المركبات. وتشمل النتائج تخفيض وقت انتظار السائقين بنسبة 22%، ووقت انتظار سيارات الإسعاف بنسبة 85%، ورفع معدل مرور السيارات بنسبة 7%، وخفض الازدحام الشديد بنسبة 24%، موثَّقةً عبر 48 سيناريو متطابق الطلب المروري.
بيانات المشروع والفريق
الجامعةجامعة الصفوة
المسار العلميالمسار البيئي
الفريقالبينه
الترتيب النهائيالمركز الخامس
التقييم النهائي83.80 / 100
المحافظةكربلاء
الإشراف الأكاديمي
د
د. احمد صالح غافل
المشرف الأكاديمي
أعضاء الفريق (4)
ج
جعفر تحسين حسن
قائد الفريق · Bachelor
أ
أشرقت فاطمة ماجد مغامس
Other · Bachelor
ع
علي غانم كرجي حميد
Other · Bachelor
ع
علي مرتضى احمد قاسم
Programmer · Bachelor
المركز الخامسالمسار الزراعي
NURAI2026-0595
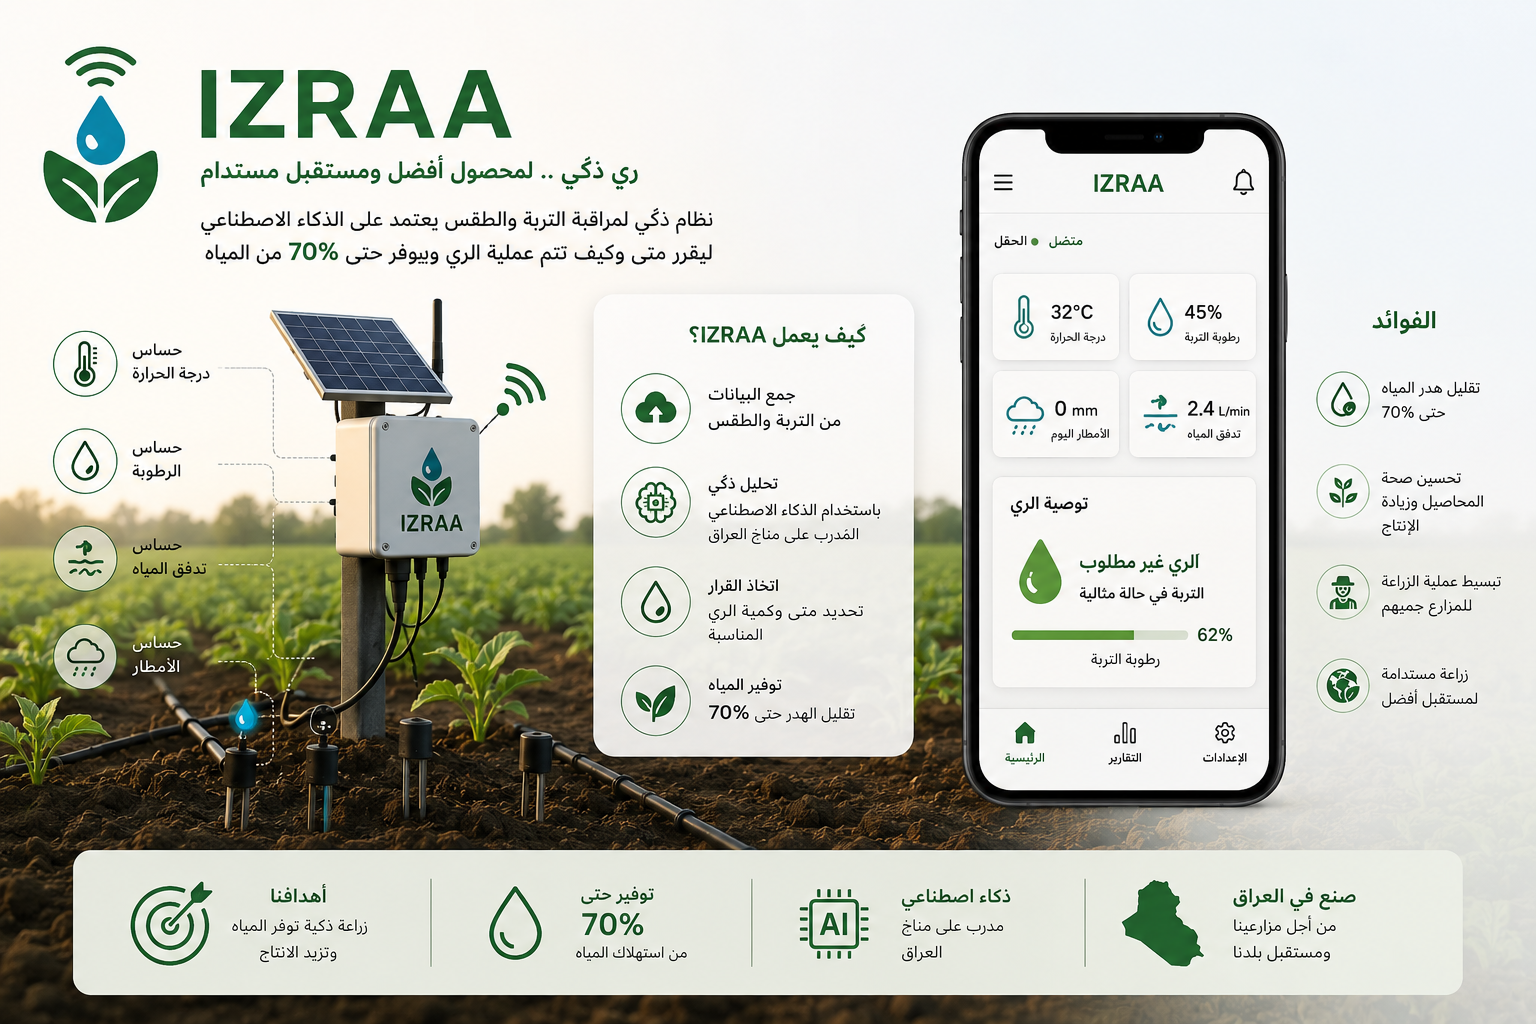
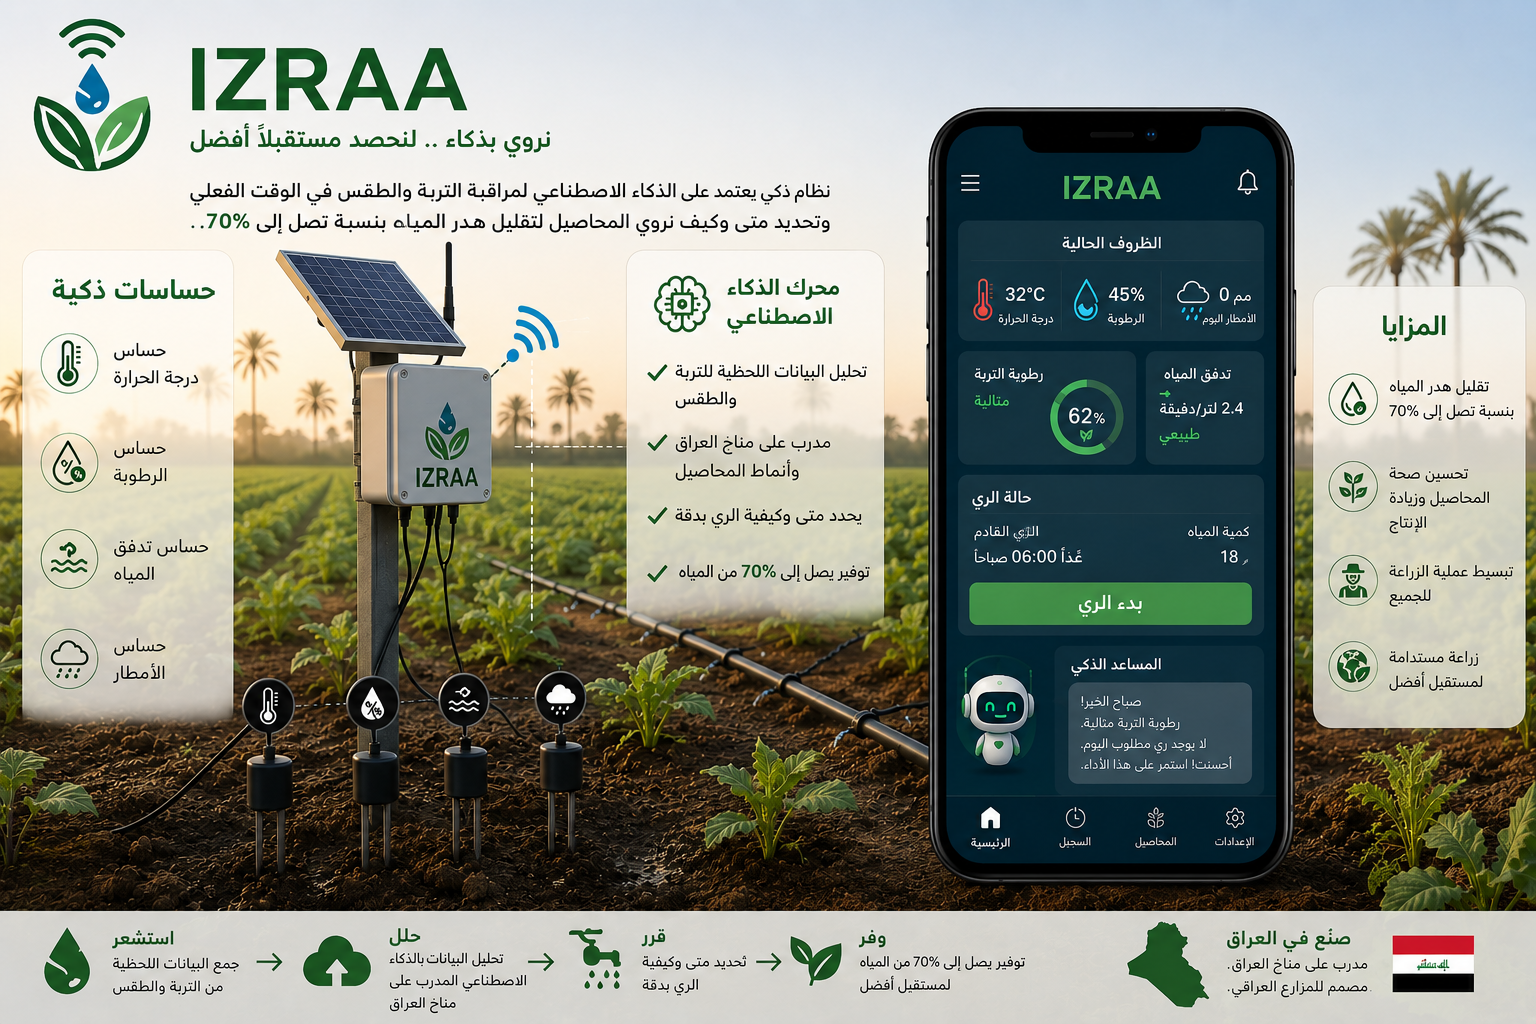
IZRAA ( ازرع )
This project addresses a significant problem in Farming, where water waste is at all times high, especially in Iraq. The proposed solution is based on…
الجامعة: الجامعة التكنولوجية
الفريق: DevSyndrome
المشرف: أ.م.د بشار سعدون مهدي
NURAI2026-0595 · المسار الزراعي
IZRAA ( ازرع )
DevSyndrome — الجامعة التكنولوجية
المركز الخامس
نبذة عن المشروع
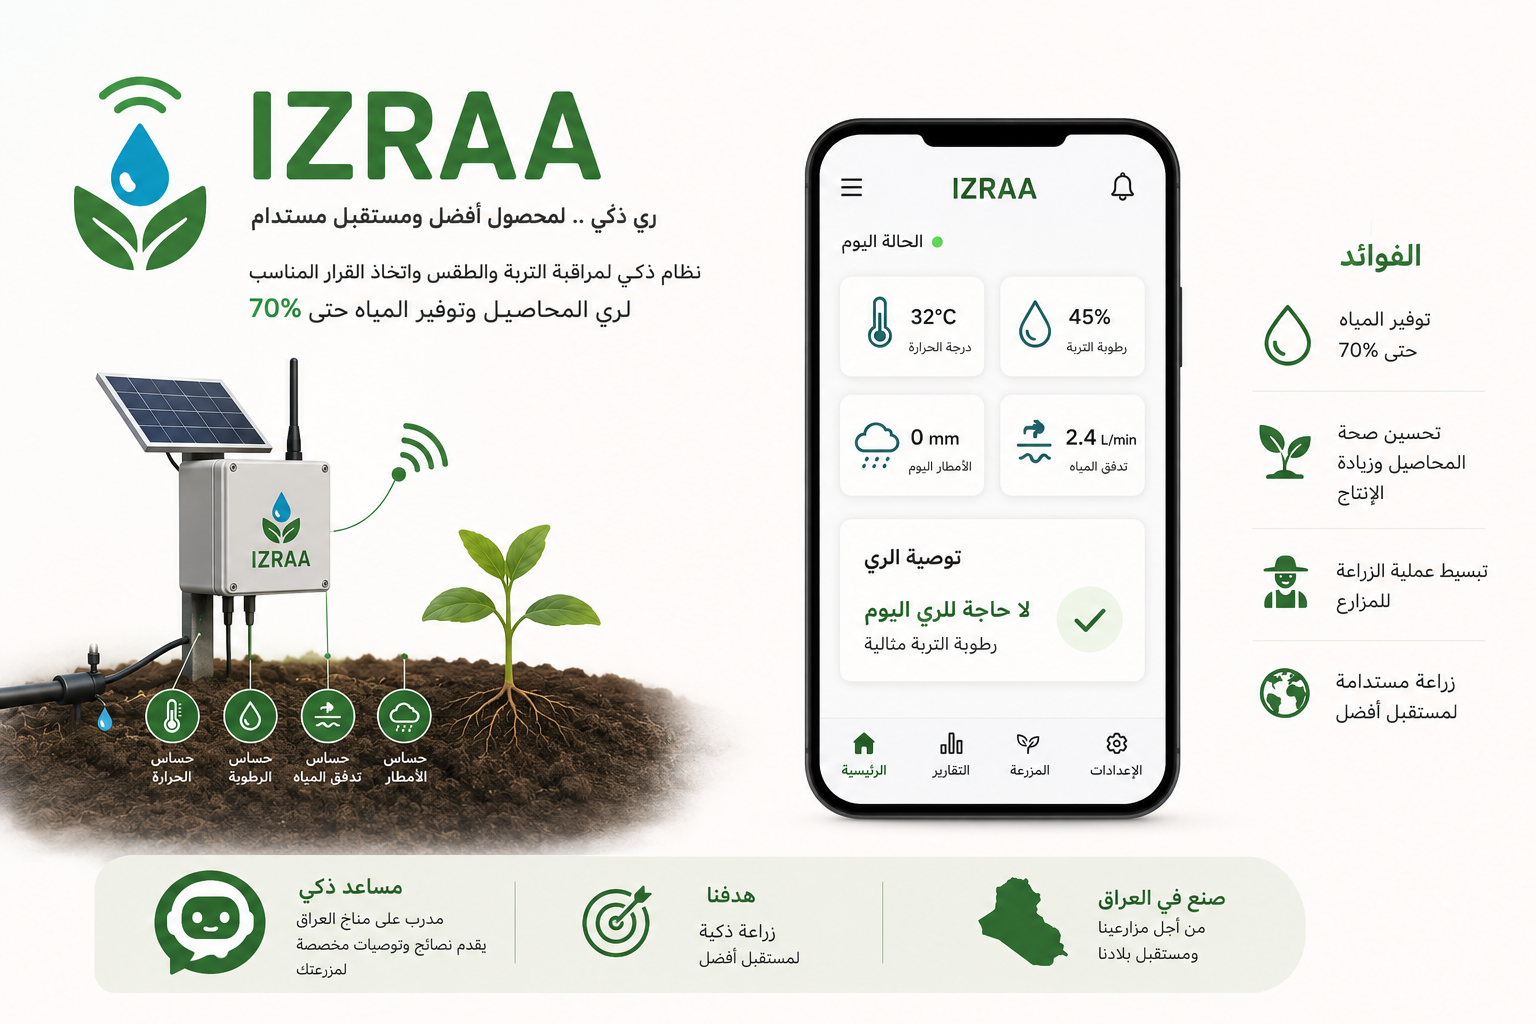
This project addresses a significant problem in Farming, where water waste is at all times high, especially in Iraq. The proposed solution is based on a hardware system that consists of a temperature sensor, humidity sensor, waterflow sensor, and rain sensor. As well as a smart software system and application that gets direct live information from the soil activity via the sensors, and decides when to water the crops and how much water to spend, with the aim of lowering water waste. Additionally, the application has a smart AI assistant that is trained on Iraqi climate. The expected outcomes include, simplifying the farming process for farmers, especially amateurs. On the other hand, it will in high hopes help reduce water waste by up to 70% when it comes to the farming industry.
بيانات المشروع والفريق
الجامعةالجامعة التكنولوجية
المسار العلميالمسار الزراعي
الفريقDevSyndrome
الترتيب النهائيالمركز الخامس
التقييم النهائي86.07 / 100
المحافظةبغداد
الإشراف الأكاديمي
أ
أ.م.د بشار سعدون مهدي
المشرف الأكاديمي
أعضاء الفريق (5)
ح
حسن علي عيسى صاحب
قائد الفريق · Bachelor
آ
آمنة محمد أسد الغريفي
Programmer · Bachelor
م
مصطفى علي عيسى
Electronics · Bachelor
ن
نور غالب عبدالزهرة جاسم
Programmer · Bachelor
ي
ياسر وسام محمد حسن
AI/Control · Bachelor
المركز الخامسالمسار الصناعي
NURAI2026-0239
Autonomous Video-to-Shorts Generation and Publishing System
منصة تعمل كوكيل ذكاء اصطناعي (AI Agent) لأتمتة الإنتاج الإعلامي بالكامل. يقوم النظام بتحليل الفيديوهات الطويلة وتحويلها آلياً إلى مقاطع سياقية (قصيرة …
الجامعة: جامعة العين العراقية
الفريق: فريق التقنية للنصر
المشرف: علي عدنان اثغيب
NURAI2026-0239 · المسار الصناعي
Autonomous Video-to-Shorts Generation and Publishing System
فريق التقنية للنصر — جامعة العين العراقية
المركز الخامس
نبذة عن المشروع
منصة تعمل كوكيل ذكاء اصطناعي (AI Agent) لأتمتة الإنتاج الإعلامي بالكامل. يقوم النظام بتحليل الفيديوهات الطويلة وتحويلها آلياً إلى مقاطع سياقية (قصيرة ومتوسطة)، مع توليد الصور المصغرة والعناوين المحسّنة (SEO). تتم جميع عمليات المعالجة والمونتاج عبر سيرفرات سحابية، لينتهي الأمر بنشر وجدولة المحتوى فورياً على أكثر من 8 منصات تواصل اجتماعي من خلال لوحة تحكم مركزية، مما يختصر عمل فريق كامل بضغطة زر.
بيانات المشروع والفريق
الجامعةجامعة العين العراقية
المسار العلميالمسار الصناعي
الفريقفريق التقنية للنصر
الترتيب النهائيالمركز الخامس
التقييم النهائي82.80 / 100
المحافظةذي قار
الإشراف الأكاديمي
ع
علي عدنان اثغيب
المشرف الأكاديمي
أعضاء الفريق (3)
ع
علي طالب محسن حمود
قائد الفريق · Bachelor
ع
عباس عبدالوهاب صبري
Other · Bachelor
م
مصطفى طالب محسن حمود
Other · Bachelor
المركز الخامس مكررالمسار الصناعي
NURAI2026-0888
GeoString An End-to-End Automated String Art Generation and Physical Fabrication Platform Based on Greedy Image Processing and Arduino-Microcontroller
This paper presents a design and implementation of Geostring, an end-to-end automated string-art platform that converts any digital photograph into a …
الجامعة: الجامعة التقنية الشمالية
الفريق: مهندسو الاوتار
المشرف: مفاز يحيى ضمرة
NURAI2026-0888 · المسار الصناعي
GeoString An End-to-End Automated String Art Generation and Physical Fabrication Platform Based on Greedy Image Processing and Arduino-Microcontroller
مهندسو الاوتار — الجامعة التقنية الشمالية
المركز الخامس مكرر
نبذة عن المشروع
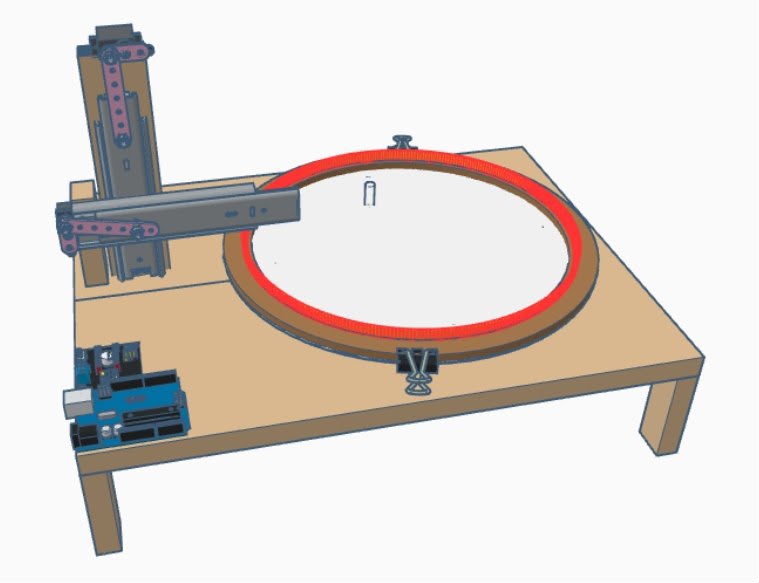
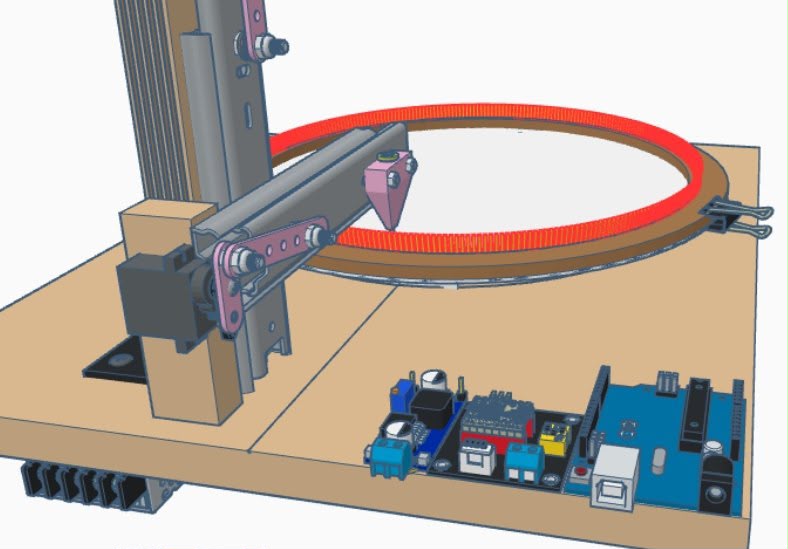
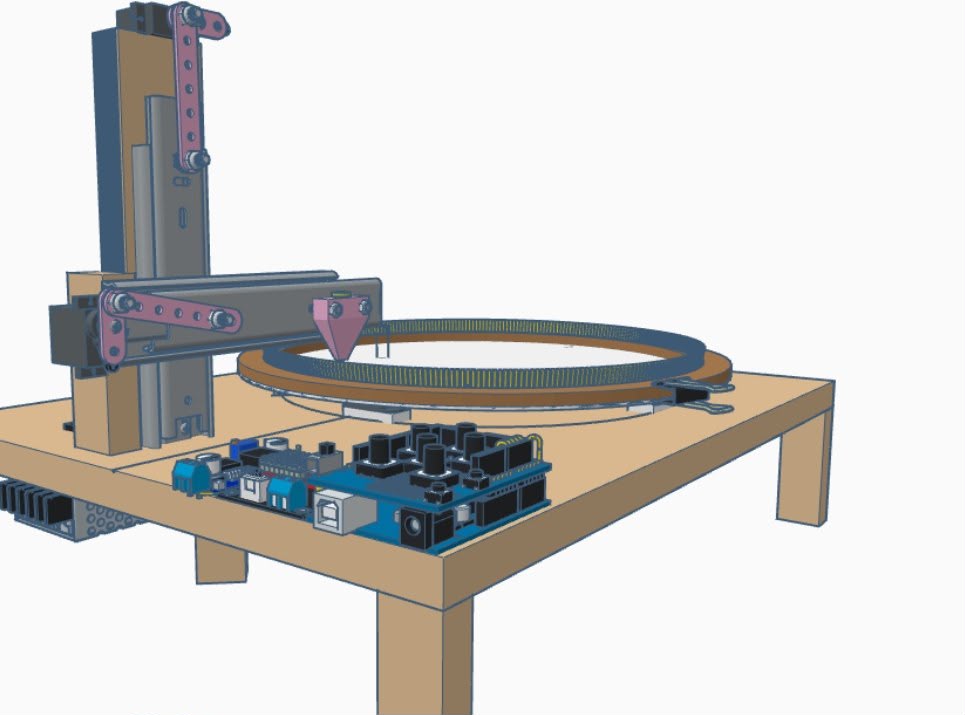
This paper presents a design and implementation of Geostring, an end-to-end automated string-art platform that converts any digital photograph into a physical artwork composed of a single continuous thread wound around a circular nail frame. The system comprises three integrated components: an interactive web-based 2D generator employing a greedy chord-selection algorithm in polar coordinates, a live Three.js-based 3D mechanical simulator, and an AI-assisted parameter tuning assistant. The physical drawing machine is built around an Arduino UNO R3 running GRBL firmware, two NEMA 17 stepper motors driven by TMC2225 silent drivers, and a GT2 belt-driven linear arm operating over a 290 mm rotating disc. The greedy algorithm iteratively selects the nail-to-nail chord that maximally reduces the residual image darkness, producing sequences of up to 8,000 chords. Experimental evaluation confirms a disc positioning accuracy of 0.08° mean error, thread-shuttle repeatability of ±0.15 mm, and successful autonomous artwork production. The platform bridges computational art with physical mechatronic fabrication, providing an open, modular, and affordable system applicable to engineering education, creative technology, and intelligent automation research.project addresses a significant problem in (mention the field or domain). The proposed solution is based on (briefly describe the idea or technology) with the aim of (state the main objective). The expected outcomes include (summarize the anticipated results or impact).
بيانات المشروع والفريق
الجامعةالجامعة التقنية الشمالية
المسار العلميالمسار الصناعي
الفريقمهندسو الاوتار
الترتيب النهائيالمركز الخامس مكرر
التقييم النهائي82.80 / 100
المحافظةنينوى
الإشراف الأكاديمي
م
مفاز يحيى ضمرة
المشرف الأكاديمي
أعضاء الفريق (4)
ث
ثابت حسان سالم
قائد الفريق · Bachelor
س
سالي احمد سعيد
Other · Bachelor
ع
عبد الله عمار علي
Other · Bachelor
ك
كوكب معن صالح
Other · Bachelor
المركز الخامسالمسار الطبي
NURAI2026-0814
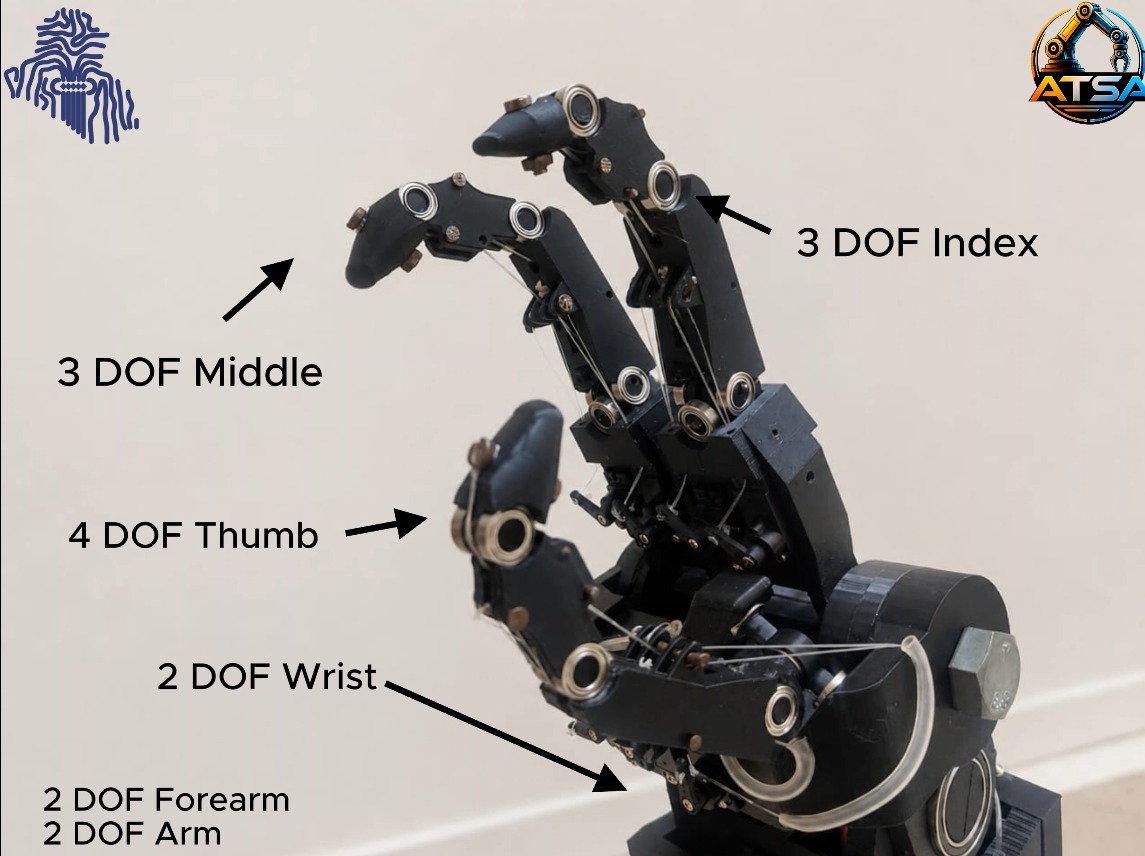
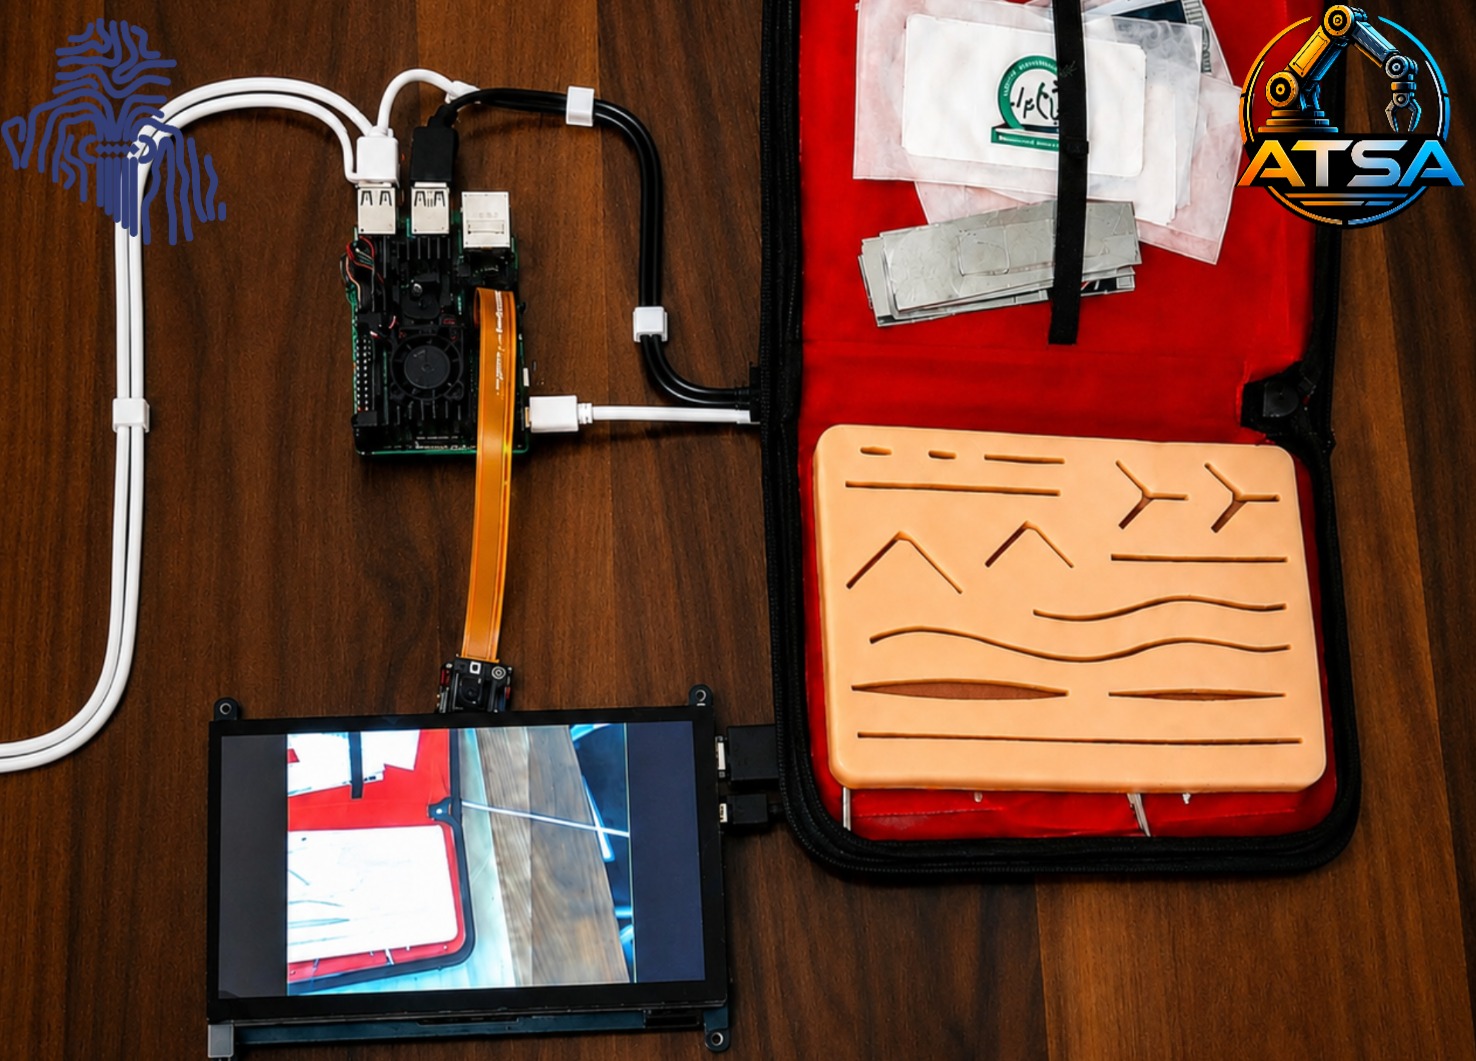
Augmented Teleoperation Surgical Arm (ATSA)
يتناول هذا المشروع مشكلة جوهرية في الجراحة المعتمدة على التشغيل عن بعد, حيث تؤثر الرعشات الفسيولوجية لليد لدى الجراح في مستوى الدقة اثناء اداء الاجراء…
الجامعة: جامعة نينوى
الفريق: فريق ATSA روبوت جراحي مدعم بالذكاء الاصطناعي
المشرف: دينا نمير عبدالجبار
NURAI2026-0814 · المسار الطبي
Augmented Teleoperation Surgical Arm (ATSA)
فريق ATSA روبوت جراحي مدعم بالذكاء الاصطناعي — جامعة نينوى
المركز الخامس
نبذة عن المشروع
يتناول هذا المشروع مشكلة جوهرية في الجراحة المعتمدة على التشغيل عن بعد, حيث تؤثر الرعشات الفسيولوجية لليد لدى الجراح في مستوى الدقة اثناء اداء الاجراءات الجراحية ضمن بيئة تشغيلية تفتقر الى الارشاد. ويستند الحل المقترح الى نظام الذراع الجراحية المعززة بالتشغيل عن بعد ( ATSA) والذي يهدف الى دمج بيئة جراحية مدعومة بالرؤية الحاسوبية من خلال اسقاط مسارات بصرية مثلى على الاهداف الجراحية,الى جانب تطبيق خوارزميات ( Kalman Filter ) بصورة انية لتصحيح الاضطرابات الحركية. ويستند الحل المقترح الى تحقيق كبت كامل للرعشات, وتعزيز الدقة في تنفيذ العمليات الجراحية , اضافة الى توفير اطار عمل موثوق يمهد لتطوير انظمة خياطه جراحية ذاتية التشغيل.
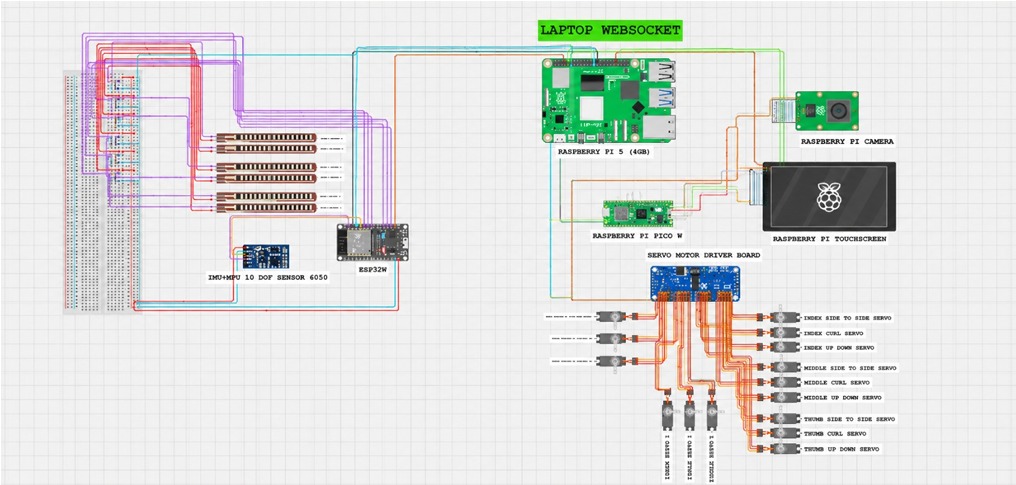
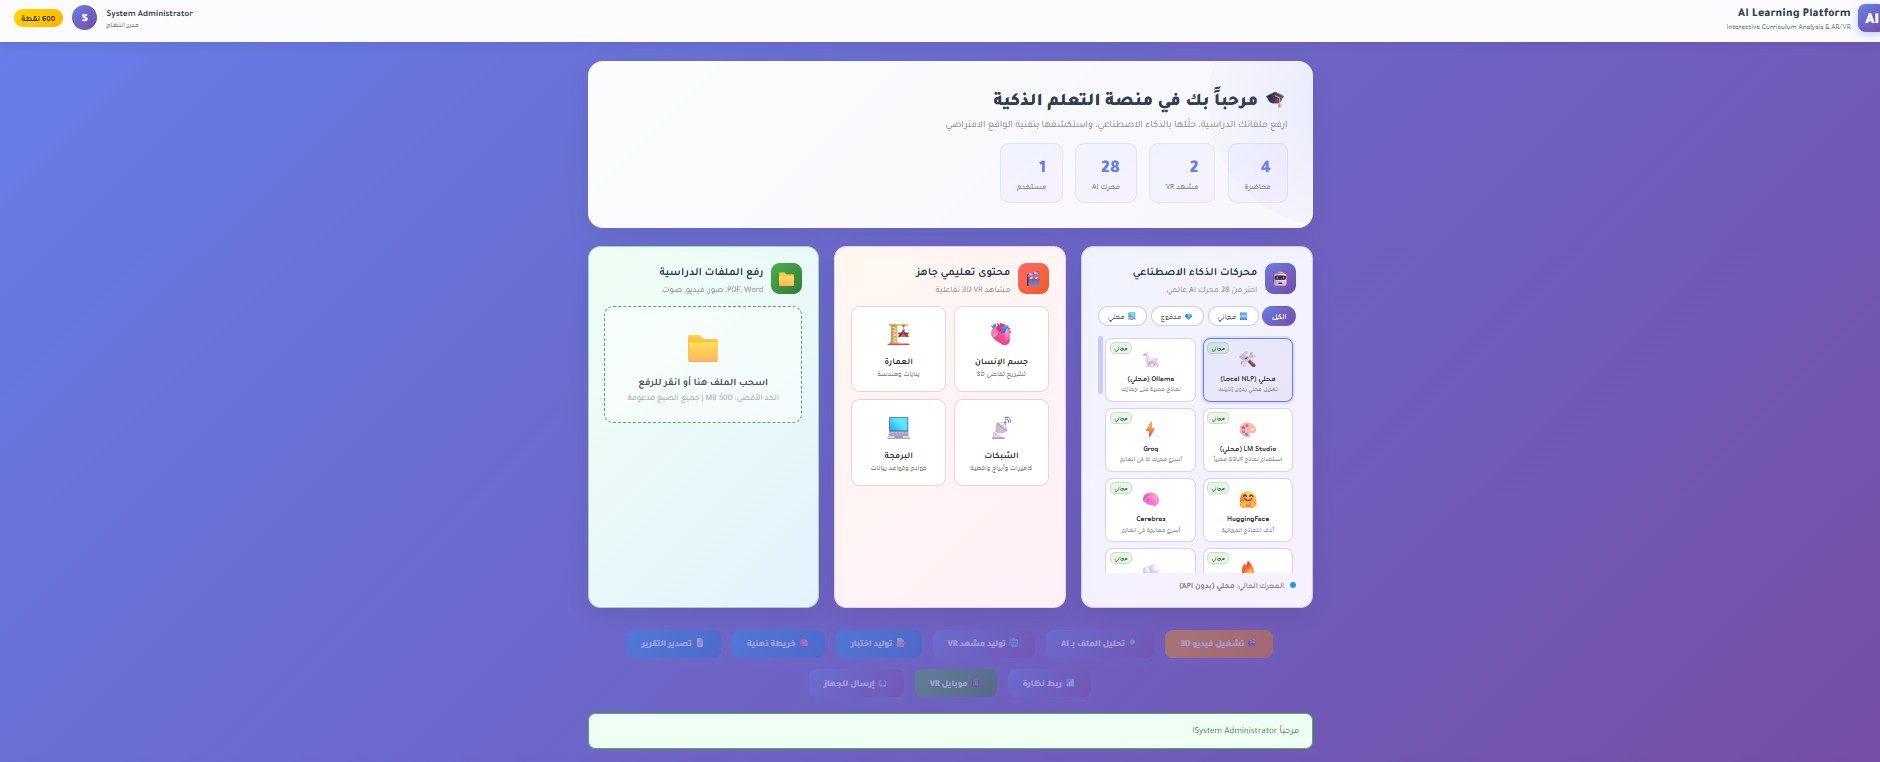
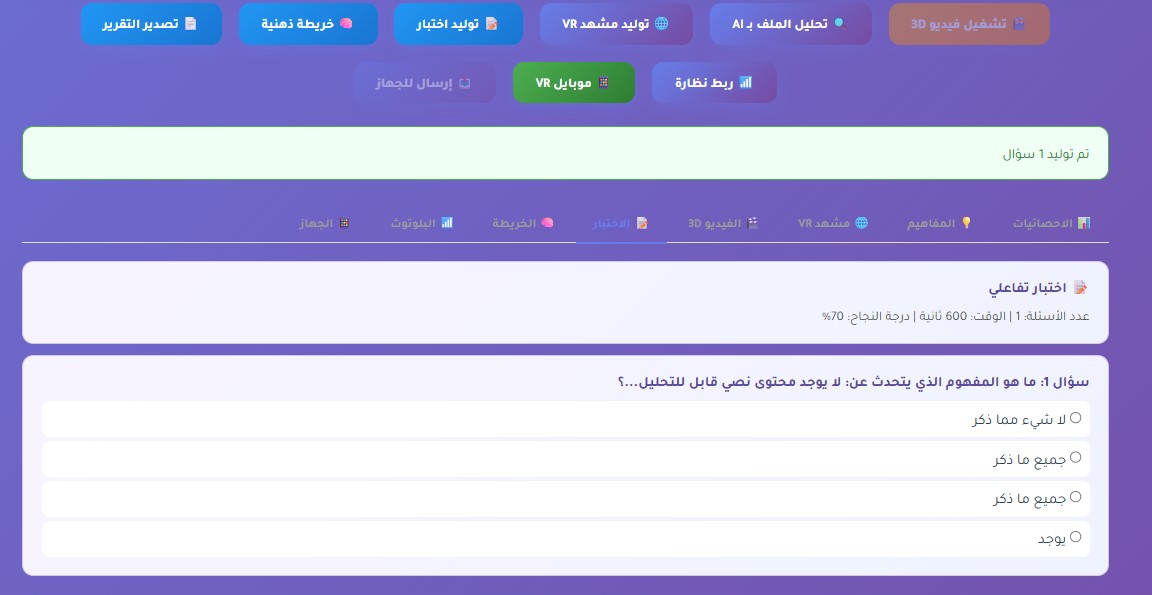
Design And Implementation Of An AI-Powered Interactive Learning Platform For Curriculum Analysis And AR/VR Content Generation
This project tackles the challenges in EdTech and immersive learning, where abstract concepts can prove hard to comprehend as traditional educational …
الجامعة: جامعة الموصل
الفريق: مبرمجون بلا حدود
المشرف: د. شيماء مصطفى محي الدين
NURAI2026-0552 · مسار التربية والتعليم
Design And Implementation Of An AI-Powered Interactive Learning Platform For Curriculum Analysis And AR/VR Content Generation
مبرمجون بلا حدود — جامعة الموصل
المركز الخامس
نبذة عن المشروع
This project tackles the challenges in EdTech and immersive learning, where abstract concepts can prove hard to comprehend as traditional educational materials predominantly use static text and two-dimensional illustrations. The project designs and implements an AI-powered interactive learning platform that automatically converts traditional educational material into experiential learning experiences. It accepts a wide variety of input types, such as PDF, DOCX, PowerPoint presentations and images (which can be in file or image formats), videos and text documents. Mix AI$ and models include OpenAI GPT, Google Gemini, Anthropic Claude, DeepSeek (an engine that is built specifically for the curriculum context), local NPL china's framework to analyze content of each unit in the subjects as a learning bot which learns from your resources ($881.10 quarterly) These resources are split from formative multiple-choice questions (MCQs) to AI-generated mind maps and interactive learning environment through Augmented Reality, Web-based Virtual Reality (WebVR - A-Frame). The graceful degradation of the multi-engine AI architecture, which is proposed in this work, could improve reliability and privacy with installation method because integrated system may detect failure in cloud service usage capability and still also be operational for critical timely operation requirement. Experimental Implementation The proposed solution was successfully validated as an automated curriculum analysis, concept extraction and 3D learning content generation without manually generating the 3D content [7]. The platform also allows for shorter preparation time required of instructors, greater interaction and engagement as well as conceptual understanding through more immersive experiences when compared to traditional ways of teaching. Assimilation of Artificial intelligence with Augmented and Virtual Reality solutions provides a flexible and optimal answer for postmodern modern-day digital education & supports the inherent pressure to implement technology-enabled learning environments .
بيانات المشروع والفريق
الجامعةجامعة الموصل
المسار العلميمسار التربية والتعليم
الفريقمبرمجون بلا حدود
الترتيب النهائيالمركز الخامس
التقييم النهائي80.27 / 100
المحافظةنينوى
الإشراف الأكاديمي
د
د. شيماء مصطفى محي الدين
المشرف الأكاديمي
أعضاء الفريق (4)
ع
عمر سعد علي حسين
قائد الفريق · Bachelor
ز
زيد مهند غانم
Electronics · Bachelor
ع
عبدالرحمن صباح سعدي
AI/Control · Bachelor
ع
عبدالعزيز عمر سعيد
Programmer · Bachelor
المركز الخامسمسار خدمة المجتمع
NURAI2026-0587
AI-Based Autonomous Fire Detection and Drone Suppression with Smart Docking for Large Facilities
The project presents an AI-based autonomous fire detection and extinguishing system designed to enhance rapid response to fire incidents. The system u…
الجامعة: الجامعة التكنولوجية
الفريق: innovation
المشرف: د.علي جبار داوود
NURAI2026-0587 · مسار خدمة المجتمع
AI-Based Autonomous Fire Detection and Drone Suppression with Smart Docking for Large Facilities
innovation — الجامعة التكنولوجية
المركز الخامس
نبذة عن المشروع
The project presents an AI-based autonomous fire detection and extinguishing system designed to enhance rapid response to fire incidents. The system utilizes computers. vision algorithms integrated with surveillance cameras to detect fire in real time. Once a fire is identified, an autonomous drone is deployed to the exact location of the detected event. The drone performs additional onboard visual analysis to precisely locate the fire source. Upon confirmation, a servo-actuated mechanism activates a fire extinguisher to suppress the fire efficiently. This approach aims to reduce response time, minimize human risk, and improve fire control in hazardous or challenging-to-reach environments.
بيانات المشروع والفريق
الجامعةالجامعة التكنولوجية
المسار العلميمسار خدمة المجتمع
الفريقinnovation
الترتيب النهائيالمركز الخامس
التقييم النهائي84.27 / 100
المحافظةبغداد
الإشراف الأكاديمي
د
د.علي جبار داوود
المشرف الأكاديمي
أ
أ.م.د. عدي شاكر هادي
المشرف المشارك
أعضاء الفريق (4)
ر
رضا وسام حسن
قائد الفريق · Bachelor
ع
عقيل ابراهيم نزر
Programmer · Bachelor
م
محمد فرحان كاظم
Other · Bachelor
ح
حسين علي كاظم
Other · Bachelor
لا توجد مشاريع مطابقة للبحث
جرّب تغيير كلمة البحث أو إعادة ضبط الفلاتر لعرض جميع المشاريع الفائزة.
 المركز الأول
المسار الزراعي