AI Image Forgery Detection with a Cybersecurity Shield
The rapid advancement of Artificial Intelligence (AI) has significantly enhanced the ability to generate highly realistic synthetic images, creating serious challenges for cybersecurity, digital …
الفريق
AI Image Forgery Detection with a Cybersecurity Shield
رمز الفريق
NURAI2026-0970
المشرف
ا.م.د. نور ثامر
قراءة الوصف الكامل للمشروع
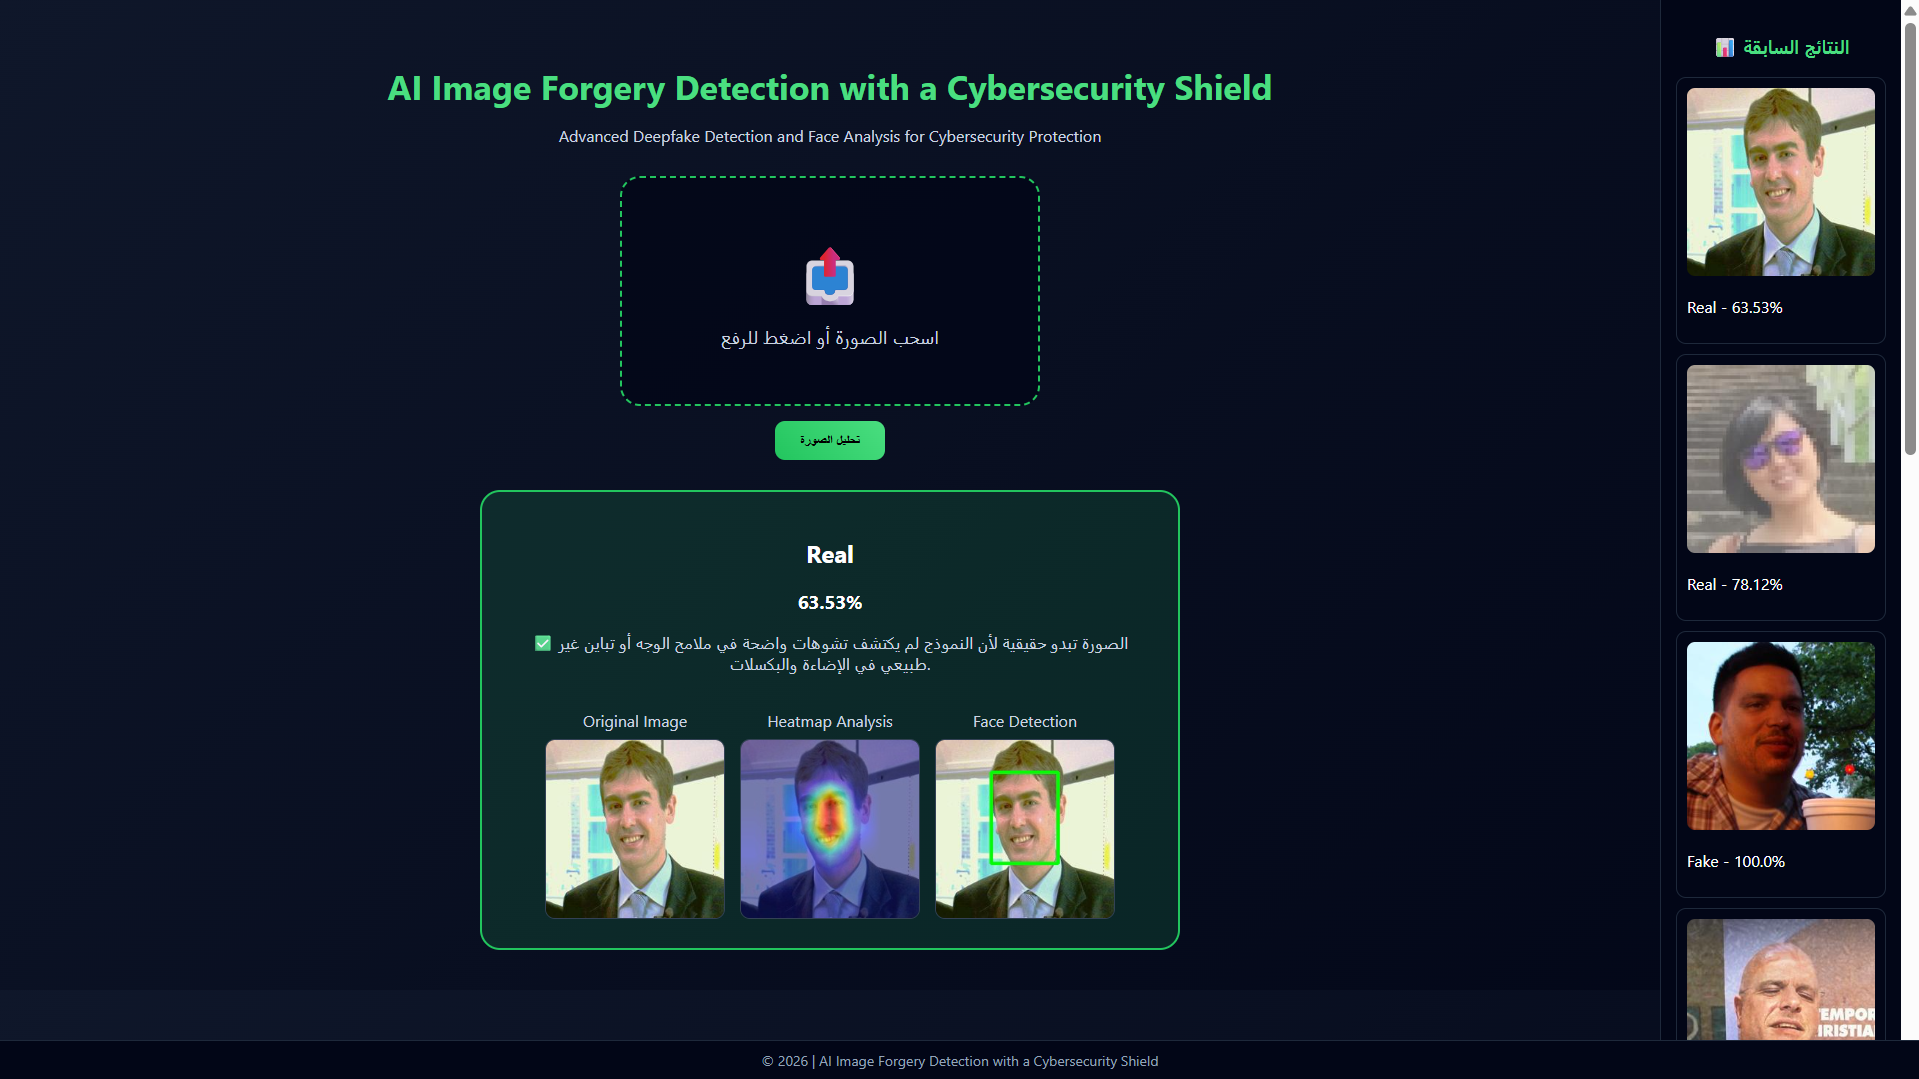
The rapid advancement of Artificial Intelligence (AI) has significantly enhanced the ability to generate highly realistic synthetic images, creating serious challenges for cybersecurity, digital forensics, and media authenticity verification. As AI-generated images become increasingly convincing, distinguishing manipulated content from authentic images has become a complex task that requires intelligent and reliable detection techniques.
This research presents an advanced AI-powered image forgery detection framework that combines customized transfer learning with deep learning to accurately identify forged facial images. Unlike conventional approaches that directly employ pretrained convolutional neural networks, the proposed framework customizes the EfficientNet architecture by replacing the original ImageNet classification head with a task-specific binary classifier and selectively fine-tuning higher network layers to enhance forgery-specific feature learning while preserving the generalized visual knowledge acquired during pretraining.
To improve model robustness and generalization capability, a comprehensive preprocessing pipeline incorporating facial image preprocessing and data augmentation techniques is employed. The training process is further optimized using the AdamW optimizer, adaptive learning rate scheduling, and Early Stopping to accelerate convergence, prevent overfitting, and improve overall predictive performance. The best-performing model is automatically selected according to validation performance before being evaluated on a completely independent testing dataset to ensure scientifically reliable performance estimation.
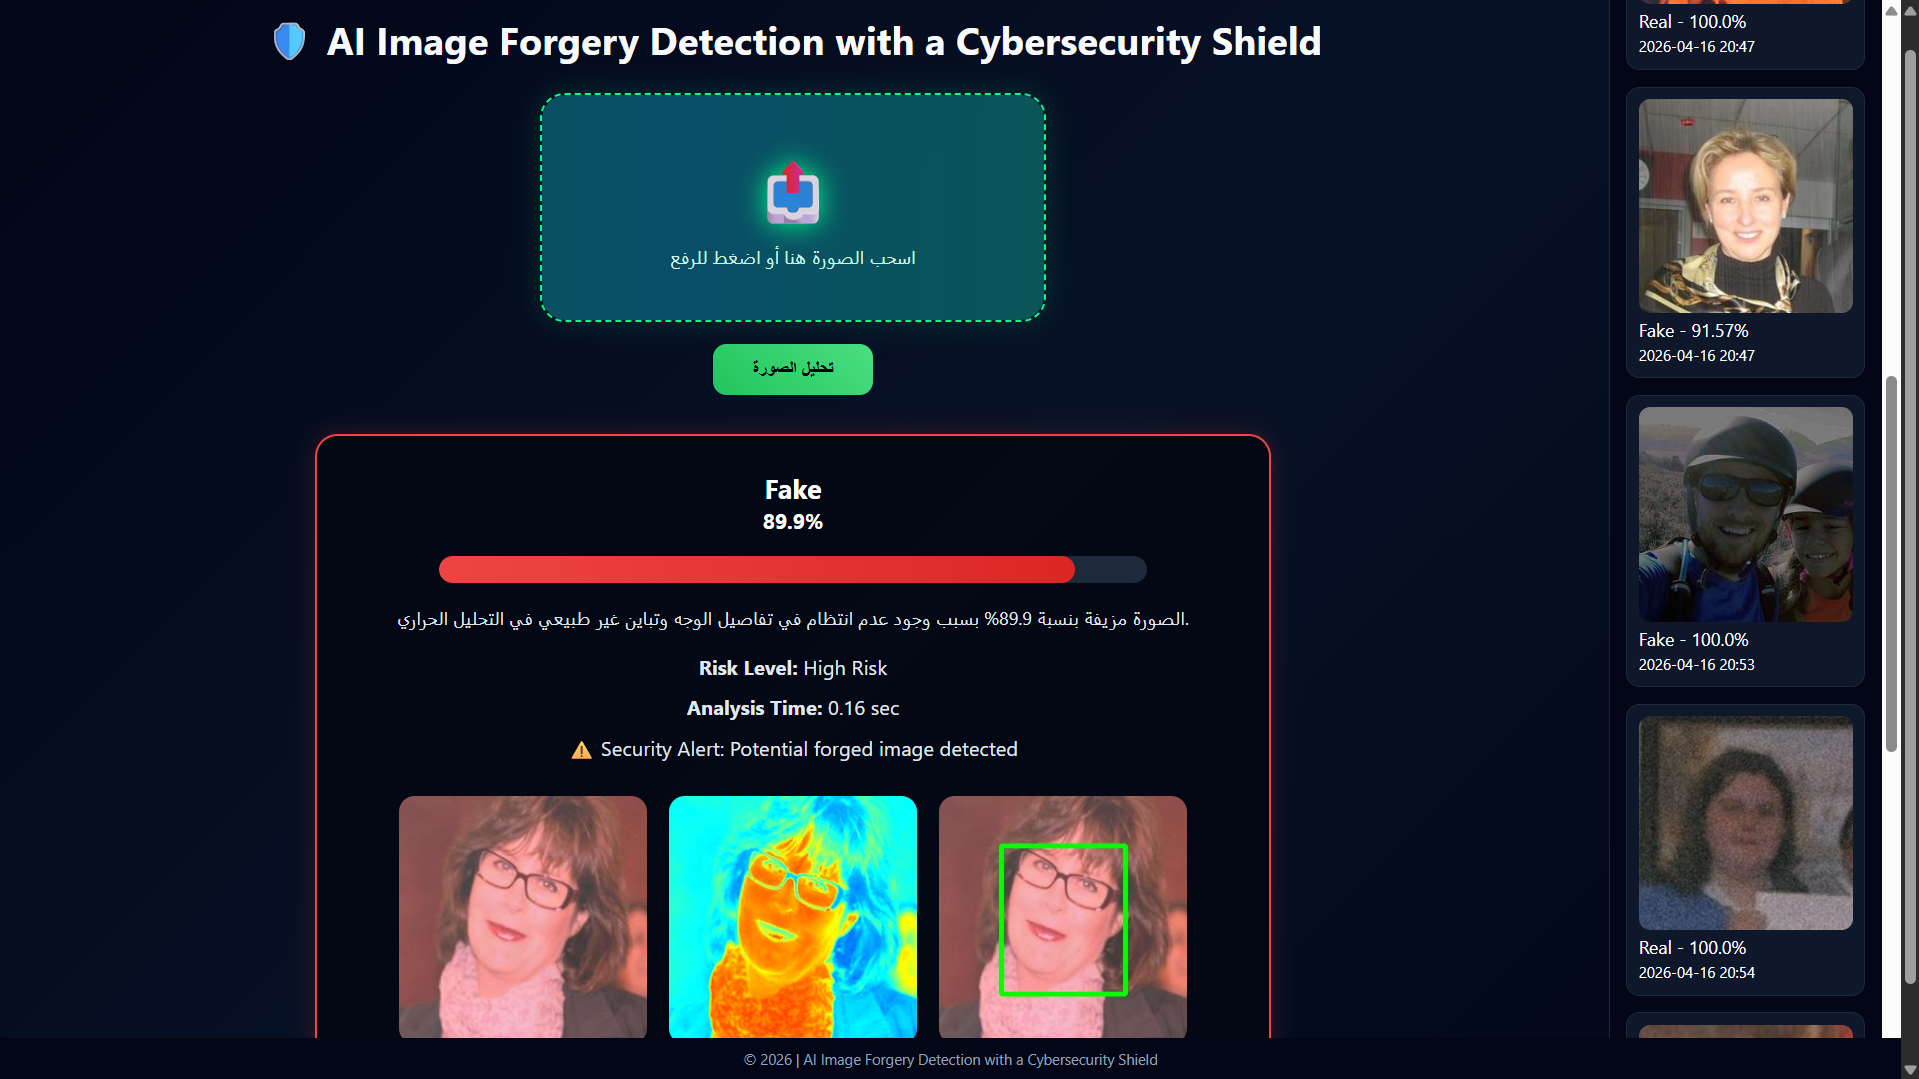
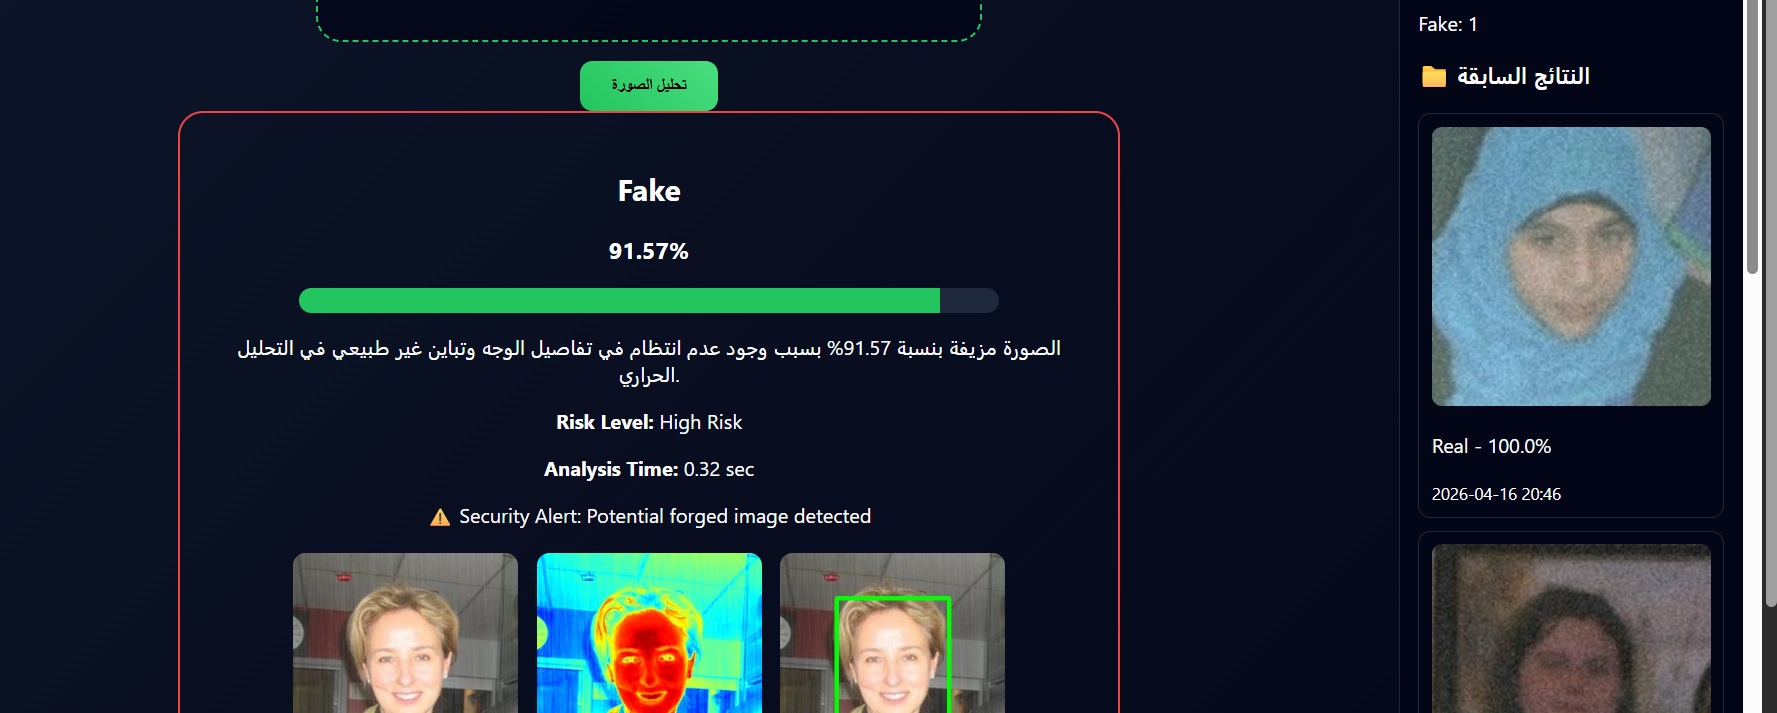
Beyond achieving high classification accuracy, the proposed framework has been deployed as a Flask-based web application, enabling practical real-time image authenticity verification through an intuitive user interface. Furthermore, Explainable Artificial Intelligence (XAI) techniques are incorporated to provide visual interpretation of the model's predictions, improving transparency and user confidence during decision-making.
The proposed framework offers an effective combination of accuracy, computational efficiency, scalability, and practical applicability, making it a promising solution for cybersecurity systems, digital forensic investigations, media authentication, and intelligent digital content protection against emerging AI-generated image manipulation techniques.
مسار خدمة المجتمع
AI-Driven Aerial Surveillance for Drone Detection and Tracking Using YOLOv8
This project addresses a significant problem in the field of aerial security and surveillance: the accurate discrimination between safe airborne objects (birds and civil aircraft) and potential s…
الفريق
فريق الراصد
رمز الفريق
NURAI2026-0346
المشرف
م.د. فائق صبار
قراءة الوصف الكامل للمشروع
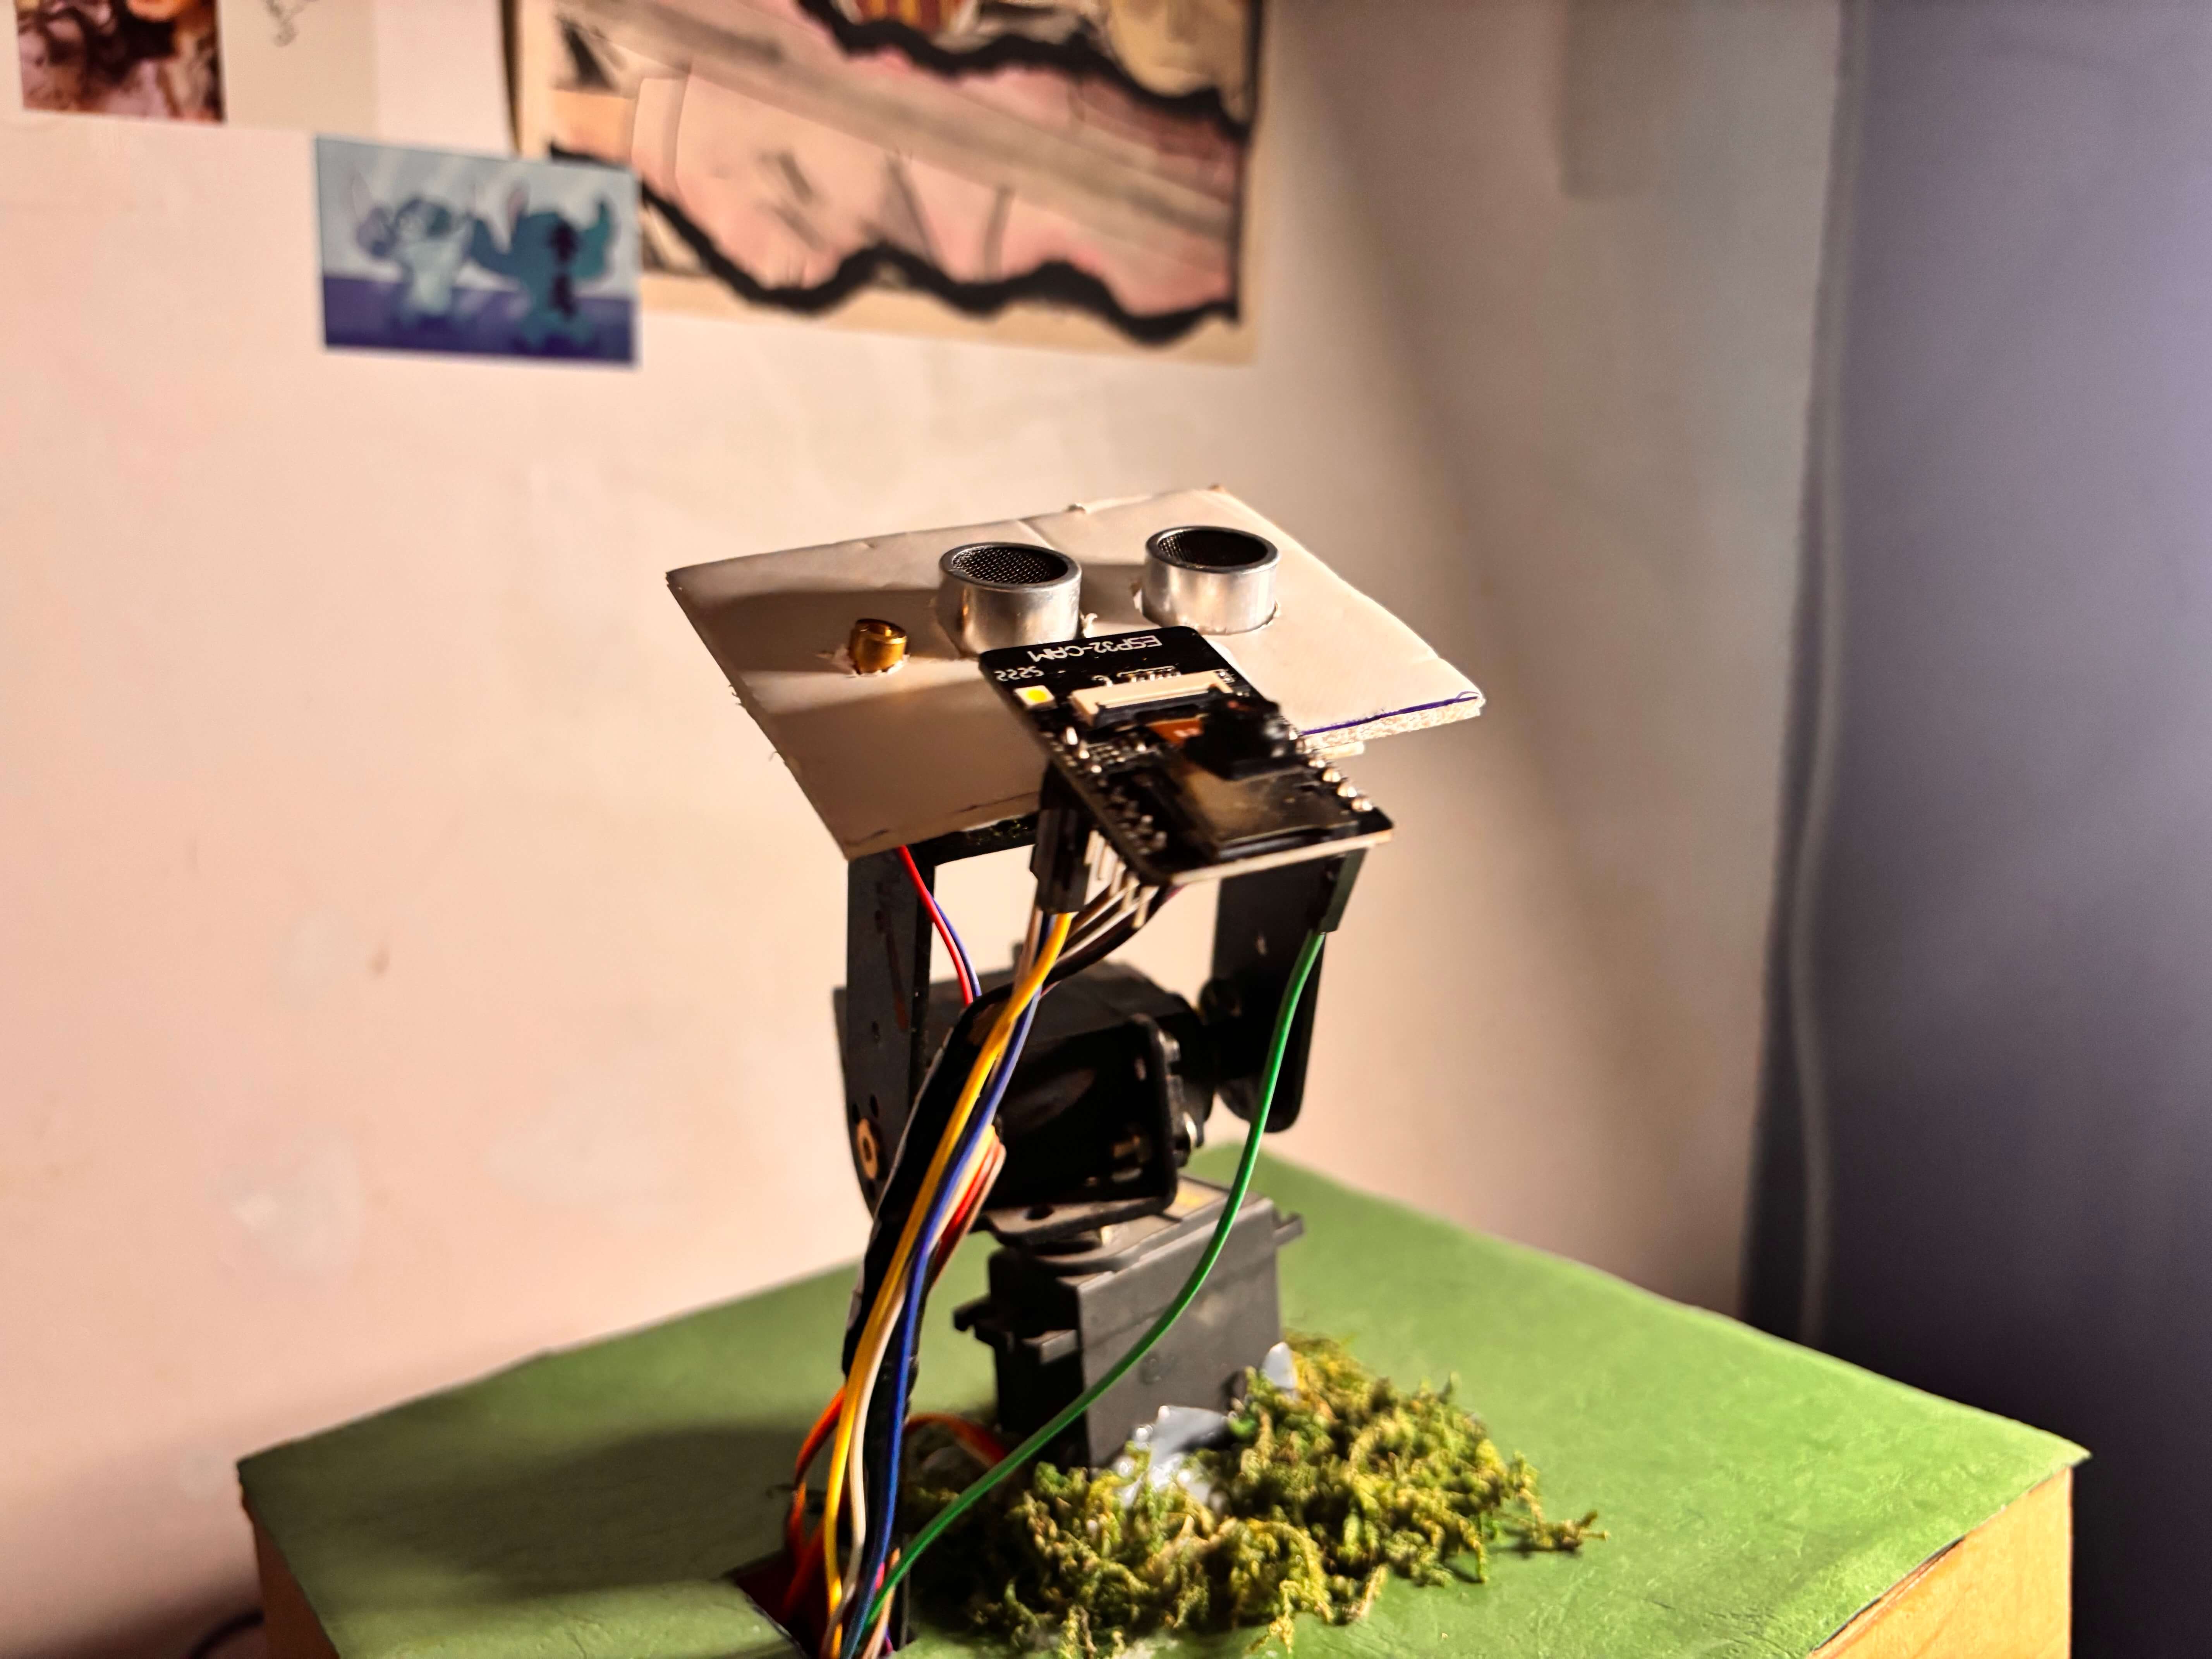
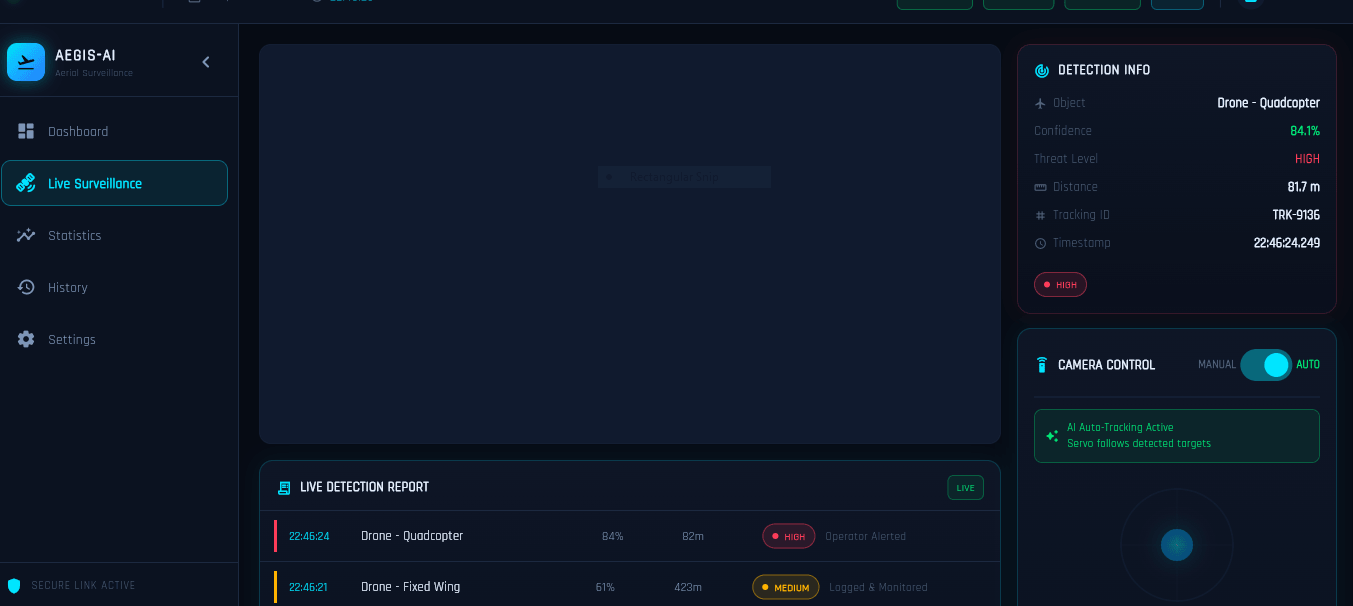
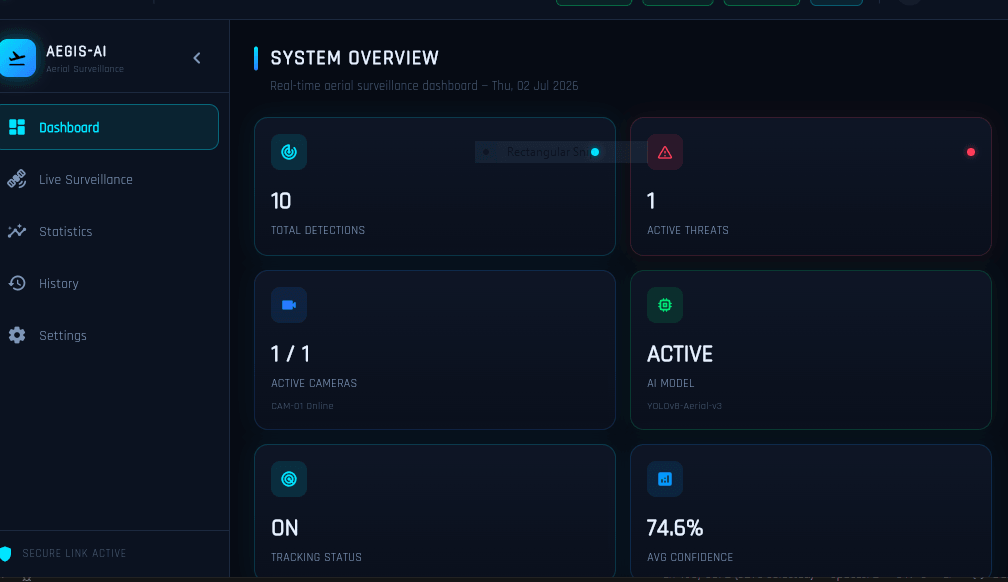
This project addresses a significant problem in the field of aerial security and surveillance: the accurate discrimination between safe airborne objects (birds and civil aircraft) and potential security threats (drones)
المسار الصناعي
Design and Implementation of Multipurpose Smart Wheeled Mobile Robot for Operation in Complex Environments
هذا المشروع يقدم تصميم وتصنيع وتنفيذ روبوت متحرك ذو قيادة تفاضلية (Differential Drive Wheeled Mobile Robot - DDWMR) قادر على أداء مهام الملاحة الذاتية والتحكم عن بُعد. يعتمد النظام المقترح على دم…
الفريق
فريق المستنصرية
رمز الفريق
NURAI2026-0354
المشرف
د. صلاح مهدي سوادي
قراءة الوصف الكامل للمشروع
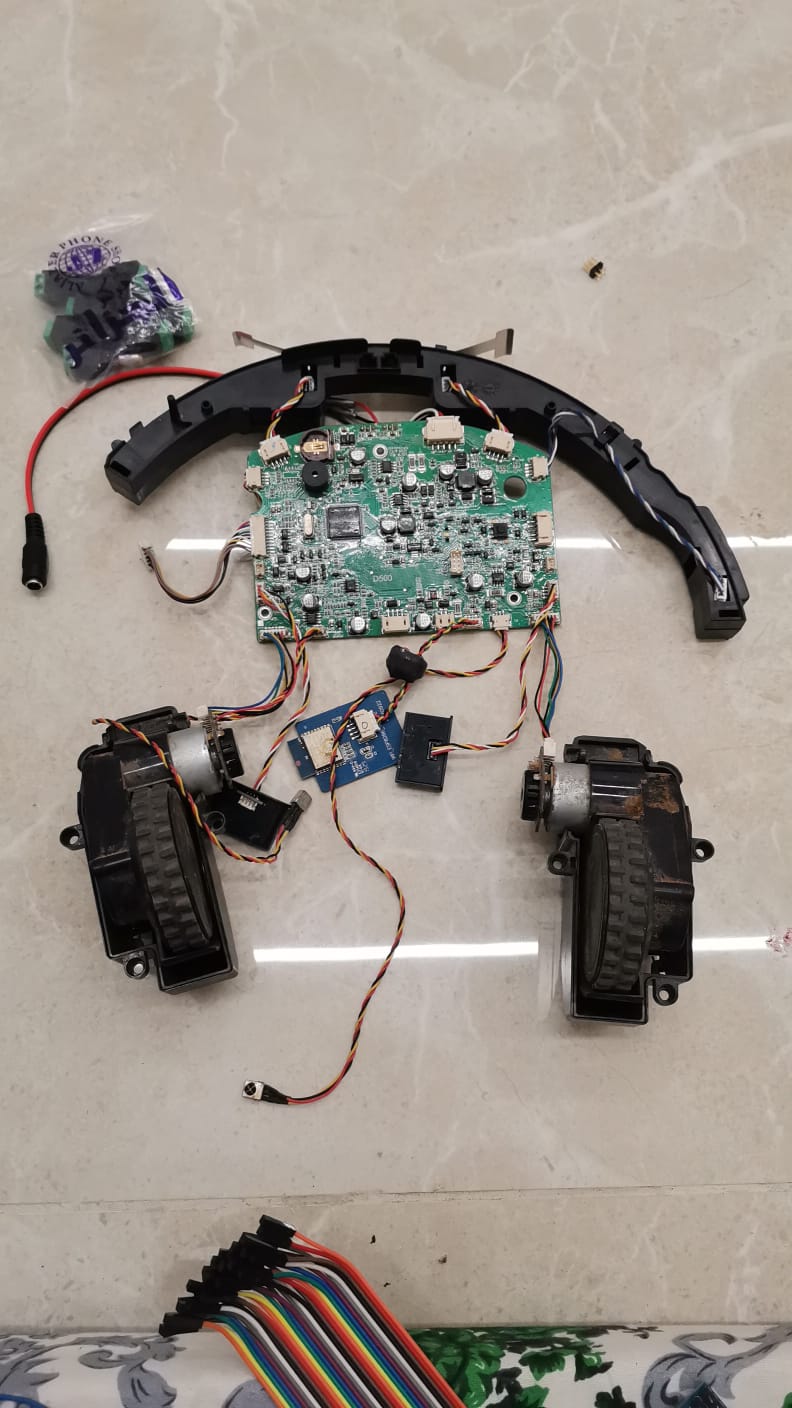
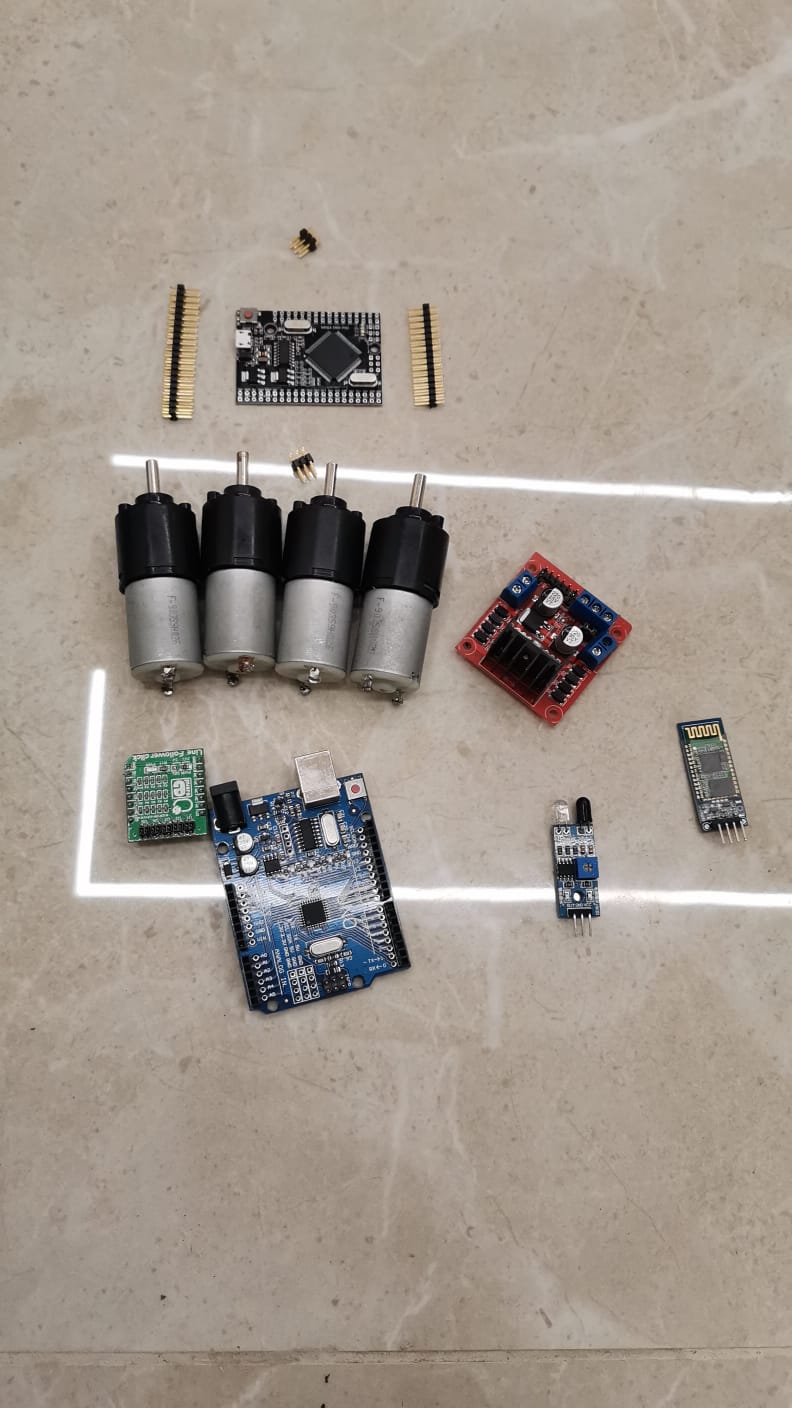
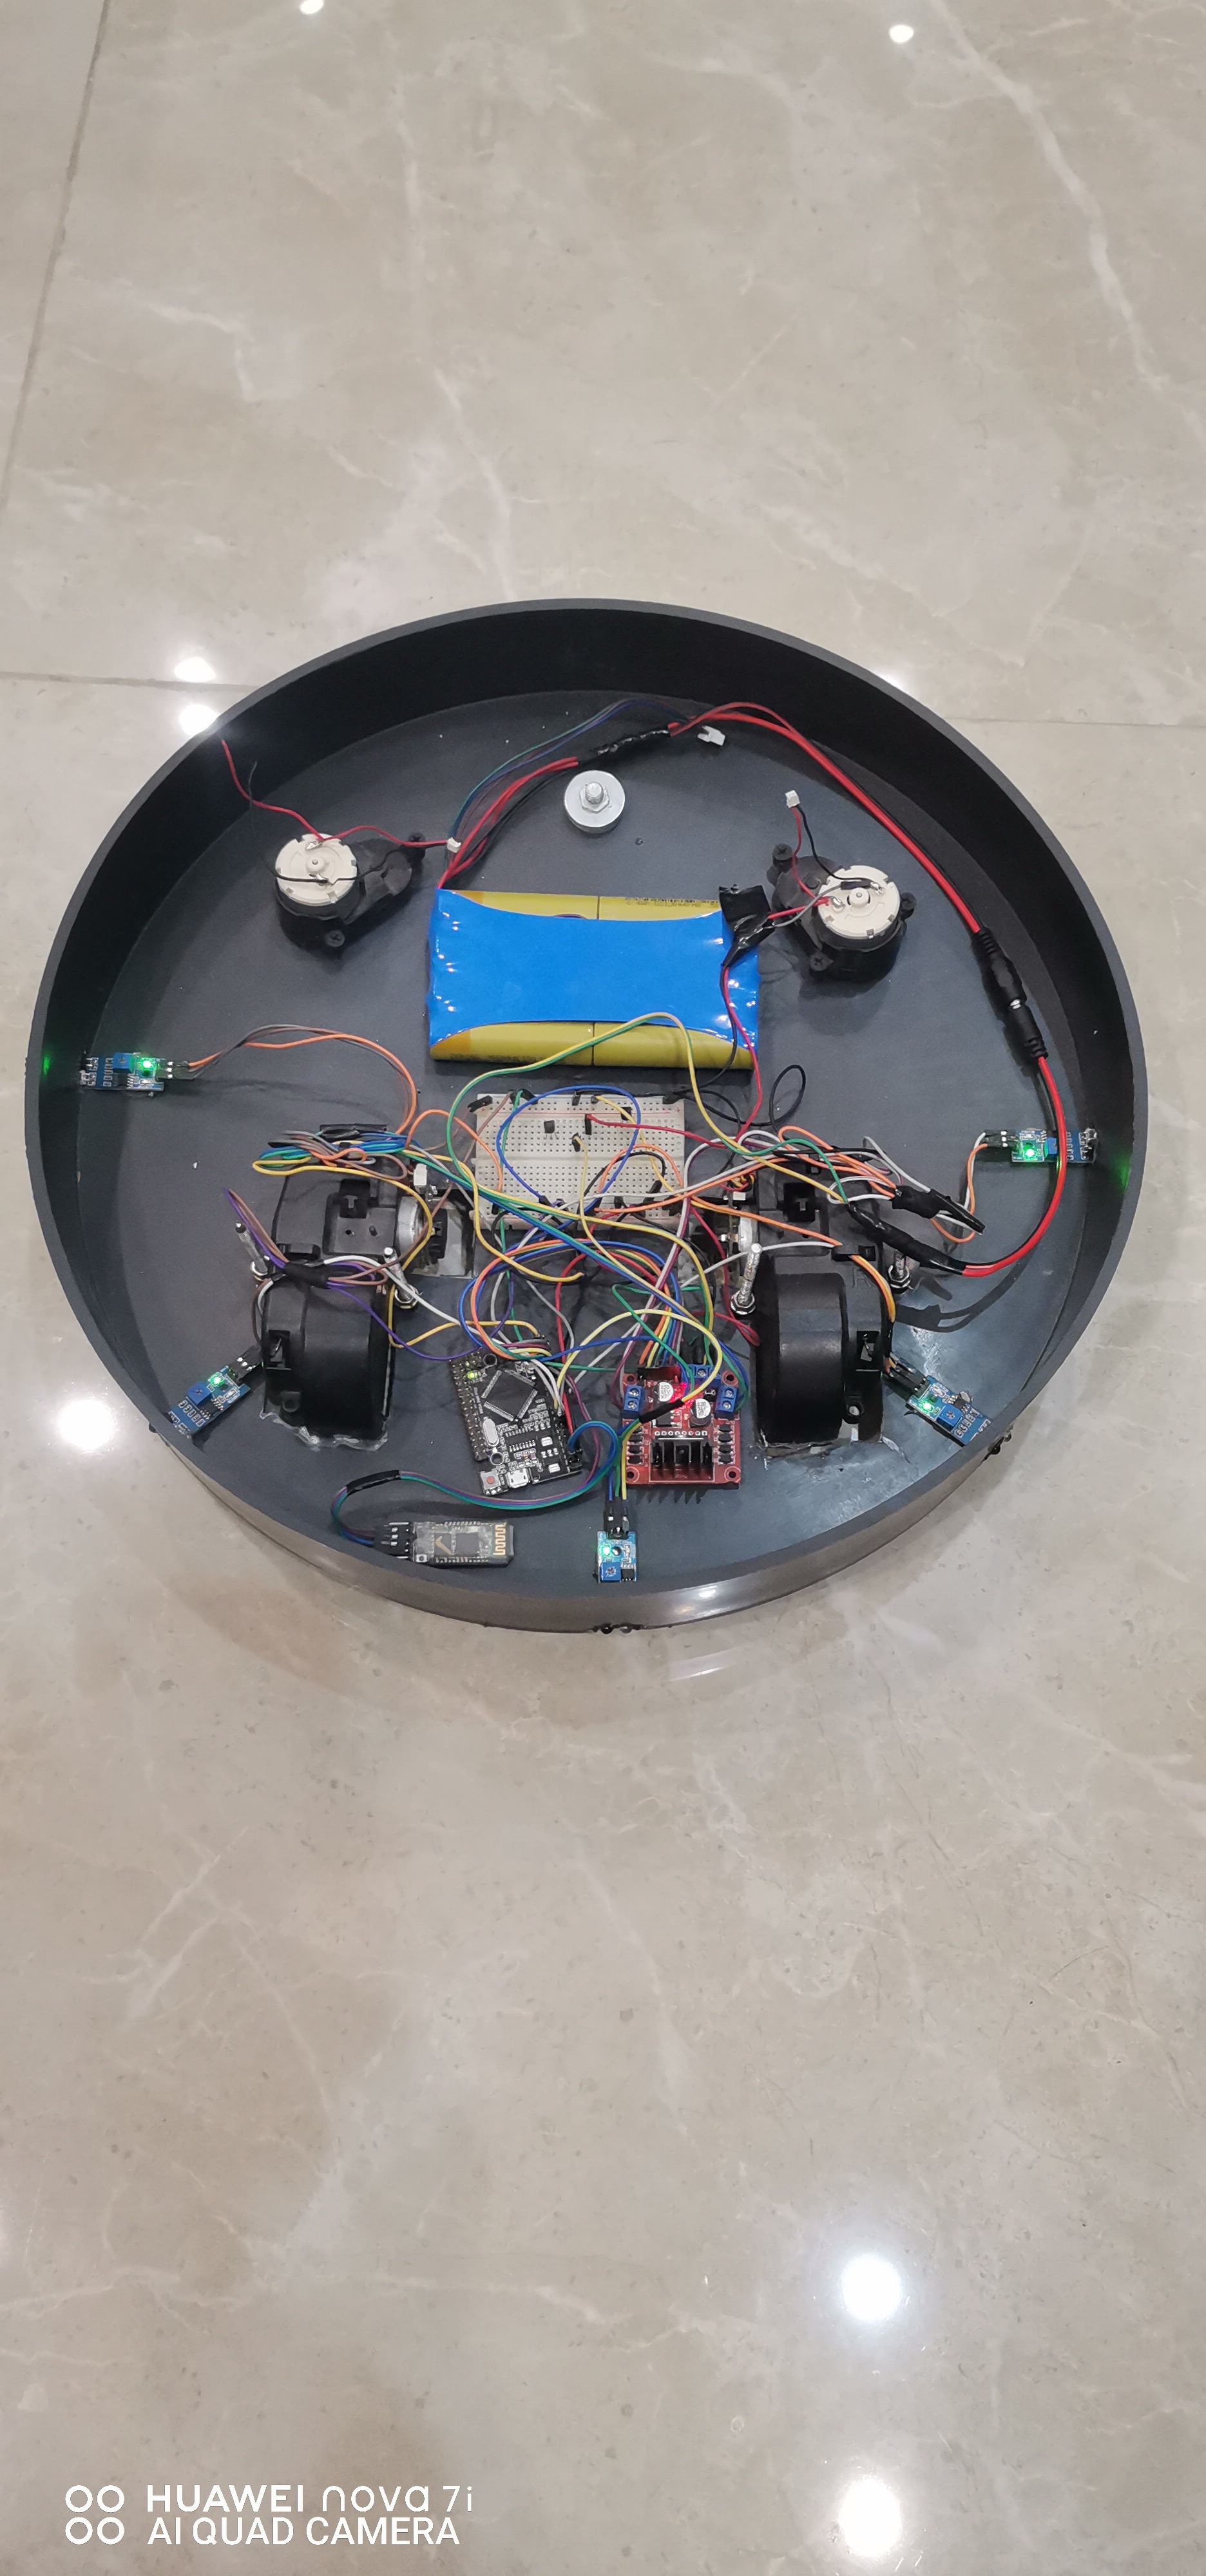
هذا المشروع يقدم تصميم وتصنيع وتنفيذ روبوت متحرك ذو قيادة تفاضلية (Differential Drive Wheeled Mobile Robot - DDWMR) قادر على أداء مهام الملاحة الذاتية والتحكم عن بُعد. يعتمد النظام المقترح على دمج التصميم الميكانيكي والإلكترونيات المضمنة وخوارزميات التحكم المعتمدة على برنامج MATLAB لتحقيق تحكم دقيق بالحركة وتتبع المسارات المطلوبة. يتكون الروبوت من عجلتين دافعتين مستقلتين وعجلة حرة لتحقيق التوازن والاستقرار أثناء الحركة، كما تم تزويده بمحركات تيار مستمر ووحدة تحكم إلكترونية لتنفيذ أوامر الحركة والتحكم. استُخدم برنامج MATLAB في نمذجة النظام ومحاكاته وتوليد مسارات الحركة وإرسال أوامر التحكم إلى الروبوت، مما أتاح إمكانية دراسة أداء النظام وتحليل استجابته في الزمن الحقيقي . أظهرت النتائج العملية نجاح الروبوت في تنفيذ أوامر الحركة المختلفة، بما في ذلك الحركة الخطية والدوران وتتبع المسارات المحددة مسبقاً، مع استجابة جيدة لإشارات التحكم المرسلة من MATLAB. كما أثبت النظام كفاءة مقبولة من حيث الاستقرار ودقة الحركة وسهولة التشغيل. يمثل هذا العمل منصة تعليمية وبحثية منخفضة الكلفة يمكن الاستفادة منها في تطبيقات الروبوتات المتحركة وأنظمة التحكم الذكية، كما يوفر أساساً مناسباً لتطوير مشاريع مستقبلية تتعلق بالملاحة الذاتية والذكاء الاصطناعي والأنظمة الروبوتية المتقدمة
NURAI · 2026
المسار الطبي
Design Different Self Tune PID Neural Network Control Schemes for Suppressing Human Immunodeficiency Virus Replication
تلازمة نقص المناعة المكتسب (الإيدز) مرض فيروسي قاتل يسببه فيروس نقص المناعة البشرية (HIV)، والذي يدمر جهاز المناعة. لا يوجد حاليًا لقاح أو علاج شافٍ لهذا المرض، ولكن العلاج بالأدوية (العلاج المضا…
الفريق
فريق الابتكار الطبي
رمز الفريق
NURAI2026-0344
المشرف
أ.د.اخلاص حميد كرم
قراءة الوصف الكامل للمشروع
تلازمة نقص المناعة المكتسب (الإيدز) مرض فيروسي قاتل يسببه فيروس نقص المناعة البشرية (HIV)، والذي يدمر جهاز المناعة. لا يوجد حاليًا لقاح أو علاج شافٍ لهذا المرض، ولكن العلاج بالأدوية (العلاج المضاد للفيروسات القهقرية، أو ART) يمكن أن يبطئ من تطور فيروس نقص المناعة البشرية. قد يُسبب الاستخدام اليومي للتدابير الوقائية آثارًا جانبية خطيرة، لذا يجب مراقبة جرعة الدواء ونظام العلاج باستمرار. طُوّرت نماذج رياضية لفيروس نقص المناعة البشرية لوصف التفاعل بين الخلايا السليمة والخلايا المصابة وجزيئات الفيروس الحرة، مما كشف أن نظام فيروس نقص المناعة البشرية يتصرف كنظام ديناميكي غير خطي. لذلك، هناك حاجة إلى استراتيجيات تحكم ذكية لتعديل العلاج ديناميكيًا من أجل تقليل الحمل الفيروسي مع الحفاظ على استقرار جهاز المناعة. في هذا المشروع، نقترح وحدات تحكم PID ذاتية الضبط تكيفية مختلفة تعتمد على الشبكات العصبية (NN)، بما في ذلك وحدة تحكم PID ذاتية الضبط تعتمد على شبكة عصبية متعددة الطبقات ونظام منطق ضبابي بتسع قواعد، ووحدة تحكم PID ذاتية الضبط تعتمد على شبكة عصبية أحادية الطبقة. من خلال التحديثات المستمرة، يقوم المحسن بتعديل استجابة نظام فيروس نقص المناعة البشرية لتتوافق مع النظام المرجعي، مما يسهل التحكم التكيفي.
المسار الطبي
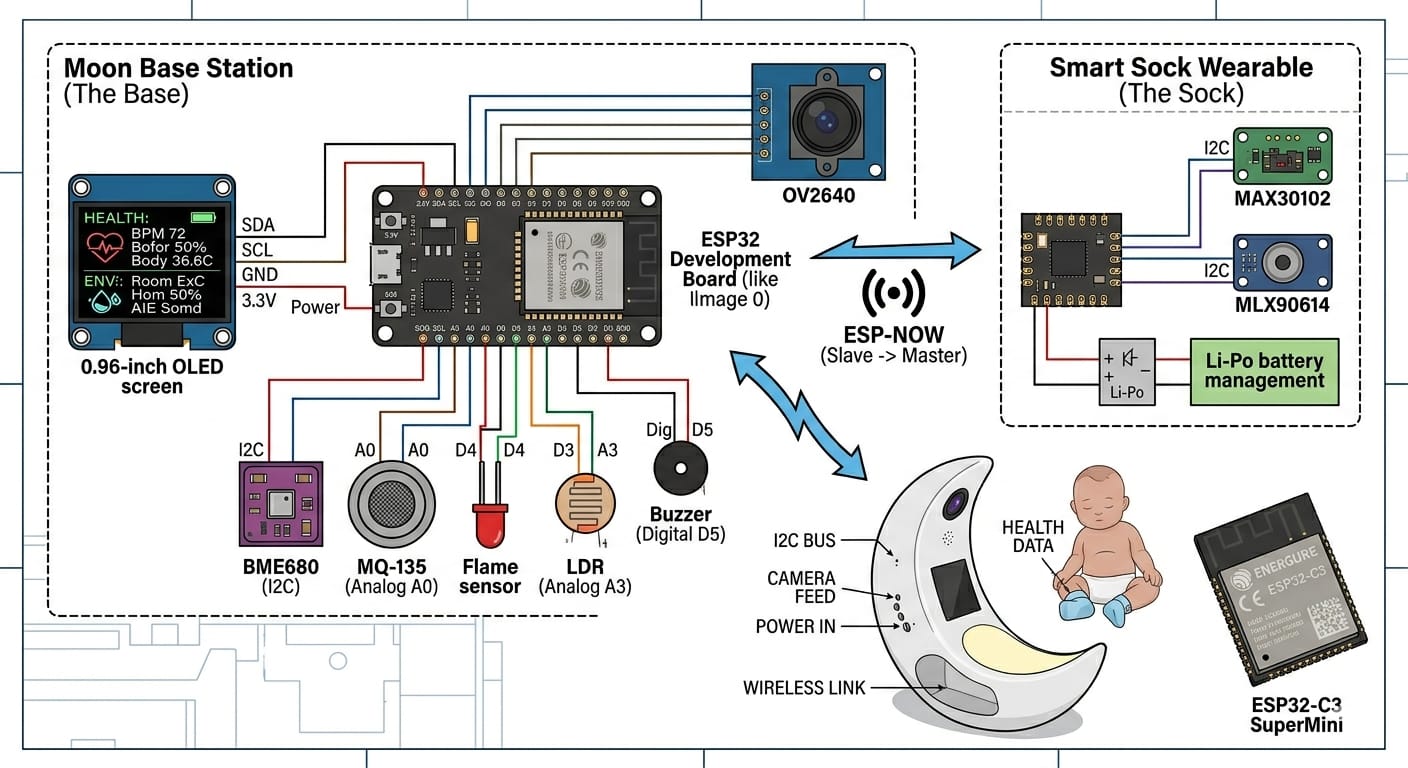
Design of a lowcost intelligent device for child protection using microcontroller
This project addresses a significant problem in remote infant health monitoring and predictive care. The proposed solution is based on a cross-platform Flutter mobile application integrated with …
الفريق
فريق قسم الكهرباء
رمز الفريق
NURAI2026-0353
المشرف
م. راضي صحن عيسى
قراءة الوصف الكامل للمشروع
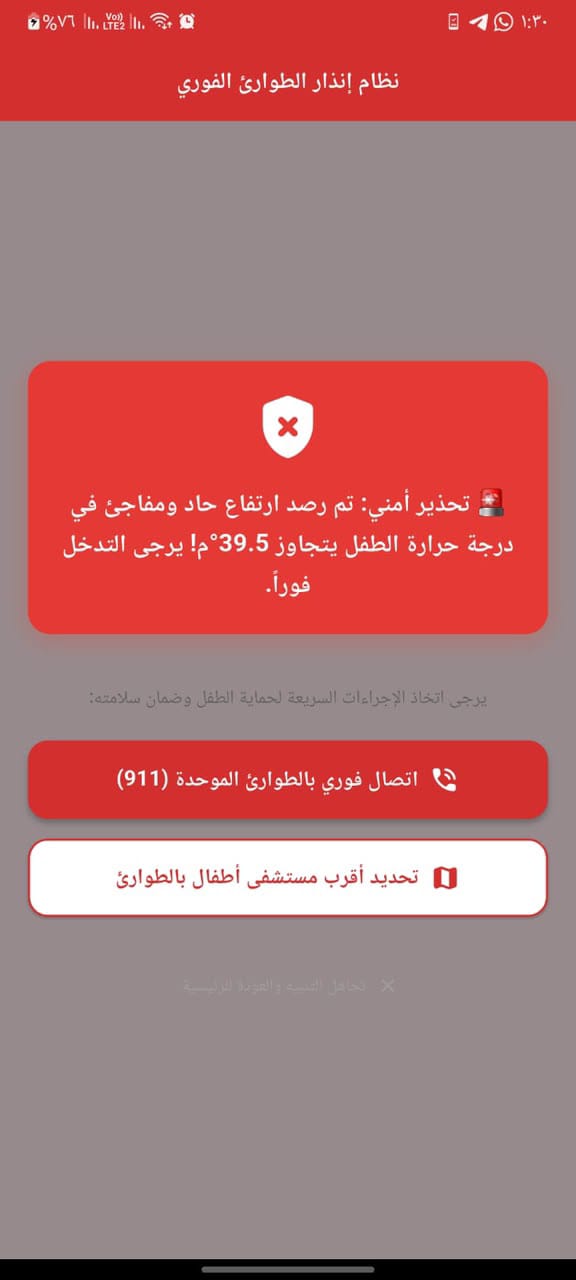
This project addresses a significant problem in remote infant health monitoring and predictive care. The proposed solution is based on a cross-platform Flutter mobile application integrated with a Node.js JavaScript backend deployed on Railway, utilizing Gemini AI and Firebase Realtime Database with the aim of transitioning infant monitoring from reactive, static threshold alarms to an AI-driven, predictive health orchestration paradigm. The expected outcomes include dynamic, near-zero latency vital signs streaming, automated 30-second analytical pipelines for early anomaly forecasting, and intelligent, pediatrician-ready weekly clinical summaries archived securely in the cloud.
مسار التربية والتعليم
Edukai: AI-Powered Adaptive Tutoring Through Behavioural Learning Analytics
This work addresses a critical limitation in contemporary digital education systems: their predominant reliance on static, undifferentiated feedback mechanisms that assess knowledge outcomes rath…
الفريق
Alpha
رمز الفريق
NURAI2026-0352
المشرف
مروج خالد ابراهيم
قراءة الوصف الكامل للمشروع
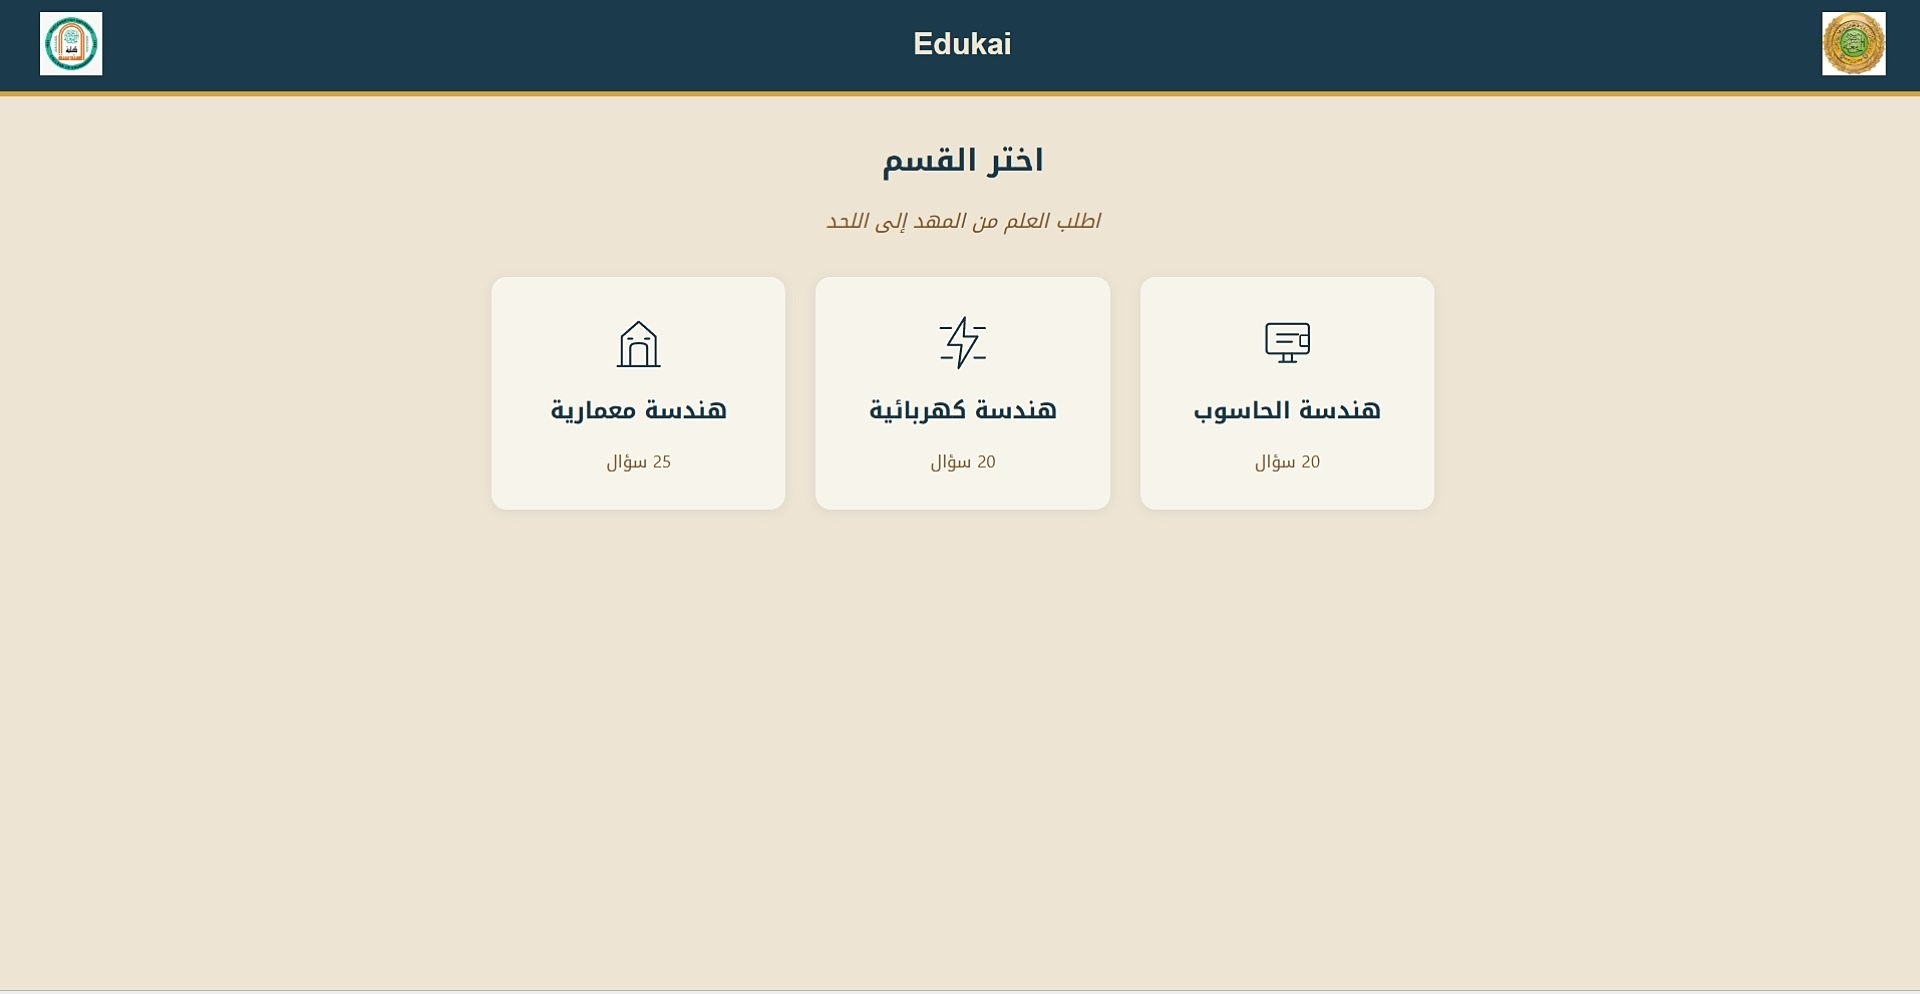
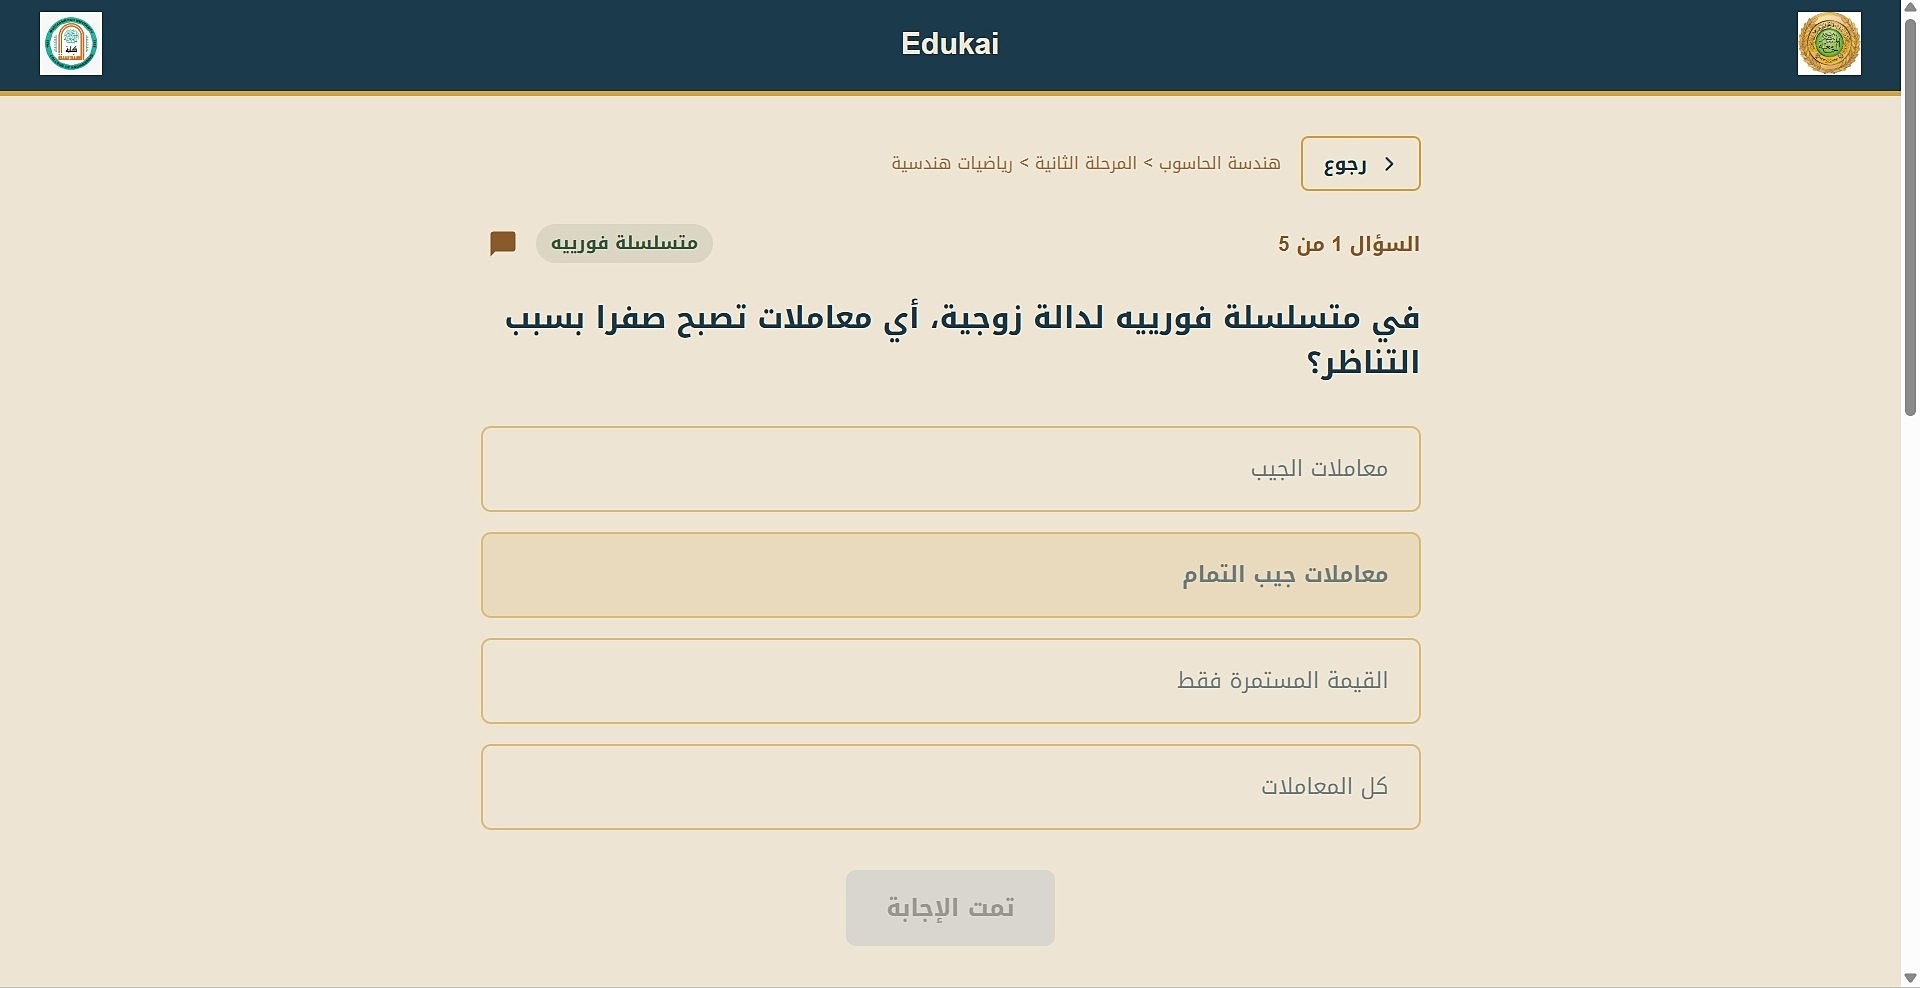
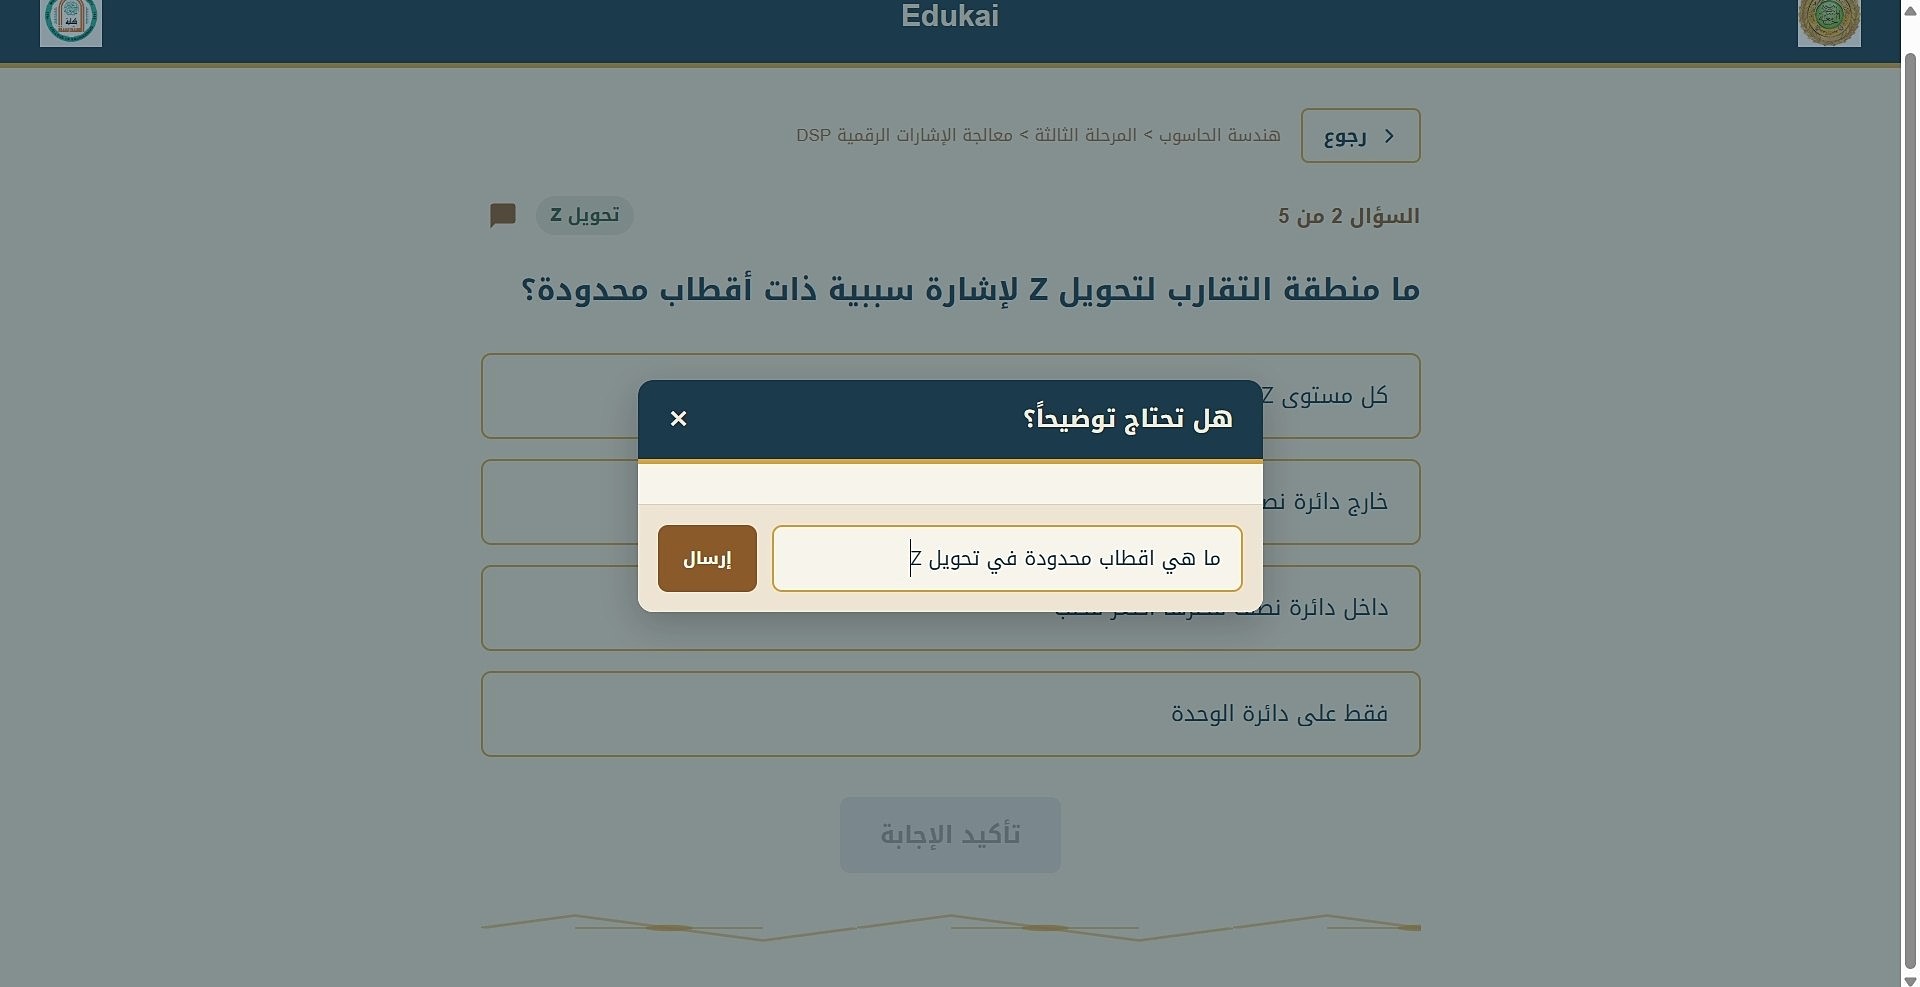
This work addresses a critical limitation in contemporary digital education systems: their predominant reliance on static, undifferentiated feedback mechanisms that assess knowledge outcomes rather than actively guiding the learning process. Existing e-learning platforms typically respond to incorrect submissions with predetermined explanations, irrespective of the specific cognitive or logical pathway that led the learner to an erroneous conclusion. To address this gap, we present Edukai, a novel interactive micro-learning platform that integrates cloud-based Large Language Models (LLMs) with granular, pre submission behavioural analytics—including option-toggling frequency and response hesitation time—to infer the learner's
underlying reasoning process in real time. This behavioural signal is fused with the submitted answer and relayed to an AI reasoning engine, which generates dynamic, context-aware remediation tailored to the individual's specific misconception, effectively shifting the platform's role from passive evaluator to active digital tutor. The proposed system further incorporates behavioural gamification principles to counter the high attrition rates characteristic of self-directed digital learning. A functional prototype has been developed and evaluated across several analytically demanding domains, including engineering probability and cognitive logic, demonstrating the feasibility of the proposed architecture. The system's lightweight, cloud-native design further establishes a scalable foundation for extension across
diverse educational and professional training contexts.
المسار البيئي
EnviroAI-Iraq: نظام ذكي قائم على إنترنت الأشياء والتعلم الألي التفسيري للمراقبة اللحظية لجودة الهواء وتقييم المخاطر البيئية وتحليل مؤشرات الاستدامة
الخلاصة أدى التوسع الحضري المتسارع والأنشطة الصناعية المتزايدة إلى تنامي الحاجة إلى أنظمة ذكية قادرة على مراقبة جودة الهواء وتحليل المخاطر البيئية بصورة آنية ودقيقة. يقدم هذا المشروع منظومة-Iraq …
الفريق
نظام ذكي لمراقبة وتحليل جودة البيئة والاستدامة في قسم علوم الحاسوب – الجامعة المستنصرية
رمز الفريق
NURAI2026-0974
المشرف
أ.م ياسمين مكي محي الدين
قراءة الوصف الكامل للمشروع
الخلاصة
أدى التوسع الحضري المتسارع والأنشطة الصناعية المتزايدة إلى تنامي الحاجة إلى أنظمة ذكية قادرة على مراقبة جودة الهواء وتحليل المخاطر البيئية بصورة آنية ودقيقة. يقدم هذا المشروع منظومة-Iraq EnviroAI، وهي منصة ذكاء بيئي مفتوحة المصدر تعتمد على تكامل تقنيات إنترنت الأشياء والذكاء الاصطناعي والتحليلات الإحصائية والتصور التفاعلي للبيانات ضمن إطار موحد لدعم اتخاذ القرار البيئي.
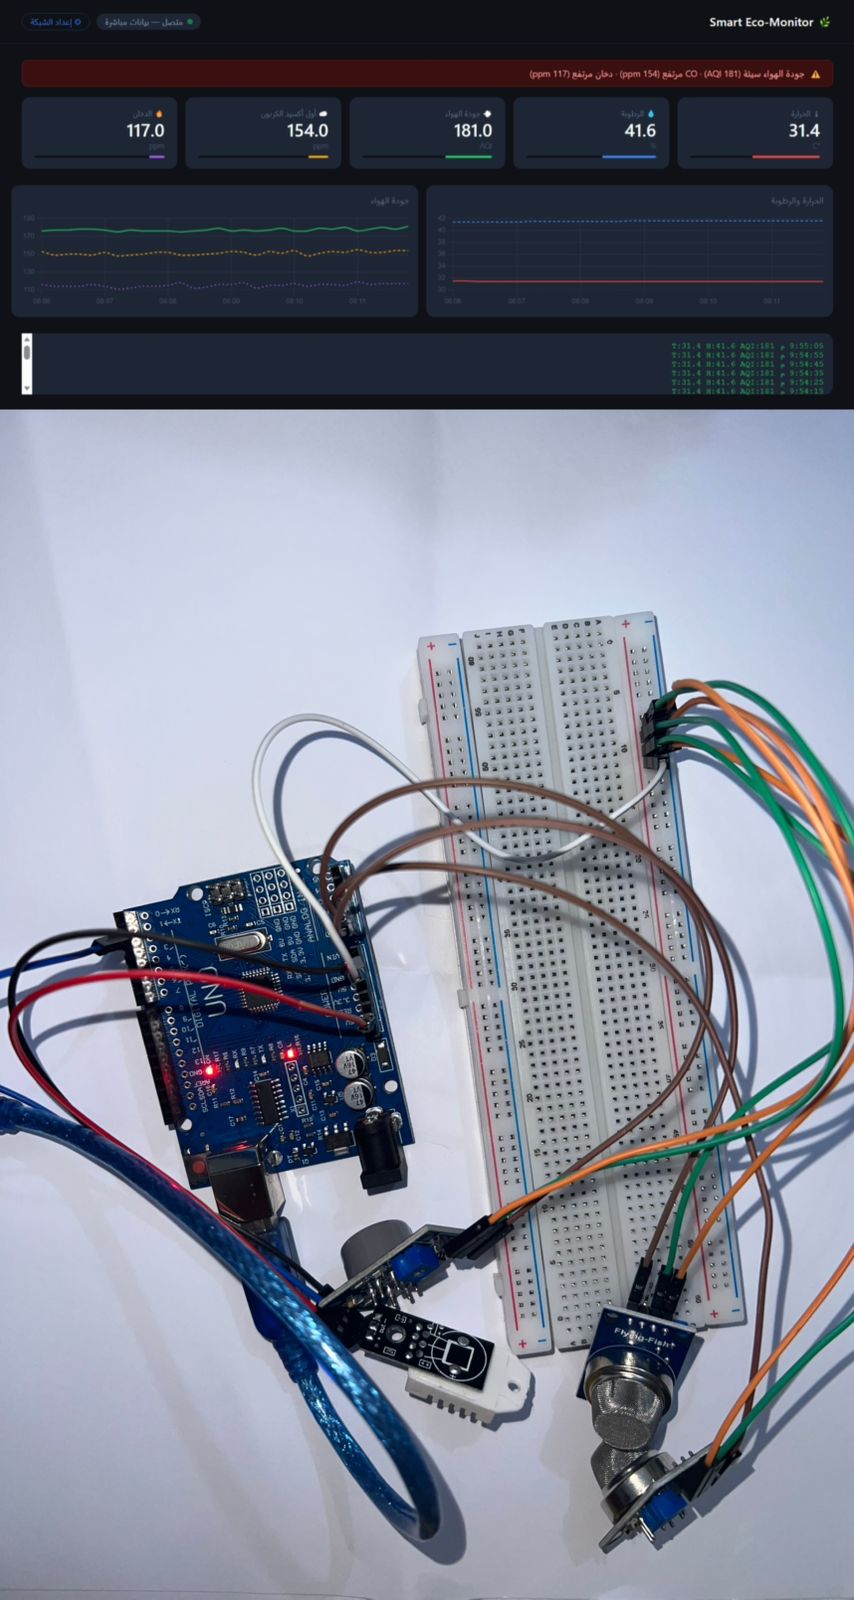
تتكون المنظومة من عدة تطبيقات مترابطة. يعتمد المستوى الأول على شبكة استشعار بيئية آنية تستخدم متحكمات Arduino UNO مع حساسات MQ-135 وMQ-7 وMQ-2 وDHT22 لقياس مؤشر جودة الهواء (AQI)، وأول أكسيد الكربون (CO)، وتركيز الدخان، ودرجات الحرارة والرطوبة، مع نقل البيانات إلى منصة سحابية للتحليل والعرض الفوري. كما تم تطوير مؤشر مخاطر بيئية موحد (RiskIndex) يدمج المتغيرات البيئية المختلفة لتصنيف المخاطر ضمن خمس فئات تبدأ من الحالة الآمنة وتنتهي بحالة الطوارئ.
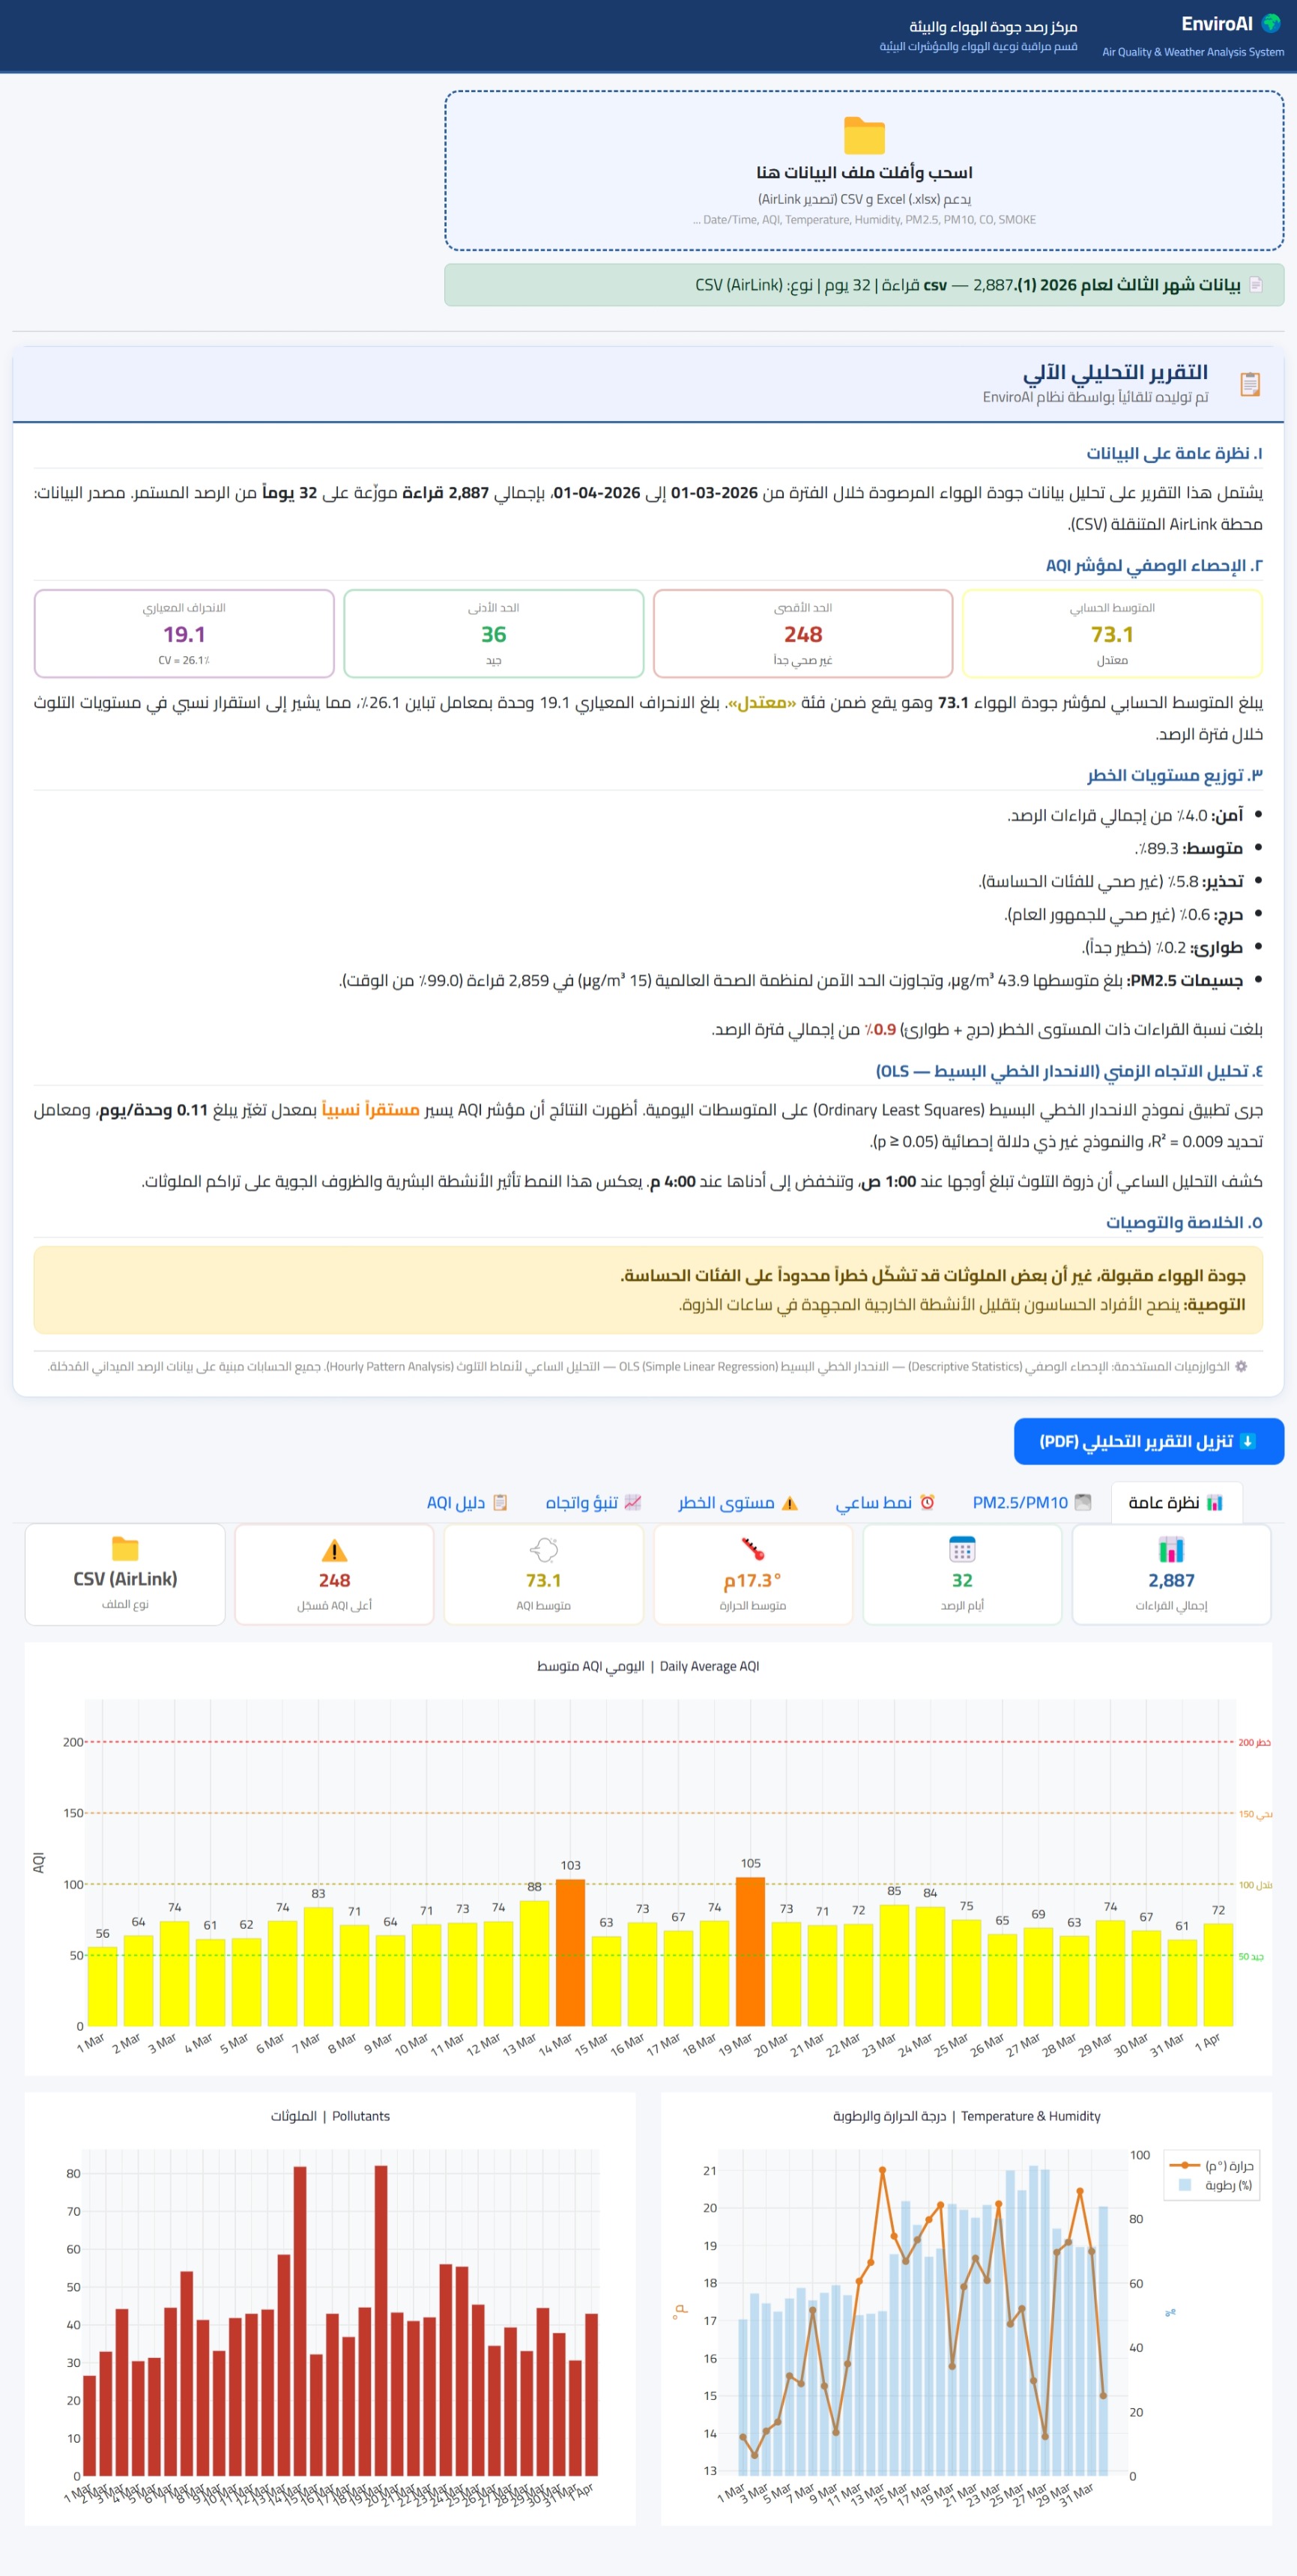
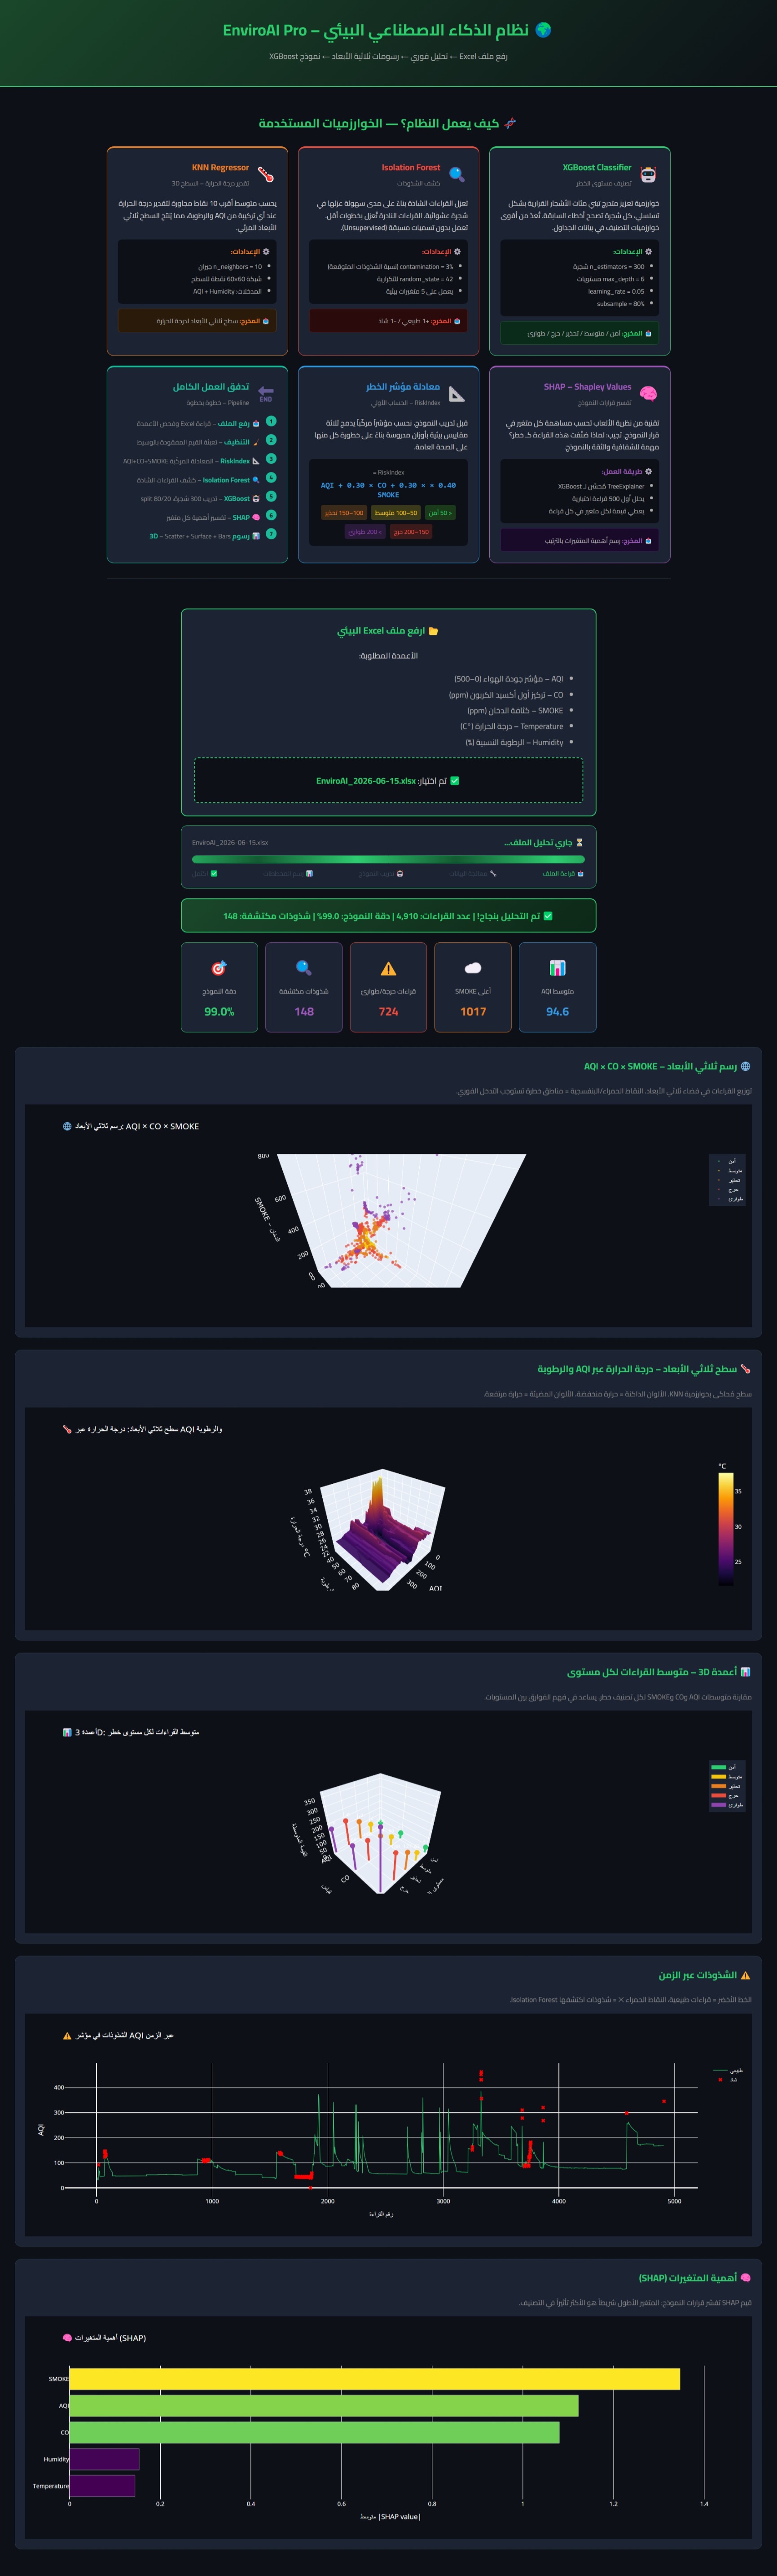
اعتمد المشروع على مجموعتي بيانات تكميليتين: مجموعة بيانات حقيقية تضم 2,887 قراءة بيئية جُمعت خلال 32 يوماً من محطة قسم علوم الجو في الجامعة المستنصرية، ومجموعة بيانات معيارية تضم 4,910 عينة من قراءات حساسات إنترنت الأشياء. ولتقييم أداء النماذج، تم تطبيق استراتيجية تقسيم طبقي للبيانات بنسبة 80% للتدريب و20% للاختبار. كما استُخدمت مجموعة من خوارزميات التعلم الآلي والذكاء الاصطناعي شملت Random Forest وSupport Vector Machine (SVM) وXGBoost وK-Means وIsolation Forest وLocal Outlier Factor (LOF) وOne-Class SVM، بهدف تصنيف مستويات المخاطر البيئية، واكتشاف الشذوذ، والتنبؤ بالأحداث التلوثية، وإصدار التنبيهات الذكية.
أظهرت النتائج التجريبية أداءً مرتفعاً للنماذج المقترحة، حيث حقق كل من Random Forest وXGBoost دقة تصنيف بلغت 99.0%، في حين حقق SVM دقة بلغت 96.4%. كما نجحت خوارزميات كشف الشذوذ في تحديد ما بين 148 و389 حالة شاذة ضمن مجموعة البيانات البالغ حجمها 4,910 قراءة. وأكد تحليل SHAP أن مؤشر جودة الهواء وتركيز الدخان وأول أكسيد الكربون تمثل العوامل الأكثر تأثيراً في قرارات التصنيف والتقييم البيئي.
تتضمن المنظومة أيضاً روبوت محادثة بيئياً ثنائي اللغة (العربية والإنجليزية) يوفر دعماً تعليمياً وفنياً حول ملوثات الهواء ومعايير جودته وطرق القياس، إضافة إلى لوحات معلومات تفاعلية، وتحليلات إحصائية متقدمة، وعروض ثنائية وثلاثية الأبعاد، وتقارير بيئية قابلة للتنزيل. وتتوفر جميع مكونات النظام وشفراته المصدرية كمشاريع مفتوحة المصدر دعماً للشفافية وإمكانية إعادة الاستخدام والتطوير المستقبلي.
تشير النتائج إلى أن دمج تقنيات إنترنت الأشياء مع نماذج التعلم الآلي والذكاء الاصطناعي القابل للتفسير يوفر حلاً عملياً وقابلاً للتوسع ومنخفض الكلفة للرصد البيئي الآني، وتقييم مخاطر التلوث، وتعزيز الإدارة البيئية المعتمدة على البيانات، ودعم الوعي البيئي واتخاذ القرار المستند إلى الأدلة.كما تتضمن المنظومة روبوت محادثة ذكي ثنائي اللغة (العربية والإنجليزية) متخصصاً في التوعية البيئية، حيث يوفر معلومات تفصيلية حول ملوثات الهواء وطرق قياسها والحدود القياسية المقبولة والخطرة، إضافة إلى شرح الحساسات المستخدمة وآلية عملها وتطبيقاتها العملية. وتوفر المنصة كذلك لوحات معلومات تفاعلية وتحليلات إحصائية متقدمة ورسومات ثنائية وثلاثية الأبعاد وتقارير بيئية قابلة للتنزيل وتوصيات ذكية للمستخدمين.
جميع مكونات المنظومة وبرمجياتها متاحة كمشاريع مفتوحة المصدر، مما يعزز الشفافية وإمكانية إعادة الاستخدام والتطوير المستقبلي. وتؤكد النتائج أن دمج تقنيات إنترنت الأشياء والذكاء الاصطناعي والتحليلات التفسيرية ضمن إطار موحد يوفر حلاً عملياً منخفض الكلفة وقابلاً للتوسع لمراقبة البيئة وتقييم جودة الهواء ورفع الوعي البيئي ودعم اتخاذ القرارات البيئية المعتمدة على البيانات في الزمن الحقيقي. ممكن الاطلاع على المشروع عبر الرابط التالي :https://enviroai-iraq.up.railway.app/
المسار الطبي
Gesture-Controlled Smart Rover for Assisted Mobility
Individuals with limited hand or arm dexterity often face significant barriers when using conventional joystick- or button-based mobility controls, which require a degree of fine motor precision …
الفريق
فريق الإسناد الذكي
رمز الفريق
NURAI2026-0342
المشرف
م. د. ايام محسن عباس محسن
قراءة الوصف الكامل للمشروع
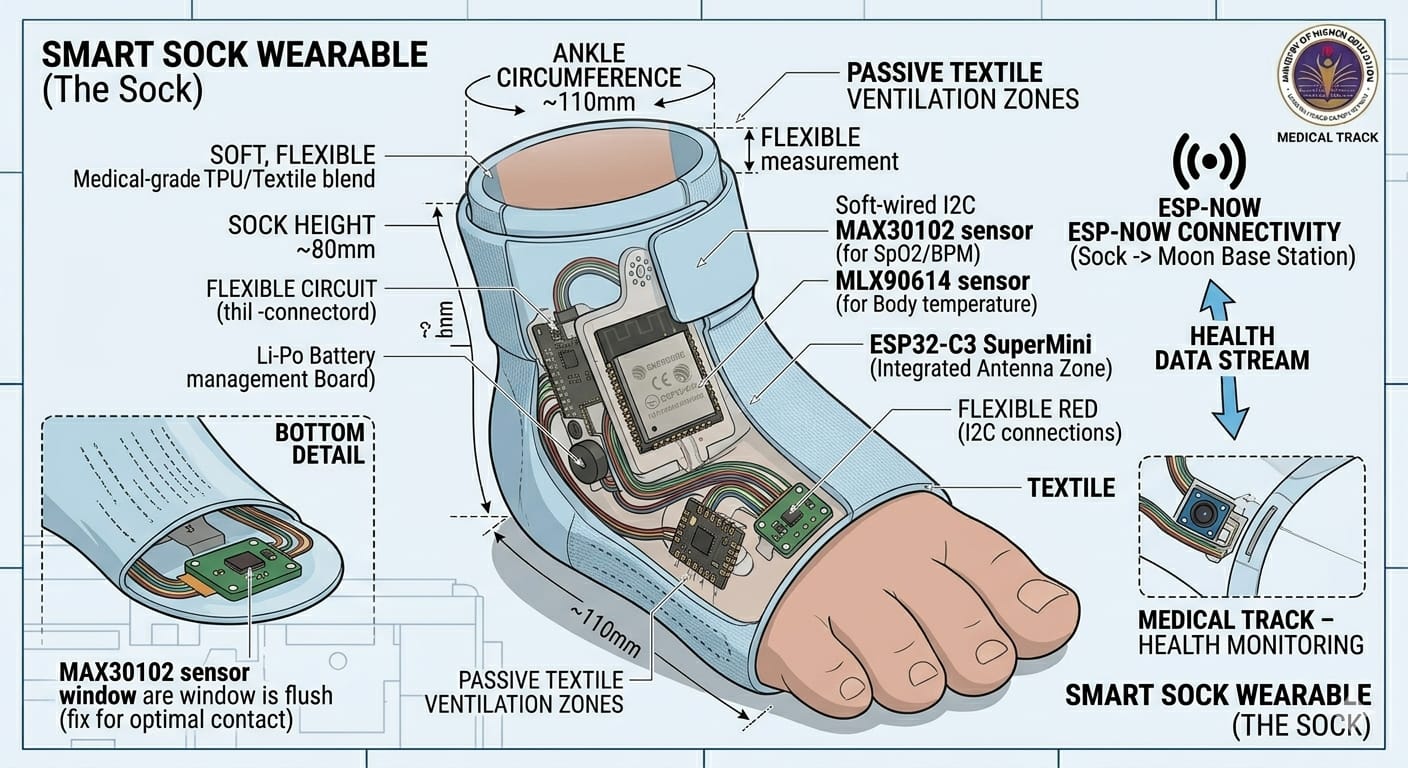
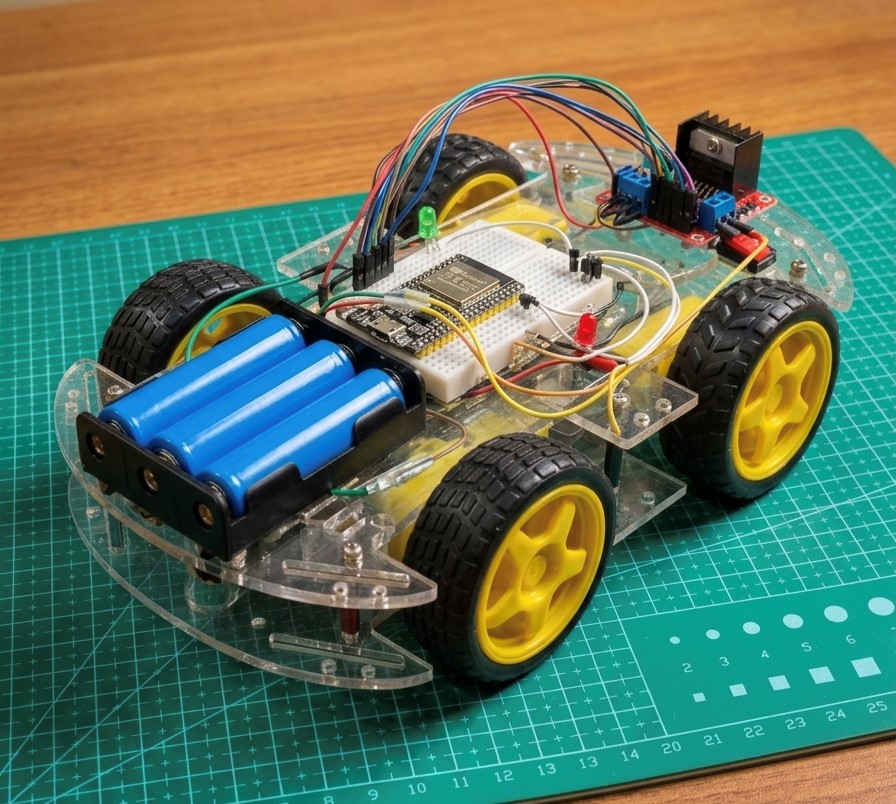
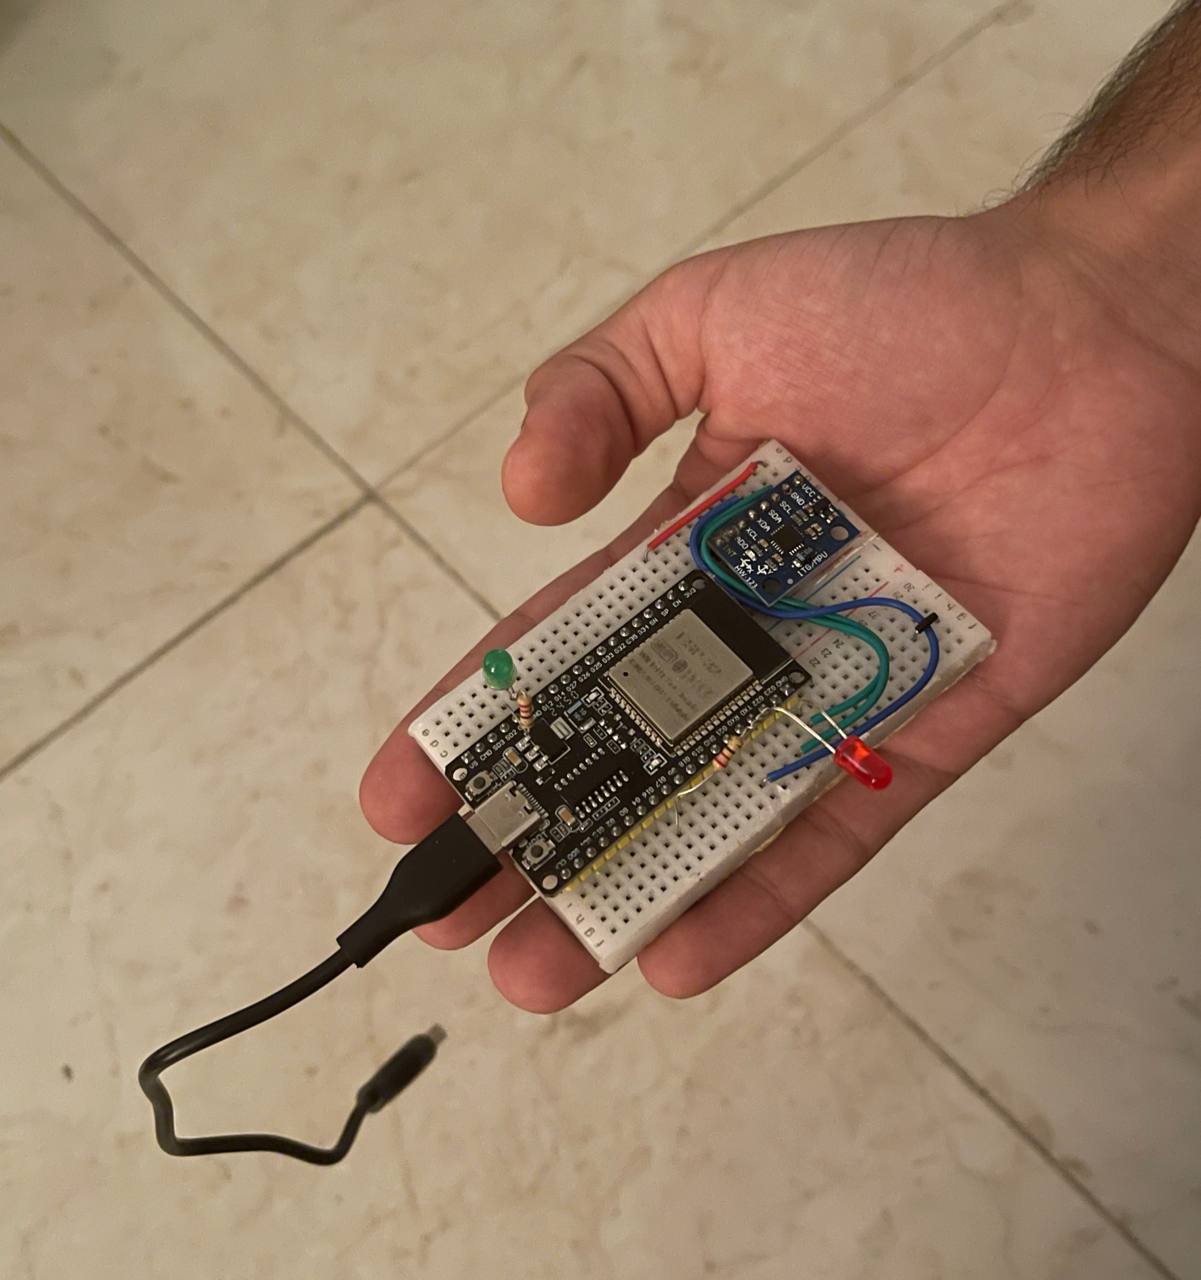
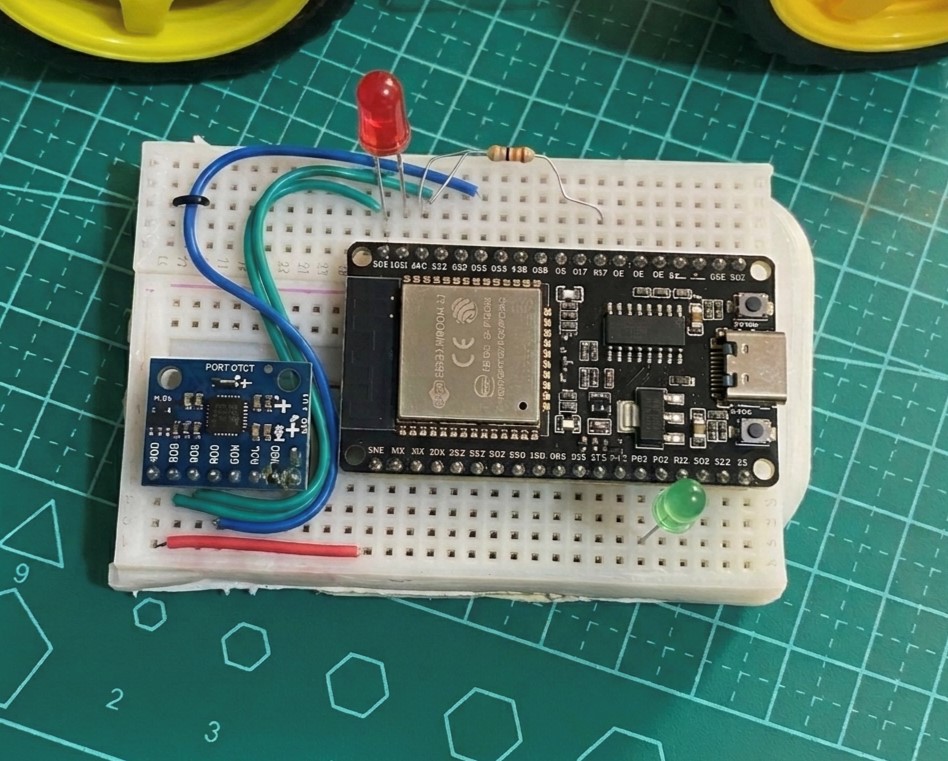
Individuals with limited hand or arm dexterity often face significant barriers when using conventional joystick- or button-based mobility controls, which require a degree of fine motor precision that not every user can reliably sustain. This project presents the design, implementation, and hands-on testing of a low-cost gesture-controlled smart rover intended as an accessible navigation platform for individuals with limited upper-limb motor function. The system comprises a wearable Smart Glove transmitter built around an ESP32 microcontroller and an MPU6050 inertial measurement unit (IMU), paired with a four-wheeled rover receiver driven by an L298N dual H-bridge motor driver. Hand-tilt data is streamed to the rover over the ESP-NOW peer-to-peer wireless protocol, eliminating the latency and infrastructure requirements of conventional Wi-Fi or Bluetooth links. A threshold-based dead-zone filter suppresses unintended movement from residual hand tremor, and an automatic rollover-detection mechanism, also based on the MPU6050, identifies a tip-over event and triggers an SOS alert to notify the user or a caregiver. During hardware integration, a motor-induced voltage brownout was identified, diagnosed, and resolved through a high-discharge battery and a common-ground wiring strategy. Field testing on a physical prototype confirmed consistent directional control, a reliable fail-safe motor cutoff, and correct triggering of the rollover SOS alert, supporting the feasibility of IMU-based gesture interfaces as a practical and replicable alternative to joystick-based assistive mobility controls.
المسار الصناعي
Machine Learning for Threat Detection in Mobile Applications
This project presents a machine-learning system that detects malicious Android applications through static analysis alone, without executing the application. Using the TUANDROMD dataset of 4,465 …
الفريق
Machine learning for detection threats on mobile applications
رمز الفريق
NURAI2026-0971
المشرف
ا.م.د. نور ثامر
قراءة الوصف الكامل للمشروع
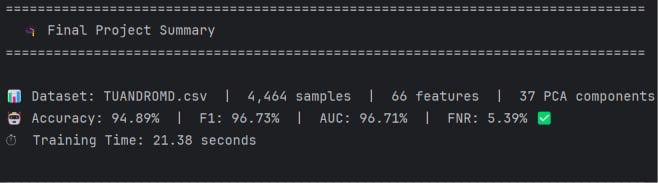
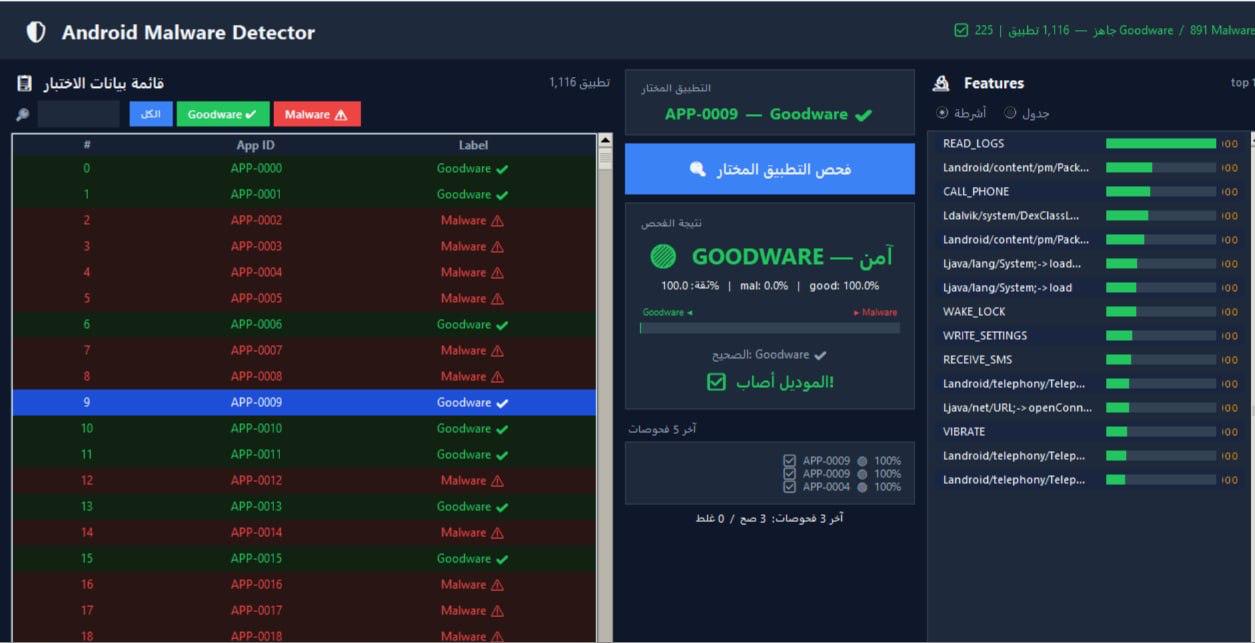
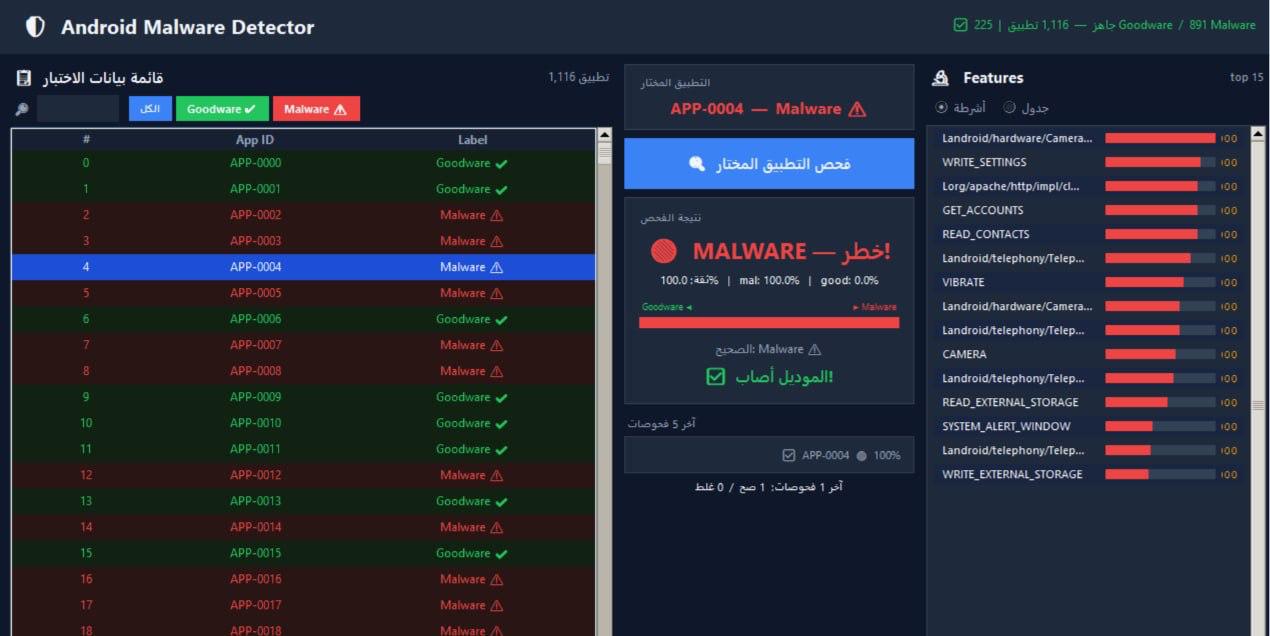
This project presents a machine-learning system that detects malicious Android applications through static analysis alone, without executing the application. Using the TUANDROMD dataset of 4,465 real Android applications described by 241 static features, the pipeline applies a custom Random Forest model for feature selection and Principal Component Analysis for dimensionality reduction, then classifies each application as malware or goodware using a Double Q-Learning reinforcement-learning model with an asymmetric reward structure that penalizes missed malware more heavily than false alarms. The trained model achieves 94.89% accuracy and a low false-negative rate of 5.39%, and is deployed through a simple interactive desktop application.
مسار خدمة المجتمع
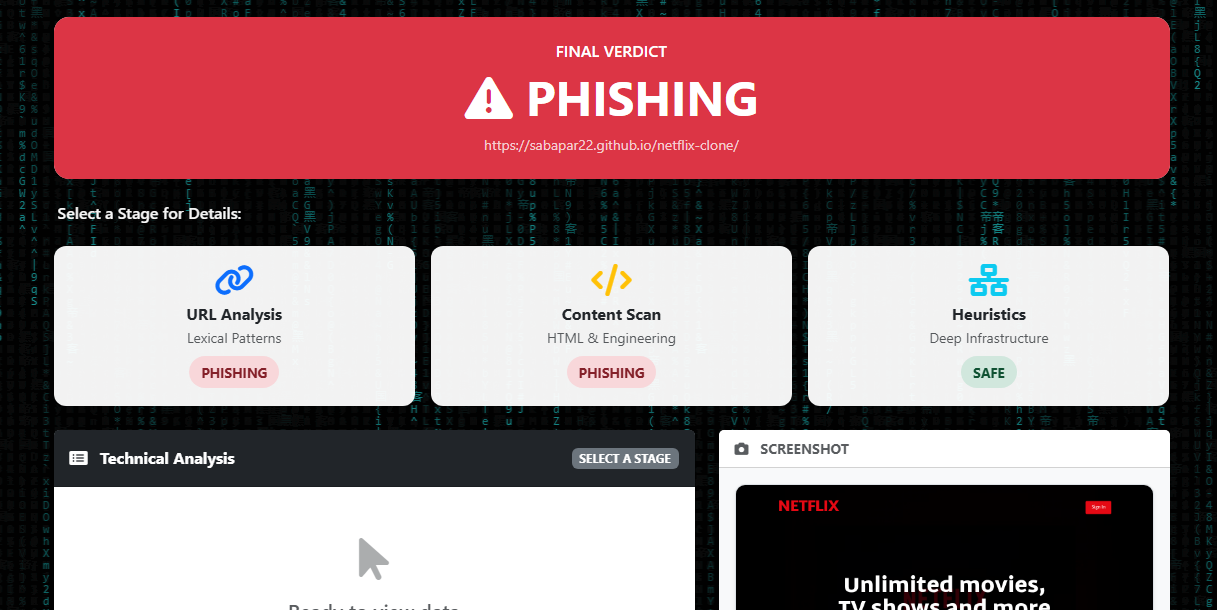
Phishing Detection Web Application
This project is a comprehensive web application (Multi-Vector) that utilizes Artificial Intelligence to detect phishing attacks across multiple channels simultaneously, including URLs, emails, an…
الفريق
Phishing Detection Web Application
رمز الفريق
NURAI2026-0977
المشرف
م.شذى جاسم محمد
قراءة الوصف الكامل للمشروع
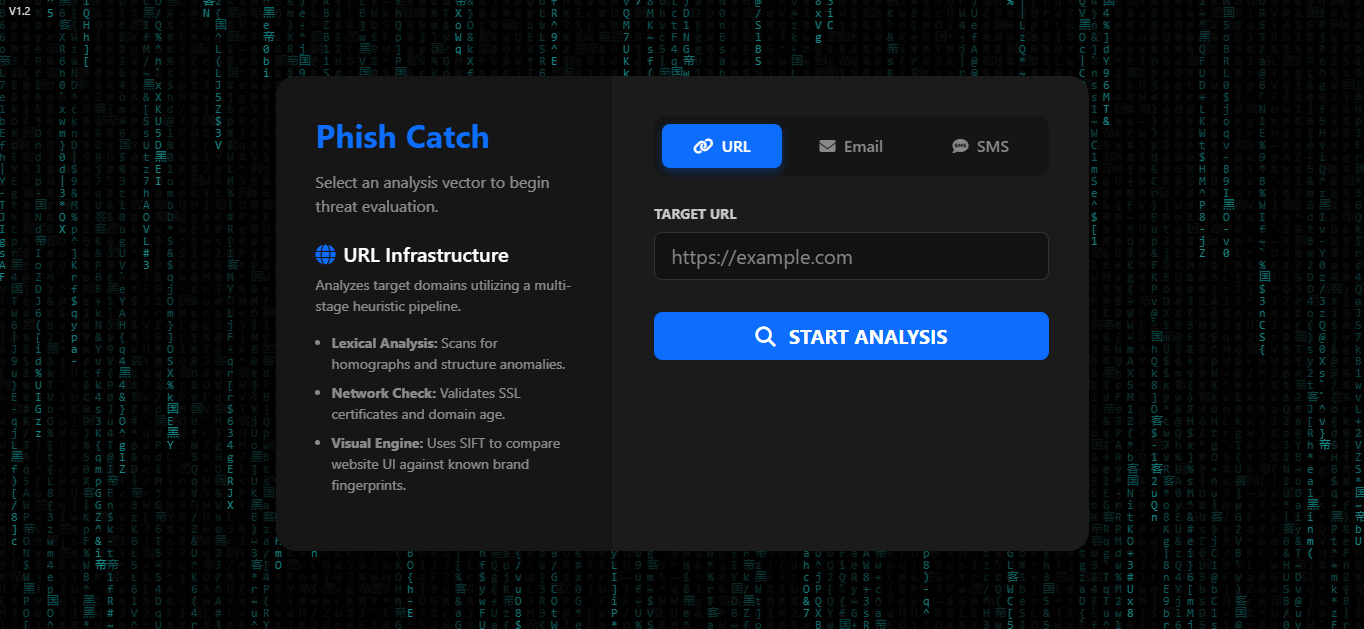
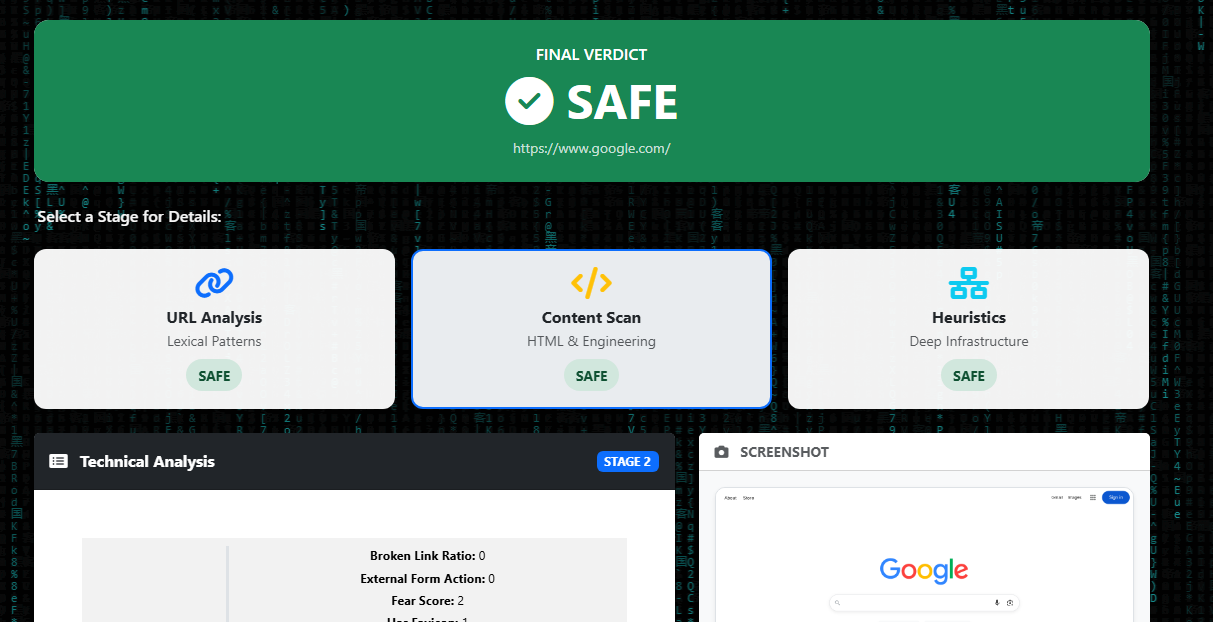
This project is a comprehensive web application (Multi-Vector) that utilizes Artificial Intelligence to detect phishing attacks across multiple channels simultaneously, including URLs, emails, and SMS messages.
المسار البيئي
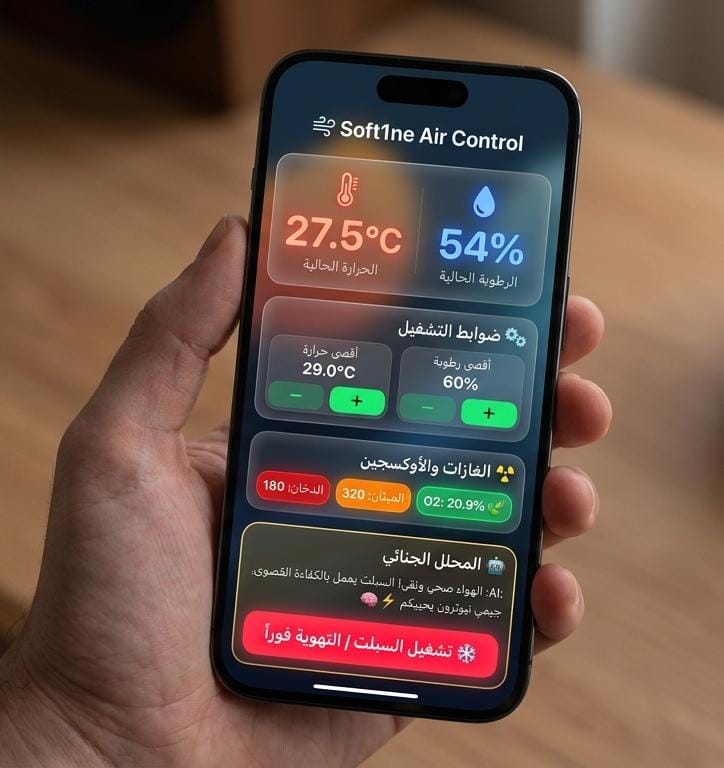
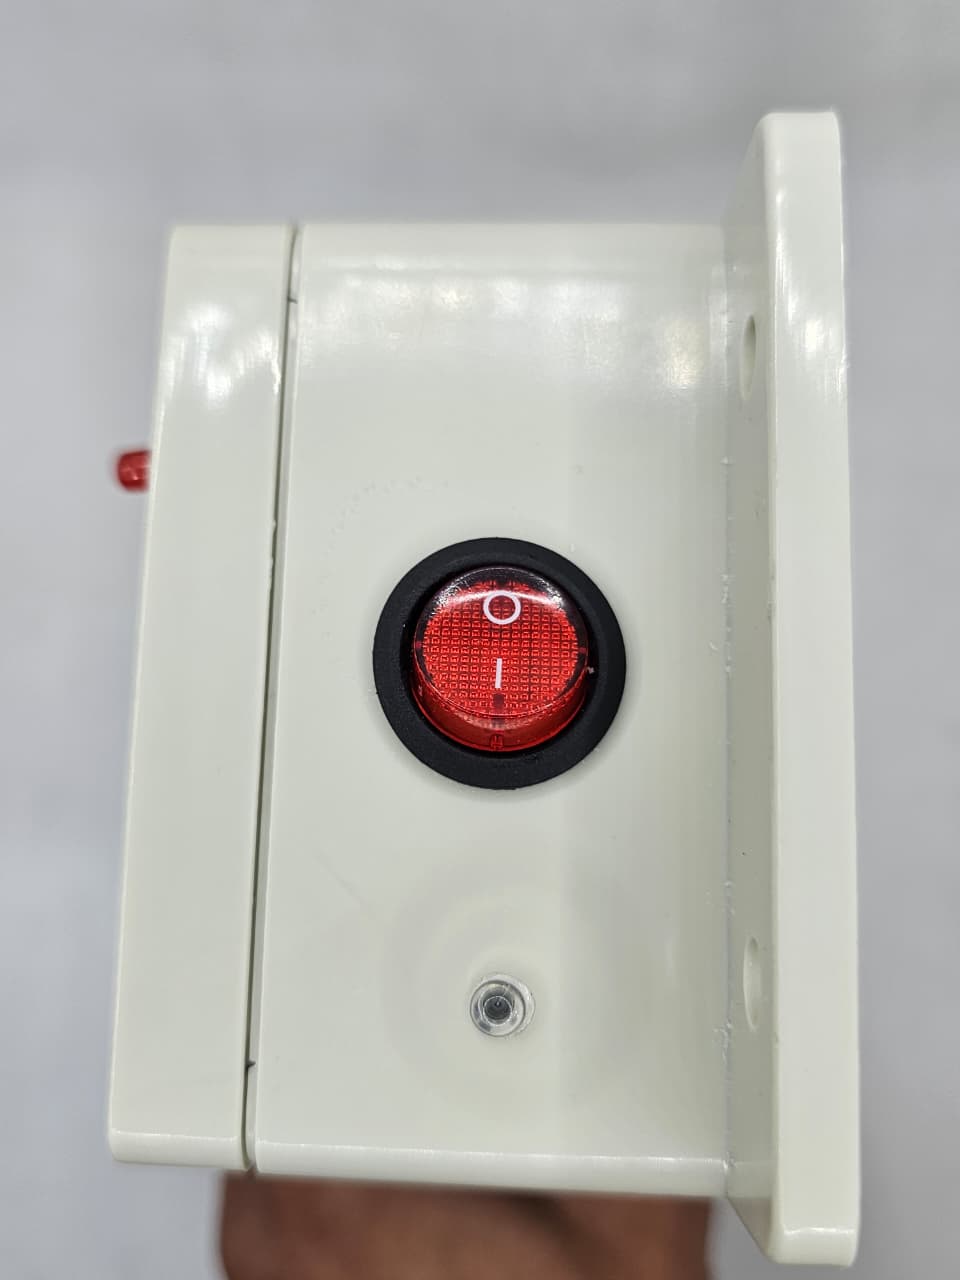
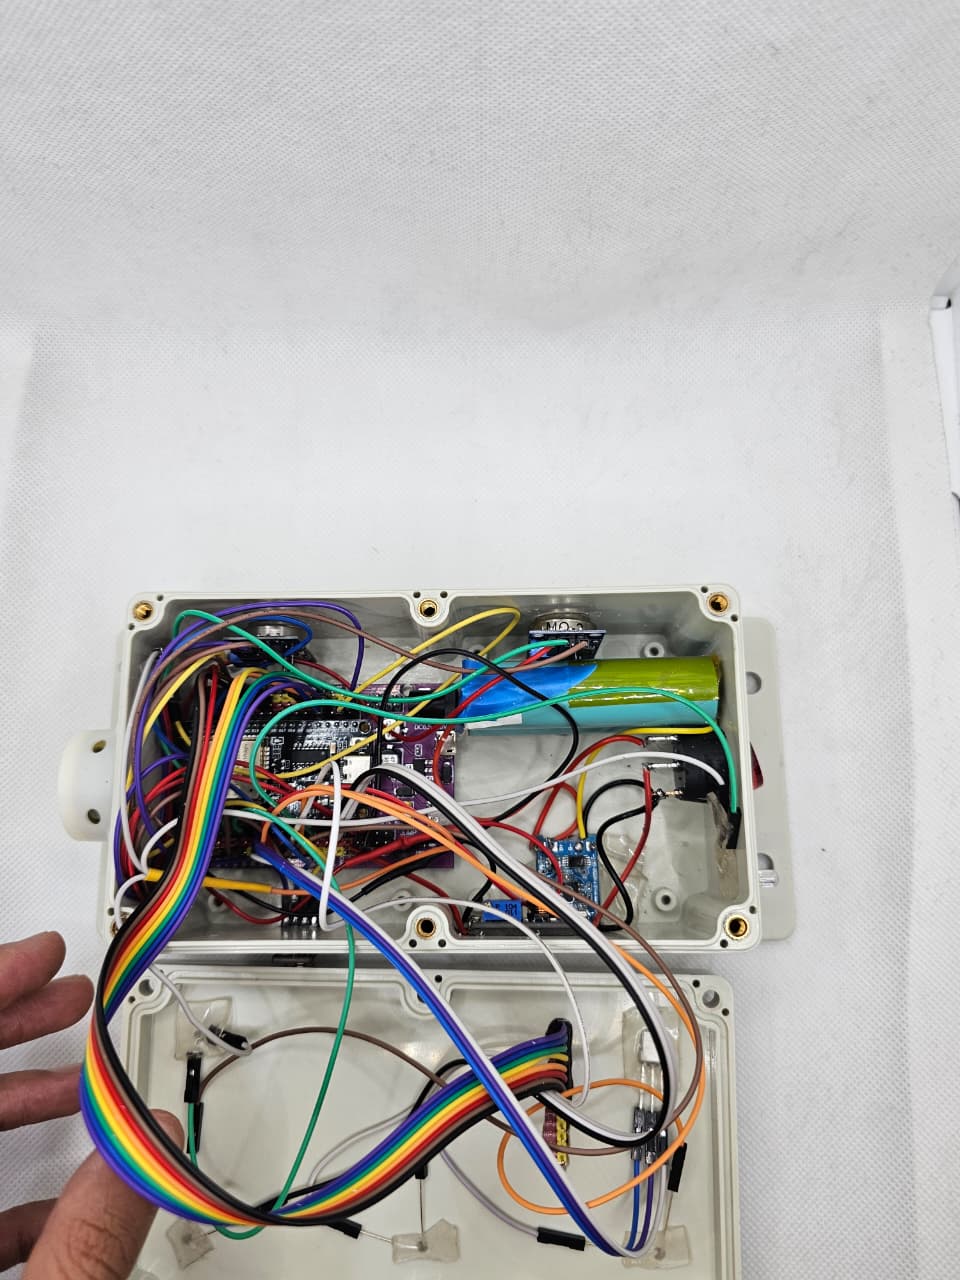
Smart Indoor Air Quality Control System
نظرا لصعوبة السيطرة على البيئة الخارجية وتحسينها لذا قررنا نصنع جهاز يعمل على تحسين البيئة الداخلية للابنية باقل كلفة. الجهاز مزود بمستشعرات (حرارة ورطوبة وضغط وغازات) وشاشة ومتحكم دقيق ونظام ذكي…
الفريق
الفريق الهندسي
رمز الفريق
NURAI2026-0351
المشرف
م.د. مها عبد الواحد عزت
قراءة الوصف الكامل للمشروع
نظرا لصعوبة السيطرة على البيئة الخارجية وتحسينها لذا قررنا نصنع جهاز يعمل على تحسين البيئة الداخلية للابنية باقل كلفة.
الجهاز مزود بمستشعرات (حرارة ورطوبة وضغط وغازات) وشاشة ومتحكم دقيق ونظام ذكي له القدرة على الرصد والتعلم الذاتي والتحليل الذكي واتخاذ القرارات لحظيا باستخدام ادوات ذكاء اصطناعي مجانية.
الجهاز يعطي مؤشر لمستوى جودة الهواء:
- الازرق وضع طبيعي وآمن.
- الاصفر وجود مشكلة قابلة للحل من خلال اعطاء اوامر للاجهزة الاخرى عن طرق الوايفاي او الاشعة تحت الحمراء لمعالجتها.
- الاحمر مع المنبه الصوتي وضع خطر يتطلب الاخلاء الفوري.
الجهاز يعمل على موازنة تلقائية للحراره عبر التحكم بنظام التكييف.
كذلك يتحكم بوحدات الترطيب او وحدات ازالة الرطوبة.
بالنسبة للغازات يتحكم بمنظومة التهوية.
الحماية المتقدمة:
الكشف عن غازات سامة مثل الميثان وايضا كشف وتوقع الحرائق قبل وقوعها وتحديد السبب وتفعيل منظومة اخماد الحريق.
الجهاز يمتاز بصغر حجمه وامكانية ربطه مع الاجهزة الاخرى وتقليل استهلاك الطاقة وكلفته لاتتجاوز 50 دولار وبطارية تعمل 8 ساعات قابلة للشحن عن طريق منفذ Type C وامكانية التحكم عن طريق الموبايل.
المسار الطبي
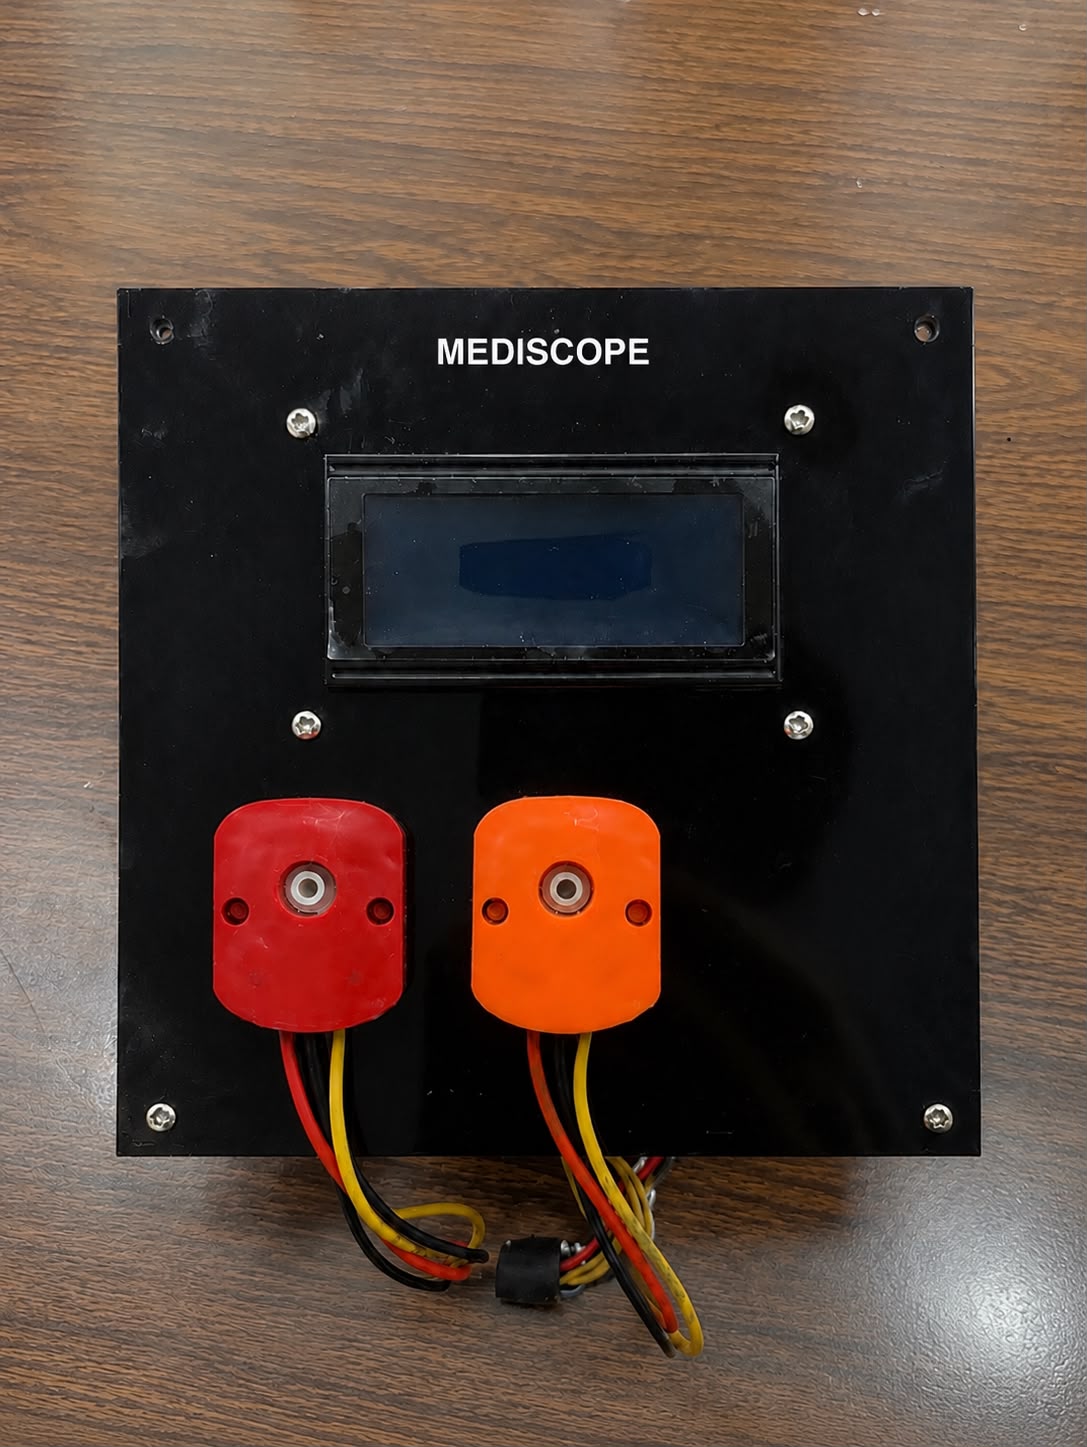
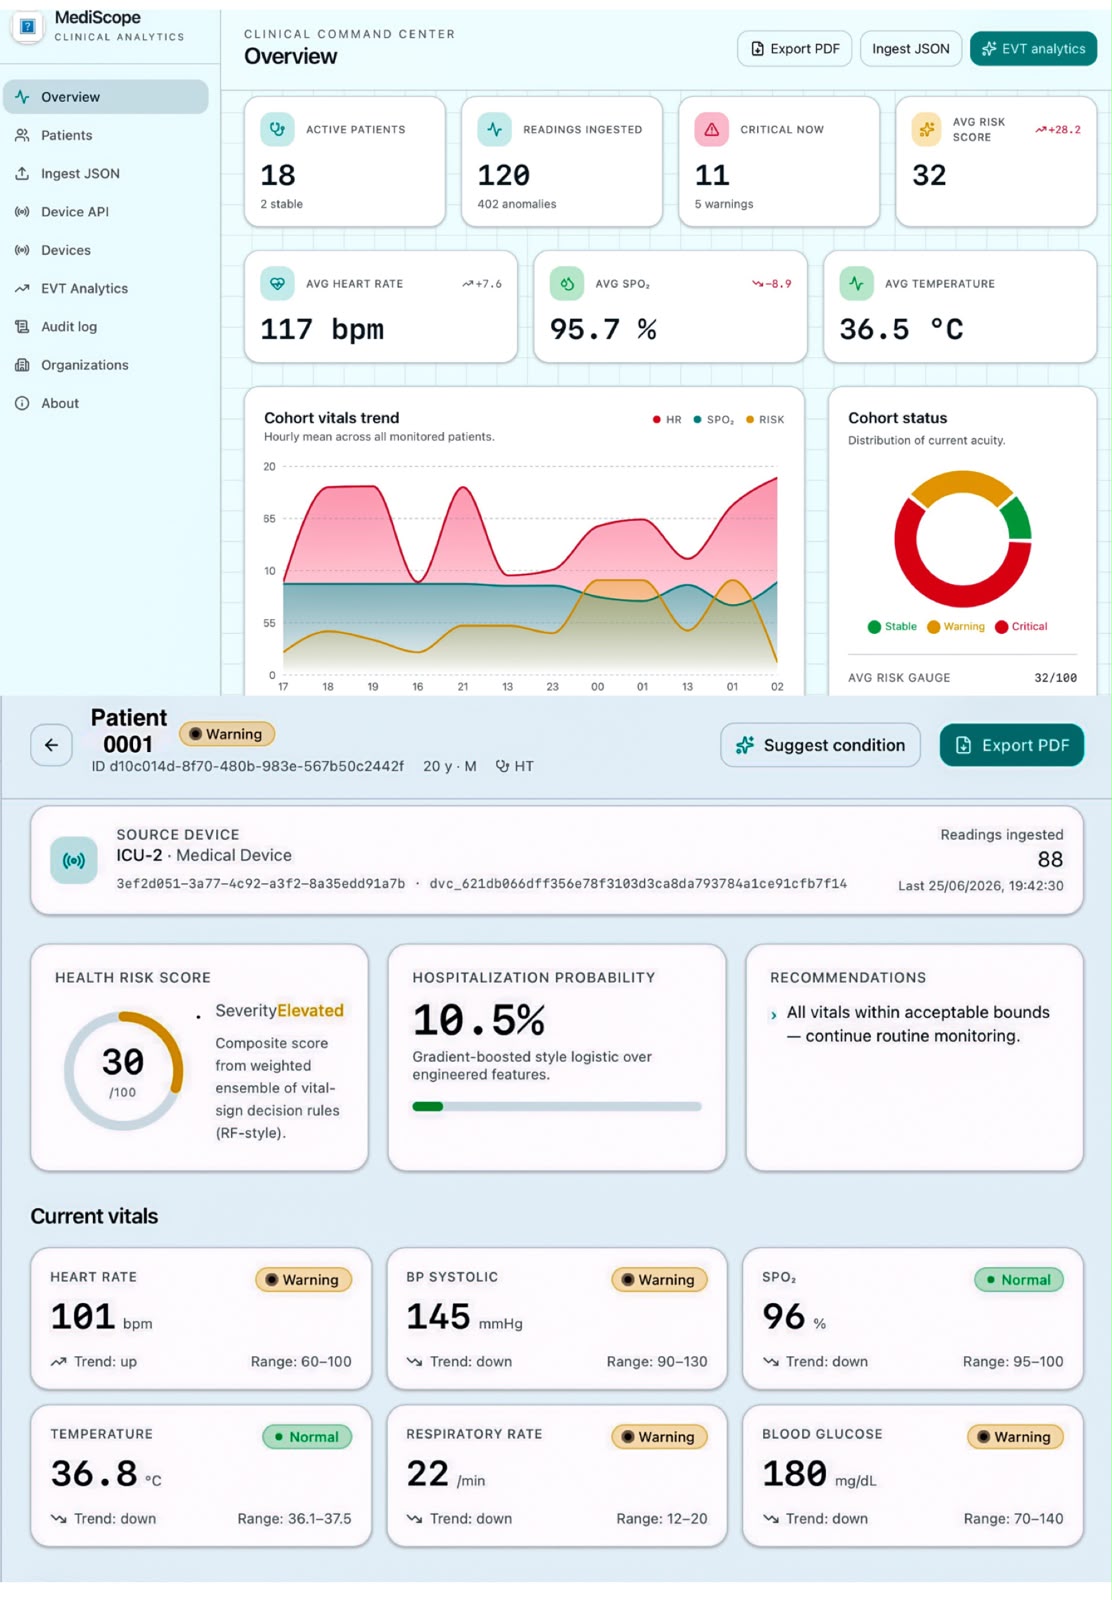
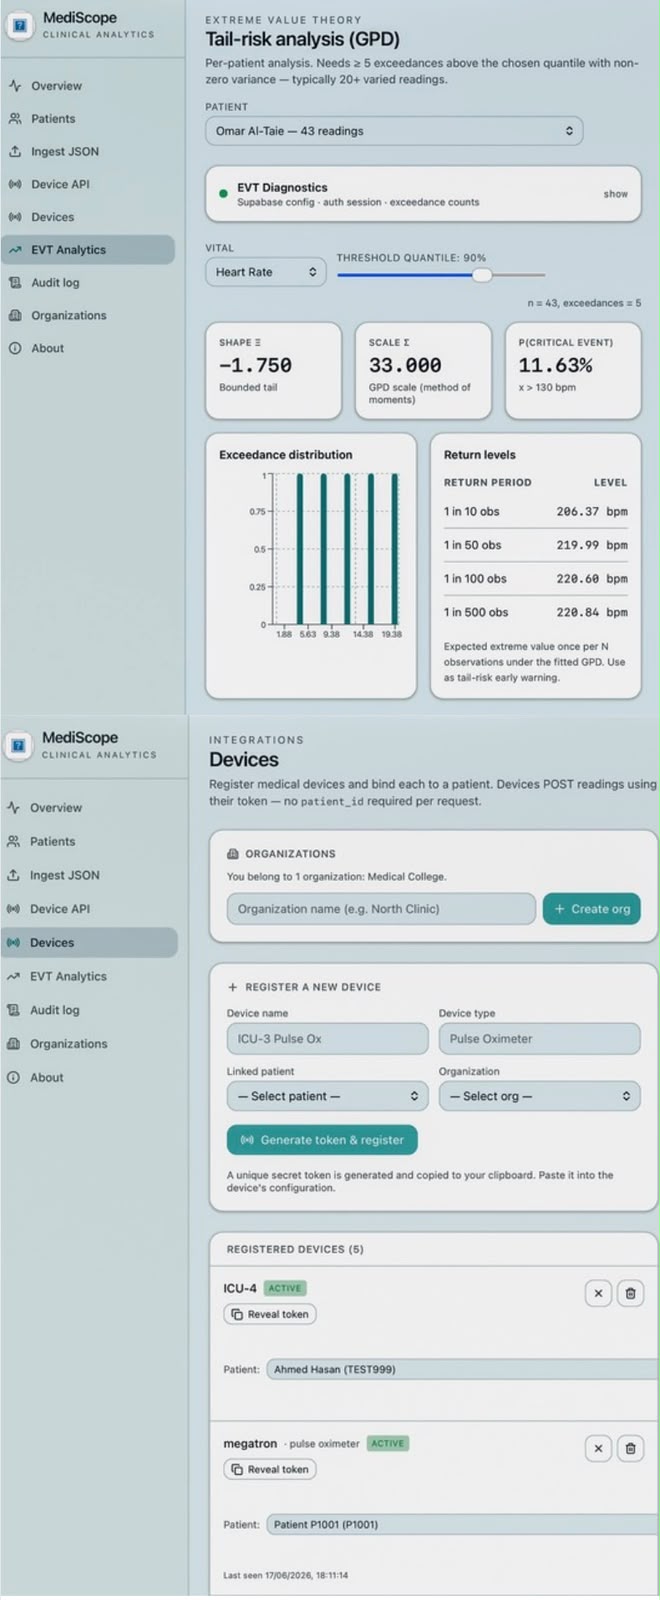
منظومة ذكية محمولة لدعم القرار الطبي تعتمد على دمج القياسات الحيوية غير الجراحية مع تحليل الأعراض والسجل الصحي والبيانات المختبرية والتنبؤ الزمني
يتعلق هذا الاختراع بنظام MEDISCOPE، وهو نظام دعم قرار طبي ذكي محمول يعتمد على تحليل غير جراحي للبيانات الحيوية للمستخدم بهدف تقديم تقييم صحي أولي فوري دون الحاجة إلى سحب عينات دموية. يستخدم النظا…
الفريق
Lexon
رمز الفريق
NURAI2026-0984
المشرف
أ.م.د.عمار محمد كامل
قراءة الوصف الكامل للمشروع
يتعلق هذا الاختراع بنظام MEDISCOPE، وهو نظام دعم قرار طبي ذكي محمول يعتمد على تحليل غير جراحي للبيانات الحيوية للمستخدم بهدف تقديم تقييم صحي أولي فوري دون الحاجة إلى سحب عينات دموية. يستخدم النظام وحدات استشعار حيوية تشمل مستشعرات PPG، ECG، حساسات الحرارة، إضافة إلى تحليل العرق والزفير والطيف الحيوي.
تُدمج البيانات الحيوية مع مدخلات المستخدم والتاريخ الصحي عبر طبقة دمج بيانات، ثم تُعالج باستخدام نماذج ذكاء اصطناعي تعتمد على التعلم الآلي وتحليل السلاسل الزمنية لإنتاج تقييم صحي يتضمن تقدير المخاطر والتنبؤ بالحالات المرضية وتقديم توصيات طبية أولية.
يدعم النظام إدخال نتائج التحاليل المختبرية الخارجية ودمجها ضمن التحليل، كما يتيح ربطًا اختياريًا ضمن شبكة صحية عائلية لتحليل العوامل الوراثية والبيئية. ويشمل آلية تحقق متعددة المستويات تعتمد على تكرار القياسات، مطابقة الأعراض، وتحليل السياق الزمني لتقليل الأخطاء، مع نماذج لاكتشاف الحالات الحرجة والتنبؤ بالأمراض المزمنة. كما يدعم الاتصال بالطبيب وتقنيات LoRaWAN للعمل في البيئات ضعيفة الاتصال