This project addresses a critical deficiency in the current landscape of indoor spatial mapping and digital twin generation, where traditional methods often fail to balance cost, accuracy, and ea…
الفريق
فريق الإبداع الفني
رمز الفريق
NURAI2026-0619
المشرف
أ.م.د. مهند قصي عبود
قراءة الوصف الكامل للمشروع
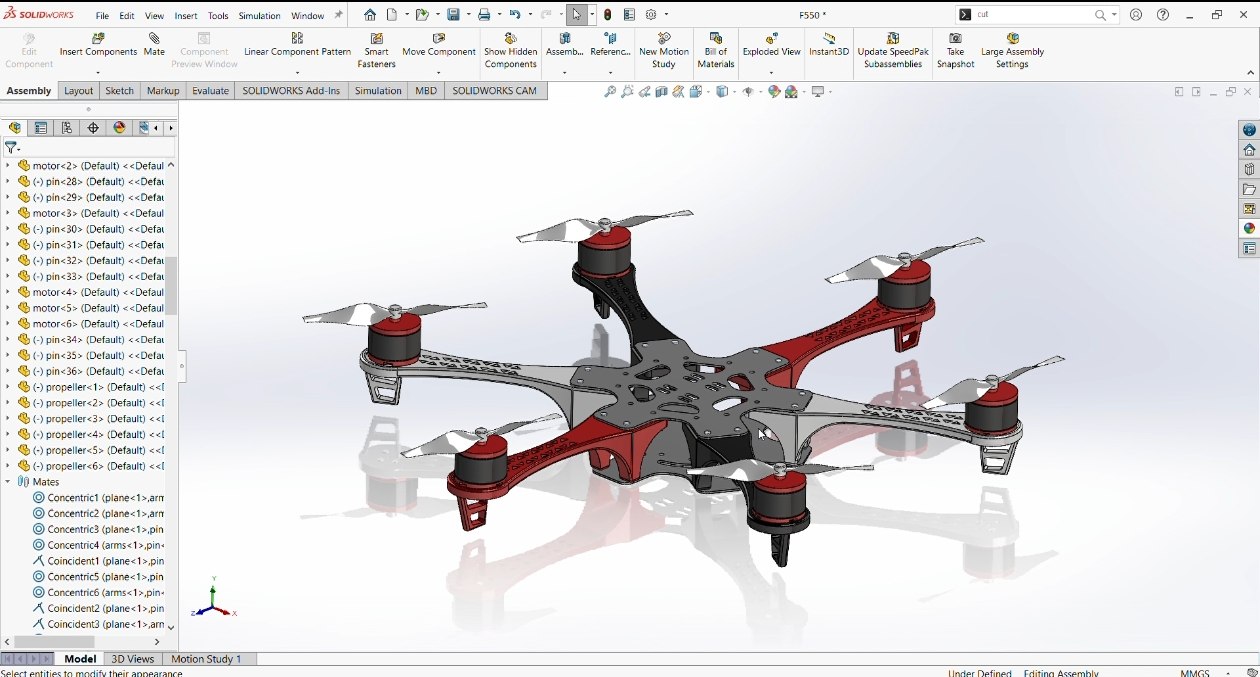
This project addresses a critical deficiency in the current landscape of indoor spatial mapping
and digital twin generation, where traditional methods often fail to balance cost, accuracy,
and ease of use. Our proposed solution is an autonomous, crash-resistant quadcopter,
structurally fabricated from 3D-printed PETG to ensure lightweight durability. Rather than
relying on prohibitively expensive or cumbersome professional scanning equipment, this
aerial platform utilizes an integrated smartphone to capture high-resolution imagery of
interior environments. The captured datasets are subjected to AI-driven analysis to generate
3D models (OBJ files), which are subsequently uploaded to Gemini AI for advanced
geometric optimization and structural refinement. This initiative aims to democratize access
to high-fidelity indoor surveying by providing a low-cost, highly maneuverable, and
automated aerial solution for complex architectural and engineering tasks.
مسار خدمة المجتمع
AI-Based Autonomous Fire Detection and Drone Suppression with Smart Docking for Large Facilities
The project presents an AI-based autonomous fire detection and extinguishing system designed to enhance rapid response to fire incidents. The system utilizes computers. vision algorithms integrat…
الفريق
innovation
رمز الفريق
NURAI2026-0587
المشرف
د.علي جبار داوود
قراءة الوصف الكامل للمشروع
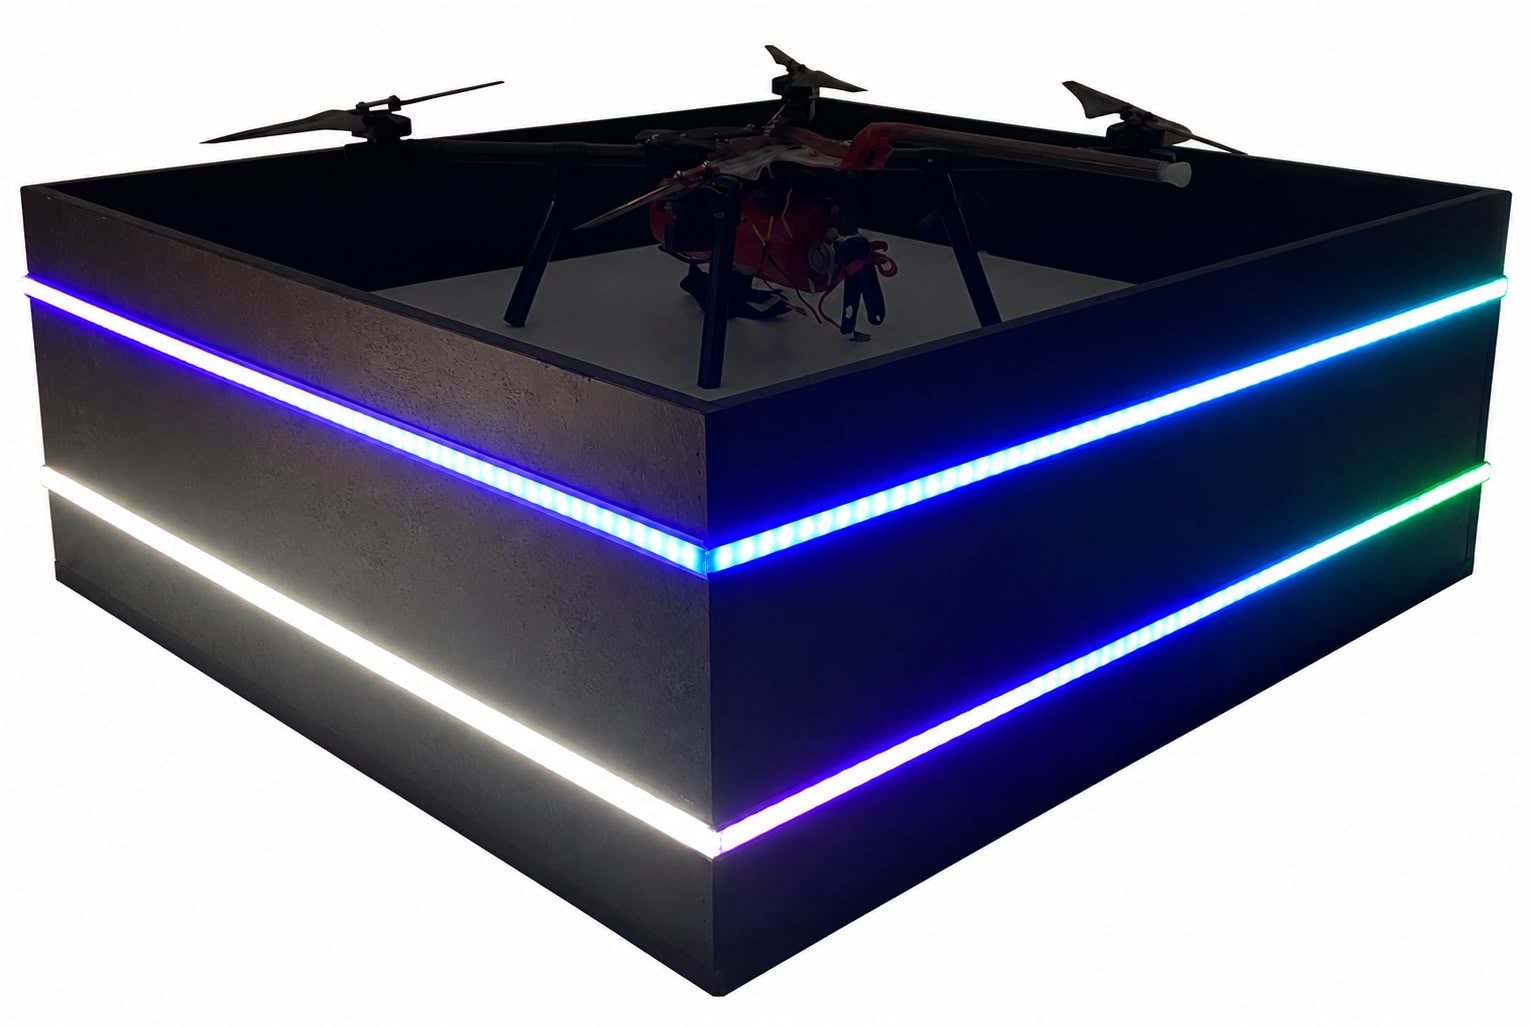
The project presents an AI-based autonomous fire detection and extinguishing system designed to enhance rapid response to fire incidents. The system utilizes computers. vision algorithms integrated with surveillance cameras to detect fire in real time. Once a fire is identified, an autonomous drone is deployed to the exact location of the detected event. The drone performs additional onboard visual analysis to precisely locate the fire source. Upon confirmation, a servo-actuated mechanism activates a fire extinguisher to suppress the fire efficiently. This approach aims to reduce response time, minimize human risk, and improve fire control in hazardous or challenging-to-reach environments.
المسار الصناعي
AI-Based Intelligent Control of a 6- DOF Robotic Arm for Safe Handling of Hazardous Matererials Using Computer Vision and Convolution Neural Network (CNN)
تعدّ مشكلة السلامة العملية في خطوط الإنتاج الخطرة هي نقل السوائل السامة والملوثة يدويًا يُعرّض العمال والعمليات للخطر. وللحدّ من هذا الخطر، صُمّم ذراع روبوتية بست درجات حرية مزوّدة بنظام رؤية يحد…
الفريق
Brain Tech
رمز الفريق
NURAI2026-0583
المشرف
أ.م.د.ايمان صالح كريم
قراءة الوصف الكامل للمشروع
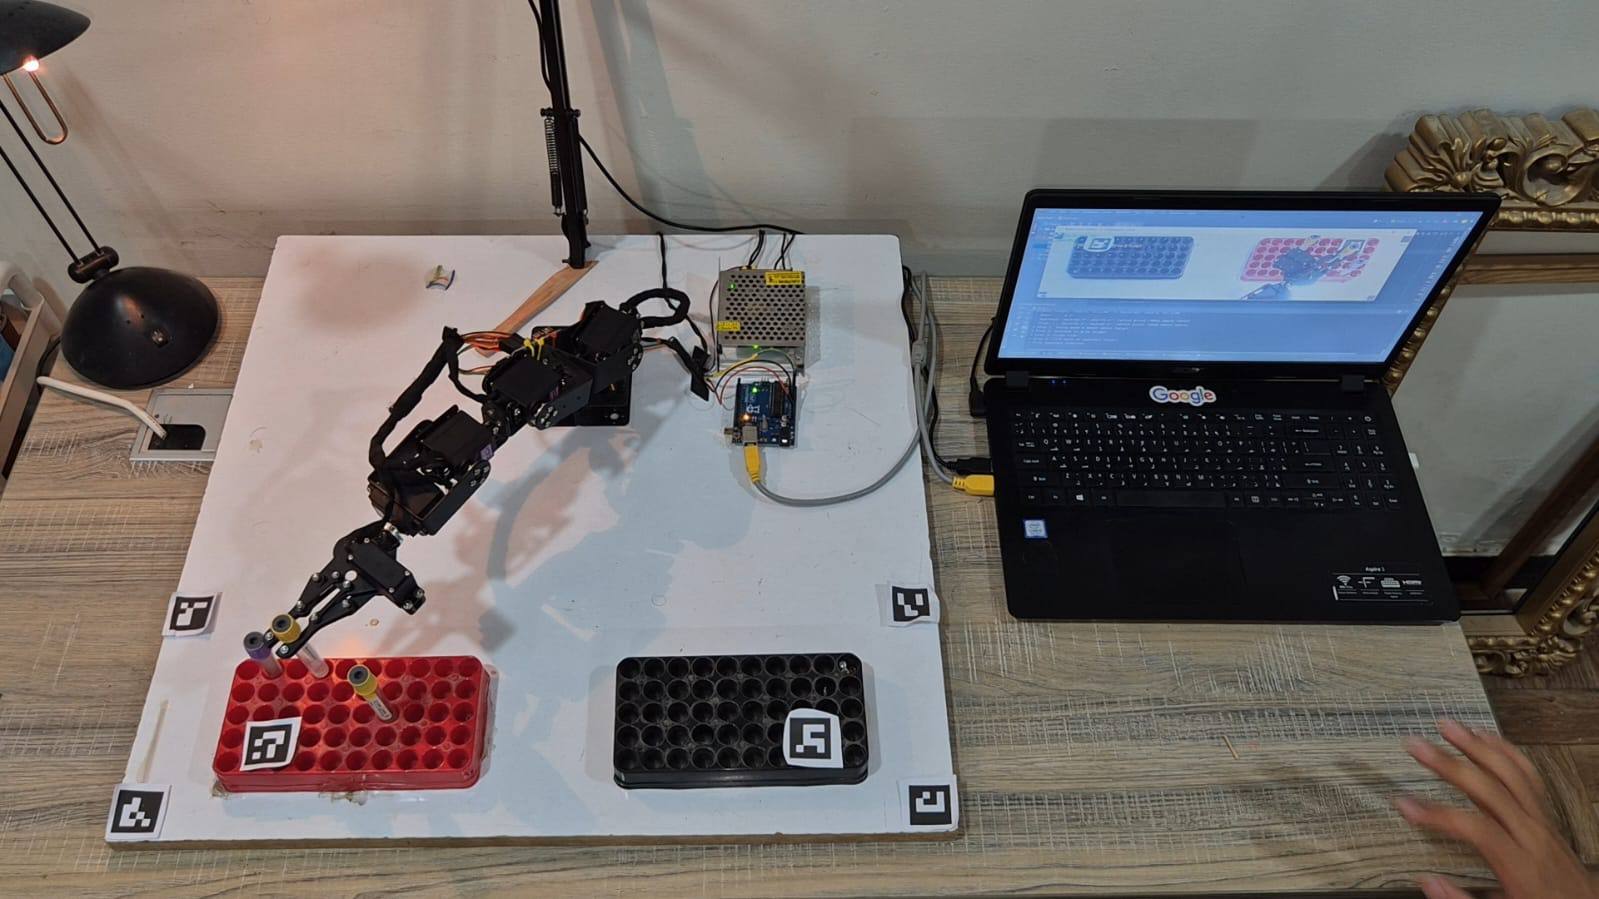
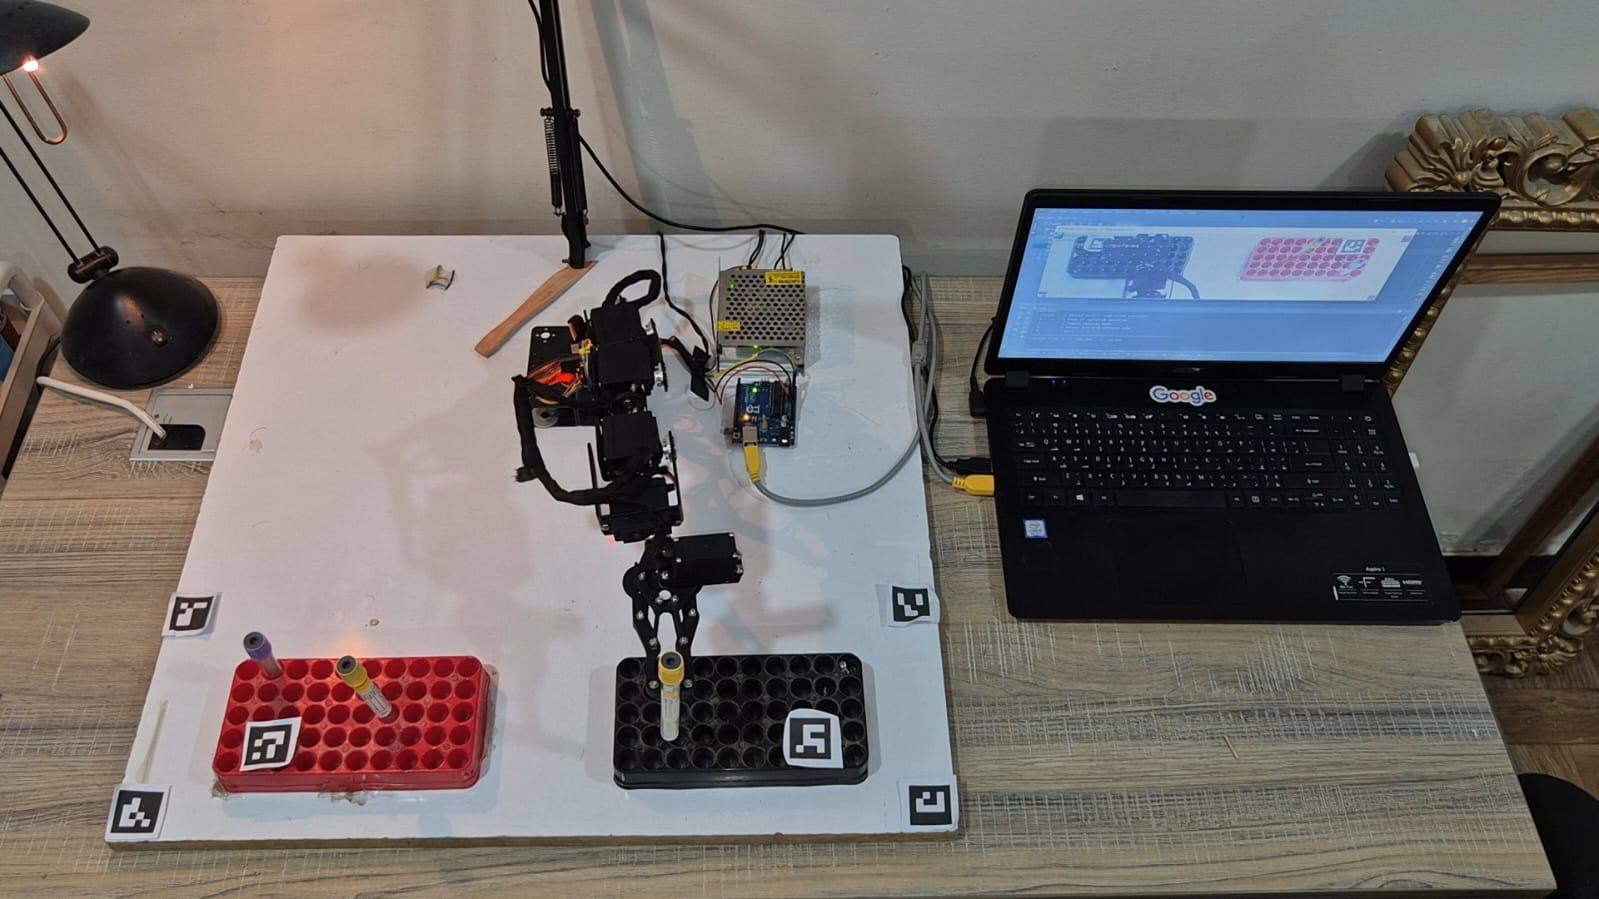
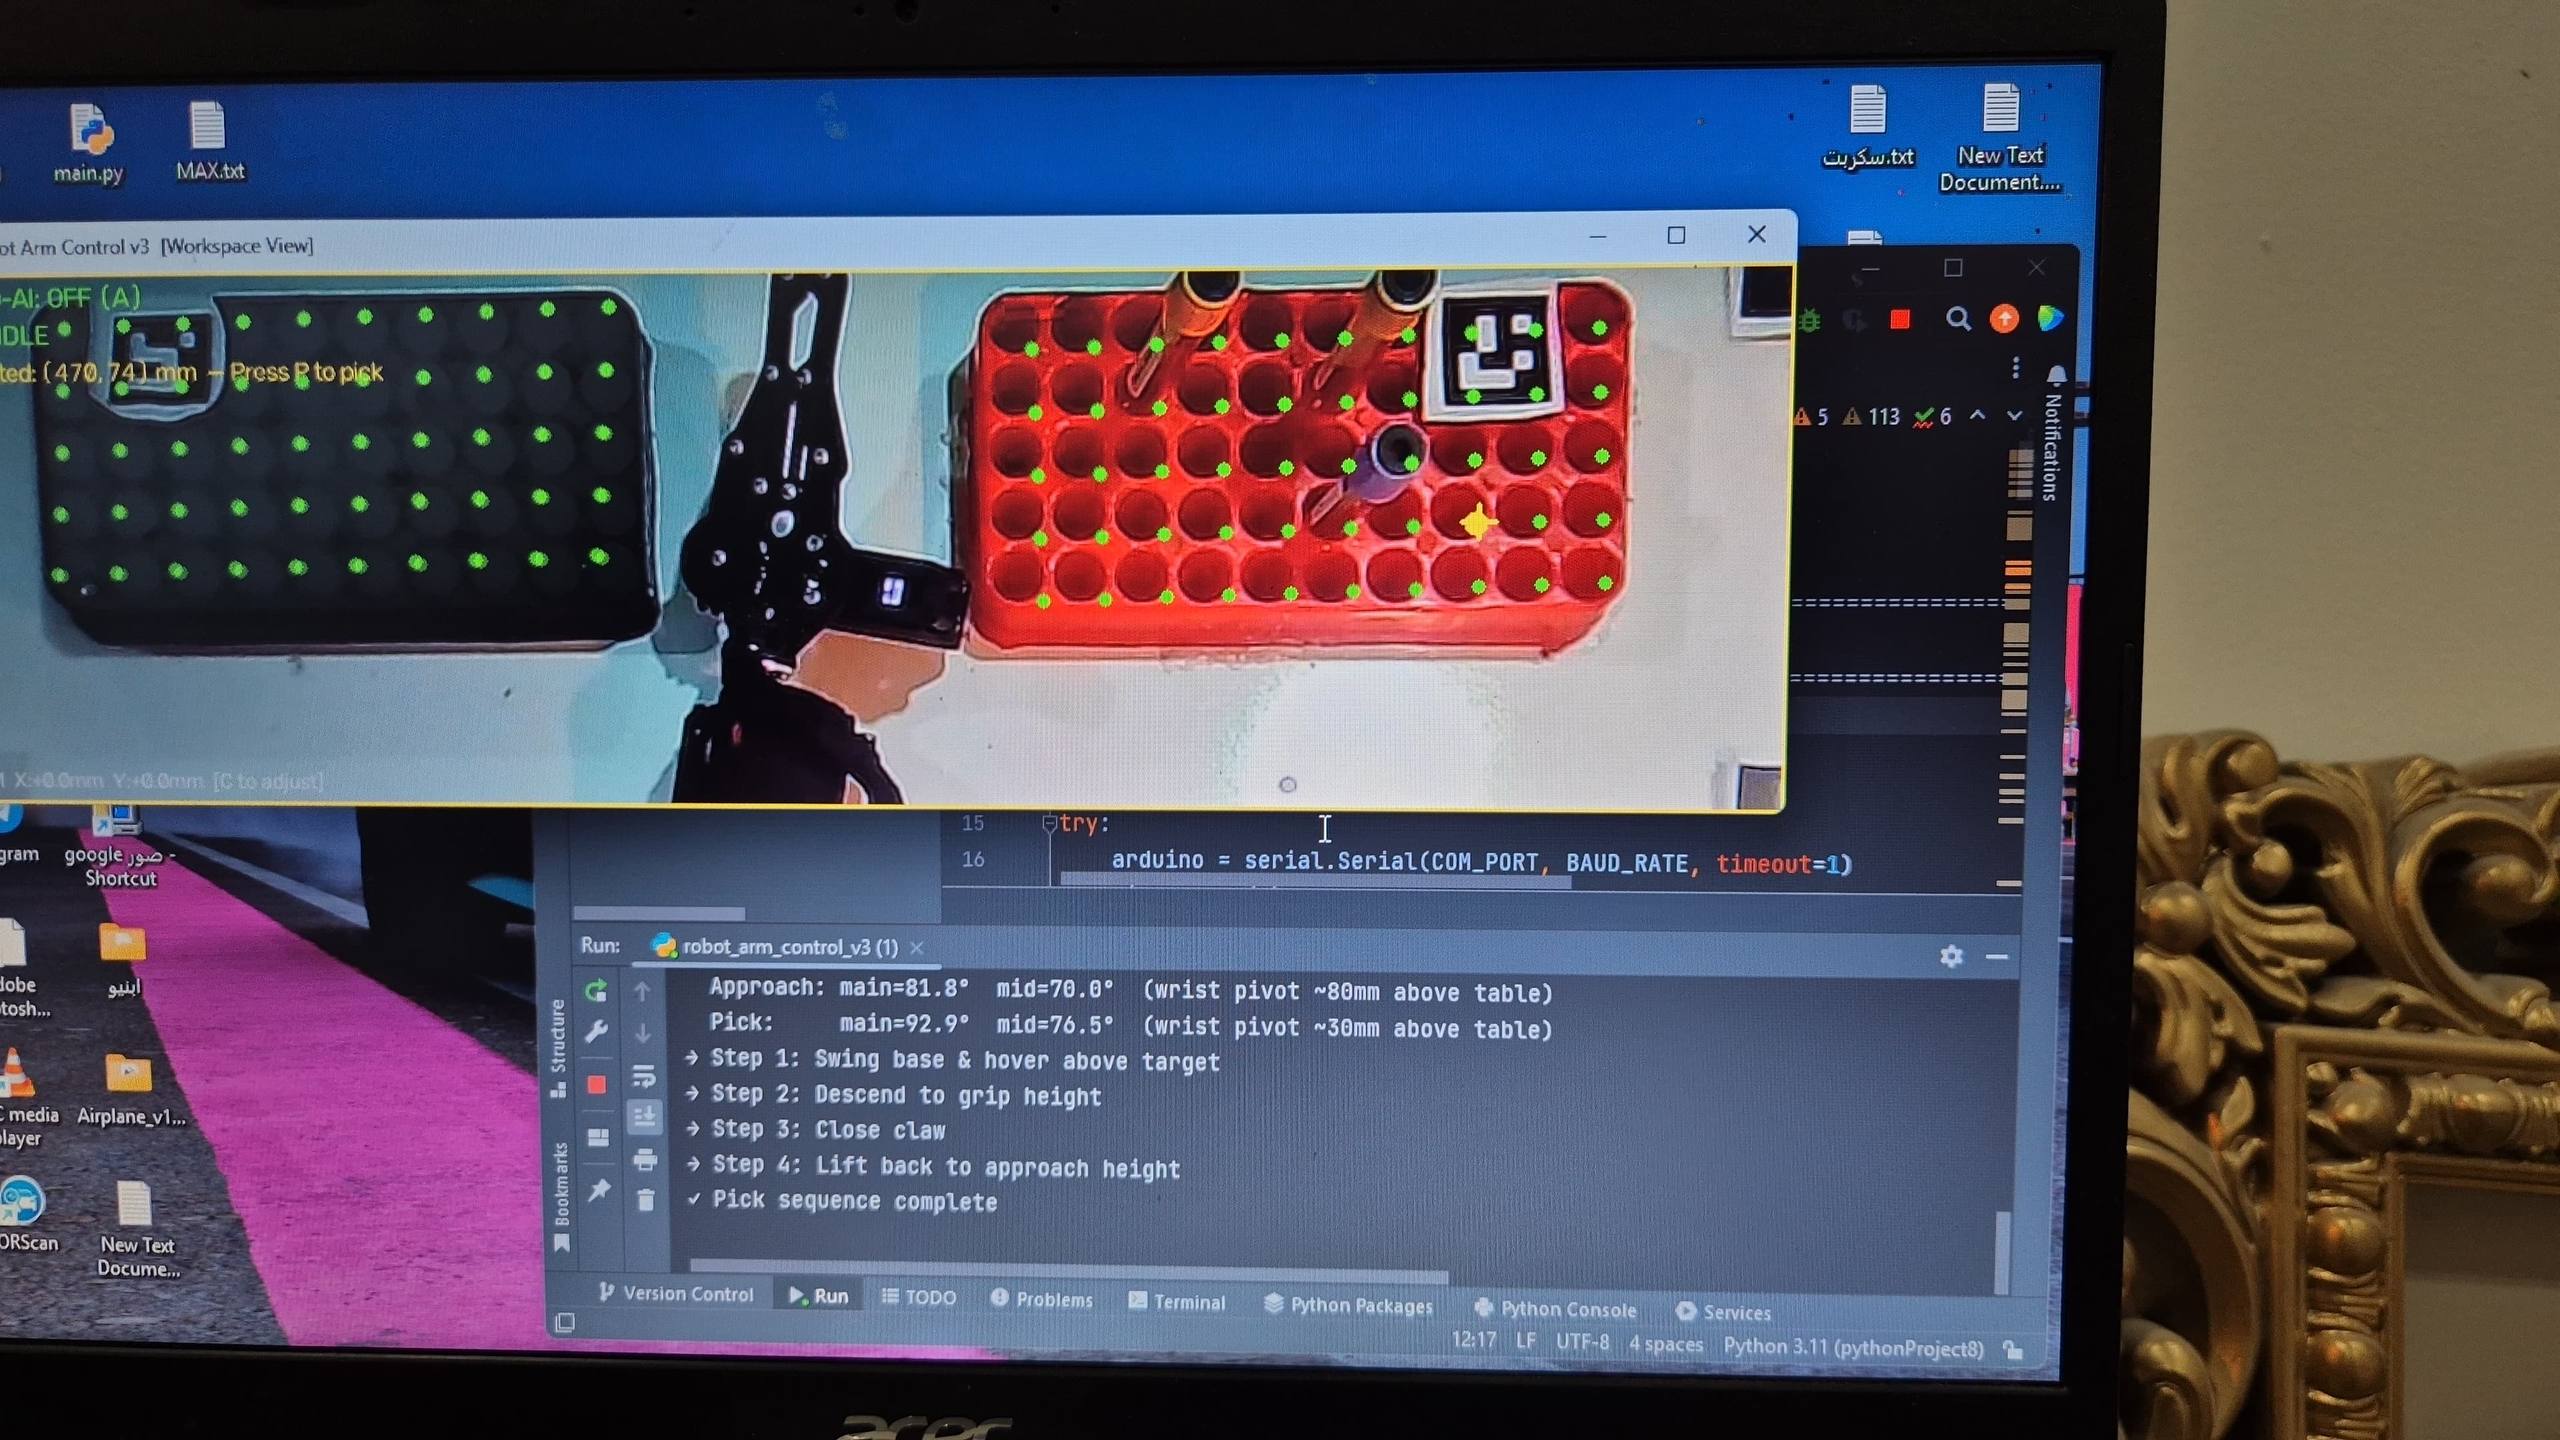
تعدّ مشكلة السلامة العملية في خطوط الإنتاج الخطرة هي نقل السوائل السامة والملوثة يدويًا يُعرّض العمال والعمليات للخطر. وللحدّ من هذا الخطر، صُمّم ذراع روبوتية بست درجات حرية مزوّدة بنظام رؤية يحدد مواقع الحاويات ويتعامل معها تلقائيًا. تستخدم الكاميرا خوارزمية معايرة تكيفية لتصحيح منظور العدسة وتحويل وحدات البكسل في الصورة إلى ملليمترات في العالم الحقيقي، ما يُمكّن الروبوت من معرفة مواقع الأجسام بدقة. تُستخدم الشبكة العصبيةالالتفافية لاكتشاف الاجسام من خلال معالجة بث الفيديو المباشر؛ حيث تستخلص الشبكة السمات المكانية من كل إطار باستخدام علامات رقمية لمعايرة مساحة العمل الديناميكية. وتعمل بنية الشبكة المعتمدة على التعلم العميق للكشف عن موقع الانبوب الذي يحتوي على المادة الخطرة بشكل فوري، كما يُنتج النموذج مربعات تحديد دقيقة لتعيين موقع الهدف بوحدة البكسل.يتميّز أداء النظام بالثبات، حيث يُجري عمليات نقل أفقية مع تعديل الحركة في الوقت الفعلي لتجنّب العوائق والحفاظ على مسافات آمنة من الأشخاص. في العمل التجريبي، الزمن المستغرق لدورة كاملة هو 15 ثانية مع سيطرة قوية ,اتّبع الذراع حركة صحيحة مع تخطيط دقيق للمسار. الشبكة العصبيةالالتفافية ميزت الحاويات بنجاح دون الاصطدام بعائق. لذا يُمكن لهذا النهج تقليل تعرّض الإنسان وجعل التعامل مع المواد الخطرة أكثر أمانًا وعملية في البيئات الصناعية
المسار الزراعي
AI-Enhanced Agricultural Drone for Pesticide Spraying and Palm Pollination
This project proposes solutions for different issues in agricultural industry, and specifically in pesticide spraying and palm pollination. While the traditional pollination and pesticide sprayin…
الفريق
فريق العظماء
رمز الفريق
NURAI2026-0615
المشرف
مازن غازي عبدالرزاق
قراءة الوصف الكامل للمشروع
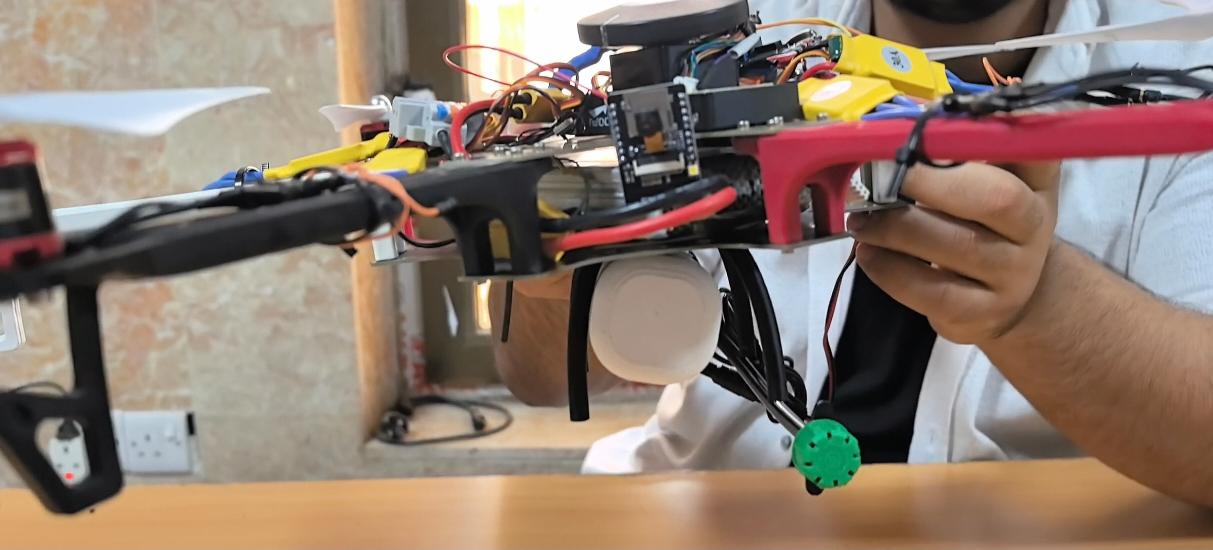
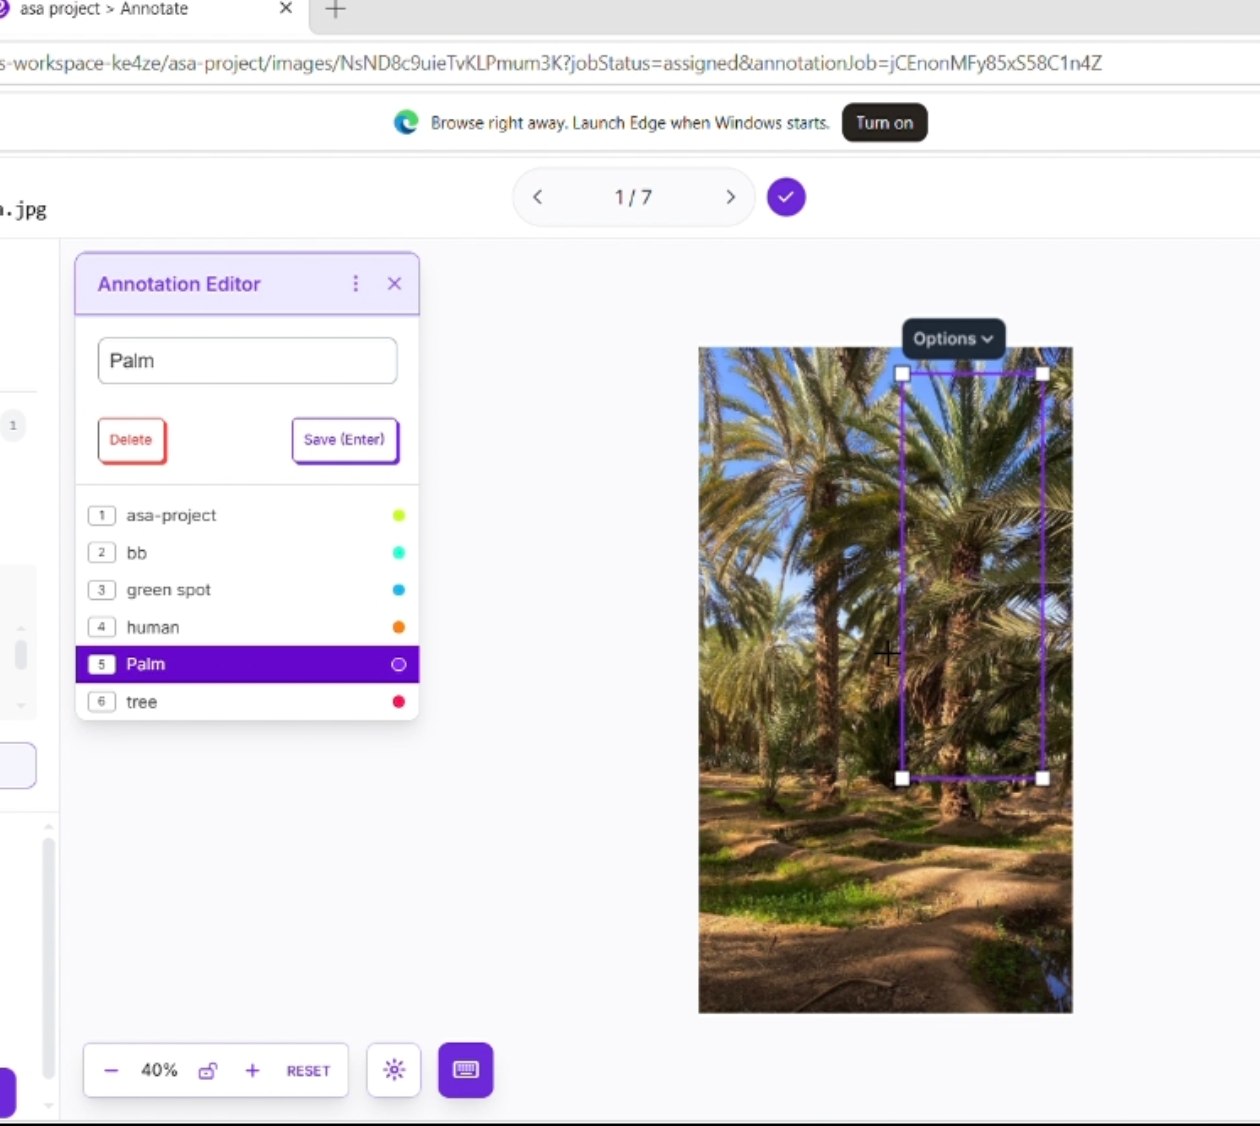
This project proposes solutions for different issues in agricultural industry, and specifically in pesticide spraying and palm pollination. While the traditional pollination and pesticide spraying consume a lot of effort and time from the workers and may cause health risks, the new technologies supported with artificial intelligence (AI) tools can sort out such issues. In this work, a design and manufacturing of a Hexacopter drone have been presented. It precisely achieves the pesticide spraying and palm pollination tasks smartly. The main system enhanced with a Pixhawk controller to maintain stable and safe flight of the drone. Also, an ESP32 camera has been added to detect palms, trees, green spot, and human along with YOLO smart detection system. Furthermore, a fully controlled pumping system has been designed and attached to the drone to start the operations automatically simultaneously with the detection. However, this project aims to develop a low-cost prototype of a smart drone that can improve agricultural work by reducing the time, effort, and risks. While the proposed drone represents a practical step into smart farming, a final product intended for large-area coverage should have a high payload capacity to carry a larger tank.
المسار الصناعي
AI-Enhanced Automated 4-Axis Hot Wire Foam Cutting Machine
This project demonstrates the architectural design, and manufacturing processes, and implemented AI tools involved in the proposed automated four-axis computer numerical control (CNC) hotwire foa…
الفريق
Orbit Team
رمز الفريق
NURAI2026-0614
المشرف
د. مازن غازي عبد الرزاق
قراءة الوصف الكامل للمشروع
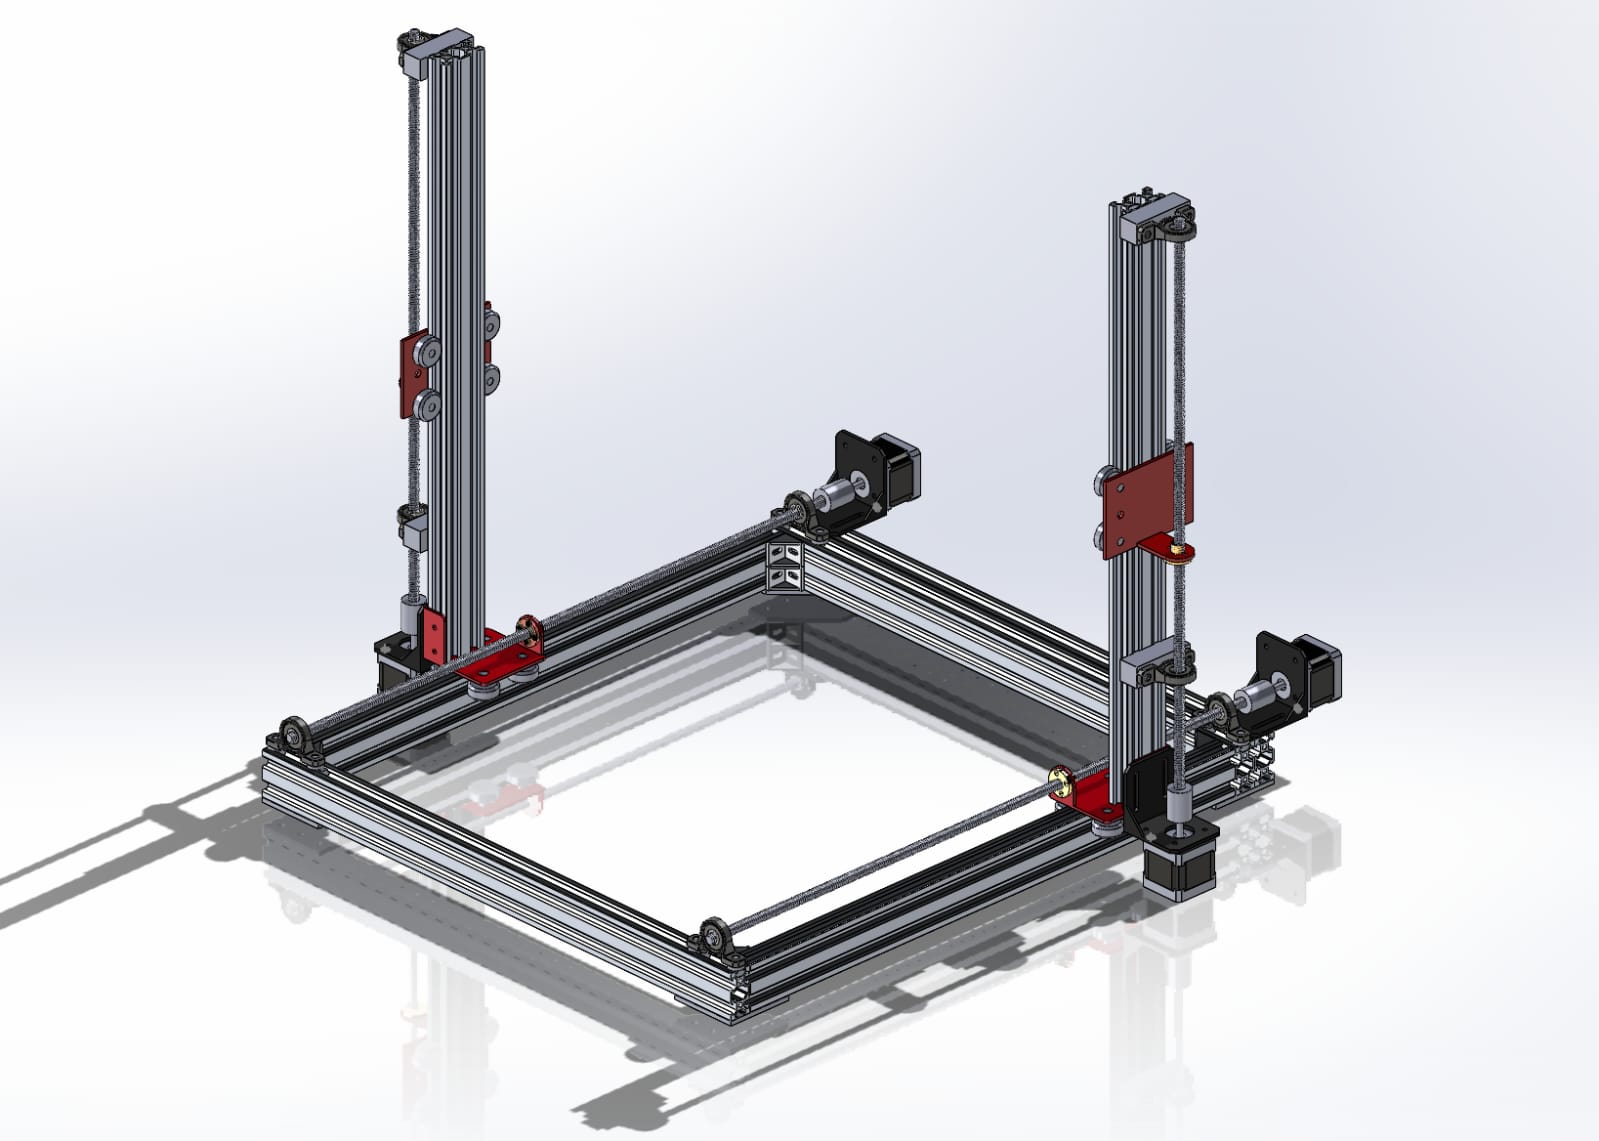
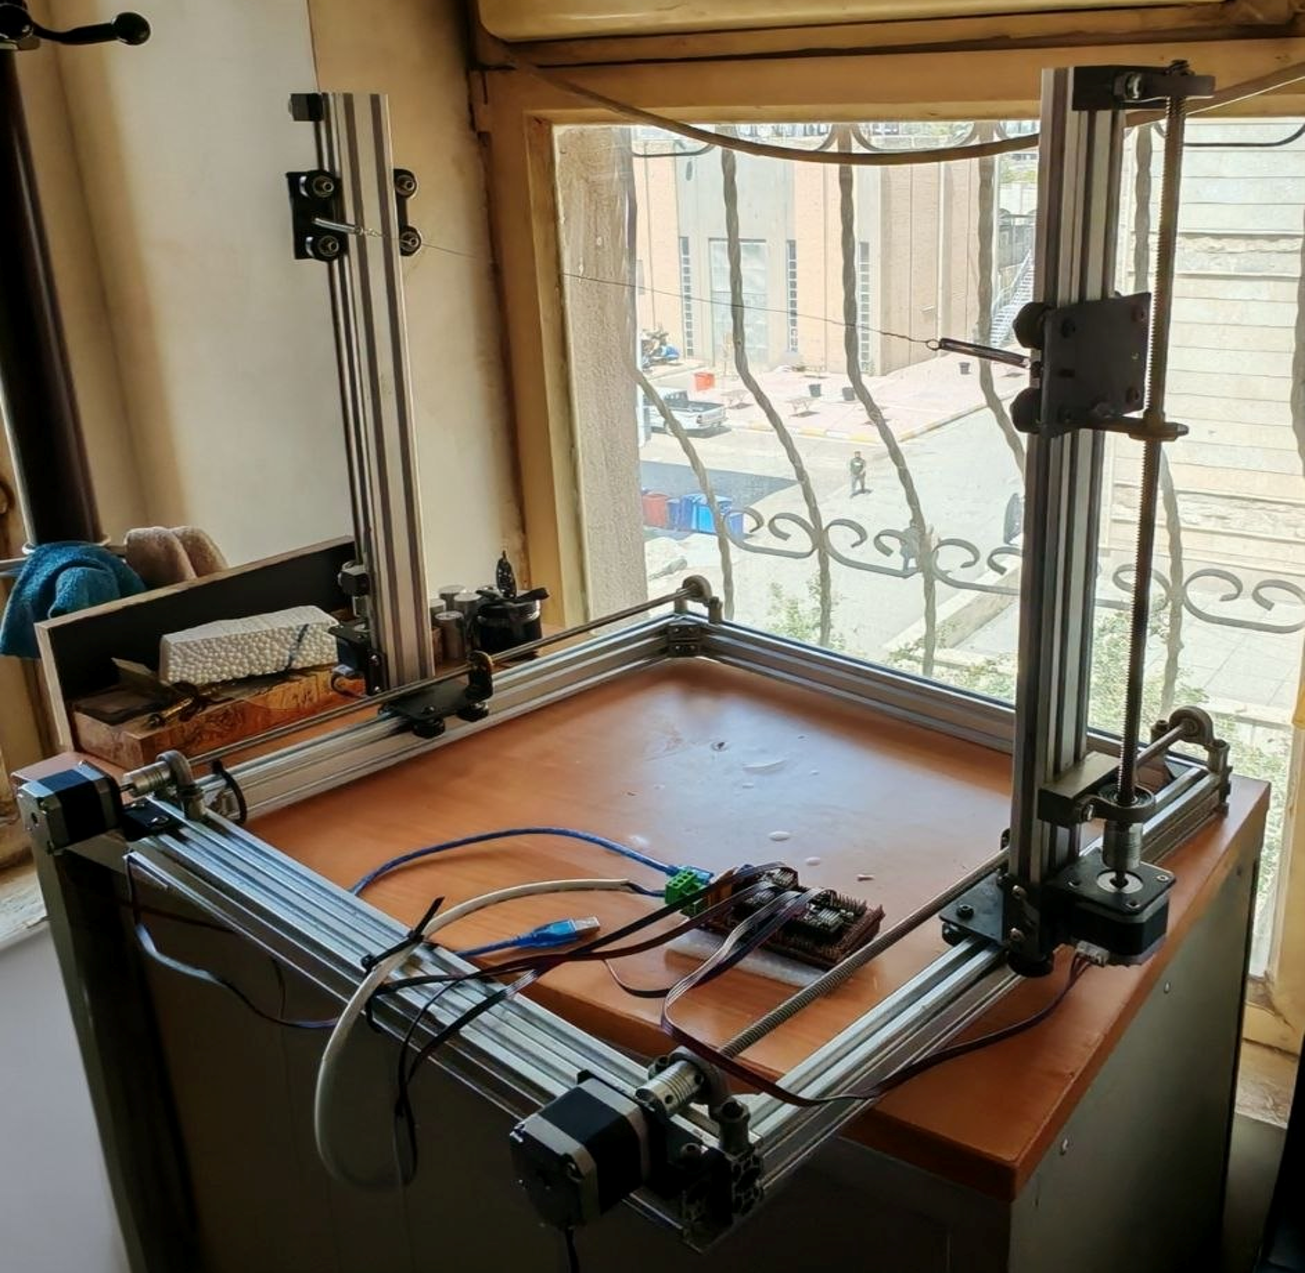
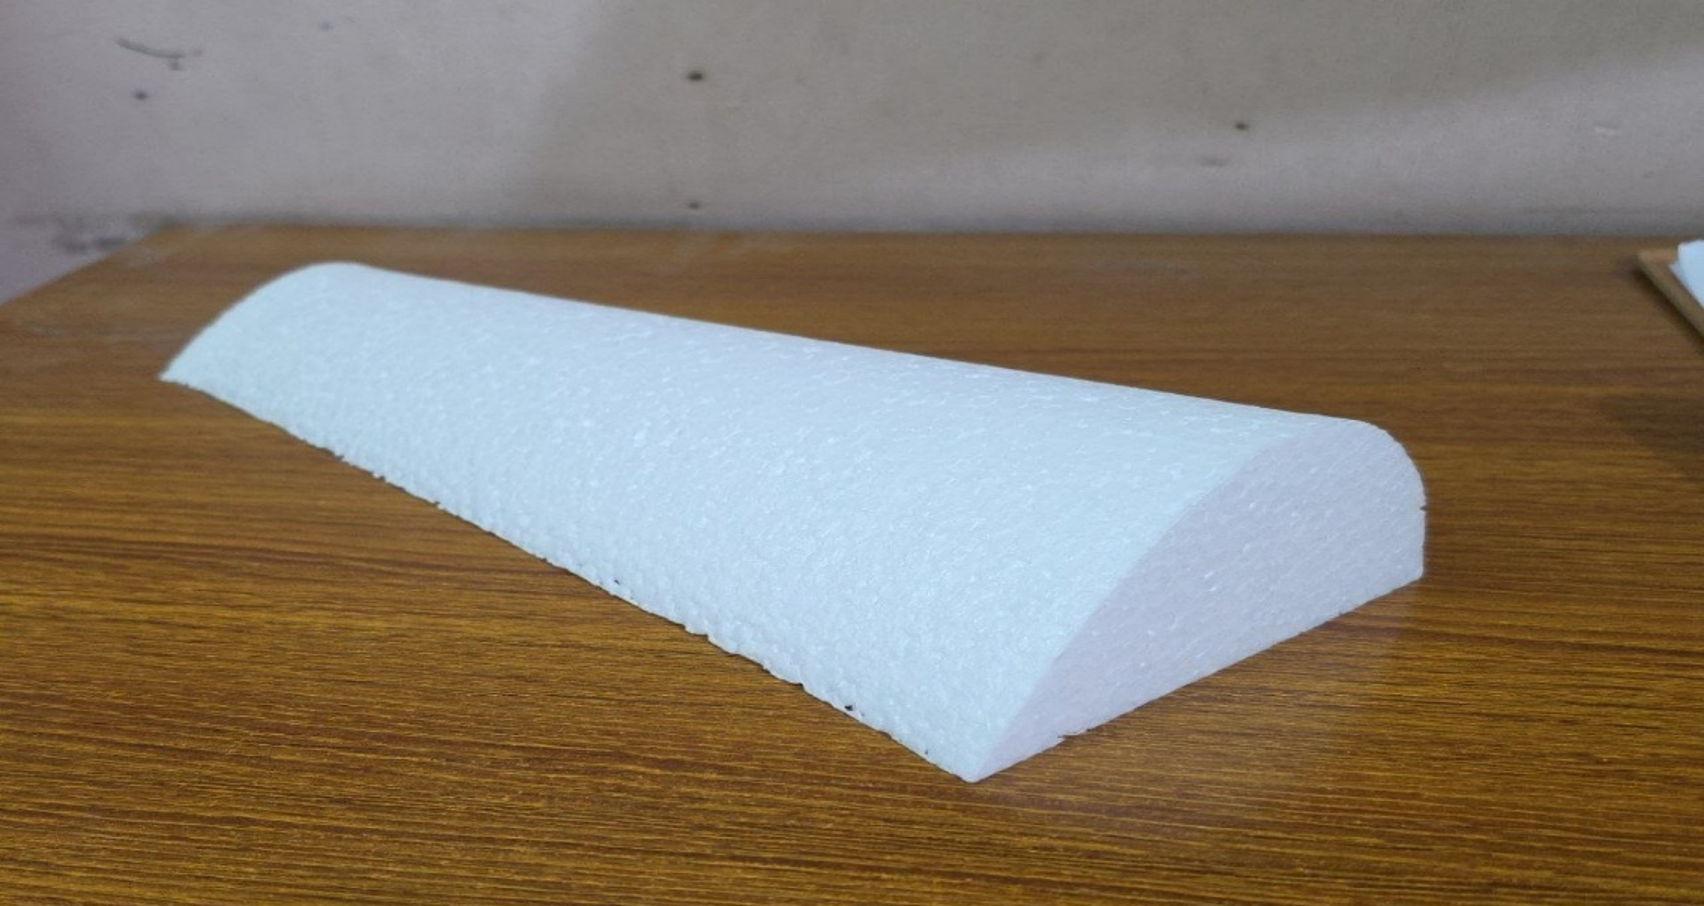
This project demonstrates the architectural design, and manufacturing processes, and implemented AI tools involved in the proposed automated four-axis computer numerical control (CNC) hotwire foam cutting machine. The aim is to cut extruded polystyrene (EPS/XPS) foam three-dimensions (3D) profiles in an optimal time while keeping consistent precise cuts. The machine was designed using SOLIDWORKS software and fabricated via different techniques including wire-cutting, sheet metal bending, and welding. The Grbl Hot Wire software is used to control the proposed machine; however, it is not open source and therefore cannot be modified. To overcome this limitation, the Cursor IDE AI tool is employed to enhance the original software by adding an extension window, integrated with the Gemini chatbot, alongside the Grbl interface. This enhancement enables the conversion of images, CAD models, and other supported file formats into editable and customizable G-code. The generated G-code is then transmitted to the 4-axis machine through an Arduino Mega controller, which can be readily upgraded to accommodate future enhancements and additional functionalities. A Molybdenum hotwire was chosen for the cutting based on the criteria of being the cheapest and available yet most suitable option for this application. Furthermore, other calculations were implemented to make sure that all the energy consumption, wire elongation and ideal cutting temperature match the desired goal. The final outcome of this project is a machine moves within four-dimensional coordinate framework (X-Y-Z-A) which can easily be upgraded into 5-axis or more, that allows it to execute asymmetrical, highly tapered and transitionary geometries like aerodynamic and airfoils. While the machine presents an outstanding dimensional accuracy, it is also considered a full platform cost-effective, upgradable, highly scalable and an adequate rapid prototyping choice.
المسار الصناعي
AI-Powered Autonomous Delivery Drone
Road congestion and a rapidly growing delivery economy make last-mile logistics in Iraqi cities slow, costly, and unreliable. This paper presents our project: a low-cost autonomous delivery drone…
الفريق
Metalhead
رمز الفريق
NURAI2026-0630
المشرف
رنا محمد حسن زكي
قراءة الوصف الكامل للمشروع
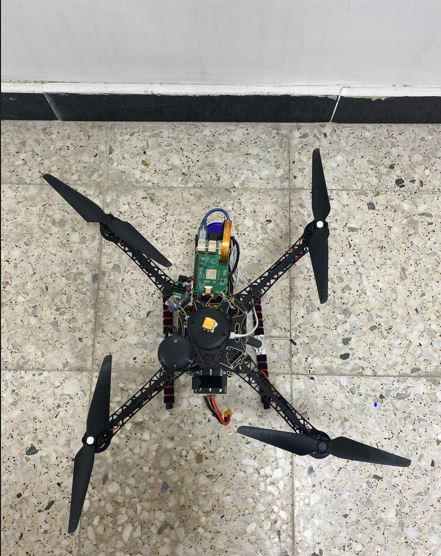
Road congestion and a rapidly growing delivery economy make last-mile logistics in Iraqi cities slow, costly, and
unreliable. This paper presents our project: a low-cost autonomous delivery drone built on the Holybro S500 V2
quadcopter with a Pixhawk 6C Mini flight controller running ArduPilot, supervised by a Raspberry Pi 5 companion
computer with a 13-TOPS Hailo-8L AI accelerator. The system performs the complete delivery mission
autonomously—takeoff, obstacle-aware cruise, arrival notification, operator-confirmed package release, and
automatic return to launch—while a custom web ground-control dashboard provides the live map, camera and
LiDAR feeds, telemetry, and a complete audit log. Onboard edge AI runs object detection in real time, and the
navigation layer uses smart algorithms including advanced robot path planning, Dijkstra-based route selection,
and 360° 2-D LiDAR obstacle avoidance with hard-stop and side-step policies. The full mission pipeline was
validated end-to-end over the University of Technology campus in Baghdad, demonstrating a practical, affordable
path toward delivery drone services in Iraq
المسار البيئي
An Edge-First Multi-Agent System for Predictive Environmental Risk Monitoring
تعد مراقبة جودة الهواء في البيئات الحضرية المزدحمة تحدياً كبيراً بسبب اعتماد الأنظمة التقليدية على الحوسبة السحابية وما يرافقها من تأخير وضعف في الاعتمادية. تقدم هذه الورقة محطة ذكاء بيئي تعمل عل…
الفريق
فريق البيئة
رمز الفريق
NURAI2026-0627
المشرف
قمر قاسم محمد
قراءة الوصف الكامل للمشروع
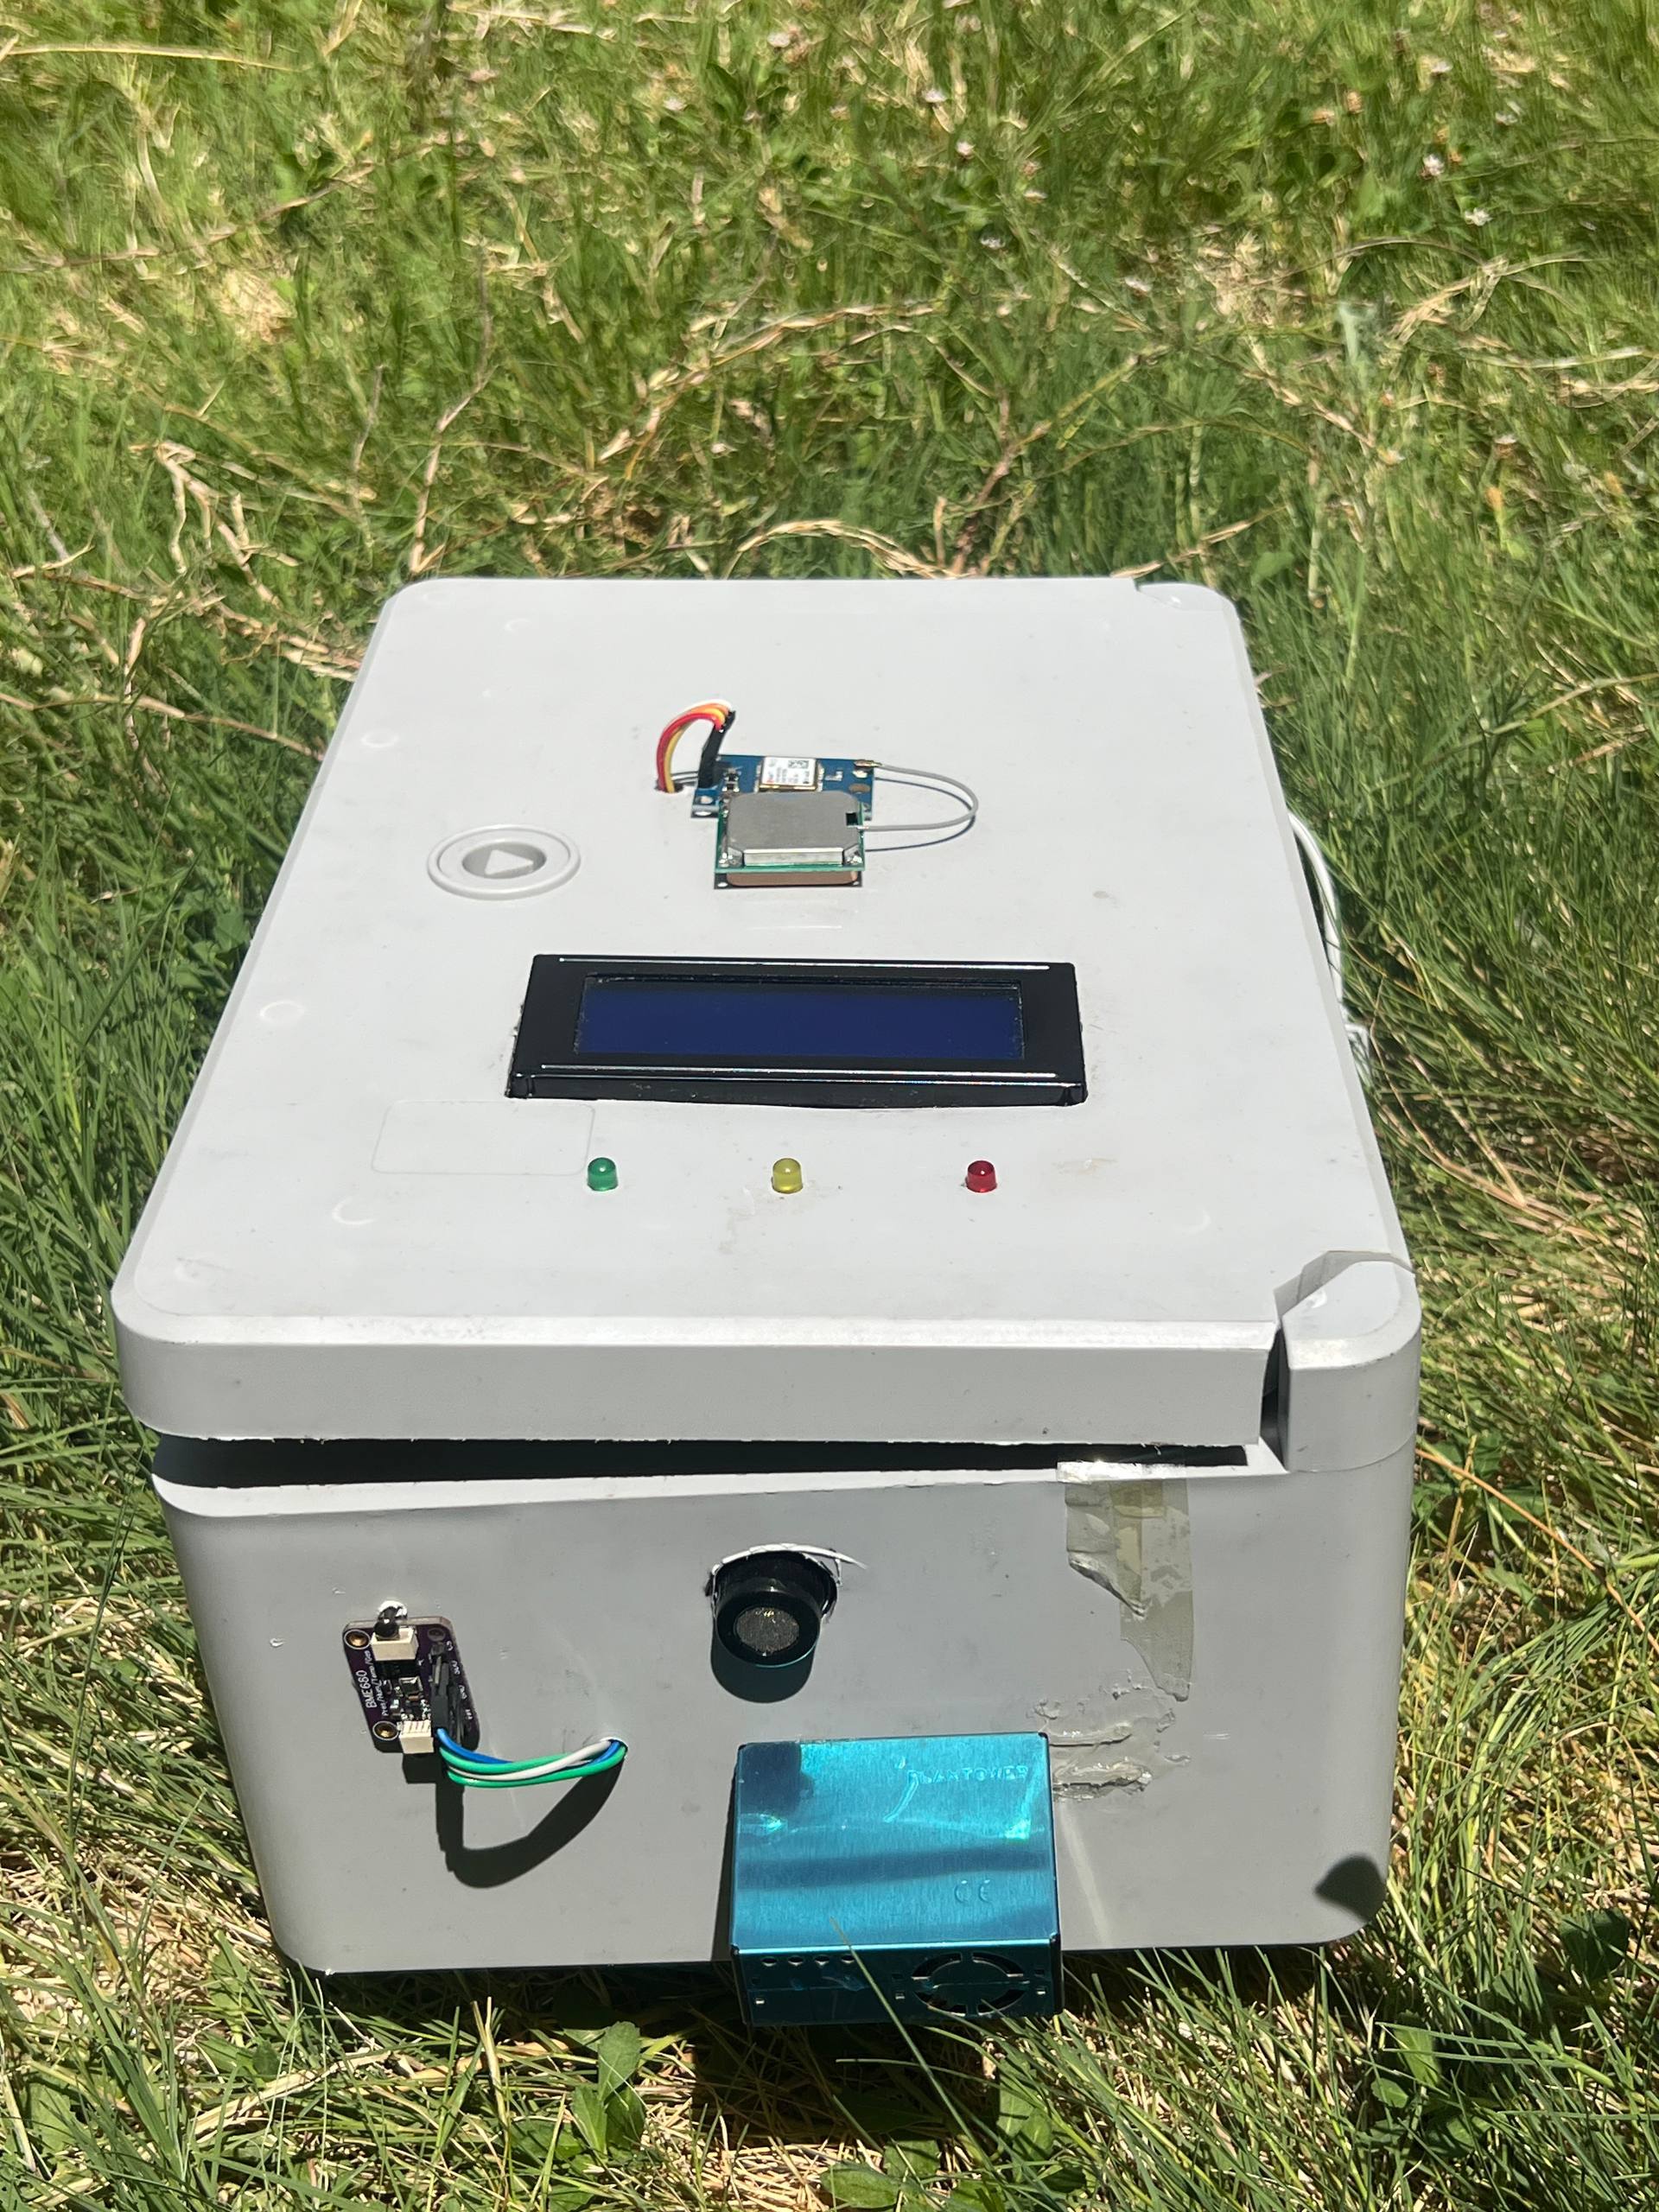
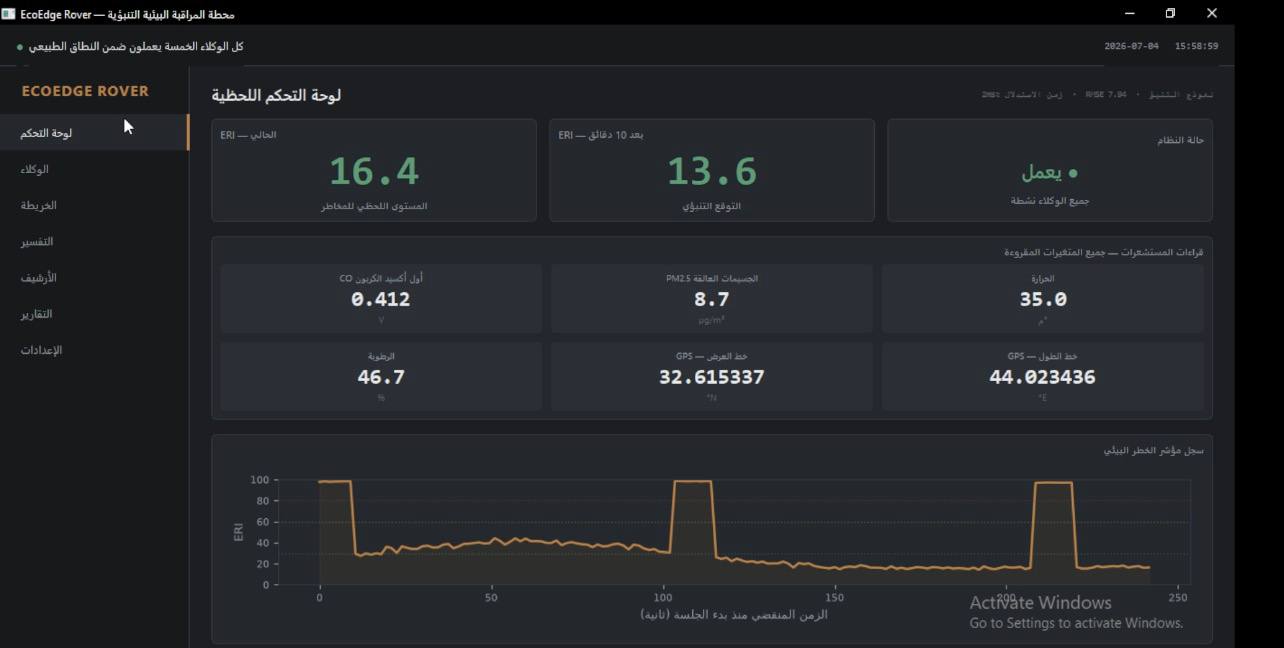
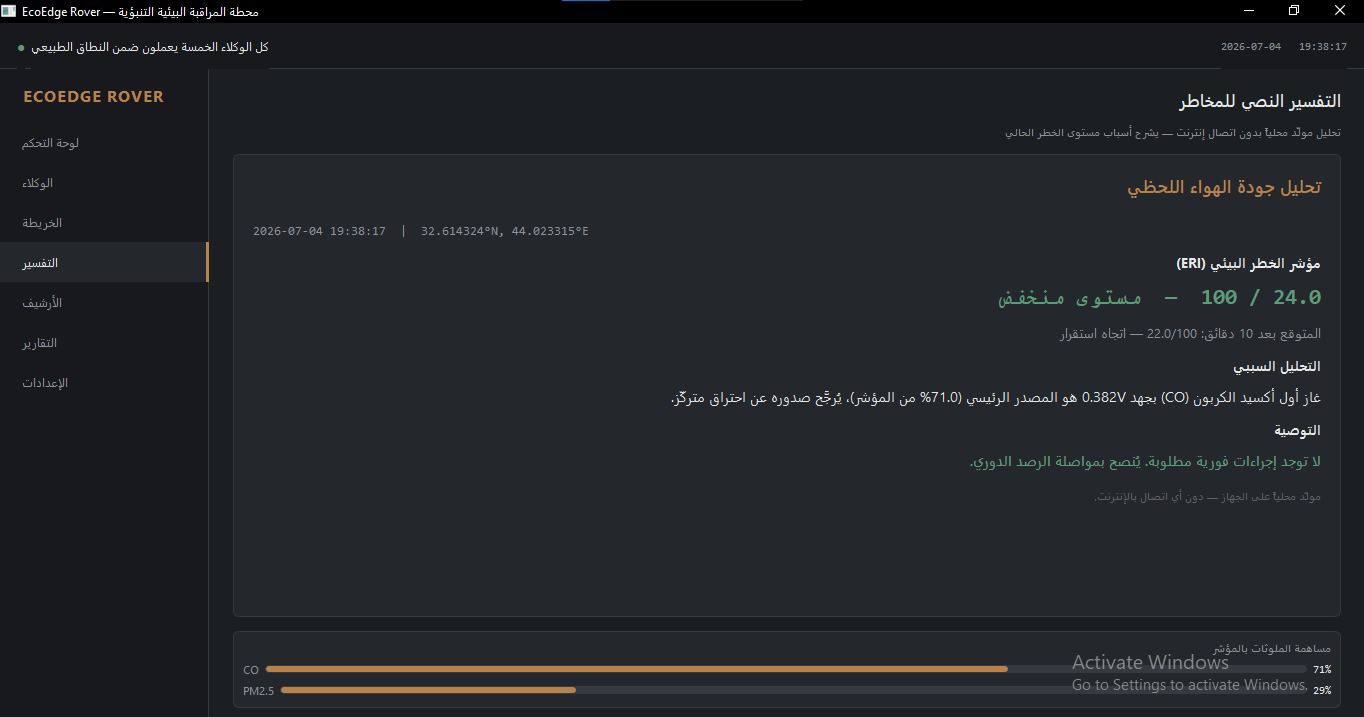
تعد مراقبة جودة الهواء في البيئات الحضرية المزدحمة تحدياً كبيراً بسبب اعتماد الأنظمة التقليدية على الحوسبة السحابية وما يرافقها من تأخير وضعف في الاعتمادية. تقدم هذه الورقة محطة ذكاء بيئي تعمل على متحكم ESP32 وفق معمارية متعددة الوكلاء باستخدام Free RTOS، وتدمج الاستشعار البيئي، ومعالجة الإشارات، واستخراج الخصائص، والتنبؤ بالمخاطر البيئية عبر التعلم الآلي المصغر (Tiny ML) ضمن منصة مدمجة تعمل بالكامل دون اتصال بالإنترنت. بدلاً من إرسال البيانات الخام، يحسب النظام مؤشر الخطر البيئي (ERI) ويتنبأ به قبل 10 دقائق باستخدام نموذج انحدار مدرب عبر Edge Impulse، محققاً قيمة RMSE بلغت 7.94 وزمن استنتاج يقارب 2 ms. كما تدعم المعمارية استمرارية عمل النظام عند تعطل بعض الوحدات بصورة جزئية عبر مهام إشراف موزعة. ويتضمن النظام برنامجاً مكتبياً للعرض اللحظي، والأرشفة، وإنشاء التقارير، إضافةً إلى نموذج ذكاء اصطناعي محلي لتوليد تفسيرات نصية للمخاطر البيئية دون الحاجة إلى الإنترنت. تبين النتائج إمكانية تنفيذ ذكاء بيئي تنبؤي منخفض الكلفة على عتاد محدود الموارد.
الكلمات المفتاحية: الذكاء الاصطناعي الطرفي، الأنظمة متعددة الوكلاء، التعلم الآلي المصغر (Tiny ML)، المراقبة البيئية، التنبؤ بجودة الهواء
NURAI · 2026
المسار الزراعي
An Integrated Mobile-First AI Ecosystem for Combating Desertification and Optimizing Flora Conservation in Iraq
This project addresses the critical environmental threat of desertification and the rapid loss of green spaces in Iraq by targeting the problem at its roots: the decline of civic afforestation cu…
الفريق
Úmeso
رمز الفريق
NURAI2026-0594
المشرف
ا.م.د اياد حازم ابراهيم
قراءة الوصف الكامل للمشروع
This project addresses the critical environmental threat of desertification and the rapid loss of green spaces in Iraq by targeting the problem at its roots: the decline of civic afforestation culture and ecological awareness among individuals. The proposed solution is based on an integrated, mobile-first AI ecosystem that requires no external IoT sensors, instead deploying smart computer vision models. At the core of the technical pipeline is a validation system to identify if the input image contains a plant, evaluate if it is wet or dry to prevent false positives through a dynamic vision calibration model, and subsequently diagnose plant diseases and pests. Additionally, an on-device function-calling model (FunctionGemma) coordinates agentic, location-based notifications between users to crowdsource plant care. The expected outcomes include a scalable, crowdsourced database of Iraq's urban canopy, interactive vegetation mapping, and public-policy integration to drive reforestation and carbon offset initiatives across Iraqi provinces.
المسار البيئي
Autonomous Outdoor Misting Climate Control System for Enhancing Urban Thermal Comfort Using Fuzzy IoT-Based Technologies
The traditional outdoor misting systems are known to have high ongoing energy use and significant water loss due to inefficient spraying. Moreover, traditional methods often create nuisance to pe…
الفريق
soul tech
رمز الفريق
NURAI2026-0602
المشرف
عماد محمد عبود
قراءة الوصف الكامل للمشروع
The traditional outdoor misting systems are known to have high ongoing energy use and significant water loss due to inefficient spraying. Moreover, traditional methods often create nuisance to pedestrians by unwanted wetting. In an attempt to overcome these inefficiencies, this paper presents SMART ECO-MISTER Breeze, a solar based urban cooling system with the support of Edge AI. The architecture proposed consists of a Raspberry Pi 4, AMG8833 Thermal Camera and BME280 sensor to enable ambient monitoring and human heat detection in real-time. The system uses AI algorithm to determine the amount of mist needed for each person and uses a 50W monocrystalline solar panel, along with a 12V LiFePO4 battery and MPPT controller to operate off the grid. The 60cm 3D printed physical prototype includes a 12V high pressure diaphragm pump, 0.1mm brass nozzles, solenoid valves and closed loop water re-cycling system. Further, the system includes a LoRa MESH wireless network, which allows to coordinate multiple cooling poles in a decentralised way across the city. Experimental validation shows that the system can provide targeted and personalized cooling without wetting pedestrians, if they do not want to be wet. In so doing, this smart architecture requires much less energy and water than traditional methods, providing a highly sustainable paradigm for urban climate adaptation.
مسار خدمة المجتمع
Cue:Smart movie discovery app
The "Cue" project offers a unique, community-oriented entertainment service in the film sector, addressing the challenge of finding specific movies. Many existing platforms highlight only popular…
الفريق
By accident
رمز الفريق
NURAI2026-0629
المشرف
رنا محمد حسن زكي
قراءة الوصف الكامل للمشروع
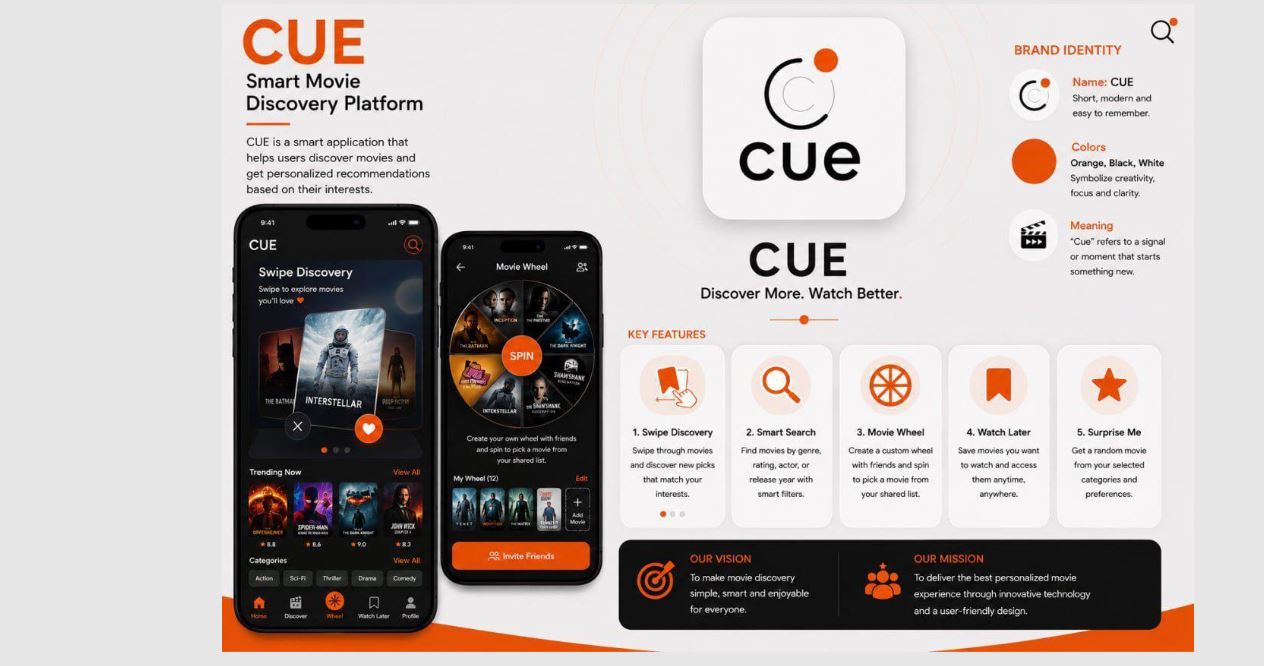
The "Cue" project offers a unique, community-oriented entertainment service in the film sector,
addressing the challenge of finding specific movies. Many existing platforms highlight only
popular or frequently featured titles, often overlooking other works that might appeal to
specific users. To solve this, we developed the Cue app with the goal of simplifying movie
discovery and search. The app utilizes smart technologies and artificial intelligence to help
users find content tailored to their tastes leveraging ratings and personalized profiles while also
allowing them to save movies to a watchlist for future viewing. In addition to the "swipe"
feature that suggests random movies, the app is powered by AI technology; it learns from user
preferences, ratings, search history, and swipe actions. The model continuously adapts to the
user's tastes, offering personalized, real-time recommendations without relying on cloud
computing services or the app's built-in databases. Users can enable or disable this feature at
their discretion. The app also features a fun "wheel spin" function that suggests a random movie
from a selected group; users can even add their own movies to the mix—a great solution for
friends who are undecided on what to watch, as the spinning wheel offers a smooth and
entertaining way to make a choice. Perhaps the most significant feature is the robust child
protection system; the "Kids Mode" is designed to safeguard children and assist parents by
filtering out inappropriate content. Once activated, the account switches exclusively to a childfriendly mode where search results and browsing options are carefully curated to display only
age-appropriate movies. An AI algorithm ensures that unsuitable content never appears,
making this feature a vital community service in today's world.
مسار خدمة المجتمع
Deep World
Our project is a multi-agent AI society simulation. It creates a virtual society where AI agents communicate like humans to simulate how people may react to an idea or decision. The user enters a…
الفريق
Deep world
رمز الفريق
NURAI2026-0599
المشرف
د. ضاري علي محمود
قراءة الوصف الكامل للمشروع
Our project is a multi-agent AI society simulation. It creates a virtual society where AI agents communicate like humans to simulate how people may react to an idea or decision.
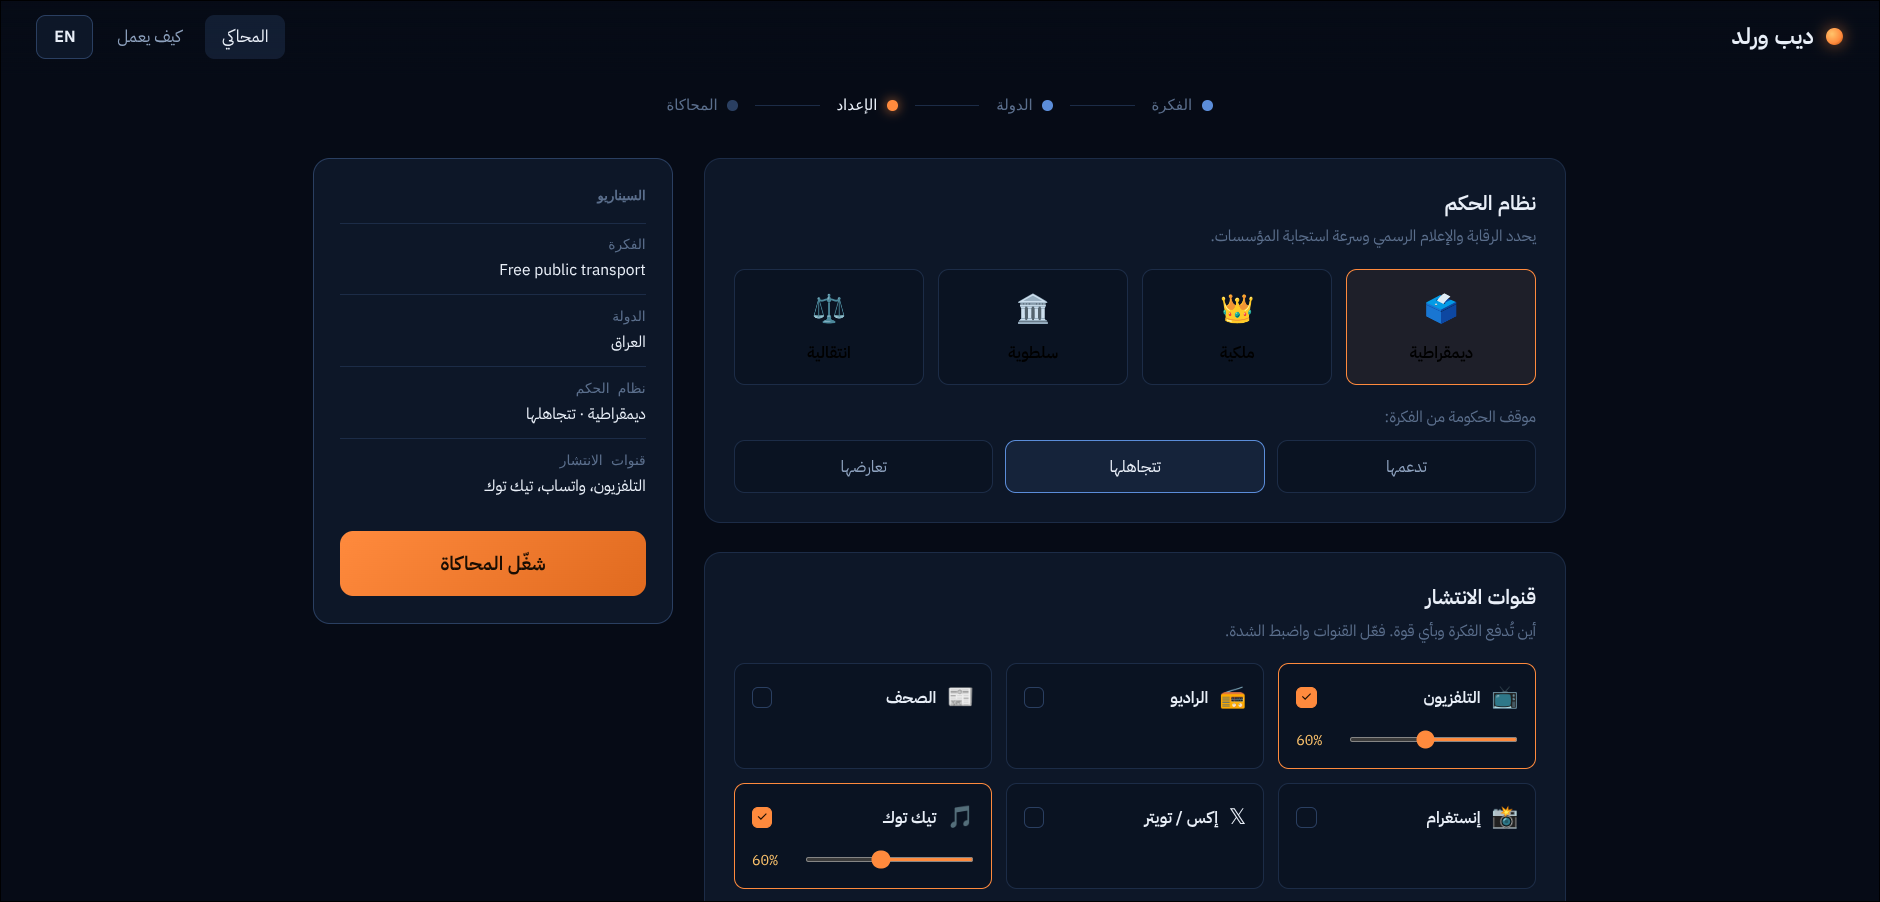
The user enters an idea for example, increasing salaries by 25%, selects the target country, chooses the authority behind the idea and the communication channels that carry it, then runs the simulation. The agents discuss the idea and respond based on their different characteristics and interactions.
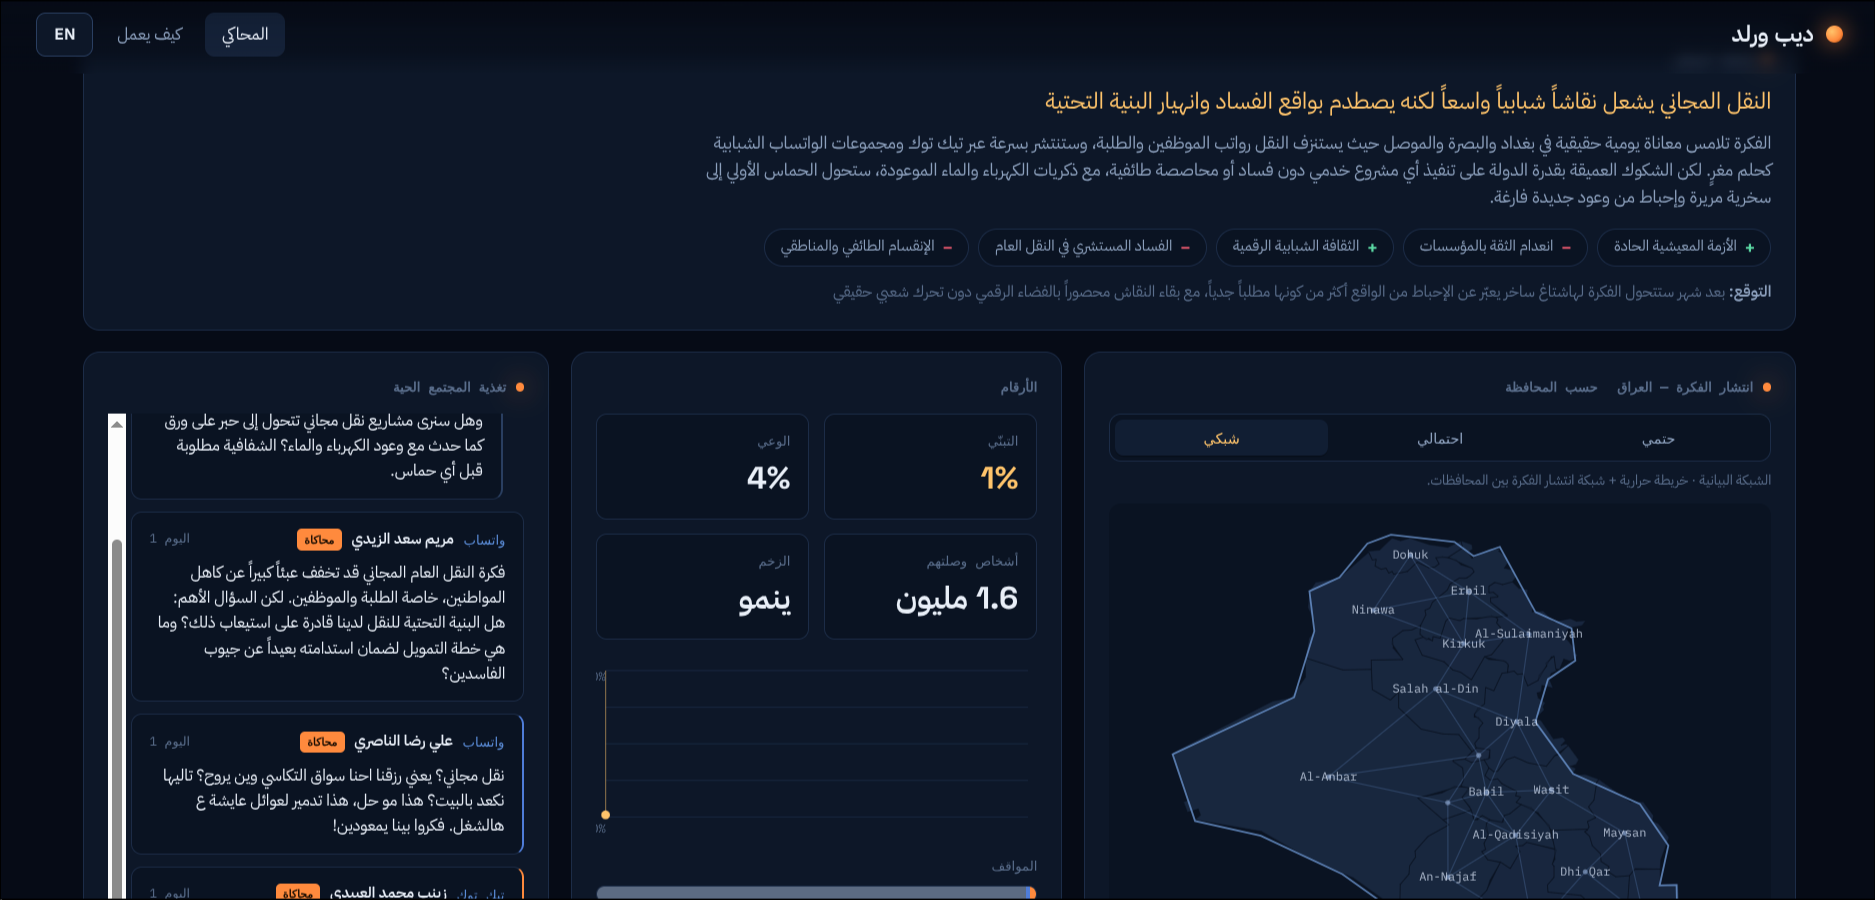
The system shows the overall public reaction, including the levels of acceptance, rejection, and neutrality, providing a possible picture of how society may respond to the idea.
المسار الصناعي
Design and implementation of a 6-Degree of Freedom Robotic Arm
This project aims to design and implement a six degrees of freedom (6-DOF) robotic arm capable of performing basic motions similar to those of the human arm. The system is based on six revolute j…
الفريق
TriControl
رمز الفريق
NURAI2026-0635
المشرف
أ.م.د تغريد محمد محمدرضا
قراءة الوصف الكامل للمشروع
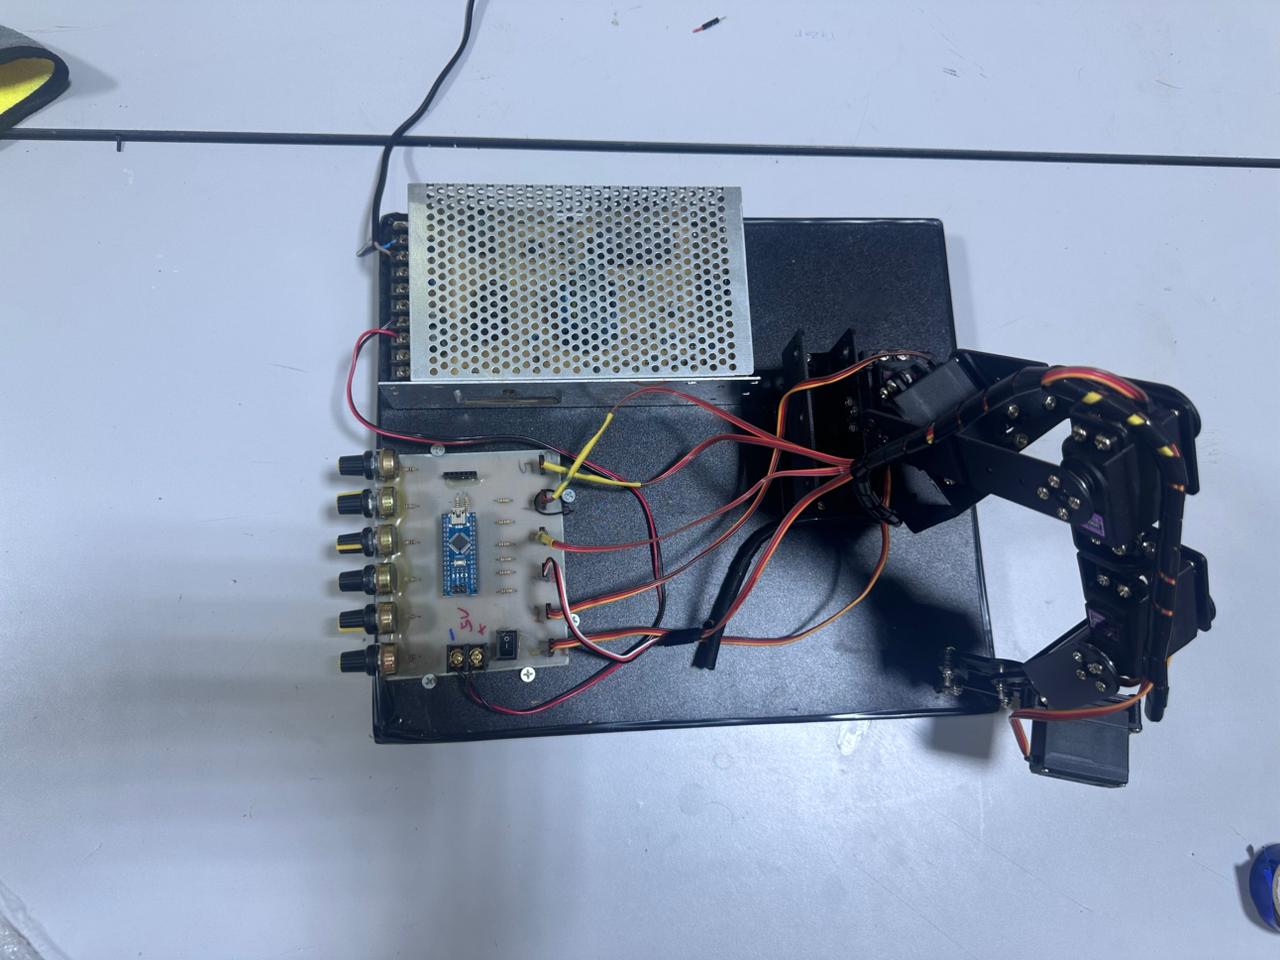
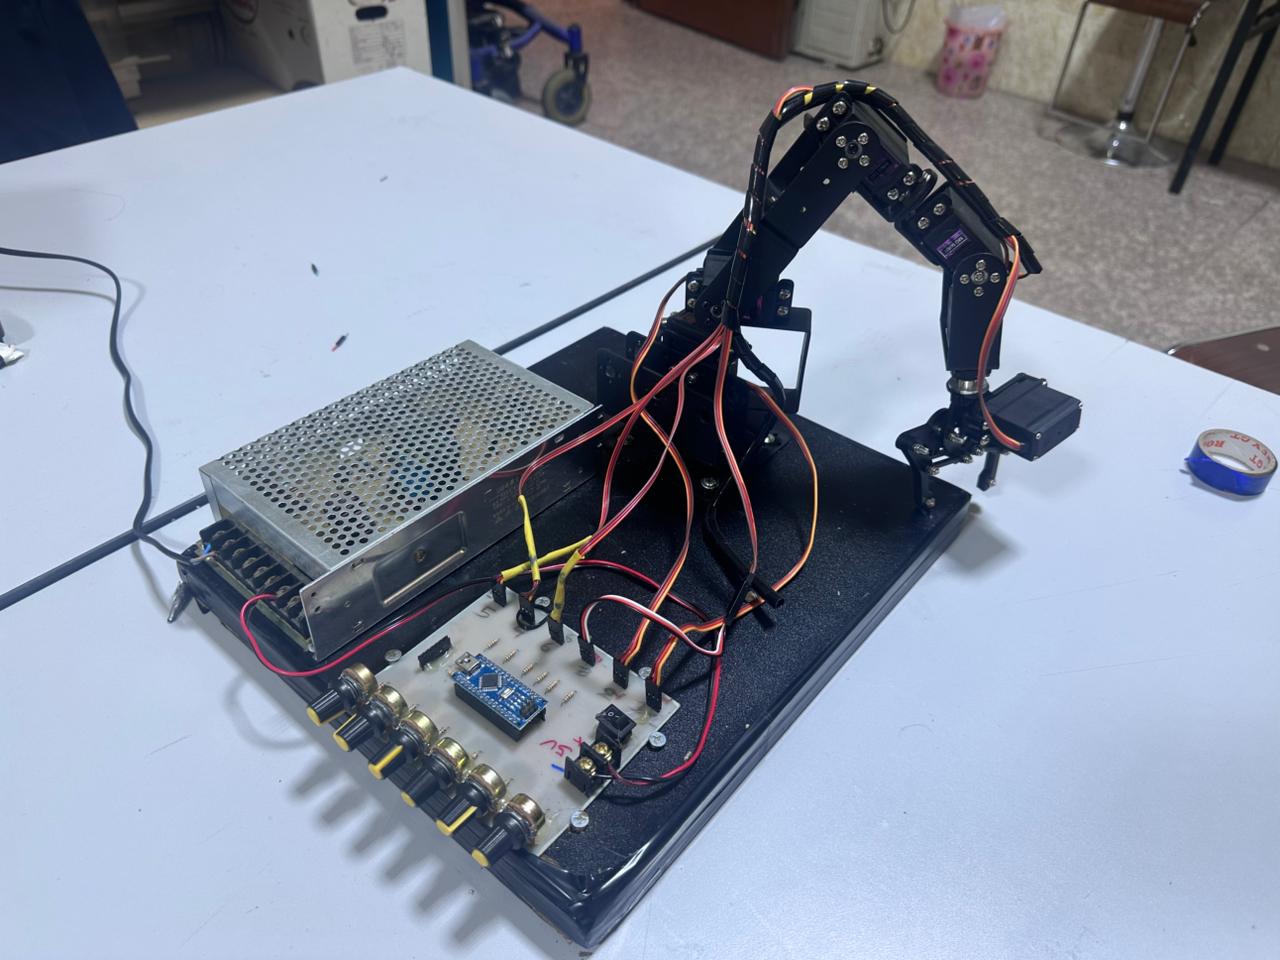
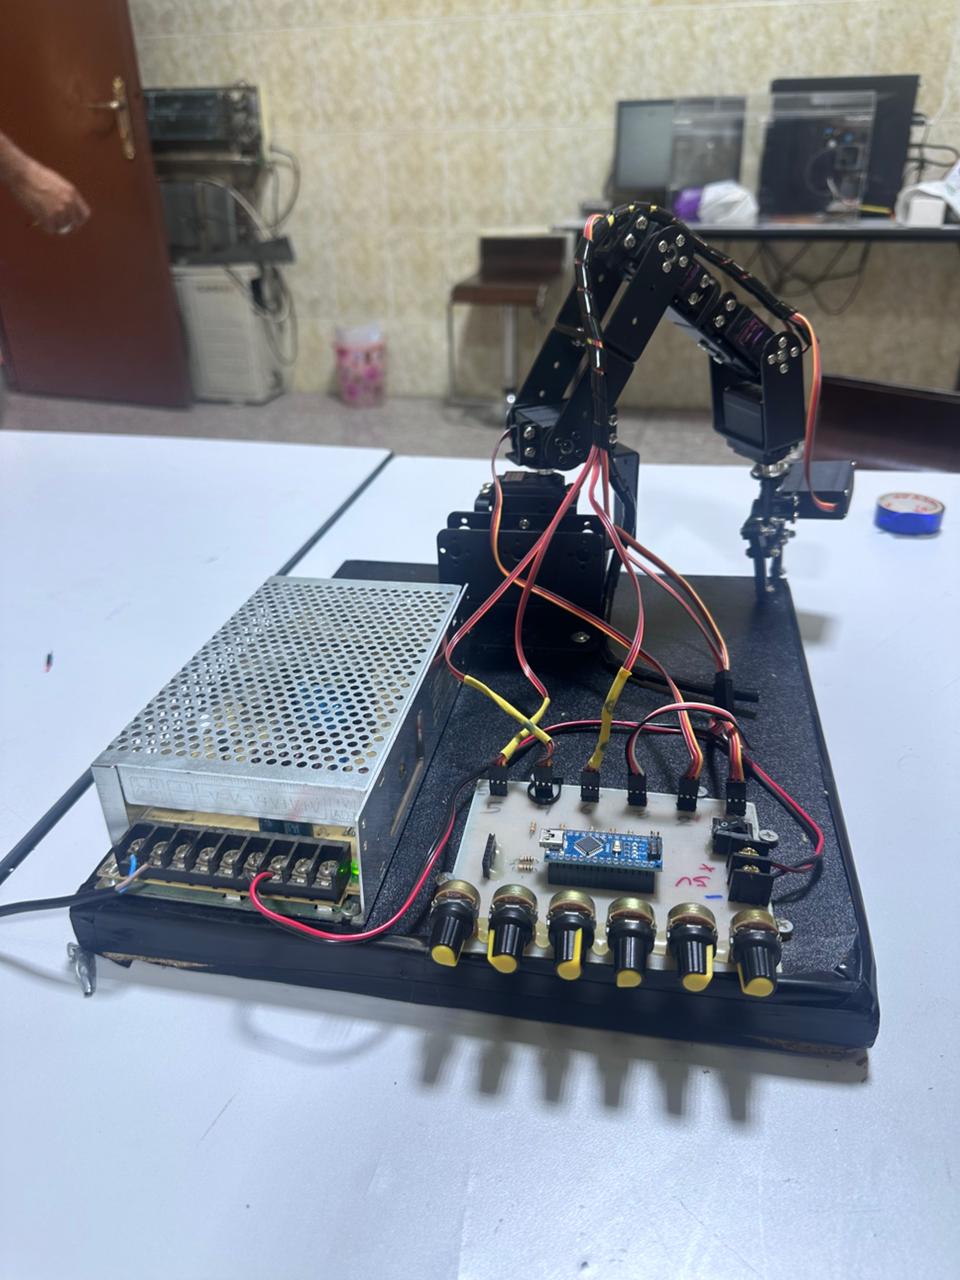
This project aims to design and implement a six degrees of freedom (6-DOF)
robotic arm capable of performing basic motions similar to those of the human
arm. The system is based on six revolute joints actuated by servo motors, with an
Arduino Nano microcontroller used as the main control unit.Joint angles are
manually controlled using potentiometers to achieve smooth and stable
movement. The mechanical structure is constructed from Aluminum 6061-T6 due
to its light weight, high rigidity, and good heat dissipation. A printed circuit board
(PCB) is employed to improve system reliability and reduce electrical errors. The
developed prototype demonstrates satisfactory performance, making it suitable
for educational purposes and simple industrial applications.