Building Management System based on Artificial Intelligent
This paper presents the design and implementation aspects of Building Management System (BMS) for the optimized control of air conditioning, standby generators, and water pumping systems. The sys…
الفريق
فريق ادارة الطاقة في المباني باستخدام الذكاء الاصطناعي
رمز الفريق
NURAI2026-0720
المشرف
د.بشار سكين فرحان
قراءة الوصف الكامل للمشروع
This paper presents the design and implementation aspects of Building Management System (BMS) for the optimized control of air conditioning, standby generators, and water pumping systems. The system utilizes a hybridized centralized-distributed control topology via an Ethernet network and Modbus RTU, where dual Delta DVP-12SE Programmable Logic Controllers (PLCs) and Human Machine Interface (HMI) are used. Real-time electrical telemetry from grid and generator lines is sampled post-ATS using a digital smart power meter and transmitted to the HMI via Modbus RTU link. Serving as the central Master node, the HMI executes Demand Side Management (DSM) strategies, including dynamic Time-of-Use (ToU).scheduling, active peak-clipping, and pump speed control. Simultaneously, PLC1 provides source-state feedback and manages generator automation, while PLC2 actuate magnetic contactors for sequential starting and selective AC load-shedding. Experimental results confirm the ability of system to response to different operation conditions to guarantee the optimum load management
المسار الطبي
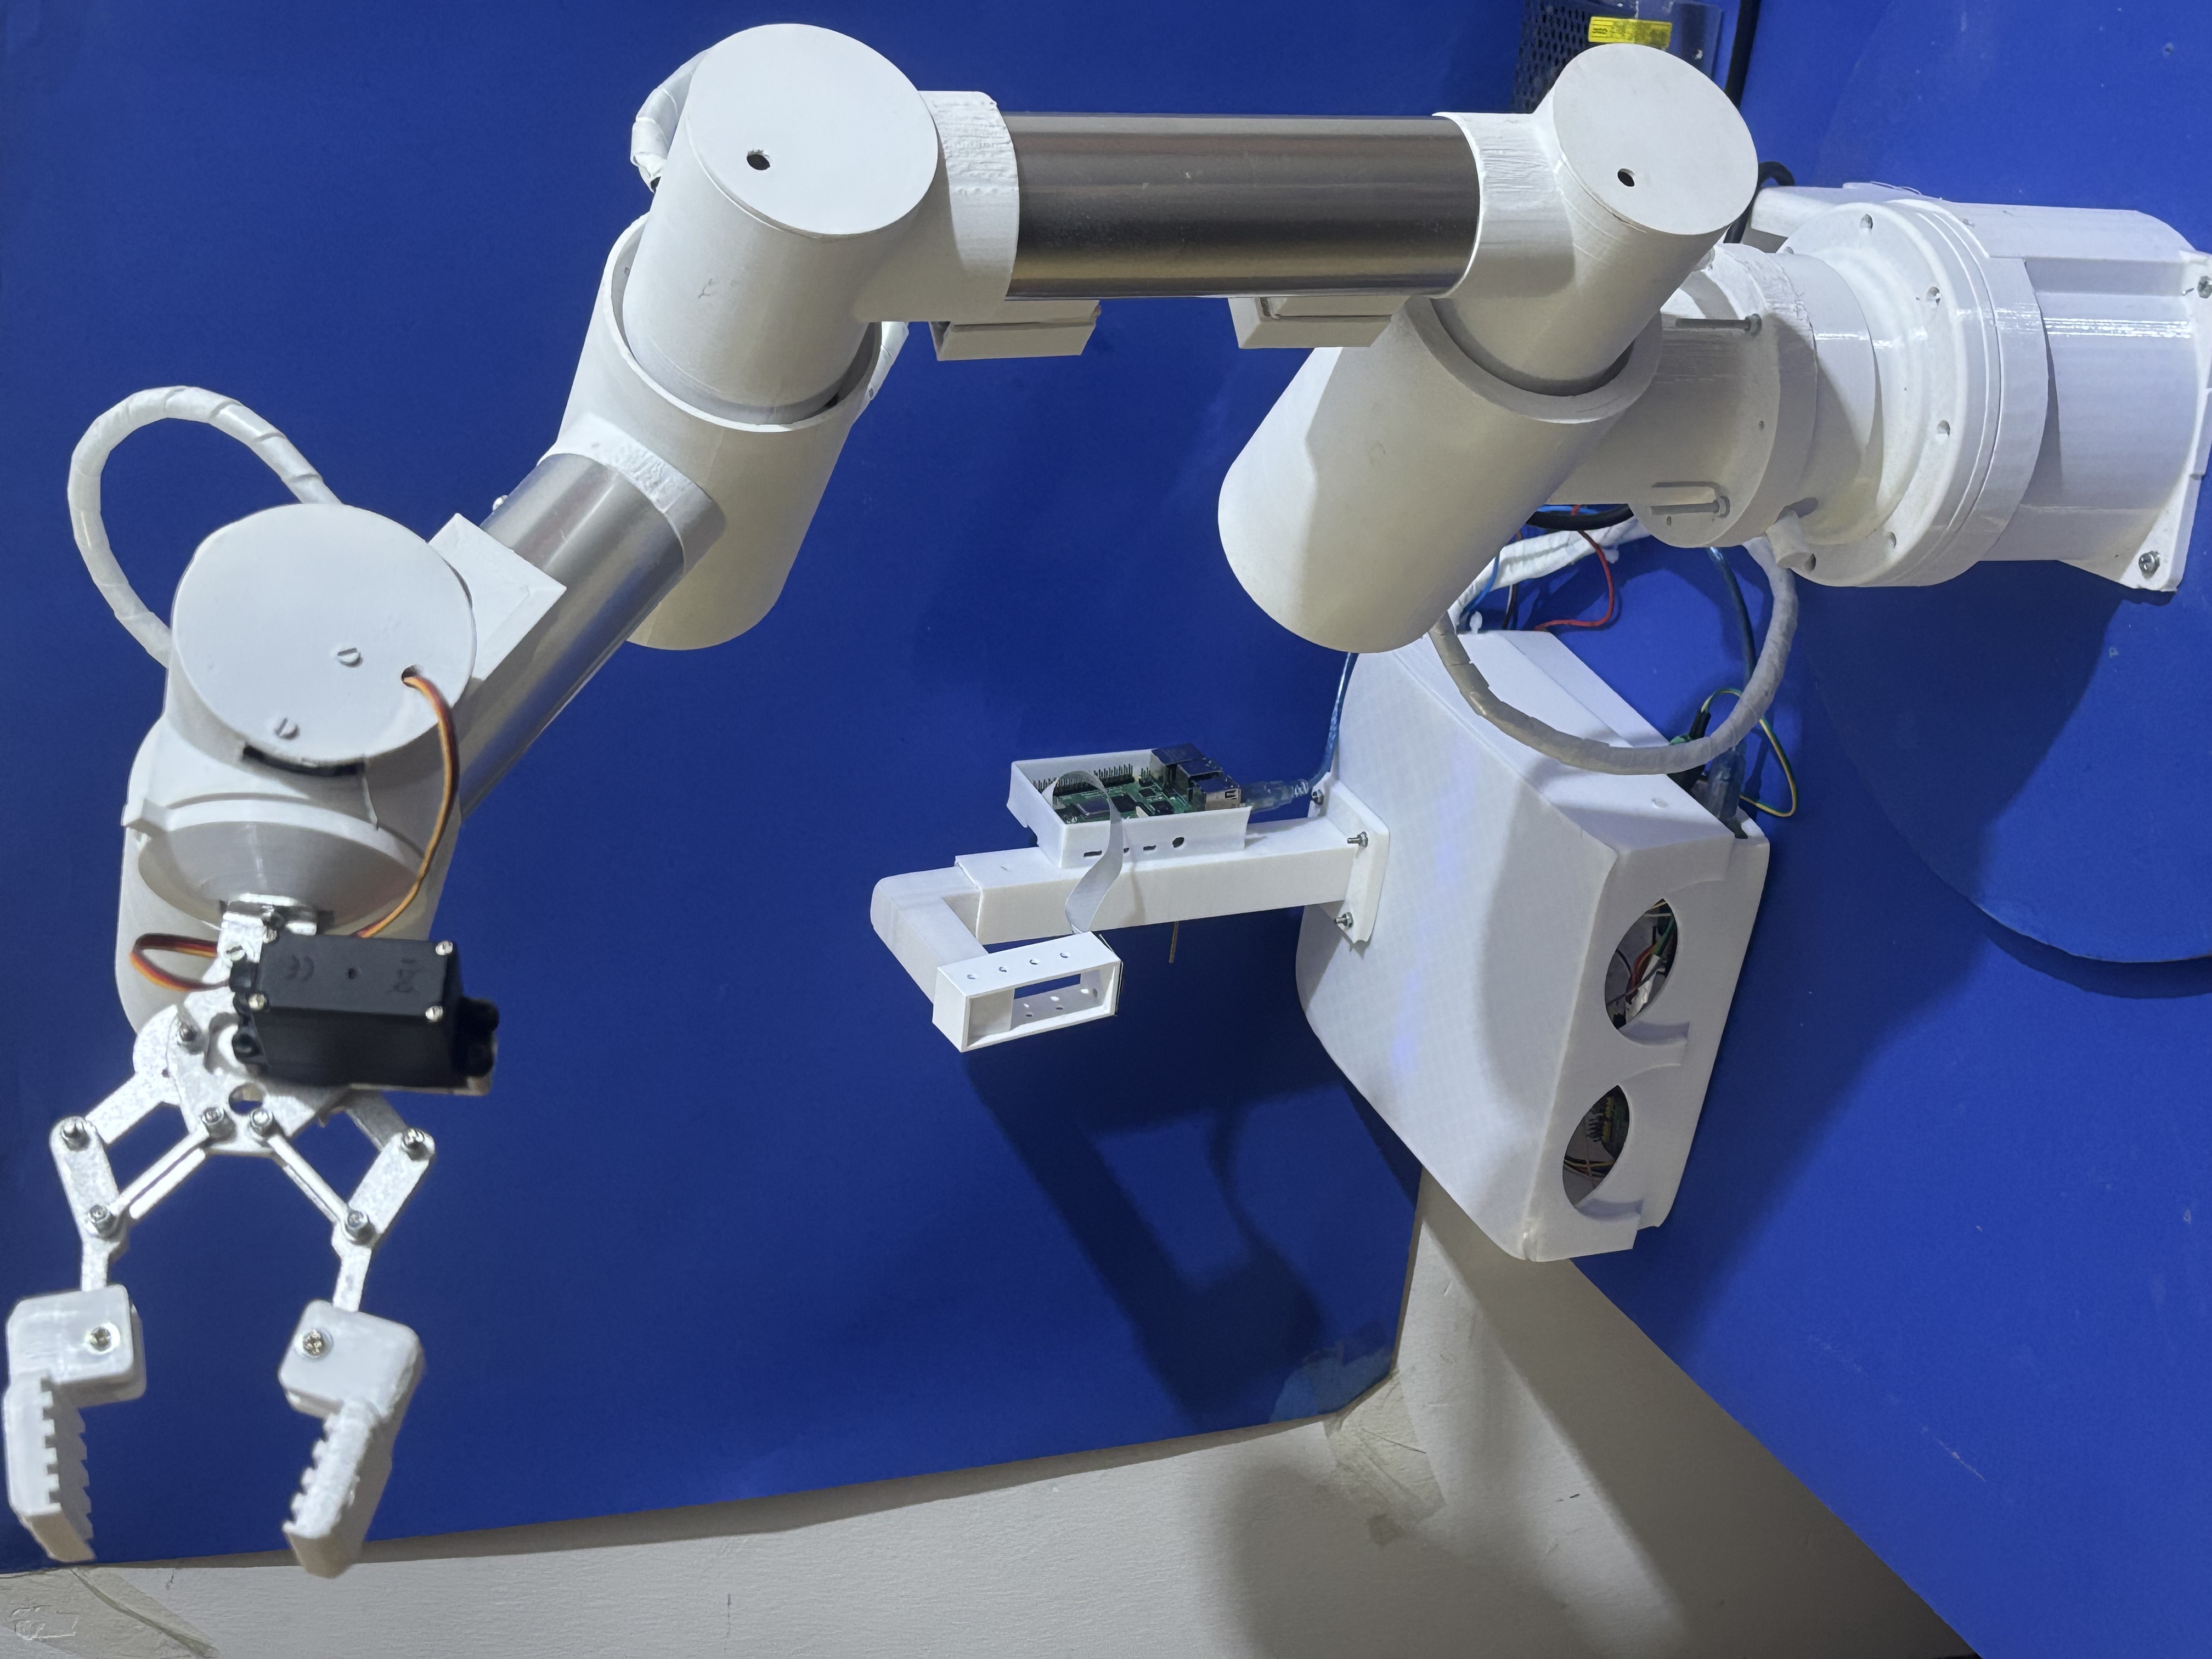
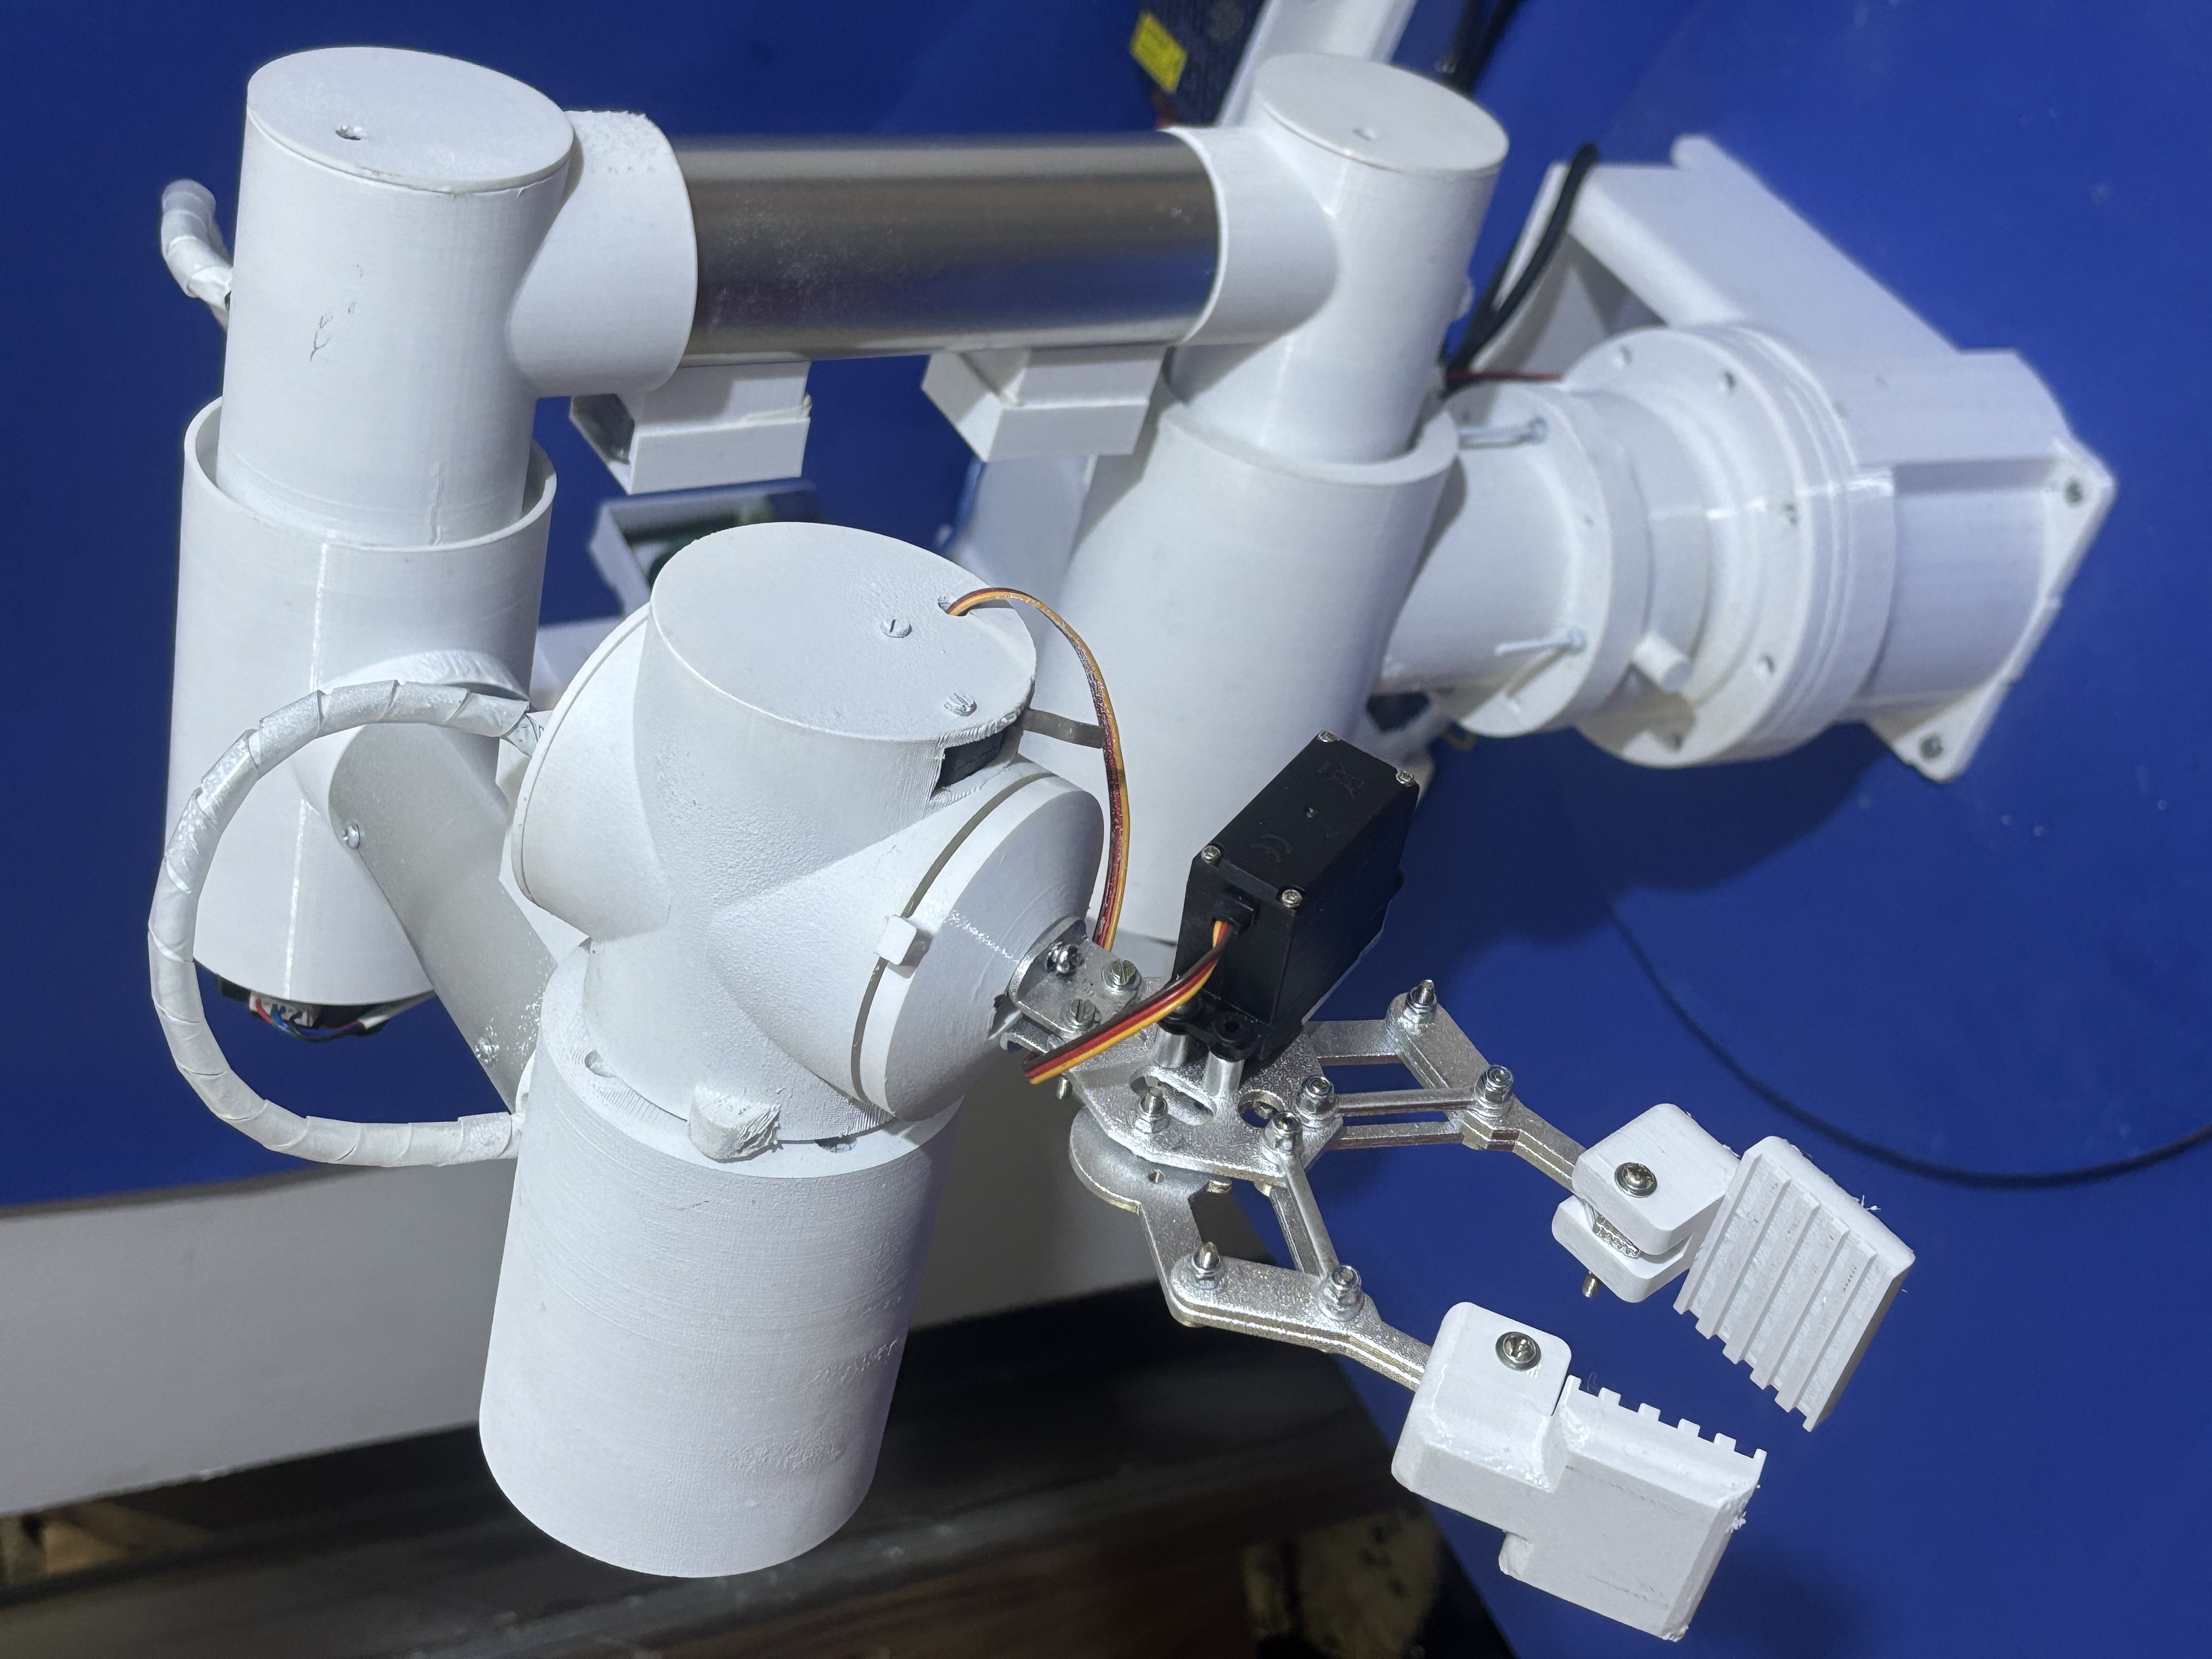
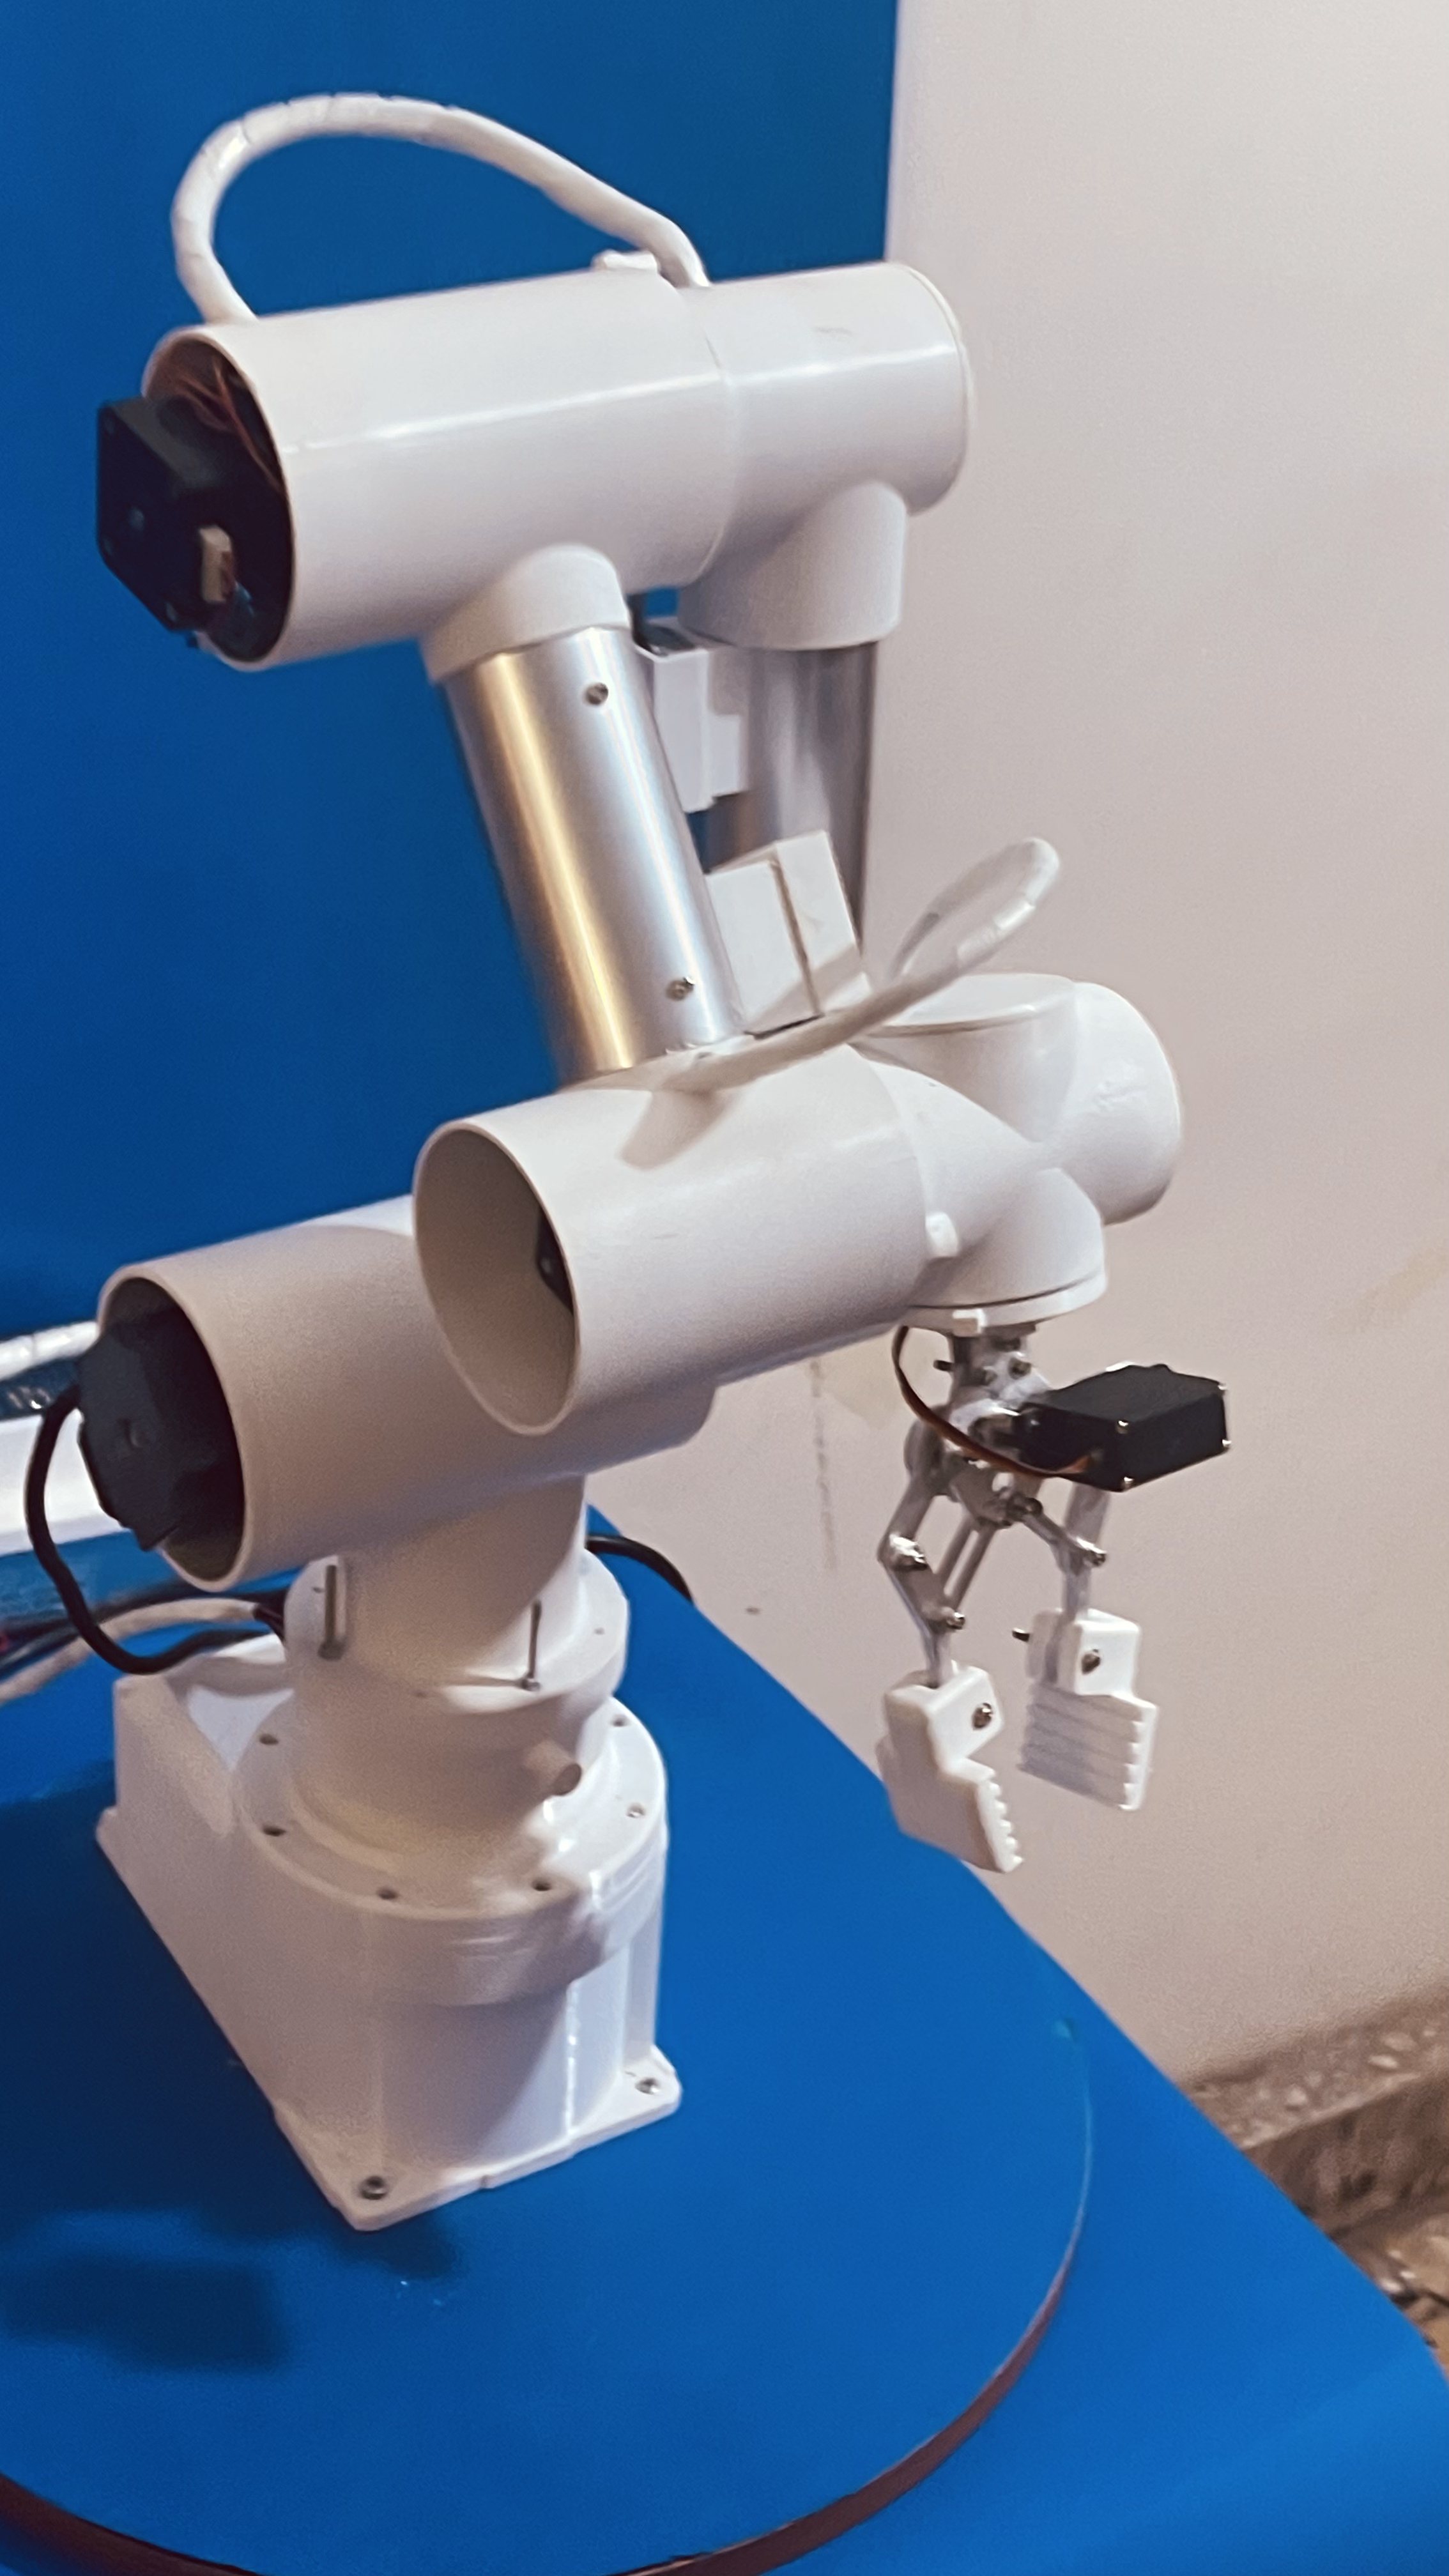
Design and Development of a Vision-Based 6-DOF Robotic System for Intelligent Drug Dispensing in Smart Pharmacies
This project addresses a critical challenge in pharmacy automation by developing a vision-guided six-degrees-of-freedom (6-DOF) robotic arm for automated medication dispensing. The system employs…
الفريق
نخبة الروبوت
رمز الفريق
NURAI2026-0732
المشرف
د.وليد سلمان محمد عباس
قراءة الوصف الكامل للمشروع
This project addresses a critical challenge in pharmacy automation by developing a vision-guided six-degrees-of-freedom (6-DOF) robotic arm for automated medication dispensing. The system employs a camera and optical character recognition (OCR) to read prescription information and identify the required medications. The robotic arm then retrieves and dispenses the medication automatically with high accuracy. The proposed system aims to reduce dispensing errors, shorten waiting times, and improve the efficiency and reliability of pharmacy operations.
مسار خدمة المجتمع
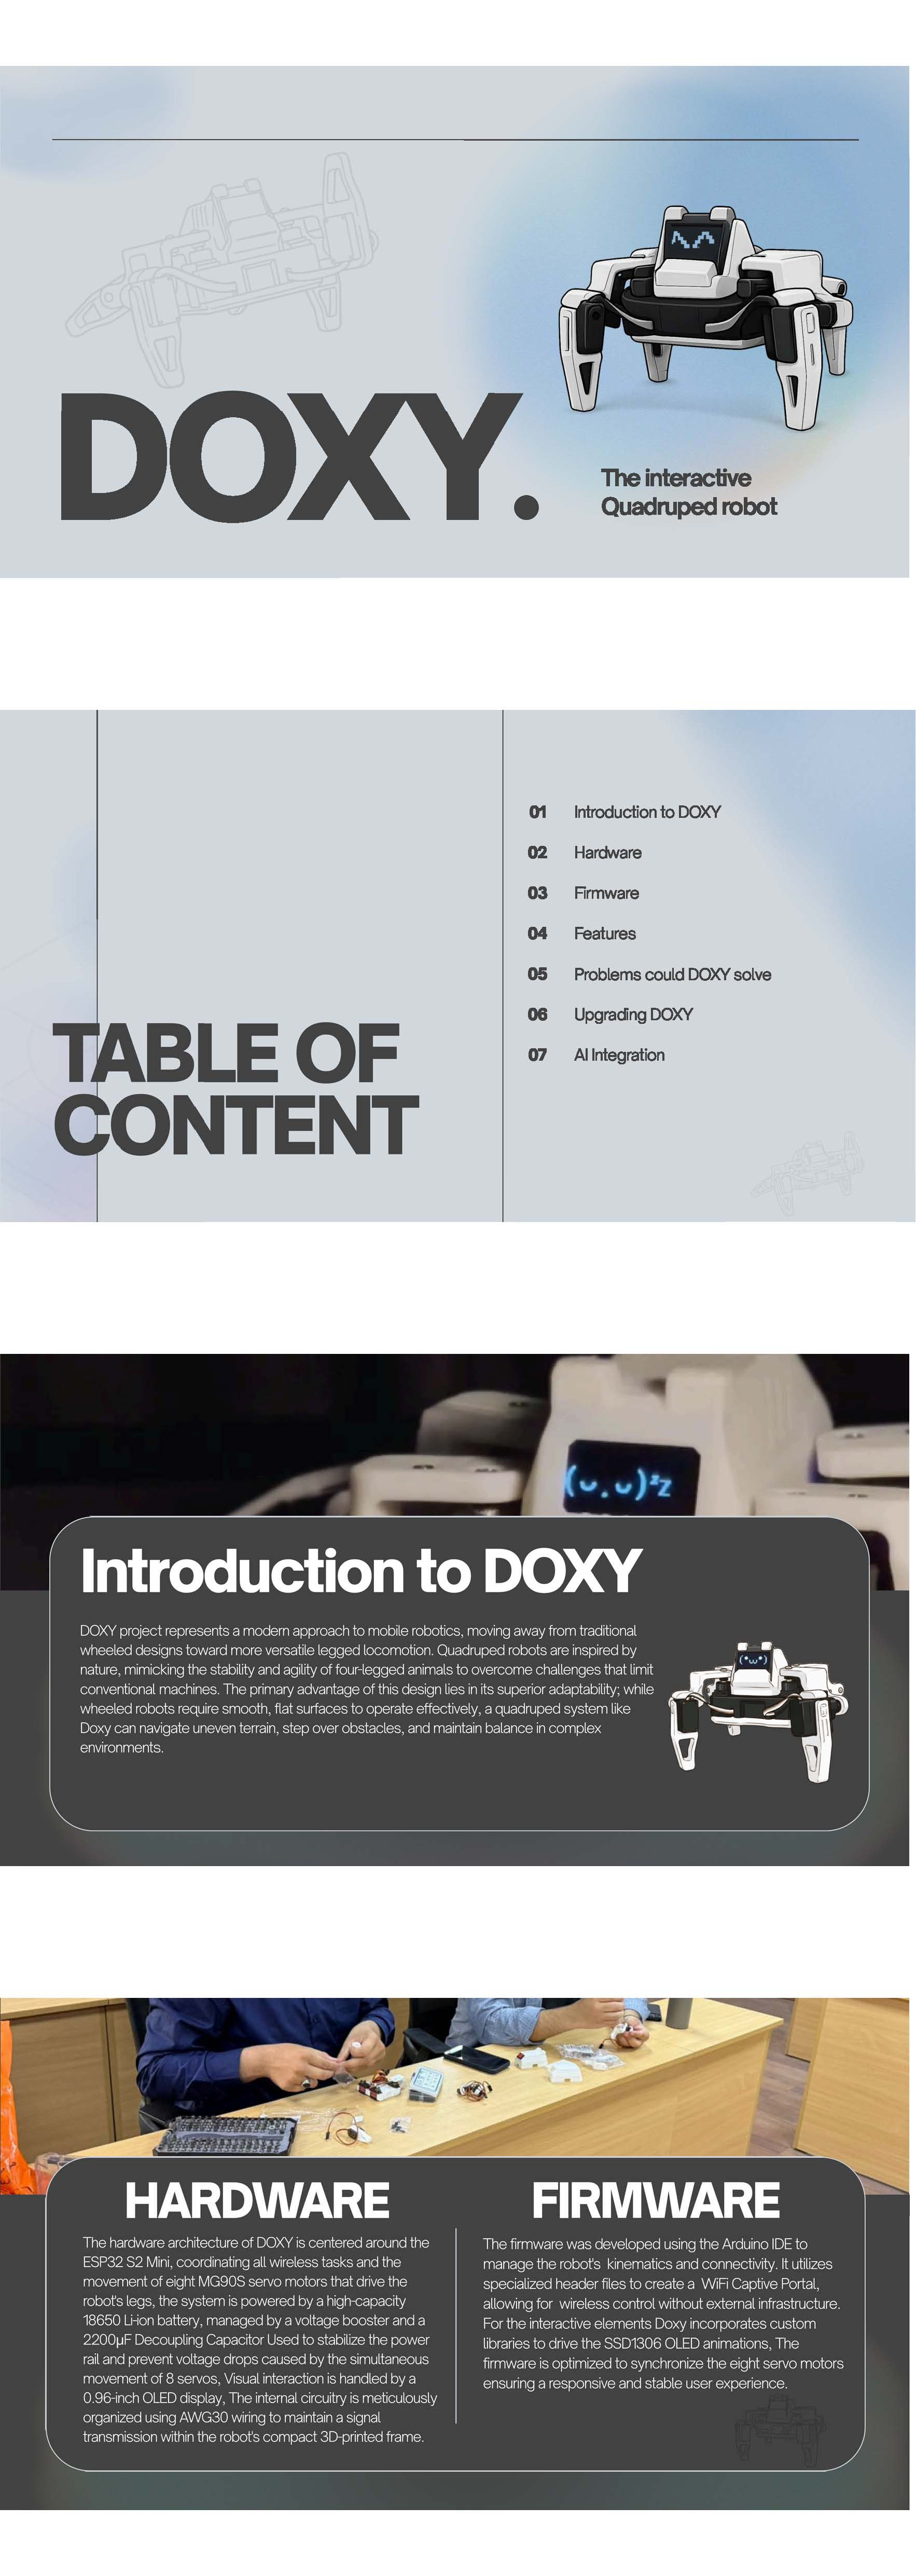
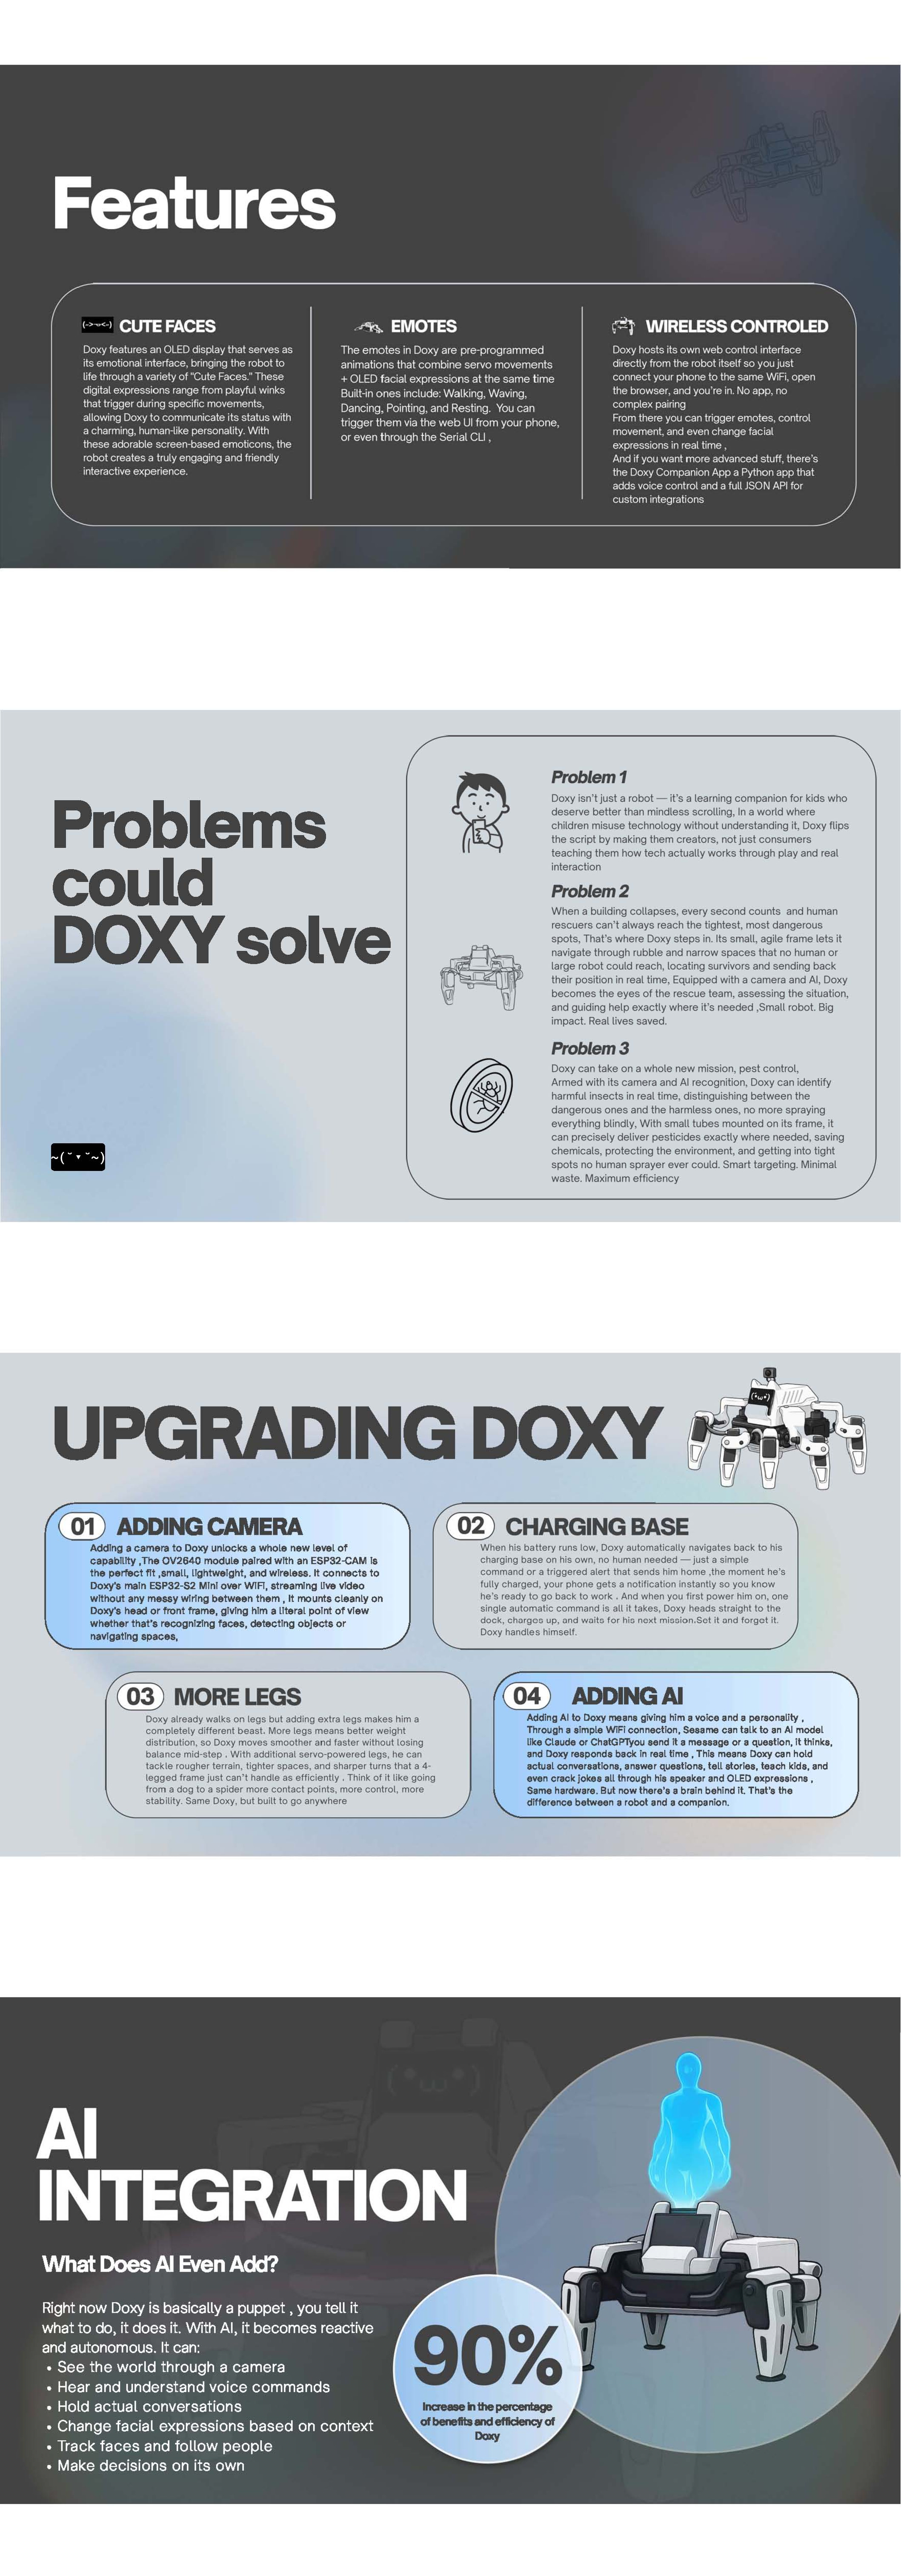
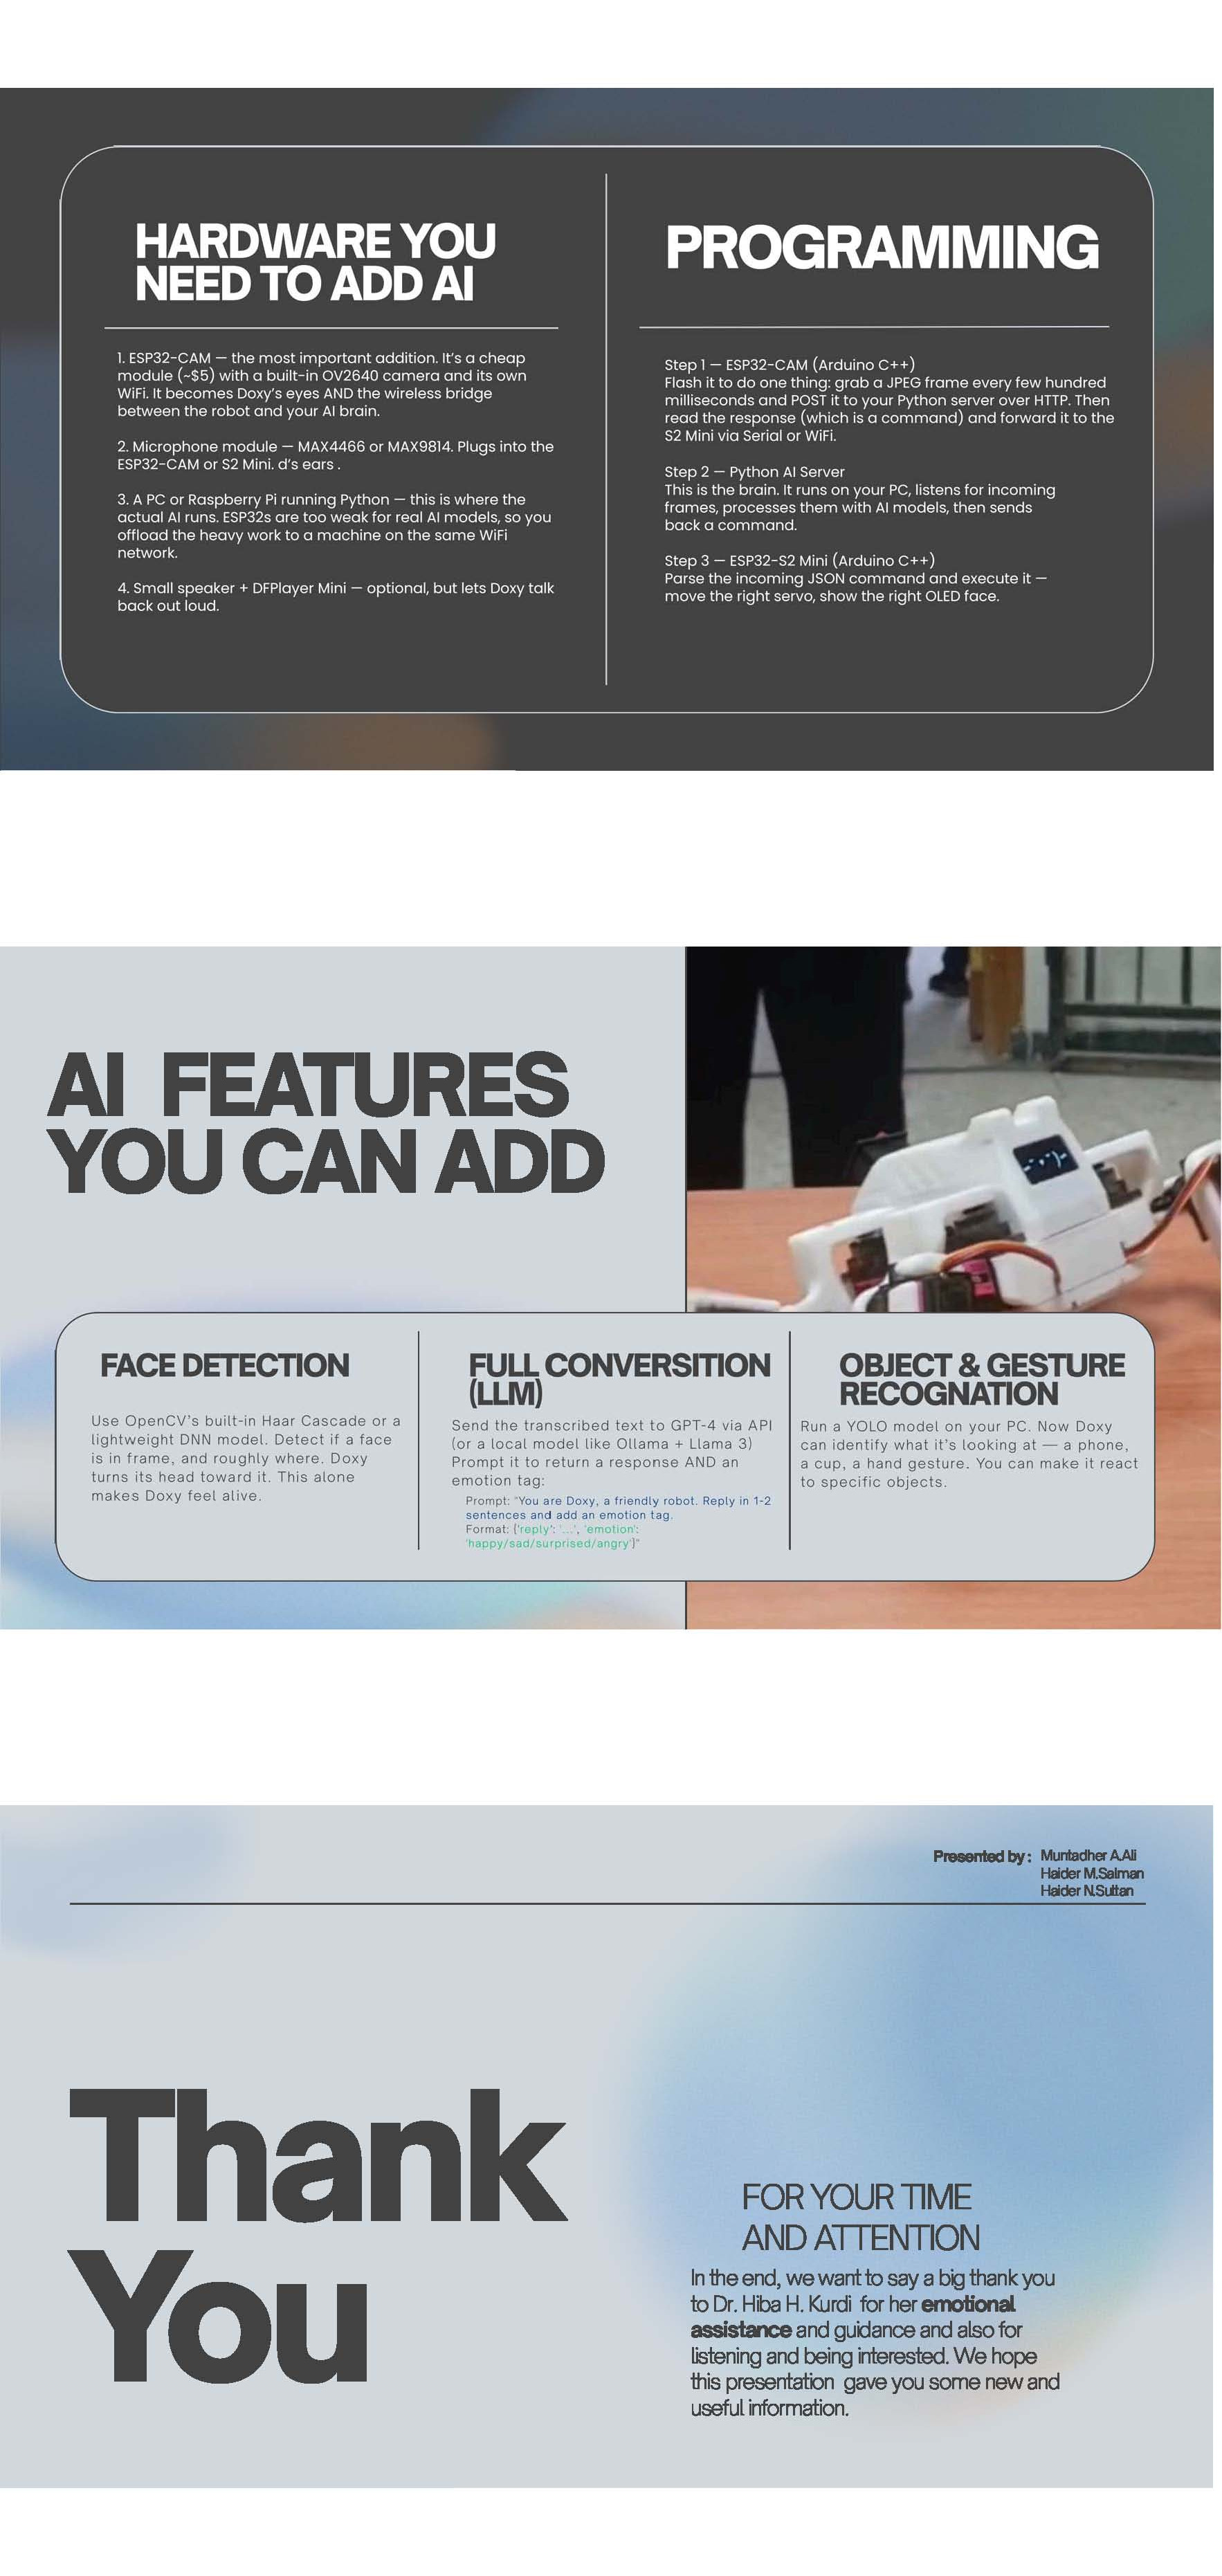
DOXY . The interactive Quadruped robot
DOXY project represents a modern approach to mobile robotics, moving away from traditional wheeled designs toward more versatile legged locomotion. Quadruped robots are inspired by nature, mimick…
الفريق
DOX
رمز الفريق
NURAI2026-0721
المشرف
د.مشتاق احمد
قراءة الوصف الكامل للمشروع
DOXY project represents a modern approach to mobile robotics, moving away from traditional
wheeled designs toward more versatile legged locomotion. Quadruped robots are inspired by
nature, mimicking the stability and agility of four-legged animals to overcome challenges that limit
conventional machines. The primary advantage of this design lies in its superior adaptability; while
wheeled robots require smooth, flat surfaces to operate effectively, a quadruped system like
Doxy can navigate uneven terrain, step over obstacles, and maintain balance in complex
environments
NURAI · 2026
مسار خدمة المجتمع
Hybrid cooling system for solar panels using Geothermal and phase change materials
Photovoltaic (PV) panels are an important renewable energy source, but their efficiency decreases with increasing operating temperature, particularly in hot climates such as Iraq. This study inve…
الفريق
Renewable team
رمز الفريق
NURAI2026-0723
المشرف
م.م هبه كردي
قراءة الوصف الكامل للمشروع
Photovoltaic (PV) panels are an important renewable energy source, but their efficiency decreases with increasing operating temperature, particularly in hot climates such as Iraq. This study investigates a hybrid cooling system combining Phase Change Material (PCM) and geothermal cooling to enhance the thermal and electrical performance of PV panels.Paraffin wax (RT42) was used as PCM to absorb excess heat during peak solar radiation, while a geothermal loop assisted in heat dissipation and PCM regeneration.
Experimental measurements of temperature, voltage, current, power output, and efficiency were conducted and compared with a conventional PV panel under outdoor conditions. The results indicated that the hybrid cooling system effectively reduced PV operating temperature and improved thermal stability. Consequently, the cooled panel achieved
higher electrical output and efficiency compared to the conventional system. The integration of PCM with geothermal cooling proved to be a sustainable and effective approach for improving PV performance in hot environments.
المسار الطبي
Innovative Brain-Controlled Wheelchair Using NeuroSky
This project presents a hybrid smart wheelchair designed to assist individuals with severe physical disabilities by integrating Brain-Computer Interface (BCI) technology with head-motion sensing.…
الفريق
صناع المستقبل
رمز الفريق
NURAI2026-0711
المشرف
د. علاء حسين عبد العال
قراءة الوصف الكامل للمشروع
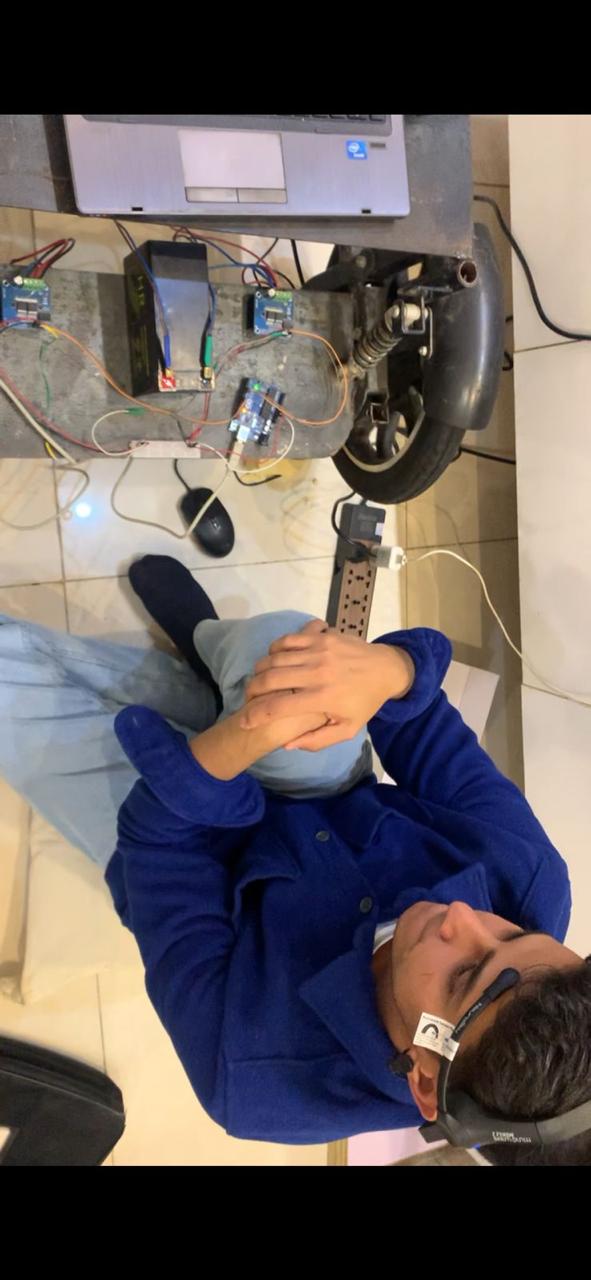
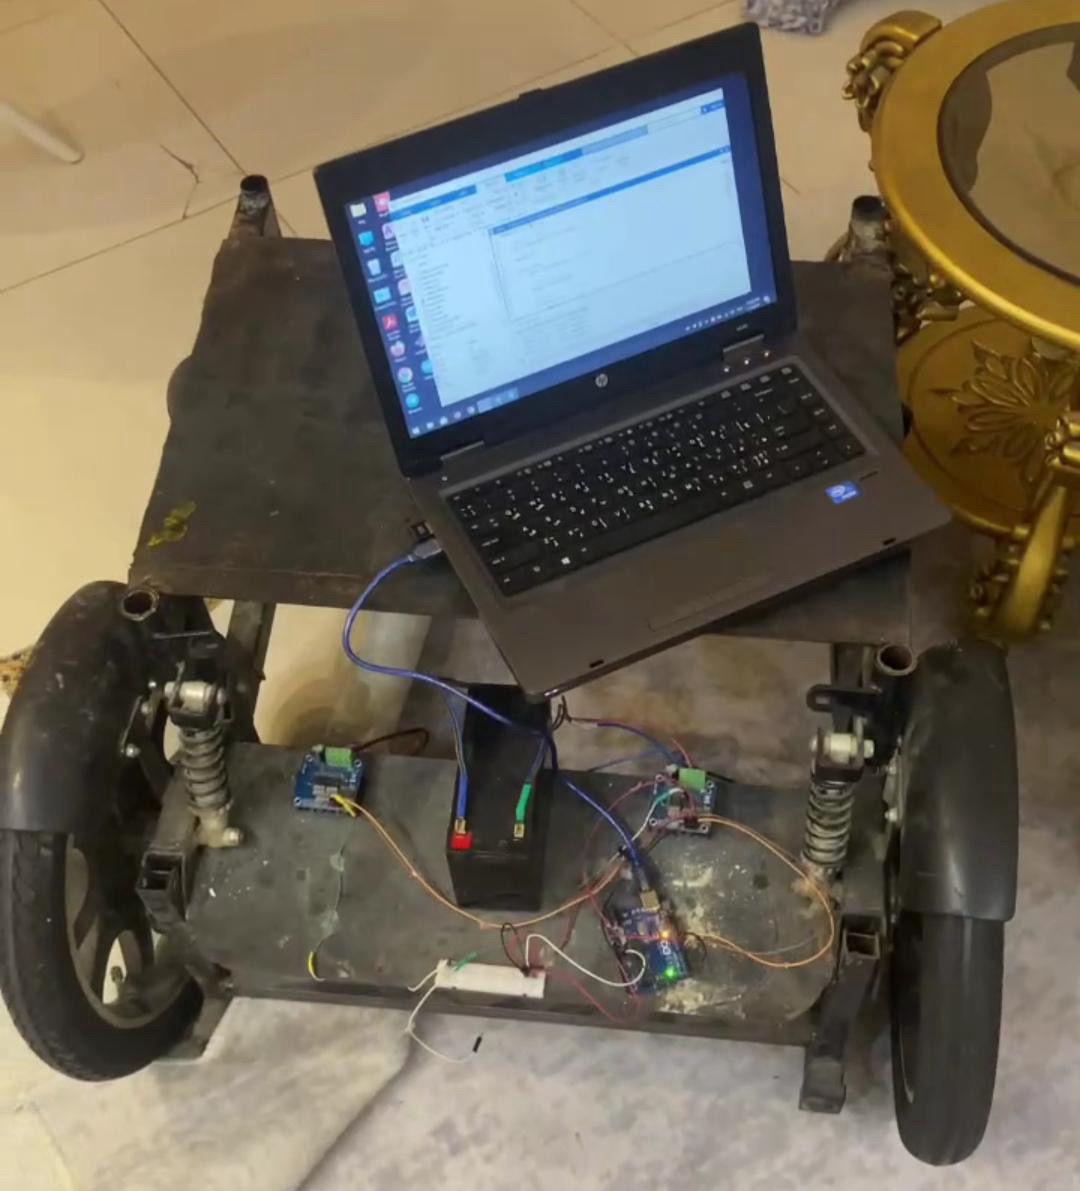
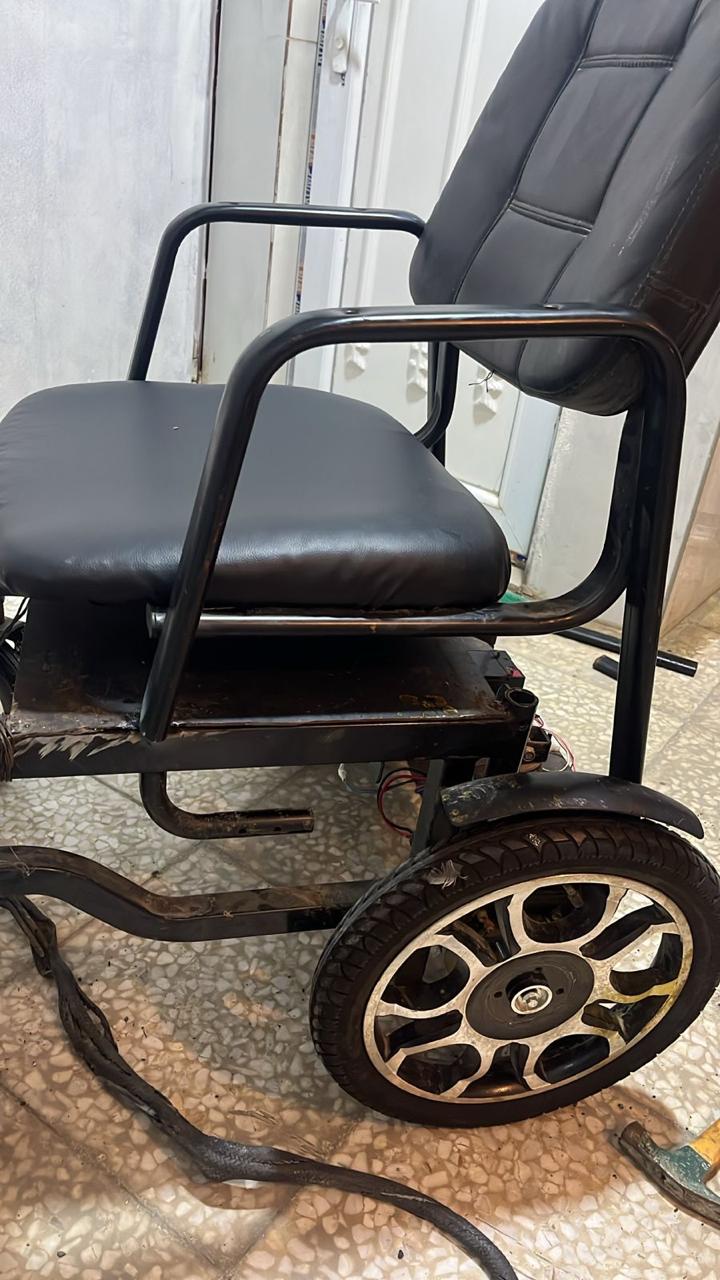
This project presents a hybrid smart wheelchair designed to assist individuals with severe physical disabilities by integrating Brain-Computer Interface (BCI) technology with head-motion sensing. The proposed system uses the NeuroSky MindWave headset to acquire electroencephalogram (EEG) signals and determine the user’s attention level. MATLAB processes these signals in real time and generates movement commands that are transmitted to a microcontroller. Forward and backward movements are controlled using EEG attention values, while left and right movements are achieved using an MPU6050 motion sensor mounted on the headset to detect head tilt. The microcontroller controls two DC motors through BTS7960 motor drivers to drive the wheelchair. Experimental evaluation demonstrated reliable performance with stable communication between software and hardware, fast response time, and accurate movement control. The proposed system provides a practical, affordable, and efficient assistive mobility solution for people with severe motor disabilities
المسار الصناعي
Robotic Hand Control via Somatosensory Glove
This project presents a robotic hand control system based on a somatosensory glove capable of capturing finger and wrist movements and translating them into control commands for a robotic hand. T…
الفريق
فريق التطور العلمي
رمز الفريق
NURAI2026-0712
المشرف
د. علاء حسين عبد العال
قراءة الوصف الكامل للمشروع
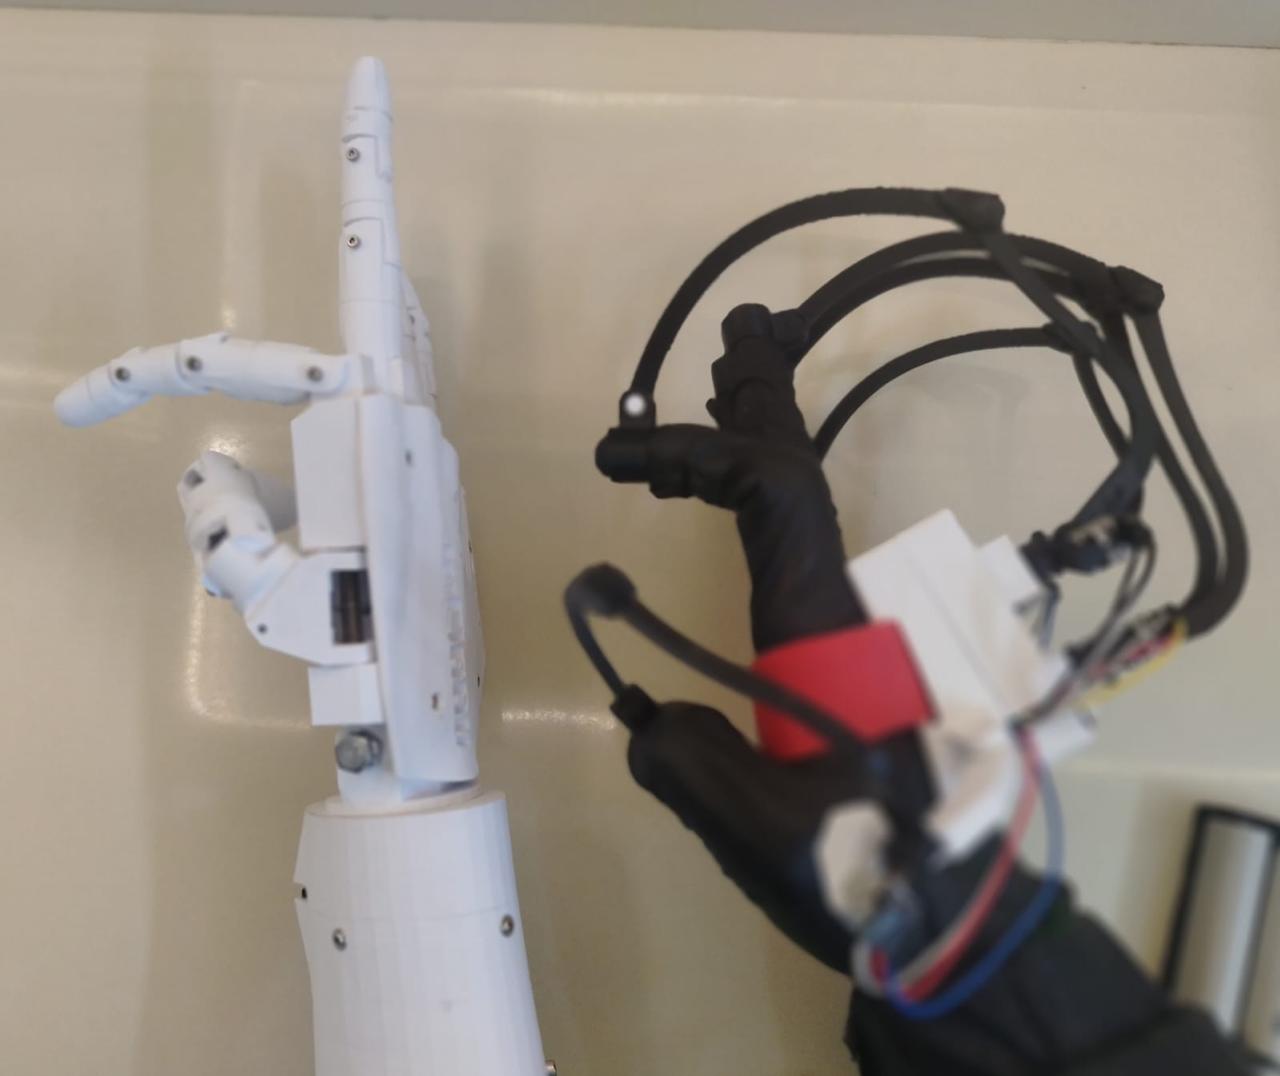
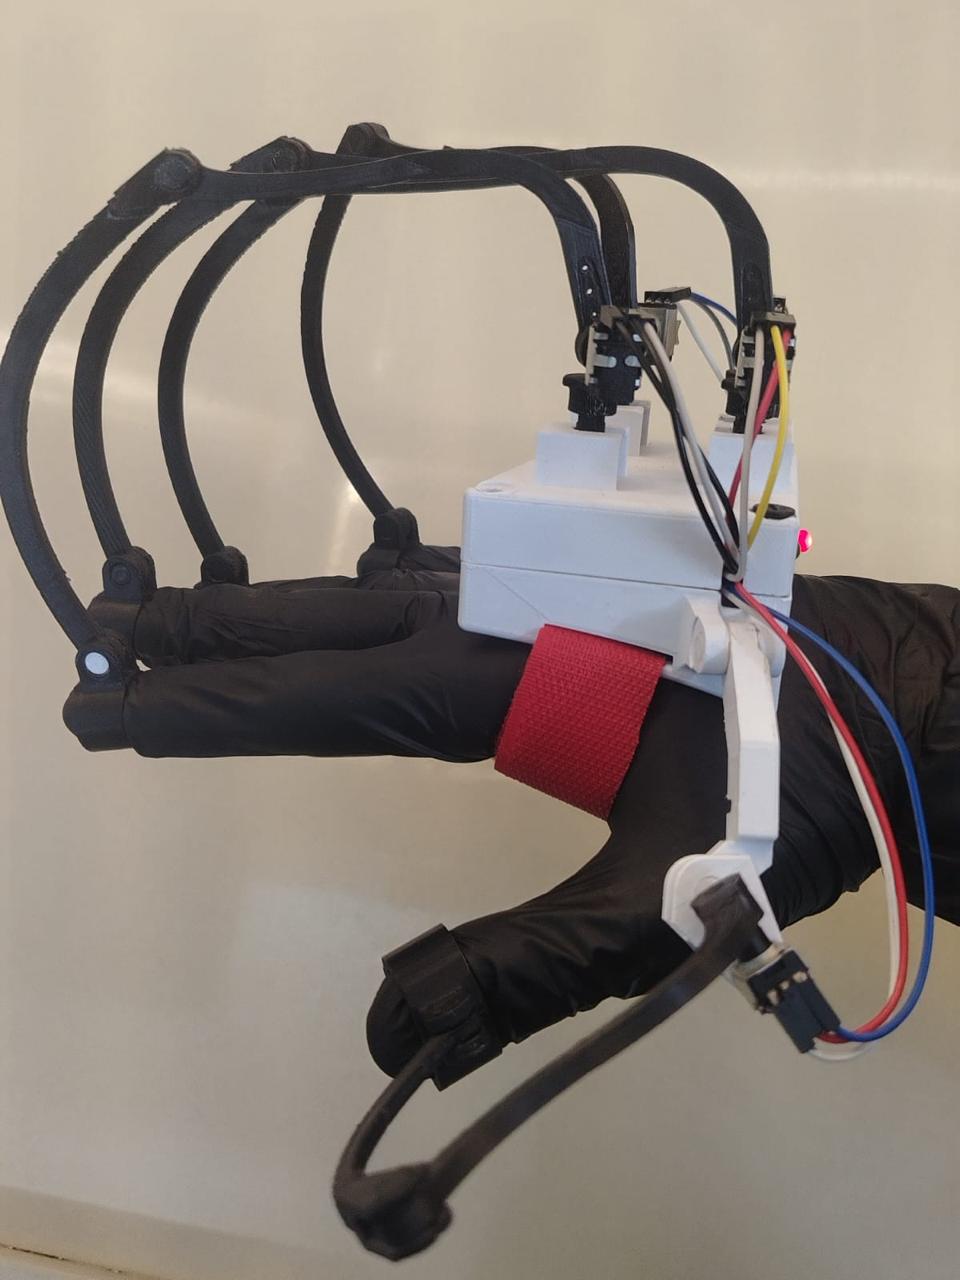
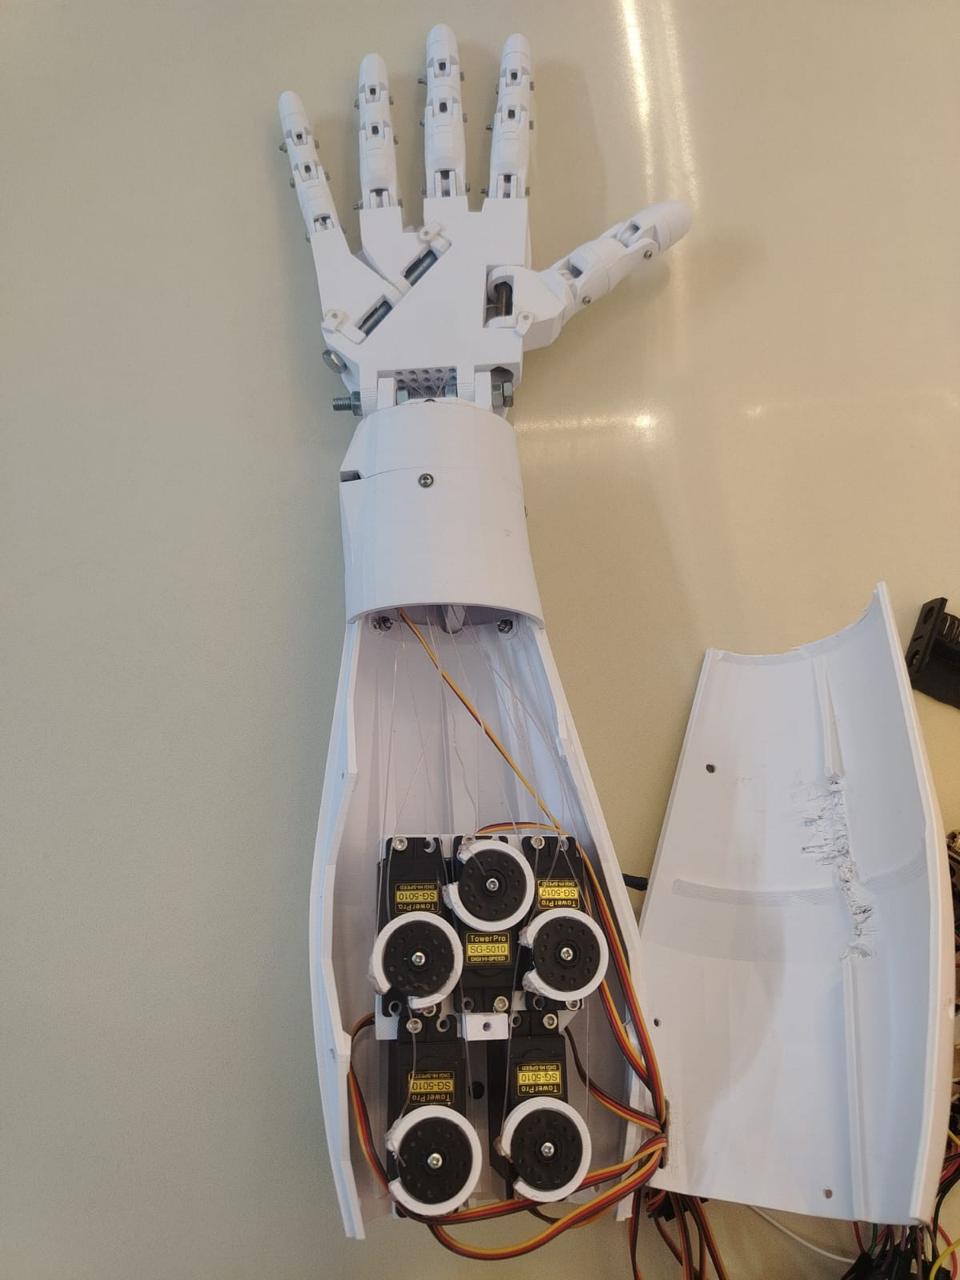
This project presents a robotic hand control system based on a somatosensory glove capable of capturing finger and wrist movements and translating them into control commands for a robotic hand. The system utilizes potentiometers to measure finger movements and an MPU6050 sensor to detect wrist motion. ESP32 microcontrollers and Bluetooth Low Energy (BLE) communication are employed for real-time data processing and wireless transmission. The robotic hand, based on the InMoov Hand design, reproduces the detected movements using six servo motors responsible for controlling the fingers and wrist. The primary objective of this project is to develop a low-cost, user-friendly, and real-time robotic control system that accurately mimics human hand movements. The proposed system provides a practical platform that can be further utilized in applications such as prosthetic devices, rehabilitation systems, remote operation, and human–robot interaction research,
NURAI · 2026
المسار البيئي
Smart Underground Water Leak Detection Robot
This project presents an automated, non-destructive mobile robotic rover designed for modern infrastructure monitoring. Built with an acoustically decoupled piezoelectric ceramic sensor, our syst…
الفريق
NASA
رمز الفريق
NURAI2026-0722
المشرف
م.م هبه كردي
قراءة الوصف الكامل للمشروع
This project presents an automated, non-destructive mobile robotic rover designed for
modern infrastructure monitoring. Built with an acoustically decoupled piezoelectric
ceramic sensor, our system detects and classifies underground pipeline leakages from
the surface without requiring invasive excavation. The core outcomes demonstrate high
precision in localized leak identification at depths of 1.0 to 1.5 meters. By eliminating
structural chassis noise during sampling and deploying an intelligent Python-based
XGBoost model, we achieve highly reliable autonomous classification while
significantly reducing labor costs.