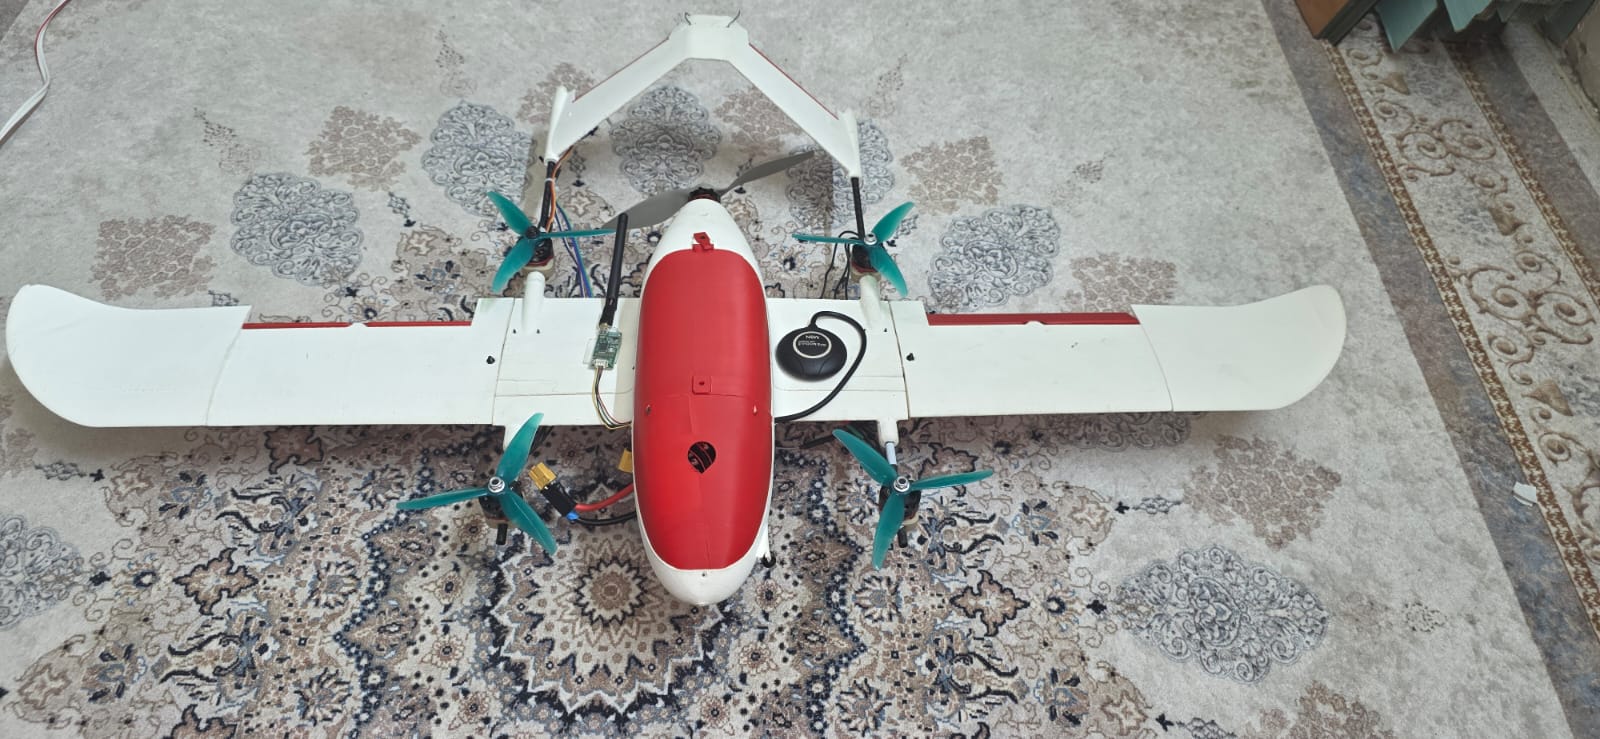
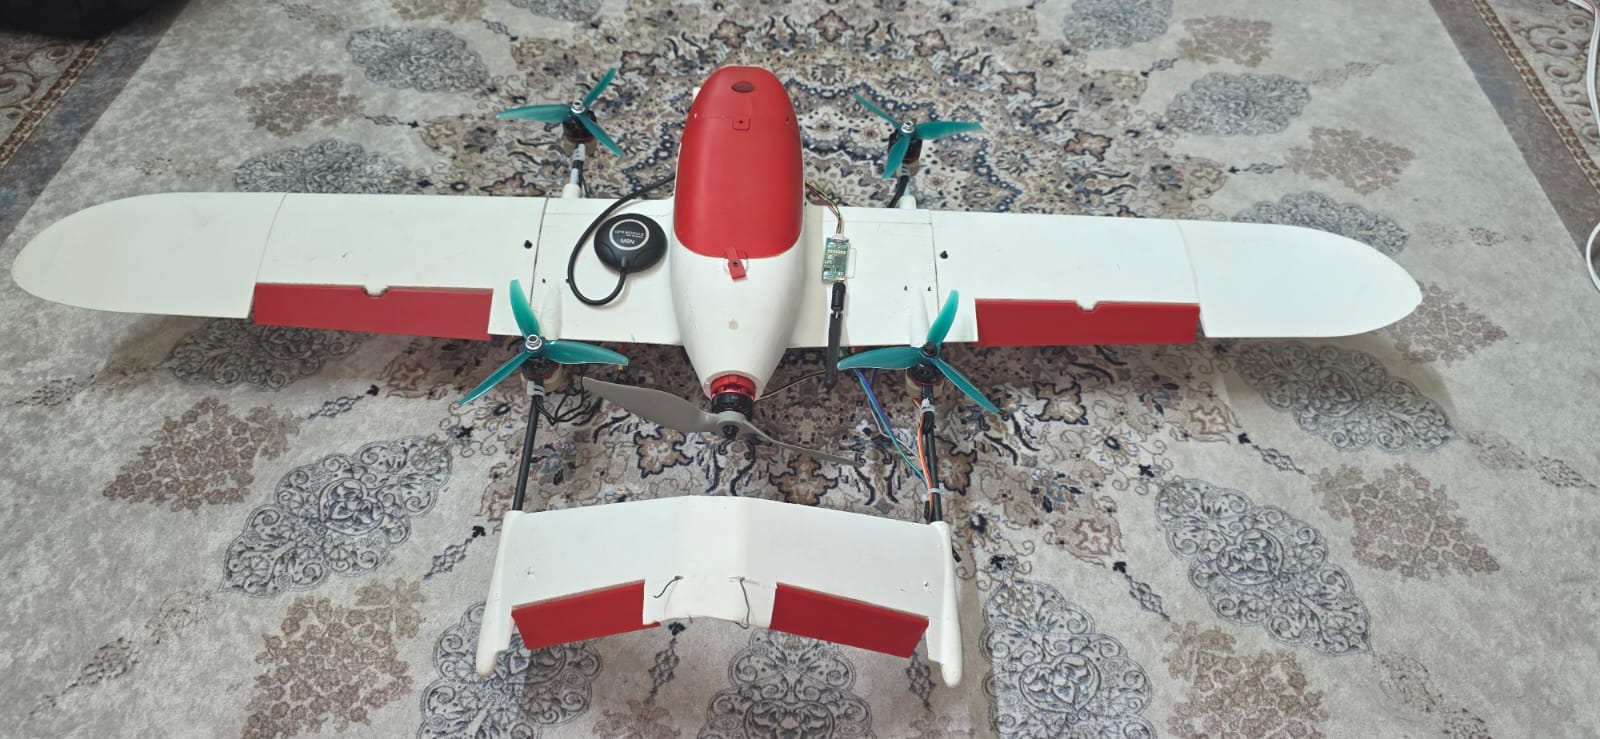
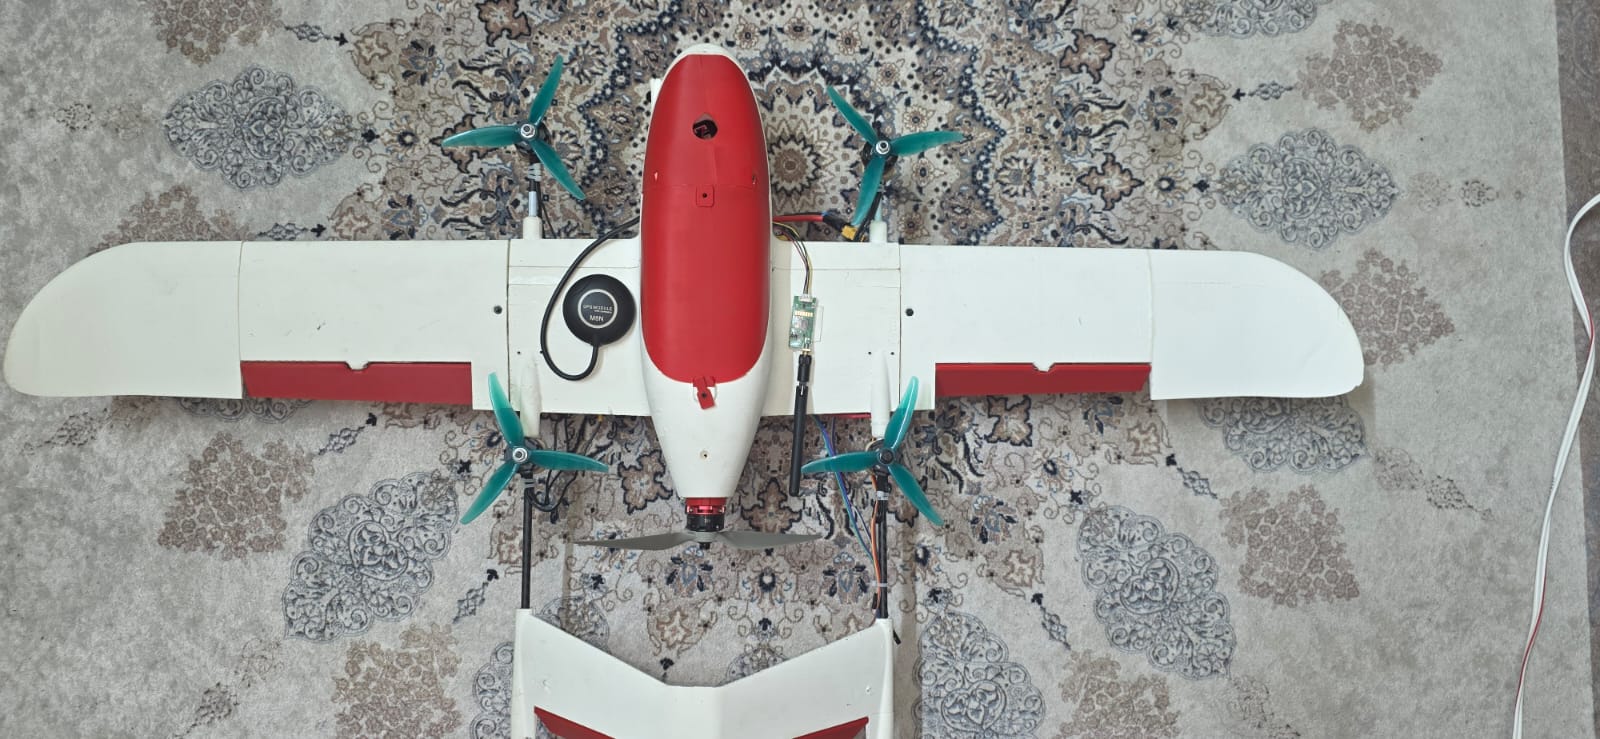
(Smart object Tracking Drone) This project introduces an AI-powered hybrid QuadPlane Vertical Takeoff and Landing (VTOL) drone designed to overcome the endurance and payload limitations of tradit…
الفريق
التراث 1
رمز الفريق
NURAI2026-0079
المشرف
د. حامد هادي منسي
قراءة الوصف الكامل للمشروع
(Smart object Tracking Drone)
This project introduces an AI-powered hybrid QuadPlane Vertical Takeoff and Landing (VTOL) drone designed to overcome the endurance and payload limitations of traditional surveillance platforms. By utilizing a decentralized architecture that offloads complex computational tasks to a ground station, the vehicle achieves extended flight times, increased cruise range, and minimized airborne weight. The integrated system provides zero-latency, real-time monitoring capabilities, enabling automated weapon detection and biometric suspect verification from safe stand-off distances. This high-efficiency platform delivers significant operational value across multiple civilian and defense sectors, serving as an advanced tool for law enforcement urban policing, automated border surveillance, and rapid search-and-rescue missions.
المسار الصناعي
SMART WALL-CLIMBING ROBOT FOR NAVIGATING VERTICAL SURFACES
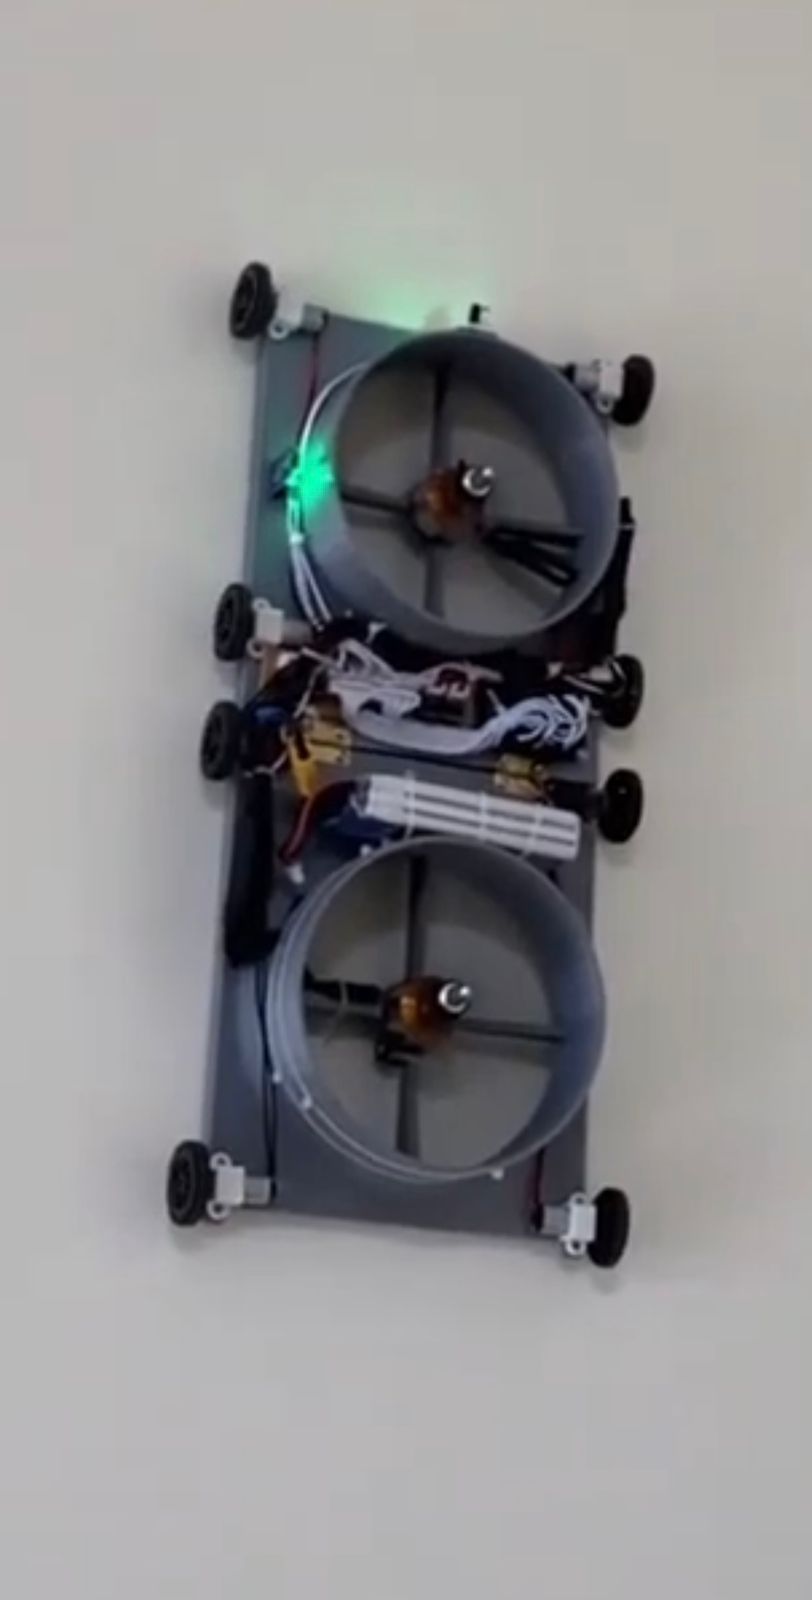
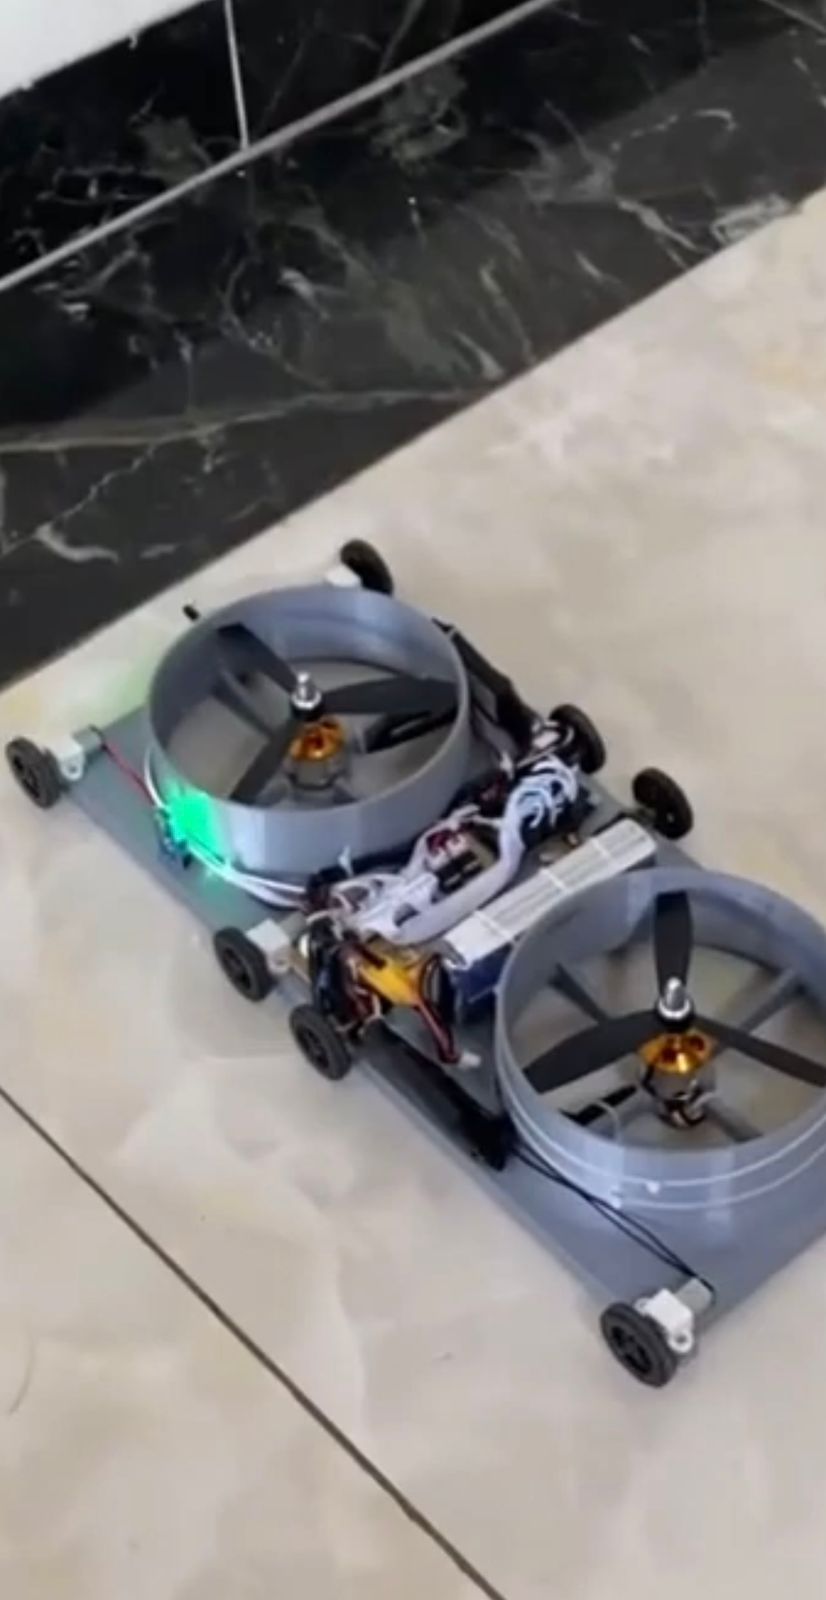
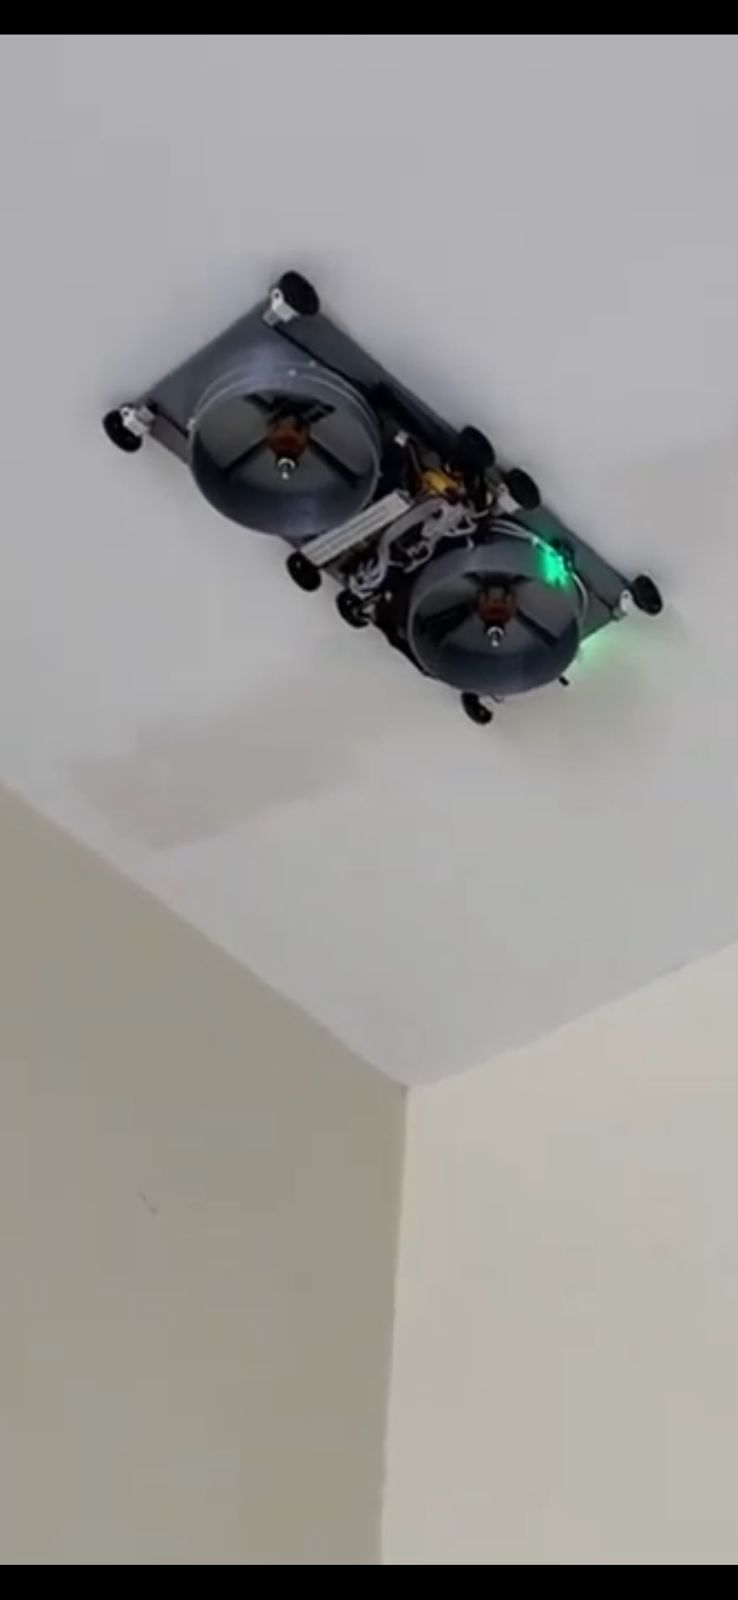
This project presents an advanced AI-powered wall-climbing robotic platform engineered to pioneer the field of zero-risk vertical inspection. Built around an ESP32 microcontroller, the current pr…
الفريق
التراث ٢
رمز الفريق
NURAI2026-0080
المشرف
د. حامد هادي منسي
قراءة الوصف الكامل للمشروع
This project presents an advanced AI-powered wall-climbing robotic platform engineered to pioneer the field of zero-risk vertical inspection. Built around an ESP32 microcontroller, the current prototype successfully masters aerodynamic adhesion using a high-efficiency Electronic Ducted Fan (EDF) coupled with high-torque drivetrain mobility. The system features a decentralized edge-computing fail-safe that processes real-time ultrasonic sensor data for instantaneous obstacle avoidance. Human-robot interaction is elevated through a sophisticated Python-based AI assistant ("Jarvis") that executes semantic intent classification using the SBERT model. A multi-threaded, full-duplex telemetry pipeline ensures continuous, high-speed data exchange between the vehicle and the ground control station. This prototype establishes a robust foundational architecture designed to integrate future multi-sensor payloads, such as thermal imaging, LiDAR, and IoT cloud ecosystems